Borinot
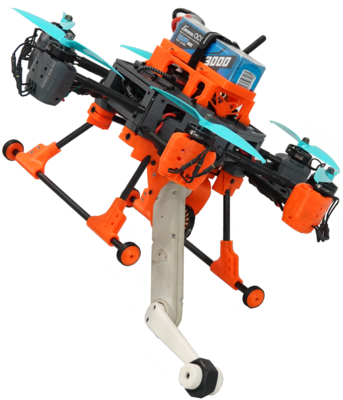
Robot / hardware buildResearch aerial manipulator combining a six-motor flying platform with a two-link torque-controlled extremity and an external motion-capture setup. [1] [5] [6] [7]
Build & first use →Official websiteBill of materials
- For
- Research laboratories able to integrate custom PX4, ROS 2, ODRI actuators and motion capture [1]
- Cost
- No current cost yet. Upstream bill of materials [6]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- BSD-3-Clause · Details by part
Overview
Borinot combines a six-motor flying platform with a two-link extremity that upstream describes as a tail, hand or leg depending on the experiment. The hardware list specifies six TMotor F90-1300KV motors with F35A 6S ESCs, an Intel NUC i7 and Pixhawk 5. The arm uses ODRI-based actuator components with a master board and micro driver. This is a research integration project, not just a printable airframe. [1] [6] [7]
Is this for you?
3D preview
Borinot with two-link flying arm simulation robot description. The HiDRo flying-arm robot description (borinot_flying_arm_2.urdf in the robots folder of hidro-iri/hidro_robots at commit 6cc6453) at zero joint positions: the hexacopter base, six propellers and the two links of the torque-controlled arm on the source joint tree (9 visual meshes). It is a simulation model: motors, electronics, battery and the leg or tail variants of the arm are not shown as separate parts, and the separate cad_files parts of the Borinot hardware repository are not used. The model repository gives no license (its package.xml license field is an unfilled placeholder) and the Gepetto example-robot-data mirror lists its license as NA; the BSD-3-Clause license of the separate Borinot hardware repository is not assumed to cover it. No reuse, manufacturing or redistribution clearance is claimed. Fit, flight and motion are not verified.
No license identified: the hidro_robots model repository (commit 6cc6453) has no license file and its package.xml license field is an unfilled placeholder; the Gepetto example-robot-data copy of this model lists “license: NA”. The separate Borinot hardware repository is BSD 3-Clause (Copyright (c) 2023, hidro-iri), but it does not state that this license covers the model repository, so it is not assumed to. Open Source Robotics shows this simulation description for reference with attribution to the HiDRo group at IRI (CSIC-UPC), Pep Martí Saumell (model) and Patrick Grosch (hexacopter design); no reuse, manufacturing or redistribution clearance is claimed. License: none identified (hidro_robots package.xml license field is a placeholder) · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: HiDRo group, IRI (CSIC-UPC); model by Pep Martí Saumell, hexacopter designed by Patrick Grosch, revision 6cc64532a5e65fb0085fe1a6008ab20cb8ef1010. Original and preview: No license identified (hidro_robots package.xml license field is an unfilled placeholder; example-robot-data mirror: NA). Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Upstream bill of materials [6]
- Hardware configuration
Six-motor aerial platform with a two-link extremity configurable for manipulation or contact-motion research.
- Controller
Intel NUC i7 companion, Pixhawk 5 flight controller and ODRI master board/micro driver.
- Sensors
- Flight-controller IMU
- External Optitrack pose input
- ODRI arm state feedback
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Preserve the estimation chain and its coordinate conventions
The documented state-estimation route combines Pixhawk IMU data with Optitrack position and orientation. Motion-capture data travels through the network to the NUC, then to PX4; the fused estimate returns to the NUC. The ODRI board separately supplies arm state. An external motion-capture computer, network and base station are therefore part of the described setup. [5]
The architecture names three conventions: Optitrack FUR, PX4 FRD and ROS 2/Eagle MPC FLU. It assigns transformations to the StatePubSub node. A recreation needs to preserve those transformations and the source of each state estimate; simply connecting all devices does not establish consistent coordinates. This review did not measure estimation accuracy or inspect a complete running workspace. [5]
Match printable parts to the incomplete assembly record
The archive contains STEP and STL parts under hardware/cad_files, including main-body, limb and landing-gear pieces. Several guide links instead use CAD/... paths. The inventory and the assembly illustrations should be reconciled before selecting fabrication files; this review did not validate part fit or completeness. [6] [7] [14]
The parts list leaves one O-ring diameter unspecified, and the flying-arm guide leaves assembled weight unresolved. Its ODRI component links also require a separately matched actuator version. These gaps prevent a complete configuration-specific BOM, mass or delivered cost from being established here. No placeholder is interpreted as a measured specification. [6] [7]
The software guide selects custom branches
The documented environment uses Ubuntu 20.04 and ROS 2 Galactic. PX4 comes from the project's motor_control branch for direct actuator control. Eagle MPC uses the bfa2_experiments branch, while the guide selects a modified Crocoddyl sbfddp-v2 branch. Some library versions are stated, but these moving branch references do not identify a complete immutable working set. [8] [9] [10]
The onboard workspace manifest adds seven repositories, including Eagle ROS 2, robot models, ODRI ROS 2, PX4 messages and the VRPN client. It mixes experiment branches with main and master. The setup guide also requires compatible message selections on both sides of the PX4/ROS bridge and calls out a yaml-cpp include-path problem. Preserve the actual resolved revisions and local edits before treating the instructions as reproducible. None of those build or configuration changes was executed here. [11] [12]
The Eagle MPC guide warns that numeric parsing depends on a locale using a decimal point. Its visualization example also needs a display. These host-environment requirements are separate from the aircraft's physical assembly. [10]
Scope of the available release
The primary repository carries a BSD 3-Clause license and provides documentation, integration configuration and mechanical files. That grant does not establish the licensing or completeness of every external flight-controller, ODRI or software dependency. The full matched electronics and firmware set remains unresolved. [3] [6] [9] [12] [14]
The operation guide describes a laboratory bring-up and flight workflow, but no fabrication, calibration, simulation, flight or contact experiment was performed for this profile. Upstream demonstrations are not reported as our own reproduced results. [1] [13]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Apr 30, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 421fb26287e4db90bc5f6cbdb1a48baca0d0d250 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · BSD-3-Clause Project-level BSD notice and preserved STEP/STL parts; third-party ODRI components retain separate terms and version matching is unresolved. [1] [3] [14] |
| electronics | not found · License not fully assessed External flight-controller/ODRI hardware and modified PX4 identified; complete matching editable electronics and device firmware sources not established in the selected primary archive. [6] [9] [12] |
| firmware | not found · License not fully assessed External flight-controller/ODRI hardware and modified PX4 identified; complete matching editable electronics and device firmware sources not established in the selected primary archive. [6] [9] [12] |
| software | available · BSD-3-Clause Integration manifests/configuration available; implementation lives in external repositories whose complete matched payload set was not preserved. [3] [12] |
| documentation | available · BSD-3-Clause [1] [3] [4] |
Selected model-based control route uses robot models and optimization, not a pretrained learned policy or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 hidro-iri/Borinot: README.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Scope of the available release and 1 more - S002 hidro-iri/Borinot: commit 421fb26
- S003 hidro-iri/Borinot: LICENSE
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Scope of the available release, Source files and licenses - S004 hidro-iri/Borinot: files
Revision, date & where cited
github.com · revision
421fb26· archive file inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S005 Borinot architecture/README.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 1 more - S006 Borinot hardware/0_components_list.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S007 Borinot hardware/6_flying_arm_assembly.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Match printable parts to the incomplete assembly record - S008 Borinot software/README.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: What you need, The software guide selects custom branches - S009 Borinot software/1_pixhawk_configuration.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, The software guide selects custom branches, Scope of the available release and 1 more - S010 Borinot software/2_eagle_mpc_installation.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: What you need, The software guide selects custom branches - S011 Borinot software/4_ros2_workspace.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Assembly & first use, The software guide selects custom branches - S012 Borinot config/borinot_onboard.repos
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, The software guide selects custom branches, Scope of the available release and 1 more - S013 Borinot operation/README.md
Revision, date & where cited
github.com · revision
421fb26· Accessed Oct 1, 2026
Used for: Scope of the available release - S014 Preserved mechanical files
Revision, date & where cited
github.com · revision
421fb26· archive paths · Accessed Oct 1, 2026
Used for: Assembly & first use, Match printable parts to the incomplete assembly record, Scope of the available release, Source files and licenses - S016 Upstream image and reuse attribution
Media-only review: Upstream image of Borinot with its aerial platform and manipulator; no flight or contact test was performed by us. Reuse basis: BSD-3-Clause; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
hidro-iri and Borinot contributors · github.com · revision
421fb26· Image SHA-256 67ac919c112409dd7a2fca404e12b7415a0e7e99a362b9ac49d2de1eb36b6a3b; repository · Accessed Oct 25, 2026
Videos
- S015 Borinot: an open thrust-torque-controlled robot for research on agile aerial-contact motion (YouTube video)
Video uploaded by Institut de Robòtica i Informàtica Industrial, CSIC-UPC, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Institut de Robòtica i Informàtica Industrial, CSIC-UPC · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S015): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.