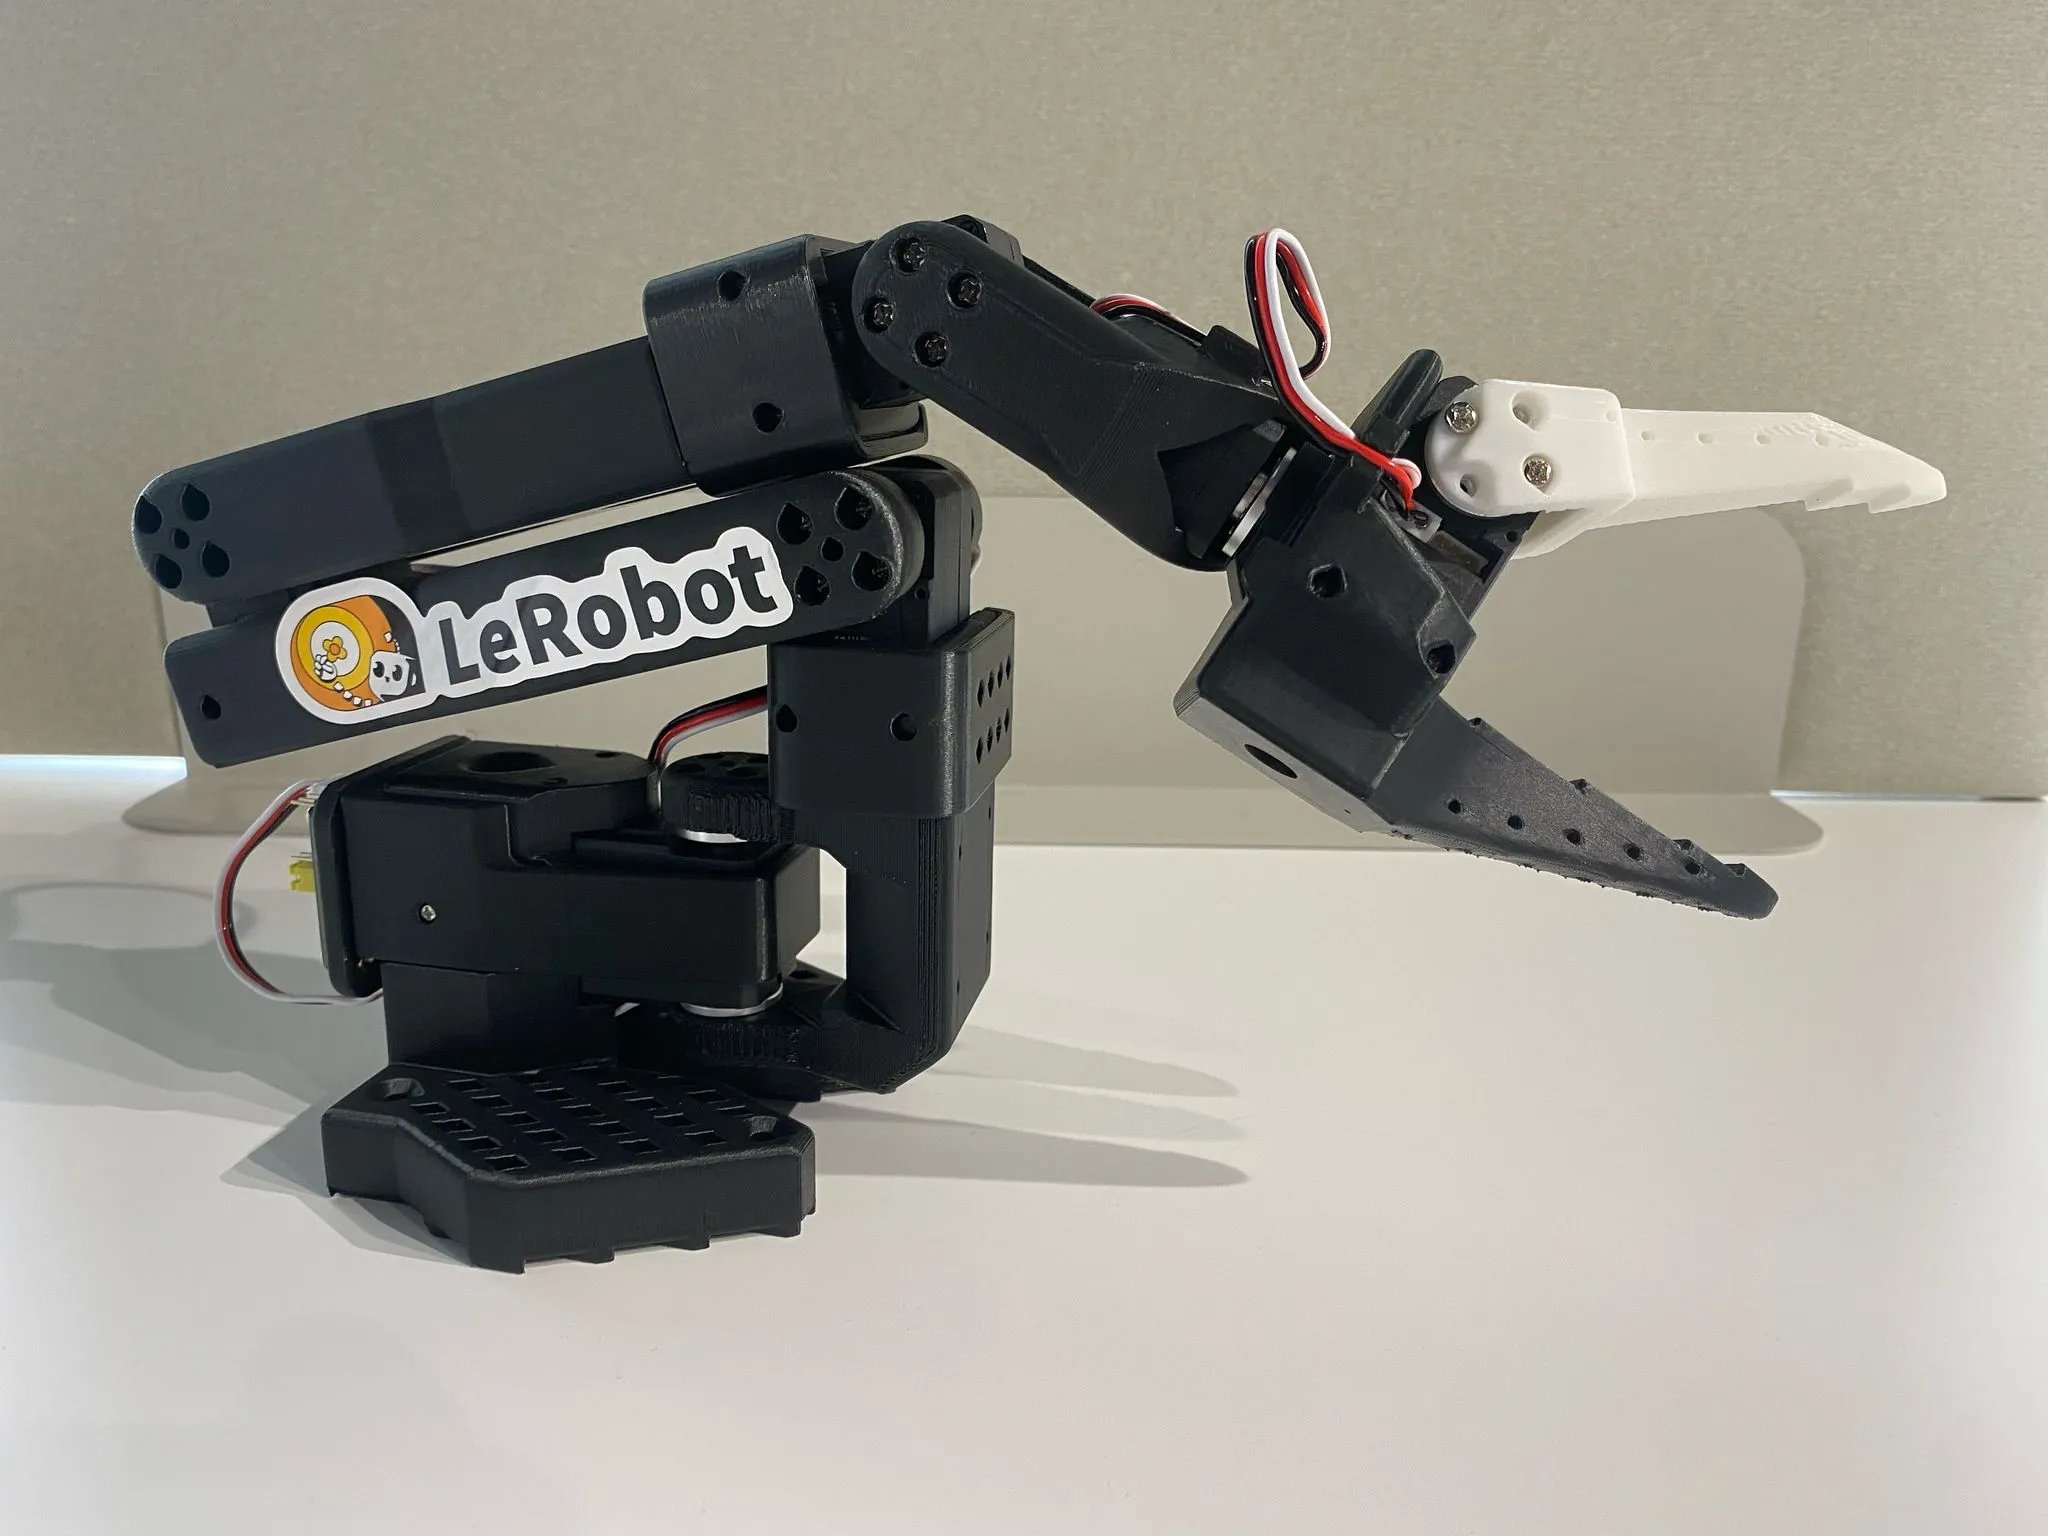
Teleoperate an arm
SO-101 →
Compare follower-only and leader–follower configurations, then follow the pinned build and calibration route.
Printed frame, compatible host computer and calibration on the actual arms.
The open robotics reference desk
Explore open source robots, components and software. Compare requirements, parts costs and licenses, then find resources to get started.
Source researched · Hardware not tested by us. How we review →
131 profiles: robots, controllers, sensors and parts costs.
23 profiles: tools for control, simulation and robot learning.
43 profiles: grippers, hands and tools, with documented interfaces.
Choose by task
Selected for their documented workflows. Source researched; we have not tested these setups.
Teleoperate an arm
Compare follower-only and leader–follower configurations, then follow the pinned build and calibration route.
Printed frame, compatible host computer and calibration on the actual arms.
Start in simulation
Follow the documented introductory tutorial to build a virtual world and run a controller.
Check the supported operating system and installation requirements before starting.
Explore robot learning
Begin with an existing dataset to inspect observations and actions before choosing physical hardware.
Python and workflow-specific dependencies; training needs a separate compute budget.
Parts lists we priced line by line from US listings, with what each price leaves out. Priced Oct 4, 2026.
Planning a build
Compare exact servo quantities, boards and shared requirements before choosing an SO-101 configuration.
Read the guide →sourcingUse examples from SO-101, LeKiwi and Microban to identify missing costs, dated offers and unverified substitutions.
Read the guide →Find free courses, books and exercises by topic, level and the equipment you have.
Today: source-researched profiles and parts estimates. Next: hands-on build reports with setup steps, failures and repeatable results. Kits may follow after testing; none are available yet.
Read our testing plan →