Reachy 2
Robot / hardware buildA Reachy 2 ROS 2 workspace providing robot descriptions, control interfaces and simulation launch components. [1]
Build & first use →Official website
- For
- ROS 2 developers evaluating Reachy 2 integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- Ecosystem
- ROS 2
- License
- Apache-2.0 · Details by part
Overview
Reachy2 Core v1.7.5 contains the ROS 2 packages for descriptions, configuration, launch and control. It is useful for identifying the software pieces of a Reachy 2 setup; it is not, by itself, a manufacturing or complete parts archive. [1] [2] [4]
Choose the kind of experiment before treating the packages as equivalent. reachy_fake mimics joint states without hardware, reachy_gazebo supplies simulation integration, and reachy_controllers interfaces with hardware and simulated joints. A successful fake-interface demonstration would not establish physical motion, payload or reliability. [1]
The documented dependency starting points are ROS 2, requirements.txt, pyproject.toml and dependencies.sh. Preserve and inspect those alongside the chosen launch/configuration files before building an environment. This review has not executed the installer or reconciled those dependencies to a physical robot revision. [1]
Apache-2.0 applies to this repository; it does not establish a blanket license for manufacturing the robot. Complete hardware sources, current delivered cost and our ability to support a build remain unresolved. [3]
Is this for you?
- Known limitations
- Core repository is a software workspace, not a complete manufacturing pack
- Fake joint interfaces do not establish physical performance
3D preview
Reachy 2 kinematics model. The official Reachy 2 visual model, with its source body grouping and component placement. Independent joints are shown at zero; linked joints retain their source-defined offsets. This simplified model is not manufacturing CAD or a demonstration of motion.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Pollen Robotics contributors, revision 149948db13b108b9f4a940a5bb94f50422eadd27. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- ROS 2
- Repository requirements.txt and pyproject.toml
- System dependencies described by dependencies.sh
Hardware & parts
- Hardware configuration
Humanoid platform
Editorial form classification from the inspected upstream overview.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| electronics | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| firmware | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| software | available · Apache-2.0 Core ROS packages; purchased hardware and external dependencies have separate scope. [1] [4] [3] |
| documentation | available · Apache-2.0 Primary workspace overview and dependency pointers. [1] [4] [3] |
This profile covers the described physical configuration and control route without a particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 pollen-robotics/reachy2_core: README.md
Revision, date & where cited
github.com · revision
0c79e40· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S002 pollen-robotics/reachy2_core: commit 0c79e40
- S003 pollen-robotics/reachy2_core: LICENSE
Revision, date & where cited
github.com · revision
0c79e40· Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S004 pollen-robotics/reachy2_core: files
Revision, date & where cited
github.com · revision
0c79e40· archive file inventory · Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S006 Upstream image and reuse attribution
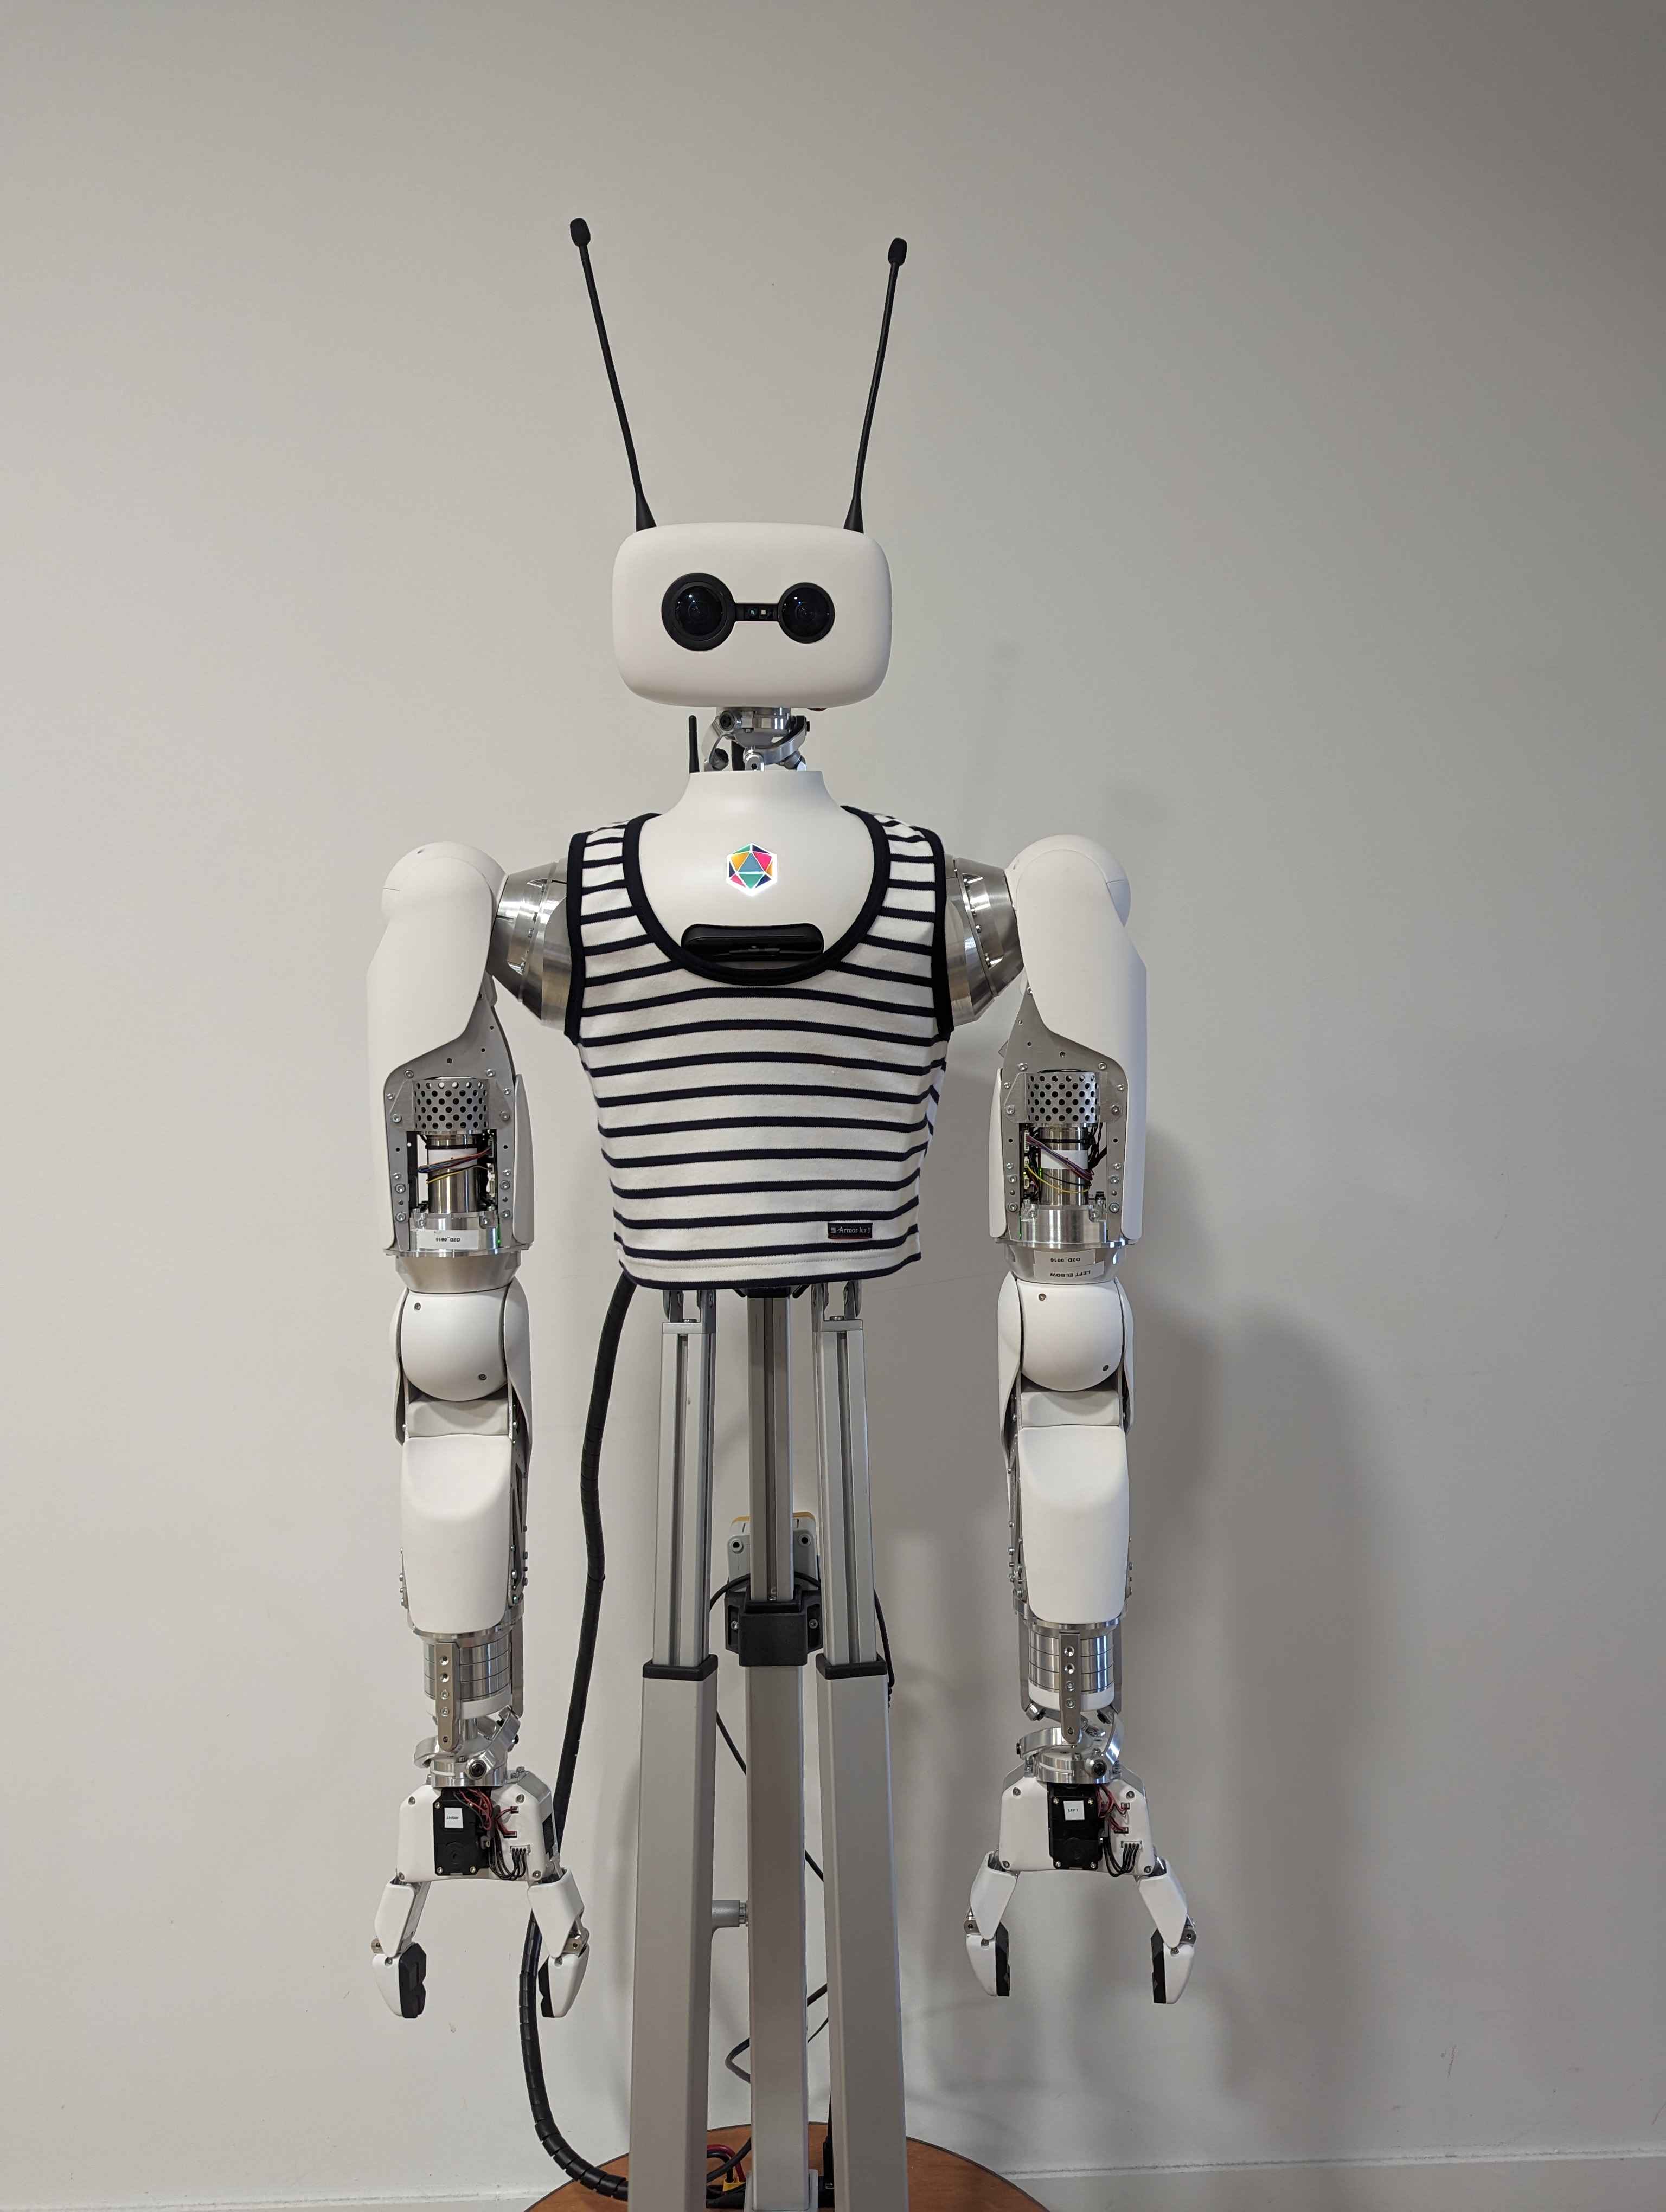
Media-only review: Photograph of Reachy 2 in the straight posture shown in its official setup guide. The upper body is on an adjustable stand; a mobile base is not visible. Reuse basis: Apache-2.0. The photo is an original documentation asset in the same first-party repository as its Apache-2.0 LICENSE. No media-specific exclusion, separate license or third-party credit was found outside dependency/theme folders. Exact generation identified by Reachy2 setup path, newer Orbita joint arms, camera head, torso and the official documentation explicitly limited to Reachy 2. The older Reachy mobile image in assets/images/advanced/overview/reachy-mobile.png is a different generation and excluded. The homepage hello_reachy2.png is a rendering and excluded. The catalog selects Reachy2 workspace v1.7.5, not a finer mechanical subrevision; photo does not establish software version or hidden electronics. Logos/clothing are incidental to the photographed robot; no affiliation/endorsement implied. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Pollen Robotics / Reachy 2 documentation contributors · github.com · revision
1caeb97· reachy2-docs , assets/images/getting-started/setup-reachy2/start-reachy2/straight_posture.jpg; original setup photograph, 3072×4080 pixels; image SHA-256 15ada5676ab56631406b1fc41a42843112f00a3ad621483cee08d695be04f1f1 · Accessed Oct 26, 2026
Videos
- S005 Pollen Robotics (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Pollen Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S005): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.