Hardware / Wheeled & tracked robots
AlohaMini2
Printable three-wheel mobile base with a motorized lift and two AM-ARM200 arms, run as a Raspberry Pi 5 host with a PC client through the lerobot_alohamini fork.
Specifications & sources
Robots, end effectors and software: compare setup requirements, configuration costs and source files.
197 entries · Newest published first
Source researched · Not hands-on tested
Hardware / Wheeled & tracked robots
Printable three-wheel mobile base with a motorized lift and two AM-ARM200 arms, run as a Raspberry Pi 5 host with a PC client through the lerobot_alohamini fork.
Hardware / Robot arms & manipulators
Printable 6+1 DoF leader/follower arm pair using Feetech STS3215 and STS3095 servos, with LeRobot support supplied through the separate lerobot_alohamini fork.
Hardware / Legged robots
Twelve-actuator bipedal leg set (lower body only) with articulated toes and a two-motor RSU ankle, published as STL simulation meshes, an MJCF model and an LFS-stored STEP assembly.
Hardware / Other physical robots
Open-hardware biopotential analog front-end board (2.54 × 1.00 cm) for ECG, EMG, EOG and EEG acquisition with a 5 V microcontroller ADC; a sensor component with EMG servo and claw-control example sketches, not a robot.
Hardware / Aerial robots
Teensy 4.0 quadcopter taught step by step in a 222-page build and programming manual, with a PCB upper frame and separate per-chapter Arduino code repositories; manual and code are licensed CC BY-NC-SA 4.0.
Hardware / Aerial robots
Sub-250 g collision-resilient quadcopter with a bamboo or carbon-rod frame joined by printed TPU parts, an INAV flight controller and a Raspberry Pi Zero W controlled through the MIT-licensed cognifly-python library; no license file was identified for the frame files.
Hardware / Robot arms & manipulators
Open controller electronics, FPGA firmware and cisst/SAW software for research systems built from retired da Vinci arms and consoles; the arms themselves are supplied hardware, not an open design.
Hardware / Aerial robots
ESP32 quadcopter with a 3D-printed frame, four brushed motors switched by MOSFETs, an SPI IMU board, Arduino firmware with Wi-Fi/MAVLink control and a Gazebo simulator; no repository license file was identified.
Hardware / Other physical robots
Pollen Robotics handheld demonstration recorder (Raspberry Pi 4, fisheye camera, OAK-D SR, finger angle sensors) with an offline SLAM pipeline that exports LeRobot datasets.
Hardware / Other physical robots
Fingertip-worn haptic device that rotates one linear resonant actuator with a Dynamixel servo to render 2D directional cues during robot teleoperation; printable parts, an editable source design and a priced BOM are released, but no control code was identified.
Hardware / Wheeled & tracked robots
200 mm 3D-printable differential-drive pet robot with an ESP32, BLDC gear motors and a choice of hobby LiDARs, run through the shared Kaia.ai ROS 2 stack; sized for common 220 mm-class printers.
Hardware / Wheeled & tracked robots
300 mm 3D-printable differential-drive pet robot with an ESP32, BLDC gear motors, a 360-degree LiDAR and a phone or tablet head, run through the shared Kaia.ai ROS 2 stack; pet character and skills are upstream work in progress.
Hardware / Aerial robots
3D-printed tricopter/flying-wing VTOL with two tilting front motors and a fixed rear motor, tuned on ArduPlane; STL/3MF artwork and parameter files are licensed CC BY-NC-SA 4.0 and native CAD is withheld.
Hardware / Robot arms & manipulators
Unpowered 3D-printed six-joint leader arm read by AS5600 encoders through an ESP32, used to teleoperate an SO-ARM follower in MuJoCo or through LeRobot.
Hardware / Wheeled & tracked robots
Differential-drive AMR base with a sheet-metal chassis, Raspberry Pi 5, Teensy 4.0, two 60 W ZD BLDC gearmotors, RPLIDAR A1 and ROS 2 Jazzy; upstream discloses open safety gaps such as no battery fuse or hardware E-stop.
Hardware / Robotic hands
Single-actuator, tendon-driven anthropomorphic hand design from the OpenBionics initiative, with 3D-printed and laser-cut variants, parametric SolidWorks CAD and a 2015 assembly report; repository-wide CC BY-SA 4.0 statement.
Hardware / Other physical robots
DIY triangulation scanning laser rangefinder (STM32F030, TSL1401CL line sensor, 780 nm laser, slip-ring head) rated by its author at 5 scans/s, 2-degree steps and up to 4 m; a sensor component for robots, not a robot.
Software / Models
Deep-learning visual navigation engine for the Crazyflie 2.1 nano-drone: PyTorch CNNs, quantization and deployment flow for the AI-deck GAP8 processor, onboard flight application and a collected dataset; code Apache-2.0, v3 dataset CC BY-NC-SA 4.0.
Hardware / Robot arms & manipulators
Seeed Studio 6+1 DoF desktop arm with CNC aluminium and printed parts, published as B601-DM (Damiao motors, 24 V) and B601-RS (RobStride motors, 48 V) under CERN-OHL-W-2.0 hardware terms.
Hardware / Humanoids
Full-size DIY humanoid prototype from RoboParty with CNC-machined metal structure, 23 Damiao actuators in the published BOM, ROS 2 deployment and Isaac Lab training code; V2.0 hardware is not compatible with V1.0.
Hardware / Legged robots
Small 3D-printed ESP32 quadruped with eight MG90S servos, an OLED face and Wi-Fi control; four controller-board routes need matching firmware pin settings.
Hardware / Other physical robots
Room-scale four-line cable robot (Arpeggio hardware) with two corner anchors and a hanging camera gripper, driven by a host-run Python motion controller; a public prototype.
Hardware / Humanoids
Small 3D-printed humanoid using sixteen Feetech serial-bus servos and a Milk-V Duo S; the main repository is now a pointer, so the BOM and STLs come from the separate docs repository.
Hardware / Aerial robots
OpenESC-20x20 is a four-channel brushless motor controller with available KiCad sources and unresolved differences between headline ratings and technical test notes.
Hardware / Tendon-driven dexterous robotic hand
BiDexHand V4 is a 16-DoF tendon-driven hand with printed parts, a Servo2040 PWM route and ROS 2 control packages.
Hardware / Six-legged servo hexapod
Printed 18-servo hexapod with separate mechanical designs, Servo2040 firmware and a Raspberry Pi controller.
Hardware / Legged robots
Modular knee-and-ankle research platform with published assembly documentation, externally hosted design downloads and a separately licensed Python SDK.
Hardware / Aerial robots
ESP32-based educational quadcopter with a documented S2 V1.2 build and sensor-dependent assisted flight modes.
Hardware / Six-legged servo hexapod
Historical six-legged servo robot with available frame designs, Servotor32 control sources and a Python 2-era host application.
Hardware / Wheeled & tracked robots
Raspberry Pi camera and relay subsystem for targeted weed treatment, with printable enclosures and configuration-specific wiring requirements.
Hardware / Robot arms & manipulators
Open brushless servo-controller designs with CAN-FD control, board-specific electrical limits and motor calibration requirements.
Hardware / Robot arms & manipulators
Legacy dual-axis brushless motor control with public v3.x firmware; v3.6 board designs and newer-generation firmware have different openness boundaries.
Hardware / Embedded robot controller board
ROS-oriented STM32F7 controller with Arduino firmware sources and separate REVH hardware files whose precise reuse license remains unresolved.
Hardware / Robot arms & manipulators
Brushless belt-reduced research actuator core with a v1.1 prepared encoder-kit route, precision printing requirements and separately integrated motor control.
Hardware / Robot arms & manipulators
TriFingerEdu v1 is a nine-axis torque-controlled manipulation platform built from three FingerEdu modules, with a documented TI evaluation-board control route.
Hardware / Robot arms & manipulators
Nine-axis three-finger manipulation benchmark with a separately instrumented object. Historical v0.9 hardware and legacy software requirements are scoped separately.
Hardware / Legged robots
Twelve-axis quadruped benchmark with Dynamixel actuation and external-tracking support. Historical v0.9 hardware and legacy software requirements are scoped separately.
Hardware / Robot arms & manipulators
Motorized printed microscope with an RMS-objective build route, separate controller and software dependencies, and explicit beta-version compatibility limits.
Hardware / Robot arms & manipulators
Programmable laboratory liquid handler with a dedicated OT-2 software route, published customization files and configuration-specific calibration requirements.
Hardware / Robot arms & manipulators
Joint-matched teleoperation leaders for robot manipulators; selected coverage follows the YAM passive configuration and distinguishes the separate Franka FR3 ROS 2 workflow.
Hardware / Robot arms & manipulators
Printed rotary pendulum with Arduino Nano control and a MuJoCo-to-hardware learning pipeline; preserved sources include rig-specific distilled policy weights and differing bring-up microstep guidance.
Hardware / Robot arms & manipulators
Handheld gripper-based demonstration collection and diffusion-policy workflow, with separate robot deployment hardware and explicit SLAM, timing and source-artifact gaps.
Hardware / Wheeled & tracked robots
Small wheeled research robot; this profile covers e-puck2 using its official hardware guide, pinned Qt monitor and separately preserved STM32F407 firmware sources.
Hardware / Wheeled & tracked robots
Raspberry Pi extension for e-puck and e-puck2 robots, with Linux integration, separate controller firmware and an optional YRL expansion board.
Hardware / Wheeled & tracked robots
Educational wheeled robot; this profile selects Thymio II PCB version 2.1 design sources and separately preserved V14 firmware, with explicit generation and dependency boundaries.
Hardware / Wheeled & tracked robots
DIY robotic mower reference platform; this review selects the 1.0a10-Azurit release and records its PCB configuration, stored-setting behavior and conflicting license notices.
Hardware / Wheeled & tracked robots
RTK-guided mower conversion ecosystem; this review selects the v2 YardForce route and preserves its separate carrier-board and xCore firmware revisions.
Hardware / Wheeled & tracked robots
Experimental agricultural robot integration stack using ROS 2 Jazzy, ESP32/Lizard control and RTK GNSS; the selected sources distinguish Gazebo mission results from incomplete hardware validation.
Hardware / Wheeled & tracked robots
Precision farming rover with separate software, electronics and mechanical sources; the documented Docker simulation substitutes fake sensor data and is not evidence of field performance.
Hardware / Robot arms & manipulators
Track-mounted gardening robot with a moving gantry and interchangeable tools; this profile selects FarmBot Genesis v1.8 documentation and distinguishes the standard and XL installations.
Hardware / Wheeled & tracked robots
Agricultural weeding rover with published prototype V3 design files and an adapted CNC weeding tool; unfinished electronics and steering details require configuration work.
Hardware / Marine robots
Commercial underwater ROV with published integration CAD and open software; this profile selects the standard six-thruster R4 configuration and distinguishes it from the Heavy upgrade.
Hardware / Marine robots
Research autonomous underwater vehicle with Pixhawk, Raspberry Pi and Jetson TX2; this review selects the documented LoCO 1.0 configuration and separates later internal structure alternatives.
Hardware / Marine robots
Historical DIY underwater exploration platform; this entry selects the OpenROV 2.8 mechanical files and the corresponding named controller-board package for source research.
Hardware / Aerial robots
Research aerial manipulator combining a six-motor flying platform with a two-link torque-controlled extremity and an external motion-capture setup.
Hardware / Aerial robots
Educational quadrotor platform pairing a PX4 flight controller with Raspberry Pi and ROS; this entry selects Clover 4.2 construction and the documented ROS Noetic image route.
Hardware / Aerial robots
Small quadrotor development platform; this profile selects the brushed Crazyflie 2.1 hardware and distinguishes its firmware target from Brushless and Bolt variants.
Hardware / Aerial robots
Laser-cut quadrotor frame for carrying a smartphone or compact camera; the preserved frame files and original Spanish manual leave complete software and electronics reproduction unresolved.
Hardware / Wheeled & tracked robots
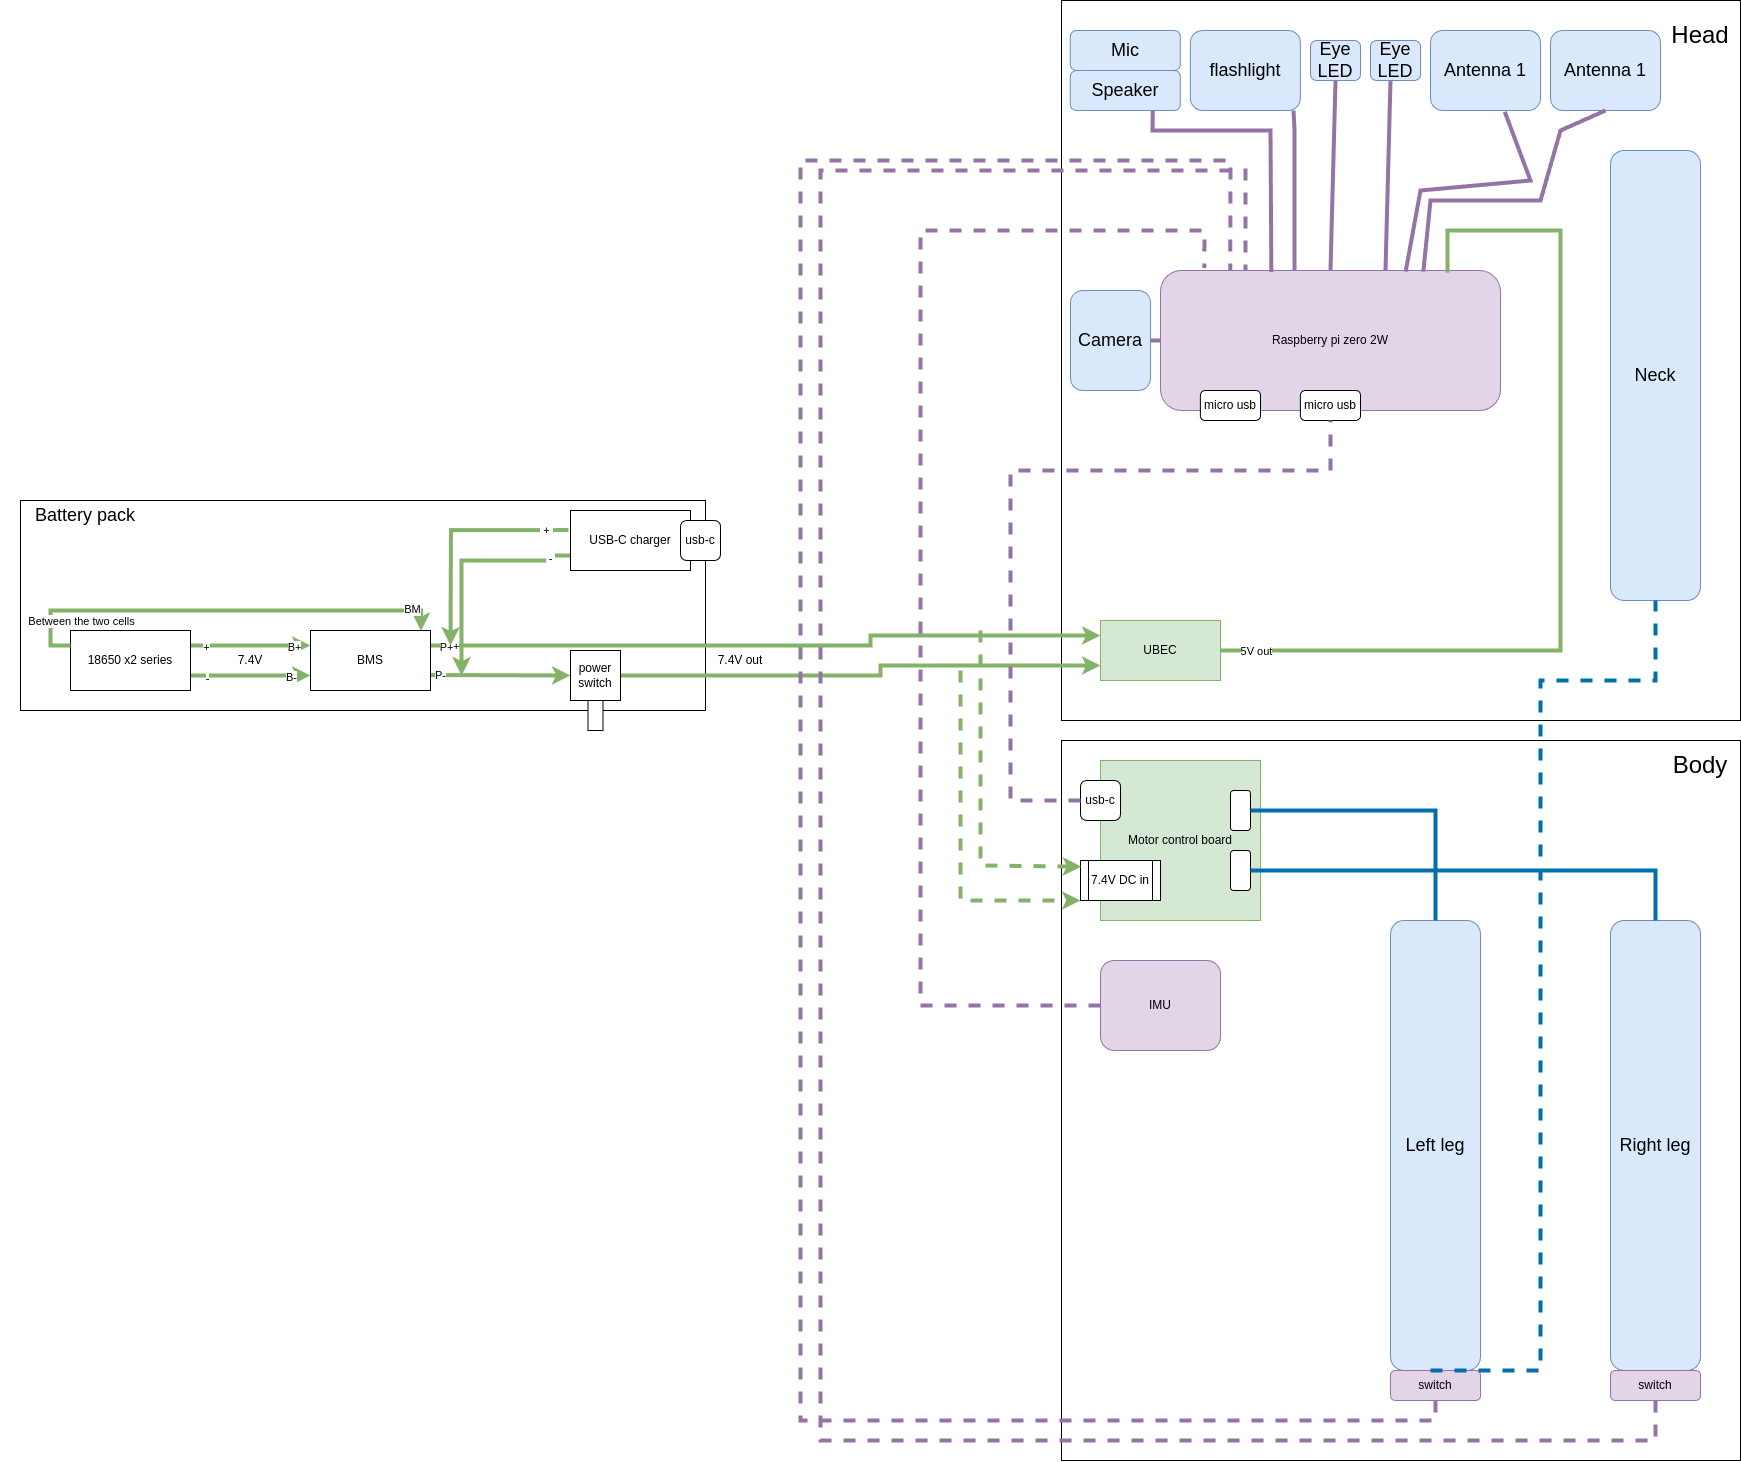
Two-arm mobile manipulator with a three-wheel omnidirectional base, released printable parts and a modified LeRobot control repository.
Hardware / Two-wheel inverted-pendulum balancing robot.
Two-wheel balancing robot with ROS 1 control and Gazebo simulation sources; physical construction uses custom motor drives, a Pi CAN shield and power distribution board.
Hardware / Wheeled & tracked robots
Small modular robot with a PCB chassis, ESP32-S3 and two- or four-wheel variants; separate Microblocks, MicroPython and ROS 2 routes have different maturity.
Hardware / Wheeled & tracked robots
Two-wheel balancing robot project using a Raspberry Pi, pi3hat and moteus motor controllers, with printed parts and source-defined balance settings.
Hardware / Wheeled & tracked robots
Raspberry Pi mecanum robot with ROS 2 navigation using lidar and an IMU; its published wheel commands are not measured wheel speeds.
Hardware / Wheeled & tracked robots
Three-wheel mobile manipulator with SO-100/SO-101 arm options, printed parts and a separate LeRobot teleoperation stack.
Hardware / Wheeled & tracked robots
Hardware-and-software platform combining two leader arms, two follower arms and an AgileX Tracer base for whole-body teleoperation and demonstration collection.
Hardware / Wheeled & tracked robots
Small tracked Jetson robot; this profile covers the preserved 1.5.1 source, whose container recipe targets ROS 2 Foxy and whose STL files carry noncommercial terms.
Hardware / Wheeled & tracked robots
Research vehicle conversion built around a specific mobility scooter, with Arduino throttle control, actuator steering and a legacy ROS/Gazebo stack.
Hardware / Wheeled & tracked robots
Four-wheel mobile base built from aluminum extrusions, with a documented articulated chassis, radio control and encoder-based motor control.
Hardware / Wheeled & tracked robots
Small Jetson Nano educational robot with printed chassis and browser-based control; the reviewed 0.4.3 build uses legacy Nano-specific images and matched wheel/caster parts.
Hardware / Wheeled & tracked robots
Mobile robot base with available ROS host software; the reviewed setup follows separately preserved Noetic sources, with unreleased controller firmware and revision-specific hardware constraints.
Hardware / Wheeled & tracked robots
ROSbot 2R mobile platform with separately versioned ROS packages and CORE2 microcontroller firmware; this entry distinguishes the 2R configuration from newer ROSbot hardware.
Software / Frameworks
GPU-accelerated robot-learning framework; the reviewed 3.0 early-access release introduces multiple physics backends and changed installation and migration workflows.
Software / Models
Transformer diffusion robot policies with pretrained checkpoints and fine-tuning tools; observation history, action statistics and robot-specific interfaces must match the selected model.
Software / Models
Vision-language-action model code, checkpoints and adaptation examples for pi0, pi0-FAST and pi0.5, with backend-specific features and robot-specific action conventions.
Software / Frameworks
Robot-learning-from-demonstration framework with HDF5 dataset tooling, offline learning algorithms and version-specific simulation datasets.
Software / Simulation
MuJoCo-based robot-learning environments with configurable robots, grippers, controllers and observations; the reviewed v1.5.2 setup requires matching rendering and action conventions.
Hardware / Wheeled & tracked robots
Python RC-car platform for manual driving and optional learned control; reviewed Raspberry Pi/PCA9685 build guidance has OS-version conflicts and an incomplete parts budget.
Hardware / Wheeled & tracked robots
Ackermann-steered racing research platform; the preserved Xavier NX/Slash guide differs from its newer Orin Nano Super/Fiesta parts list and requires configuration-specific calibration.
Hardware / Wheeled & tracked robots
Configurable ROS 2 mobile-robot stack; this profile selects a two-wheel differential-drive, ESP32 control route with separately versioned firmware and measured chassis parameters.
Hardware / Wheeled & tracked robots
RC-based research racecar; the reviewed Nano route uses V3 printed parts and separately versioned ROS control packages, with older firmware/image assumptions requiring validation.
Hardware / Wheeled & tracked robots
Six-wheel printed rover with separately preserved build files and ROS software; the reviewed default software uses ROS Melodic and requires per-robot calibration.
Hardware / Wheeled & tracked robots
Six-wheel rocker-bogie rover with off-the-shelf mechanical parts and separate ROS control software; reviewed hardware and software snapshots need version and calibration reconciliation.
Hardware / Wheeled & tracked robots
Smartphone-controlled wheeled robot platform; the reviewed DIY configuration combines an Arduino Nano and L298N driver, with phone and firmware requirements distinct from the advertised body cost.
Hardware / Wheeled & tracked robots
ROS 2 mobile research platform on an iRobot Create 3 base, with distinct Standard/Lite sensor packages and distribution-specific base-firmware requirements.
Hardware / Legged robots
Underactuated bar-swinging research robot with one QDD actuator, passive hooks and simulation/control sources; requires a ladder test rig, and the reviewed hardware script conflicts with its guide.
Hardware / Legged robots
Twelve-servo Raspberry Pi/Arduino quadruped with downloadable CAD and Python gait code; hardware is noncommercial source-available and manual calibration is required.
Hardware / Printed quadruped with three joints per leg.
Twelve-servo printed quadruped prototype with CAD, PCB files and ROS control sources; calibration, gait refinement and build instructions remain incomplete.
Hardware / Wheeled & tracked robots
Reaction-wheel unicycle research platform, scoped to v2.5 CAD and firmware with a documented state-estimation error and historical development tools.
Software / Simulation
C++ and Python toolbox for multibody dynamics, mathematical optimization and model-based robot control, with installation choices tied to platform and solver requirements.
Software / Simulation
Robot simulation library and application with physics, sensors and plugins; Jetty setup and ROS integration require matching package and distribution choices.
Software / Frameworks
Libraries and tools for robot applications, reviewed through a Humble release manifest and version-matched documentation for installation and node communication.
Software / Simulation
Robot simulation environment with a scene editor, sample worlds and controller APIs; reviewed at R2025a with release-specific graphics requirements and asset licensing.
Hardware / Legged robots
Original Mini Pupper quadruped with twelve custom servos, Raspberry Pi hardware and separate movement/ROS stacks; hardware generation, image and calibration route must be matched.
Hardware / Legged robots
Quadruped source collection with distinct A1 and A2 configurations, printable structural parts, C++ control and browser-based simulation; this review centers on the documented A1 operating configuration.
Hardware / Legged robots
Nybble/Bittle robot-family entry centered on OpenCat 1.2.5 NyBoard firmware, calibration and host tools; software openness does not establish complete frame or electronics manufacturing sources.
Hardware / Biped with five controlled joints per leg.
Ten-joint biped with purchased actuators, machined and welded metal parts, and a ROS 1 learning-to-control workflow; external hardware rights and build completeness need separate checks.
Hardware / Legged robots
Twelve-joint quadruped with purchased actuators and fabricated metal parts; its preserved ROS 1 control snapshot warns that the supplied policy is not very stable.
Hardware / Desktop biped with two three-axis legs.
Printed desktop biped with four custom torque actuators, two positioning servos and a shared Python simulation/hardware interface; controller-source licensing remains unresolved.
Hardware / Humanoids
Humanoid design and one-leg benchmark exploring low leg inertia through belts and parallel linkages; the maintainer has put the project on hold.
Hardware / Humanoids
Ten-degree-of-freedom research biped with machined aluminum parts, EtherCAT motor control and learned locomotion; artifact and dependency licenses need separate checks.
Hardware / Humanoids
Printable humanoid with FreeCAD sources, a Servo 2040 control route and MuJoCo examples; power selection and several servo mappings remain unresolved.
Hardware / Legged robots
Wheeled balancing robot with articulated servo legs, Arduino balance firmware and Raspberry Pi inverse-kinematics examples; electronics and controller integration remain incomplete.
Software / Simulation
Physics engine for articulated mechanisms and contact, with C/Python interfaces and a version-sensitive model and simulation workflow.
Software / Frameworks
ROS 2 navigation framework with configurable bringup, localization and behavior-tree navigation; robot and distribution matching are essential.
Software / Frameworks
ROS 2 framework for managing controllers and hardware interfaces, with mock components for checking integration before physical hardware trials.
Software / Middleware
Bridge that exposes position-controlled ros2_control arms as Intrinsic ICON hardware modules.
Software / Libraries
C++ shared-memory transport and real-time utilities used by the ICON control framework.
Software / Frameworks
Preview framework for managing model-serving lifecycles and exposing inference services to ROS 2.
Software / Tools
MoveIt planning services and client skills for Intrinsic Core, with a documented offline mock-hardware route.
Software / Middleware
ROS camera adapters with documented Orbbec, Luxonis, Zivid and experimental Ensenso integration routes.
Software / Libraries
C++ allocation monitor for detecting heap operations inside designated real-time sections.
Hardware / Legged robots
Wheeled biped with four leg servos, two driven wheels and a Raspberry Pi control stack; the reviewed build guide needs revision matching.
Software / Frameworks
Local robotics runtime, SDK and real-time control framework with a documented machine-tending simulation route.
Software / Tools
Configurable CNC machine-tending reference application using Intrinsic Core, behavior trees, perception and machine I/O.
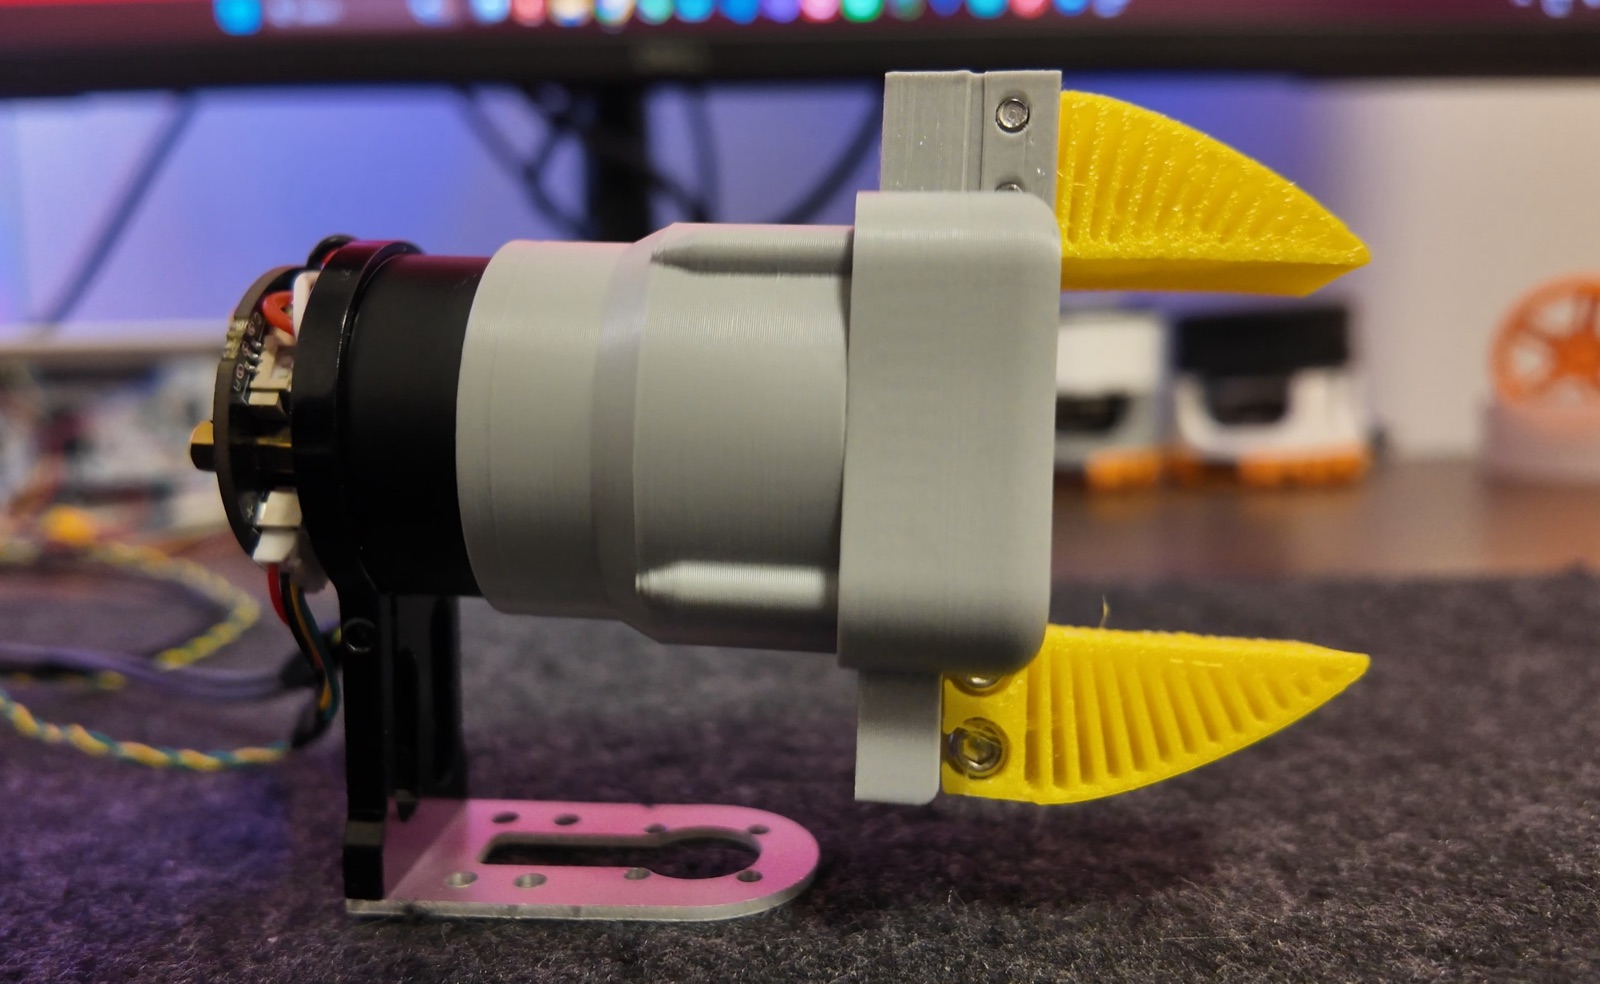
Hardware / Compact rack-driven parallel gripper
Compact rack-driven gripper with an assembly STEP and upstream build photo; exact actuator, BOM and control integration still need to be specified.
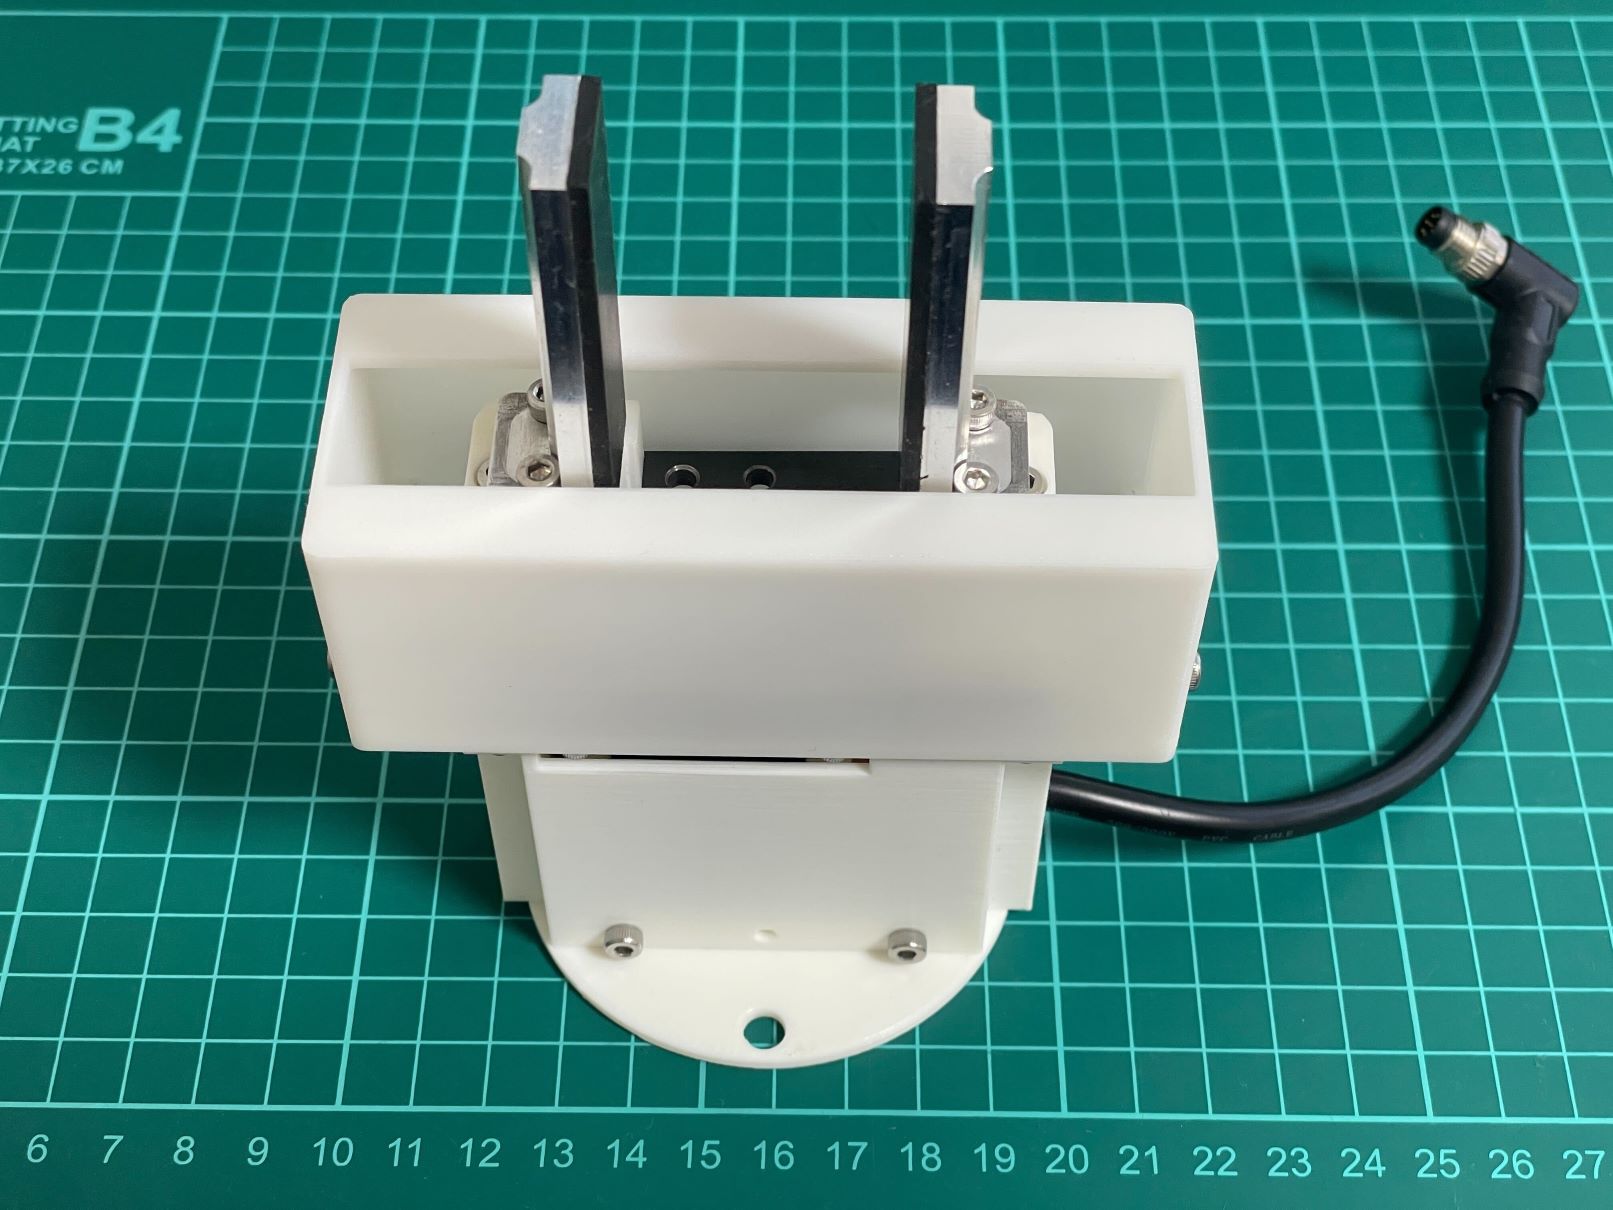
Hardware / Rack-driven parallel gripper for LITE 6
Parallel-jaw gripper for the LITE 6 using a Dynamixel XL330 servo, printed housings, machined claws and OpenRB control examples with a serial-rate mismatch to resolve.
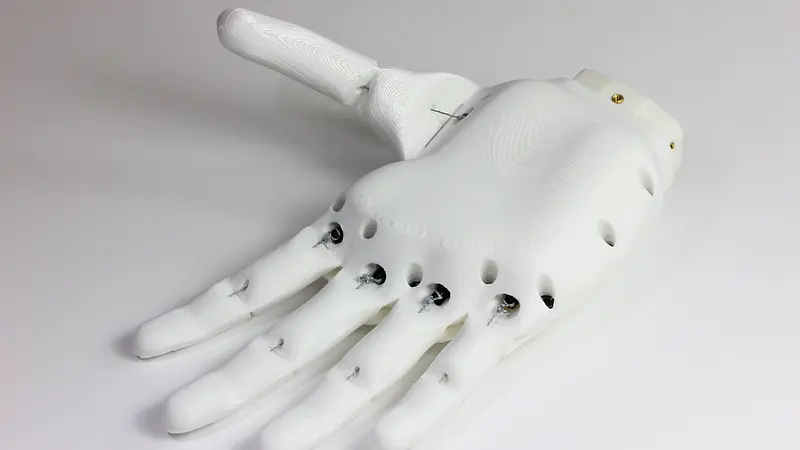
Hardware / Five-finger robotic development hand
Five-actuator robotic development hand with a flexible printed palm, rigid covers and separate Almond controller and Artichoke firmware sources.
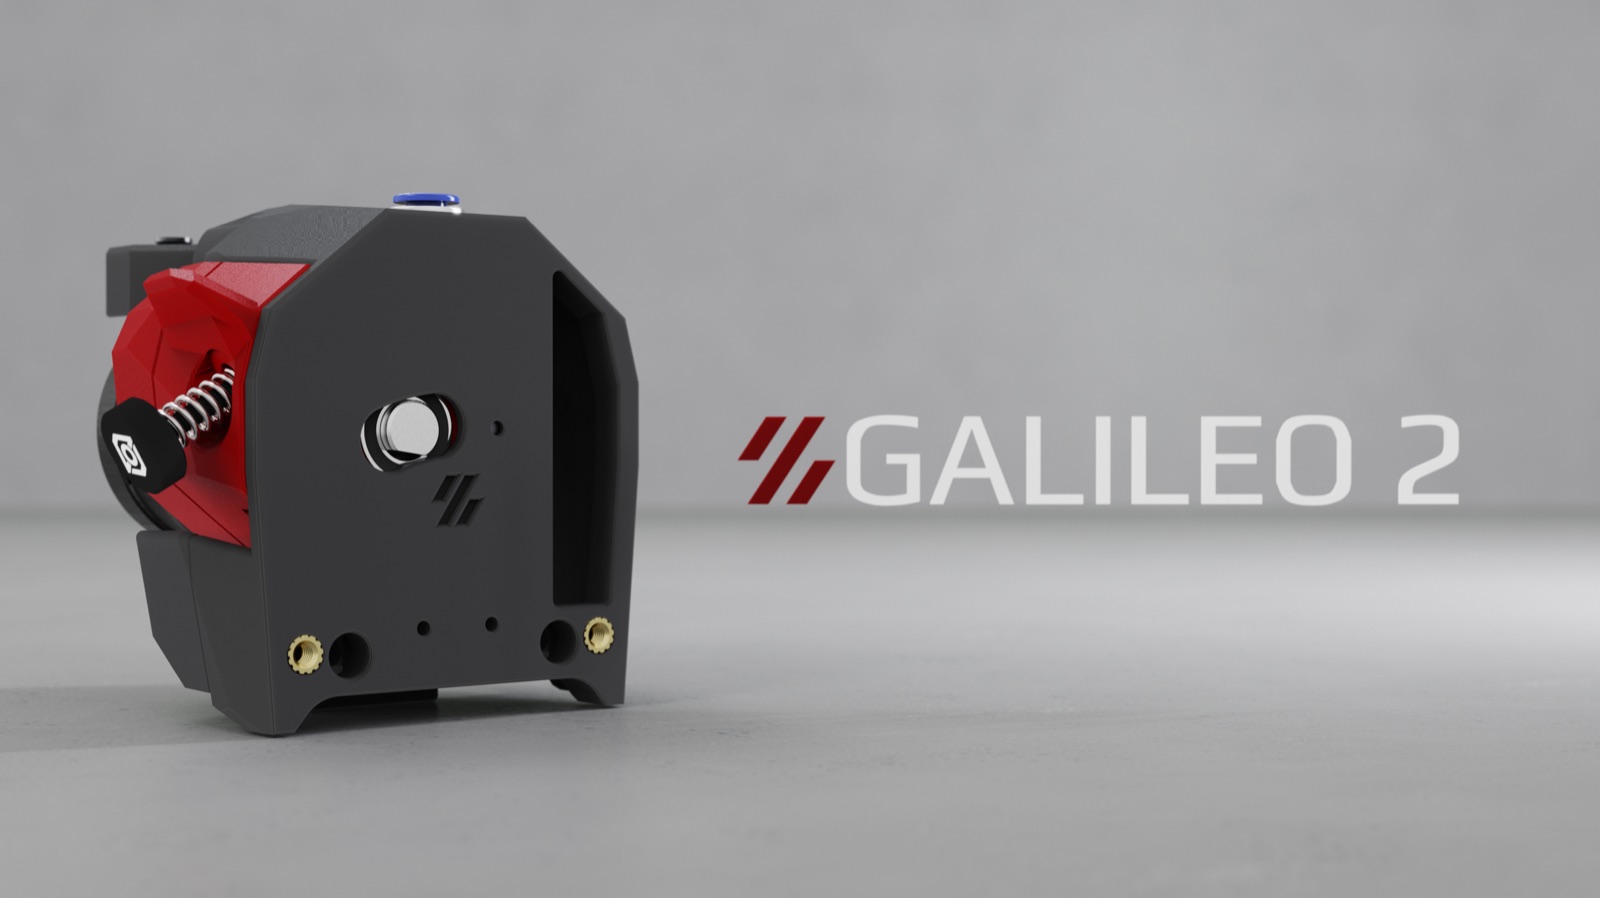
Hardware / Planetary-geared filament feeder
Planetary-geared filament feeder for a Stealthburner toolhead, with custom gearbox parts, selectable printed housings and a detailed assembly manual.
Hardware / Magnetic tool coupling
Experimental printer tool changer that rotates permanent-magnet rings to attach lightweight tools; requires custom docks and Klipper configuration.
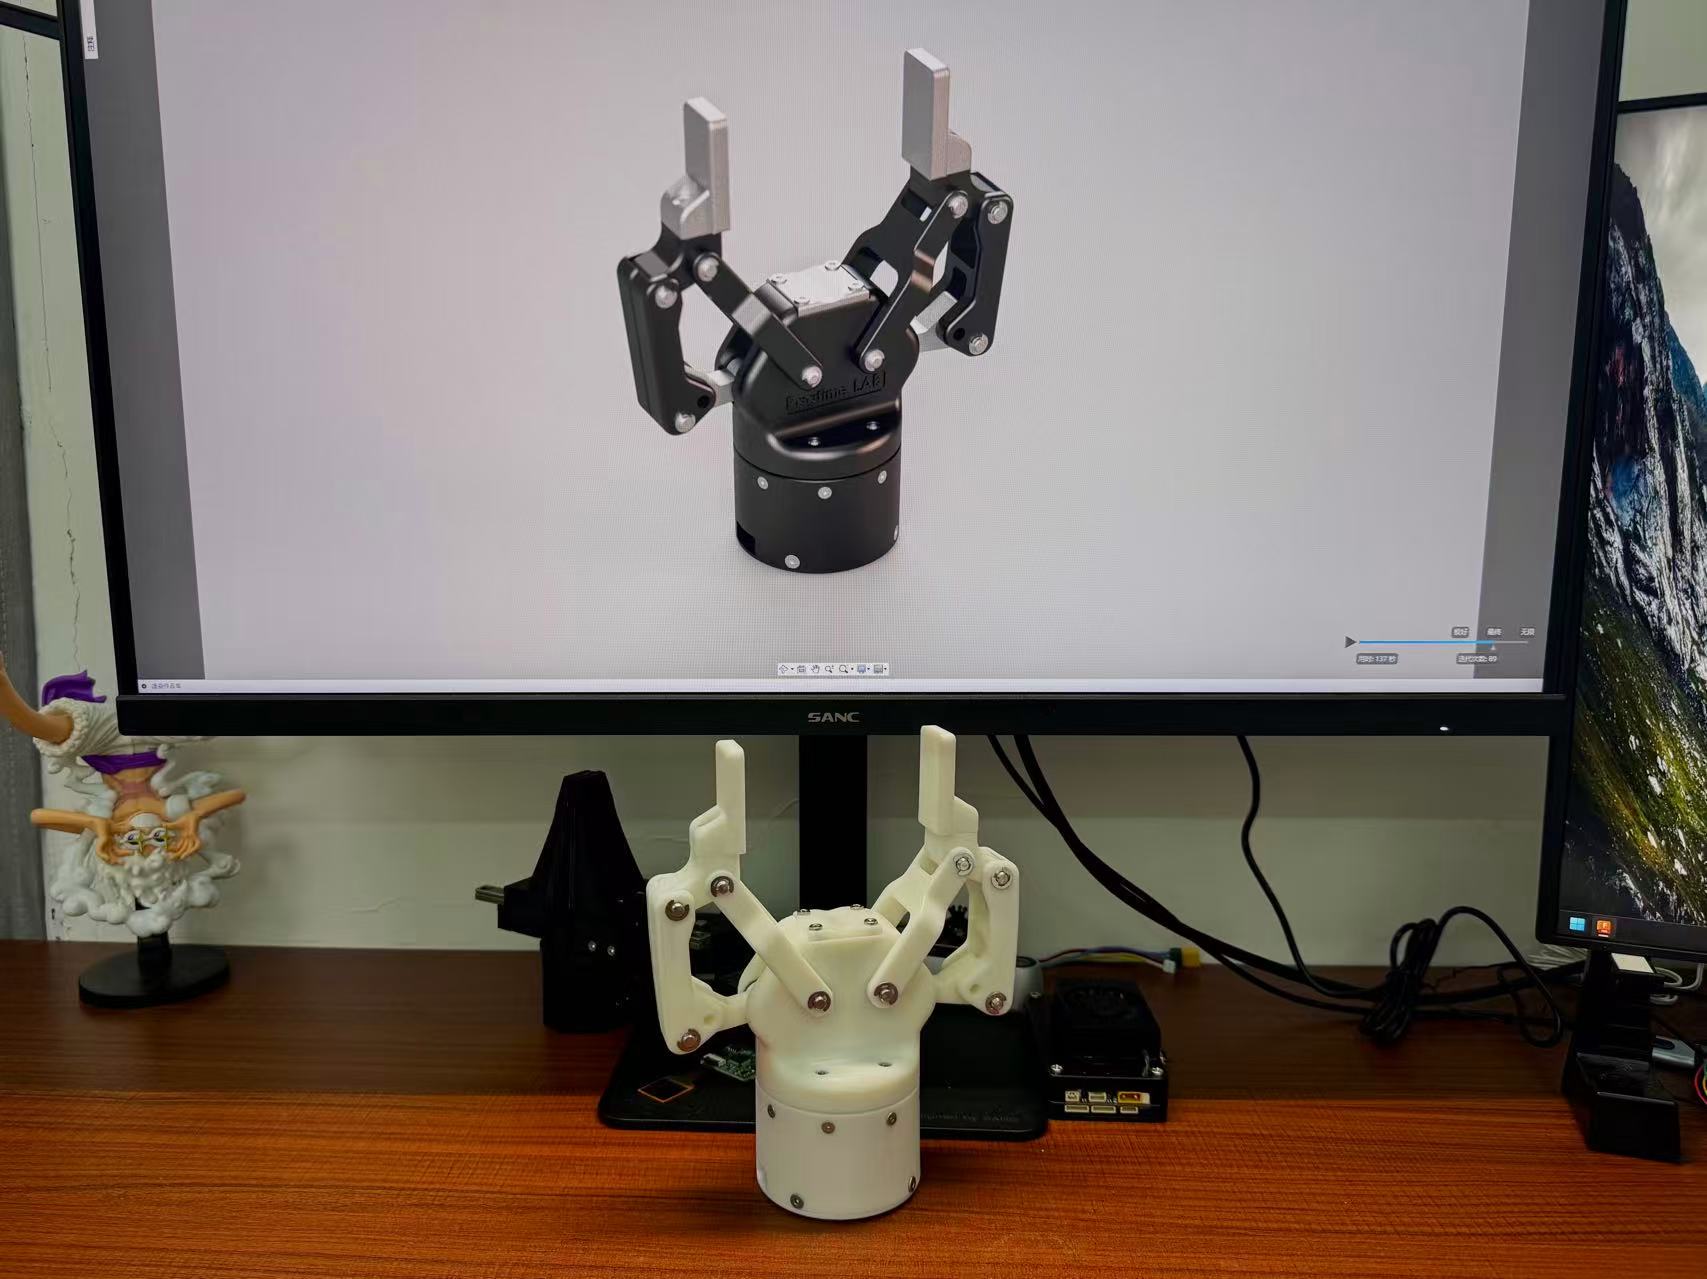
Hardware / Underactuated two-finger gripper
Underactuated two-finger gripper with DM4310 actuation, assembly CAD and a mixed fabrication BOM; control licensing is unresolved.
Hardware / Six-legged walking robot
A six-legged educational robot with printable chassis and legs, Dynamixel motors and Arduino control.
Hardware / Tool coupling and docking components
Tool-coupling hardware with dimensioned aluminum parts, a stepper-driven latch and V6/Hemera tool variants.
Hardware / Robot-mounted two-finger gripper
DYNAMIXEL-driven two-finger gripper with a camera, assembly CAD and robot-specific mounting parts.
Hardware / Parallel and adaptive grippers
XL430-W250-T drives a belt/rail gripper with constant-force springs; U2D2 and power hub are listed.
Hardware / Dexterous hands
A five-finger tendon-driven hand with seven actuators, sixteen joints and separate hardware/software licenses.
Hardware / Dexterous hands
Six-DoF anthropomorphic hand with linkage fingers, adaptive thumb and worm-and-rack transmissions.
Hardware / Paste and syringe extrusion
A modular syringe pump and extrusion design with printable parts and multiple syringe and mounting configurations.
Hardware / Dexterous hands
A printable four-finger hand with eight actuators and a Reachy 2 wrist interface.
Hardware / Pellet extrusion
Large-format pellet screw extrusion around a purchased RobotDigg 16 mm compression screw/barrel and NEMA23 flange.
Hardware / Dexterous hands
Printable CRAFT Hand parts and Bambu print profiles with left/right palm and thumb alternatives.
Hardware / Delta tooling
A family of fourth-axis jaw grippers, flexible jaws, single/double suction heads, pen tools and a filament-printing head.
Hardware / Delta tooling
Magnetic pick-and-place tool carried by the Delta-Robot One moving platform.
Hardware / Dexterous hands
A tendon-driven hand with wrist and forearm; v1 build modifications differ from the v2 early-access design.
Hardware / Pellet extrusion
Pellet extruder with multiple STEP revisions and NEMA17/NEMA23 variants, intended for MIM printing materials.
Hardware / Suction and sensing
A suction cup combining vision and tactile sensing with wireless electronics.
Hardware / Electric grippers
A printable replacement gripper for SO-101 that reuses the original gripper motor.
Hardware / Dexterous hands
Six linear actuators drive five fingers with coupled joints; NUCLEO-F303K8 control, Bluetooth and ROS support.
Hardware / Tool changing
Kinematic tool-changing ecosystem including extrusion and pen tools; liquid-handling use is reported.
Hardware / Dexterous hands
An anthropomorphic hand with Full and Lite motor options and separate CAD downloads.
Hardware / Paste and syringe extrusion
Compact syringe plunger driven by an NPM PFCL25-48Q4 linear stepper; printed parts optimized for ABS.
Hardware / Vacuum and small-part handling
A vacuum pick-and-place nozzle subsystem with inventoried FreeCAD holder and spring files and separate purchased-component references.
Hardware / Parallel and adaptive grippers
Two AX-12A servos drive parallel fingers through four-bar linkages; OpenRB-150 control and a palm RealSense D405.
Hardware / Electric grippers
A modular stepper-driven gripper with selectable rail and motor lengths.
Hardware / Dexterous hands
Tendon-driven hand family with base, touch, lite and joint-sensing variants; Feetech and Dynamixel motor-specific parts.
Hardware / Paste and syringe extrusion
Modified Replistruder 5 with NEMA17, 3:1 GT2 belt reduction, anti-backlash TR8×1.5 lead screw and 1 mL Hamilton syringe.
Hardware / Parallel and adaptive grippers
Printed parallel fingers with interchangeable tips and a Feetech STS3215; optional camera mount.
Hardware / Pellet extrusion
A pellet-printing design for an Ender-3 conversion, with inventoried screw, barrel and heat-block geometry.
Hardware / Parallel and adaptive grippers
Parallel gripper using the WHJ03 joint module, interface PCB and 24 V RS485/Modbus RTU control.
Hardware / Paste and syringe extrusion
Syringe extrusion design for FRESH hydrogel printing, distributed as STL and STP in a versioned Zenodo archive.
Hardware / Electric grippers
A parallel gripper for SO-ARM100/101 with selectable guide rods and modular printed parts.
Hardware / Dexterous hands
A learned-control humanoid hand with external fabrication instructions, CAD and controller data.
Hardware / Parallel and adaptive grippers
Tendon-driven sliding jaws on a 12 mm rail, MX28T servo, OpenCM9 and EXP485. Optional capacitor board supports power-loss repositioning.
Hardware / Soft grippers
A pneumatic soft gripper made with cast elastomer and printed molds.
Hardware / Electric grippers
A motor-driven adaptive gripper with a reported 48 mm stroke and CAN control.
Hardware / Filament extrusion
Filament toolhead platform with CAD and printable housings for a printer extrusion assembly.
Hardware / Adaptive grippers
A family of adaptive hands with shared CAD parts and a separate Dynamixel control repository.
Hardware / Dexterous hands
Yeah Hand/Rebelia lineage: humanlike hand with separate robot/prosthetic firmware and commercial servos.
Hardware / Two leader arms and two follower arms
A four-arm bimanual teleoperation and demonstration-recording system with a separate learning stack.
Hardware / Six-axis articulated arm
A six-axis workshop arm with printed or aluminum structure; this review covers MK3 and its matching 6.3-series controls.
Hardware / Biped humanoid
A 1.2 m humanoid design with separate media and motion computers, fabricated metal/nylon structure and an unfinished locomotion-policy release.
Hardware / Printed articulated arm
A printed educational robot arm with CAD, firmware, BOM and assembly documents in one source repository.
Hardware / Printed-gearbox humanoid
A humanoid built around printed gearboxes, with separate simulation assets and low-level control code that requires joint calibration after power cycles.
Hardware / Legged robots
A six-actuator research biped with passive ankles, tethered power/data and no active yaw control.
Hardware / Compact articulated arm
A compact custom arm combining CNC parts, harmonic reducers and custom motor-control electronics.
Hardware / Desktop articulated arm
A six-axis printed arm built around cycloidal gearboxes, with separate mechanical and control documentation.
Hardware / Humanoids
A humanoid development project with a separate arm-and-exoskeleton branch of work for LeRobot teleoperation.
Hardware / Humanoids
A research humanoid family whose hardware revisions, robot configuration and software distribution must be matched before reproduction.
Hardware / Humanoids
A humanoid soccer research platform with a released load-bearing plastic body design and a separately maintained ROS framework.
Hardware / Humanoids
A modular printable humanoid with body-section tutorials, tendon-driven hands and a separate MyRobotLab control route.
Hardware / Modular humanoid
A public-alpha humanoid project whose CAD, operating system, simulation and inference code live in separate sources.
Hardware / Desktop robot arm
A printable Dynamixel arm with a separate leader design for teleoperation and robot-learning experiments.
Hardware / Laser-cut articulated arm
A four-degree-of-freedom educational arm made from versioned laser-cut parts.
Hardware / Compact printed humanoid
A roughly 30 cm printed humanoid using 19 DYNAMIXEL servos, a Raspberry Pi Zero 2 W and a custom-fabricated robot HAT.
Hardware / Humanoid interaction platform
A humanoid interaction research platform with distinct FDM and SLS-oriented mechanical designs and a separate software repository.
Hardware / Humanoids
Two humanoid soccer research designs with separate CAD, actuator selections and fabrication requirements.
Hardware / Printed articulated arm
Printable Niryo One arm designs with a separate ROS stack and a documented older-hardware archive.
Hardware / Legged robots
A small printed biped with bus servos, a Raspberry Pi runtime and learned walking policies; the reviewed v2 build still has documentation and configuration gaps.
Hardware / Articulated arm platform
An arm research platform whose hardware release separates the arm, evaluation cell and KER assemblies.
Hardware / Four-joint arm with actuated gripper
A four-joint DYNAMIXEL arm with a separate gripper axis, documented for PC-based ROS control or standalone OpenCR operation.
Hardware / Printed desktop arm
A printed desktop arm with a separate Commander application and a required PAROL6 control board.
Hardware / Humanoids
A printable humanoid whose #5 basic design replaces the #4 part set and uses Raspberry Pi 5 compute.
Hardware / Six-axis articulated arm
A six-axis research arm using Dynamixel MX-28 motors and Python control.
Hardware / Six-axis educational arm
A six-axis educational arm using printable parts, Dynamixel XL-320 servos and Raspberry Pi control.
Hardware / Printed humanoid
A printed research humanoid using 25 Dynamixel actuators and a documented legacy Odroid setup.
Hardware / Humanoid platform
A Reachy 2 ROS 2 workspace providing robot descriptions, control interfaces and simulation launch components.
Hardware / Expressive desktop robot
An expressive desktop robot with separate Wireless, USB-connected Lite and simulation setup routes.
Hardware / Biped humanoid
A 20-joint research humanoid with a 2025 ROS 2 revision and an older ROS 1 software lineage that must be kept distinct.
Hardware / Legged robots
A modular torque-controlled quadruped family; this review distinguishes wired Solo12 from its battery-and-wireless upgrade.
Hardware / Legged robots
A historical eight-actuator quadruped using coaxial leg mechanisms, Teensy control and customized ODrive firmware.
Hardware / Original Pupper v1 servo-driven quadruped
The original servo-driven Stanford Pupper, a Raspberry Pi quadruped whose upstream support has ended in favor of a separate v3 design.
Hardware / Articulated six-axis arm
A printable six-degree-of-freedom teaching arm with editable FreeCAD, STEP and STL mechanical sources.
Hardware / Printed research humanoid
A humanoid research platform with distinct 2XC and 2XM motor configurations, separate PCB sourcing and noncommercial hardware terms.
Hardware / Six-axis articulated arm
A family of six-axis YAM arms supported by a Python and CAN control library with revision-specific models.
Software / Libraries
Tools for collecting robot demonstrations and training and deploying learned policies.
Software / Frameworks
A ROS 2 manipulation framework supporting motion planning and kinematics.
Hardware / Desktop manipulator
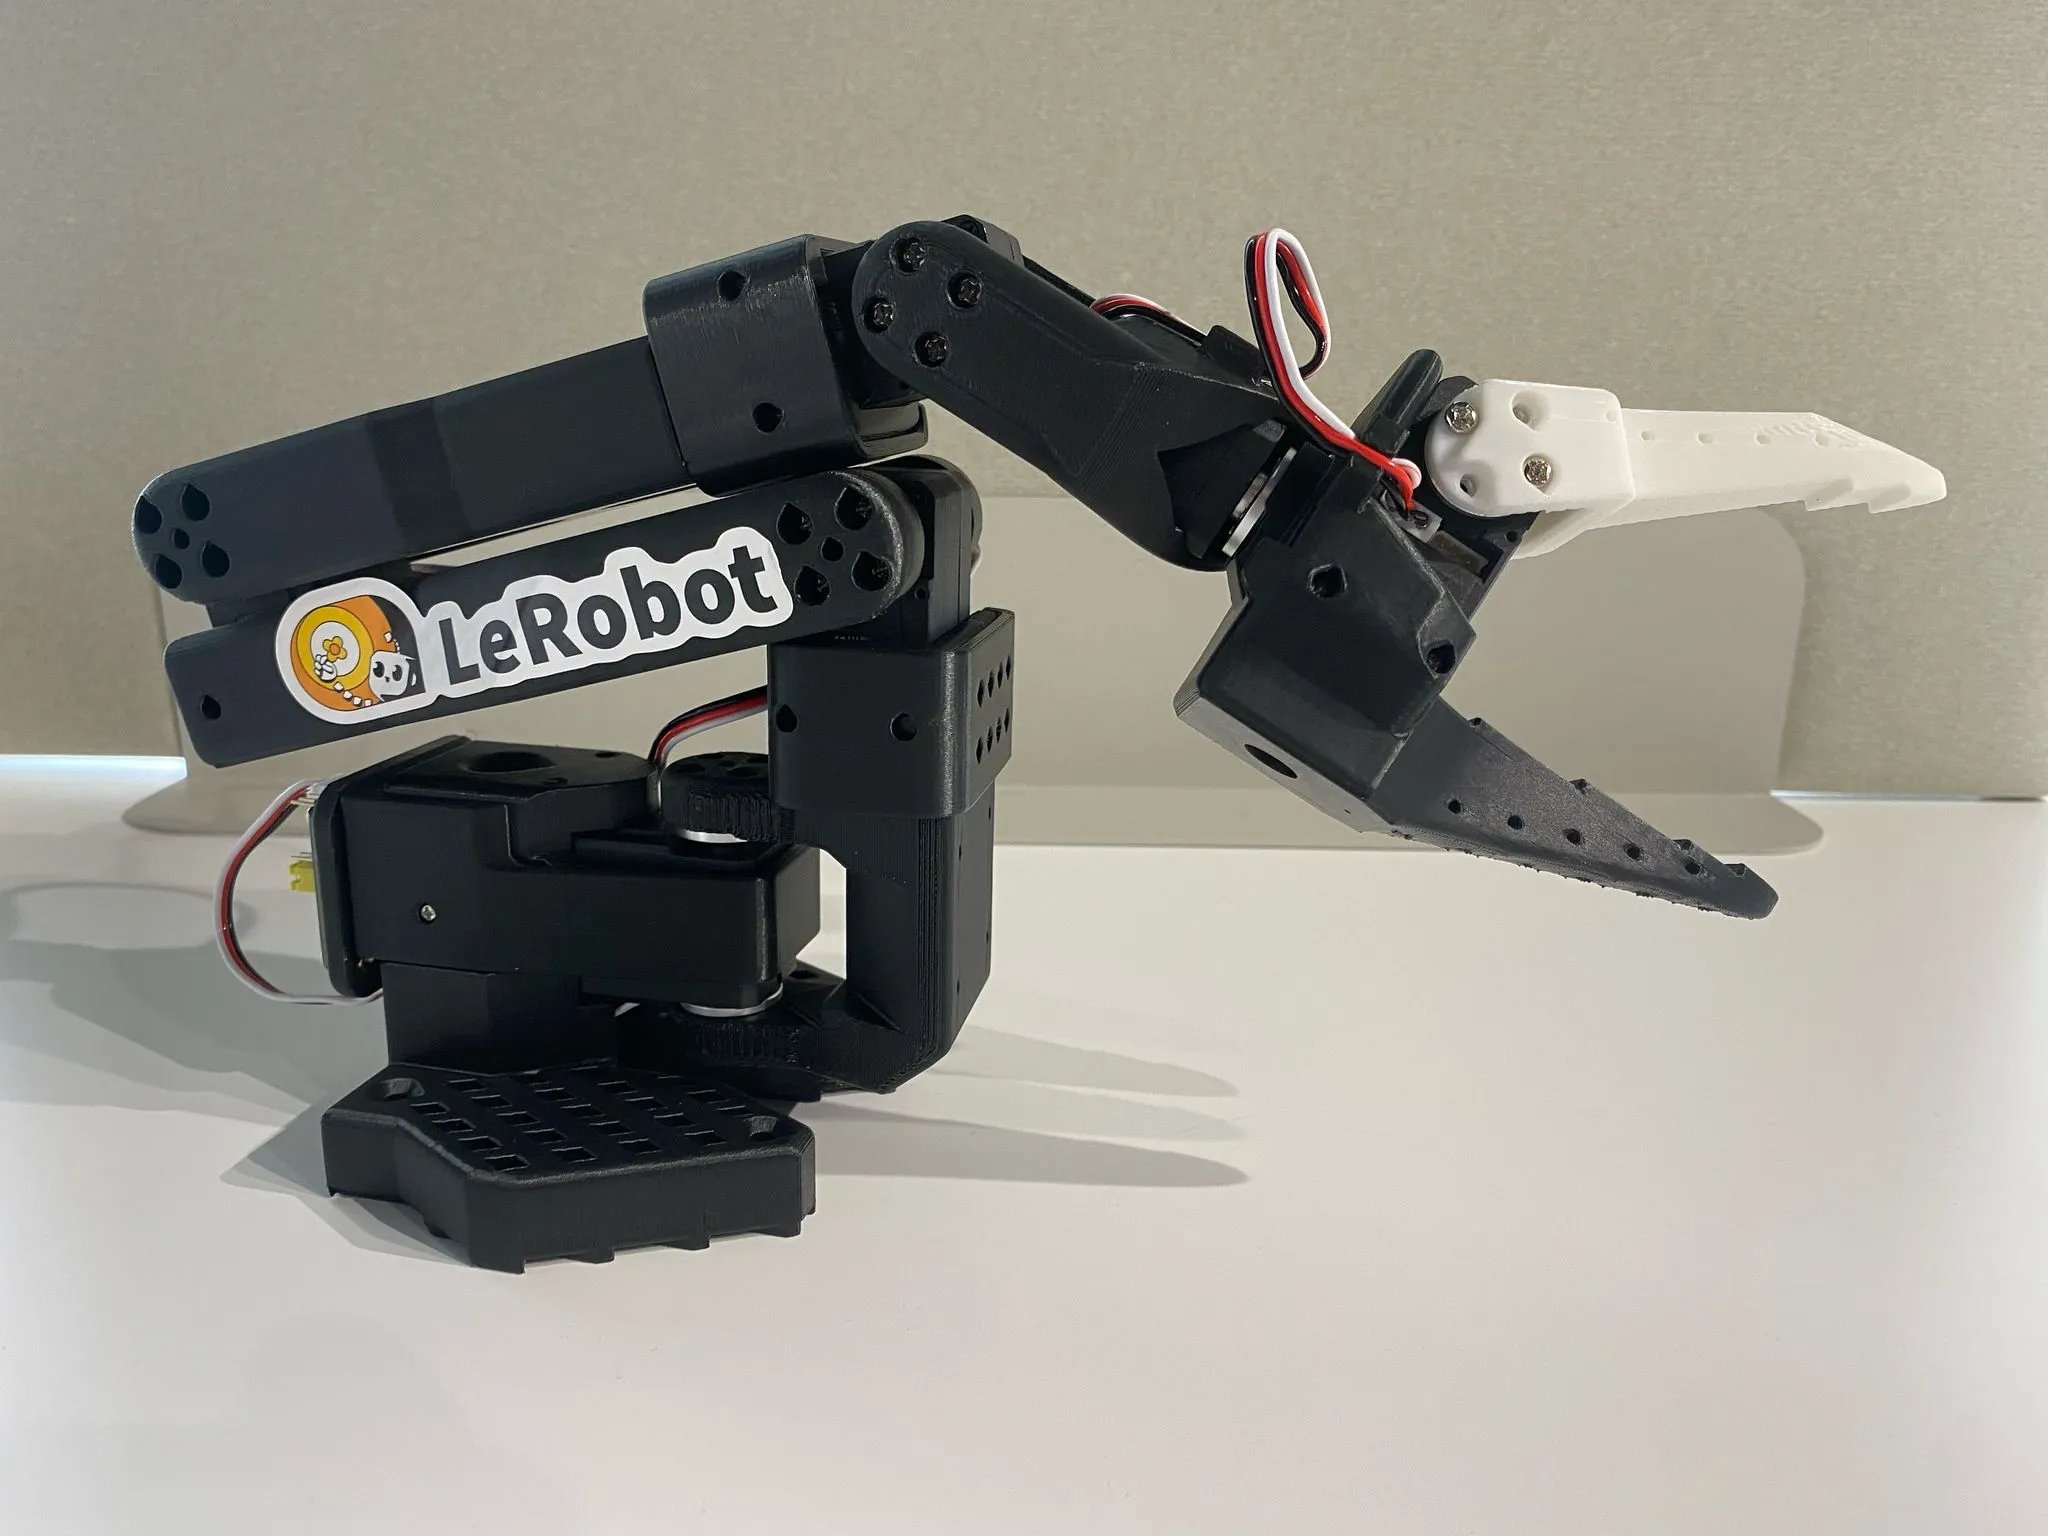
A printable robot arm for teleoperation and robot-learning experiments.
Hardware / Wheeled mobile platform
A mobile robot platform for learning and experimenting with navigation.
No matching entries. Try another term or clear the filters.
We know about these designs but do not profile them. Each note says why. Follow the links for the official project and its license.
Platform tags identify documented interfaces or applications; they do not establish tested fit or certification. Methodology · About the spec