Zowi
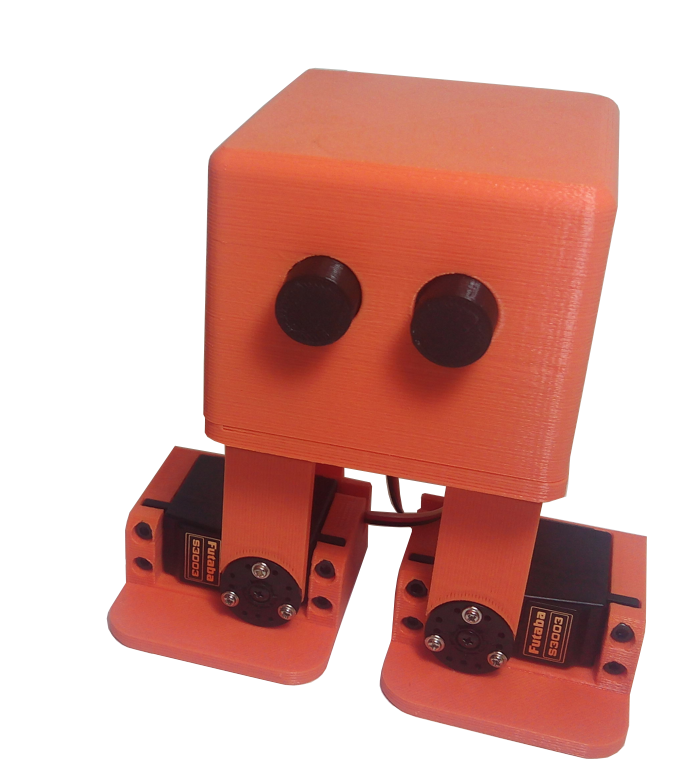
Robot / hardware buildHistorical four-servo educational biped with FreeCAD sources, printable parts and Arduino calibration/motion code; selected coverage is the original printable design. [1] [2]
Build & first use →Official websiteUpstream build guideBill of materials
- Cost
- No current cost yet. Upstream bill of materials [1]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0 · license not fully assessed for firmware · Details by part
Overview
The original printable Zowi is a small educational biped driven by four servos. BQ released FreeCAD design sources, individual printable meshes and Arduino motion code. This profile selects Zowi_3Dprintable; the injection-molded product and the JIM/Scopum remixes in the same repository have different parts and should be treated separately. [1] [2]
Is this for you?
- Known limitations
- No current complete-build quote or available kit verified; printing, board, servos, power, tools and delivery remain configuration-specific.
- The calibration sketch loads EEPROM despite a false-flag comment, and its active loop walks repeatedly despite a centering comment; review before uploading.
- The Oscillator dependency and third-party software rights/version matching need separate checks; no compilation or physical gait test performed.
Editorial assessment from cited sources; no reproduction or compatibility test.
Hardware & parts
Upstream bill of materials [1]
- Hardware configuration
Four-servo educational biped; selected printable original has no actuated arms
- Actuators
- Four Futaba 3003 servos or equivalents named by upstream
- Controller
BQ ZUM BT328 or Arduino as specified by the printable BOM
- Power
Printable BOM lists eight AAA cells and four dual-cell holders; wiring/voltage must be reconciled with the selected board and servos
Assembly & first use
Open the upstream getting-started guide [1]
- Use Zowi_3Dprintable parts and BOM; do not mix Zowi_mold or Scopum/JIM remix parts.
- Match the board, servo power and four servo signal pins; inspect the calibration sketch before writing EEPROM.
- Center the mechanism, adjust individual trims and attempt a short documented motion after checking the dependency versions.
Editorial assessment from cited sources; no reproduction or compatibility test.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Cost and licensing boundaries
No current complete price or available kit is established. Budget for the selected servos and board, printed parts, fasteners, power, programming computer, tools, shipping and tax. [1]
BQ declares CC-BY-SA-4.0 for the design. That declaration should not be extended automatically to separately linked Arduino and oscillator code. This is source-researched educational coverage; firmware compilation, calibration and physical walking remain untested. [4] [5]
3D preview
Preview not available yet. The original printable design provides FreeCAD and STL payloads. No source-positioned preview has been prepared; this is separate from the molded product and remixes.
Model sources
The original printable design provides FreeCAD and STL payloads. No source-positioned preview has been prepared; this is separate from the molded product and remixes.
Project notes
Start with the four-servo BOM
Upstream lists four Futaba 3003 servos or equivalents, a BQ ZUM BT328 or Arduino, specified M3 fasteners, four two-cell AAA holders and eight AAA cells. That list identifies components, but does not establish that every alternative Arduino board and servo can use the same power wiring. Resolve the selected board's supply and servo requirements before energizing the mechanism. The original printable design has no actuated arms. [1] [2]
The FreeCAD source and STL files are real payloads: the FreeCAD container and a sample binary mesh were inspected. No CAD fit, printing tolerance or mechanical strength test was performed. [1]
Read the calibration code as well as its comments
The calibration sketch maps the four servo signals to pins 2, 3, 4 and 5. The motion library can load individual trim values from EEPROM. The supplied sketch calls init(..., true), while a nearby comment explains the behavior for false; check the actual flag and stored state before calibration. Upstream also warns to save trims once and remove the EEPROM-writing line on later runs. [2] [3]
The code README links the Oscillator library to ArduSnake. Match that dependency and the selected Arduino toolchain before compiling; the repository's older examples are source material, not a verified current installation recipe. In Zowi_3Dprintable/code/zum/calibration/calibration.ino, the active loop calls zowi.walk(4,1800) repeatedly, despite a comment describing servo centering. Review and adapt that loop before uploading if the intended first exercise is stationary centering. Only then attempt a short movement. [2] [3] [4]
What we checked
Source research only. No firmware compilation, dependency installation, CAD fit or strength validation, assembly, calibration, runtime or physical performance test performed. No affiliate links or supplier endorsement. Upstream design/media files are linked, not redistributed.
Not yet established
- Requirements: operating system, host computer, tools
Updates
- Upstream last updated
- Jan 8, 2016 [6]
- Latest release
- Not established
- Profile updated
- Oct 28, 2026
- Sources last checked
- Oct 28, 2026
- Next review
- Nov 28, 2026
- Reviewed revision
- c8981003695be8a97ea401da0e51d454429000fb (commit snapshot; separately linked artifacts have their own revisions) · combined hardware and software repository
Source files and licenses
Include this distinct physical design for Study a simple four-servo biped and follow its documented trim-and-motion workflow. The inspected artifacts support a bounded source-researched next step; they do not establish reproduced hardware or commercial support.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 FreeCAD ZIP container and binary STL payload inspected. Printable original is separate from mold version and remixes. [1] [5] |
| electronics | not found · License not fully assessed BOM specifies bought-in BQ ZUM BT328 or Arduino; custom board design completeness/rights not established in this review. [1] |
| firmware | available · License not fully assessed Source available. Root CC-BY-SA declaration exists, but linked and bundled oscillator/Arduino dependencies need component-specific terms; no blanket software license inferred. [2] [3] [5] |
| documentation | available · CC-BY-SA-4.0 [1] [5] |
No distinct robot host application selected; Arduino development tools remain external dependencies.
No learned policy or dataset is selected for the documented first task.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Printable Zowi design and BOM
Four Futaba 3003-class servos, Arduino/ZUM board, fasteners and eight AAA cells; CC-BY-SA-4.0 design.Revision, date & where cited
github.com · revision
c898100· Zowi_3Dprintable/README.md at · Accessed Oct 28, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S002 Actual four-servo motion implementation
Servo attachment, stored trim values and oscillator-based motions.Revision, date & where cited
github.com · revision
c898100· Zowi_3Dprintable/code/zum/libraries/Zowi/Zowi.cpp at · Accessed Oct 28, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Start with the four-servo BOM and 2 more - S003 Calibration sketch and EEPROM cautions
Pins 2–5, trim adjustment and write-once EEPROM guidance; comment and init flag disagree.Revision, date & where cited
github.com · revision
c898100· Zowi_3Dprintable/code/zum/calibration/calibration.ino at · Accessed Oct 28, 2026
Used for: Is this for you?, Assembly & first use, Read the calibration code as well as its comments, Source files and licenses - S004 Oscillator dependency
ArduSnake Oscillator dependency linked separately.Revision, date & where cited
github.com · revision
c898100· Zowi_3Dprintable/code/README.md at · Accessed Oct 28, 2026
Used for: Is this for you?, Assembly & first use, Cost, Read the calibration code as well as its comments - S005 Repository design license declaration
CC-BY-SA-4.0 declaration for repository products.Revision, date & where cited
github.com · revision
c898100· README.md at · Accessed Oct 28, 2026
Used for: Cost, Source files and licenses - S006 Selected repository revision metadata
Revision, date & where cited
github.com · revision
c898100· acquisition manifest · Accessed Oct 28, 2026
Used for: What we checked - S007 Original printable Zowi physical photograph and reuse declaration
Shows the original four-servo printable BQ Zowi. The root README declares CC BY-SA 4.0 for repository products, and the printable design README repeats that license. This source is the physical-photo asset embedded in that design documentation.Revision, date & where cited
Obijuan / bq contributors · github.com · revision
c898100· Zowi_3Dprintable/images/zowi-image-1.png and root README.md in the pinned snapshot; exact archive and source hash are preserved locally. · Accessed Oct 28, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-28 — Added an attributed crop of the original printable four-servo Zowi photograph under CC BY-SA 4.0; profile facts and cost evidence unchanged.