Rhino V2 adaptive gripper
End effectorUnderactuated two-finger gripper with DM4310 actuation, assembly CAD and a mixed fabrication BOM; control licensing is unresolved. [1] [3] [4]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Builders able to fabricate and integrate a custom gripper. [1]
- Cost
- No current cost yet. Upstream bill of materials [2]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- GPL-3.0 · license not fully assessed for software · Details by part
Overview
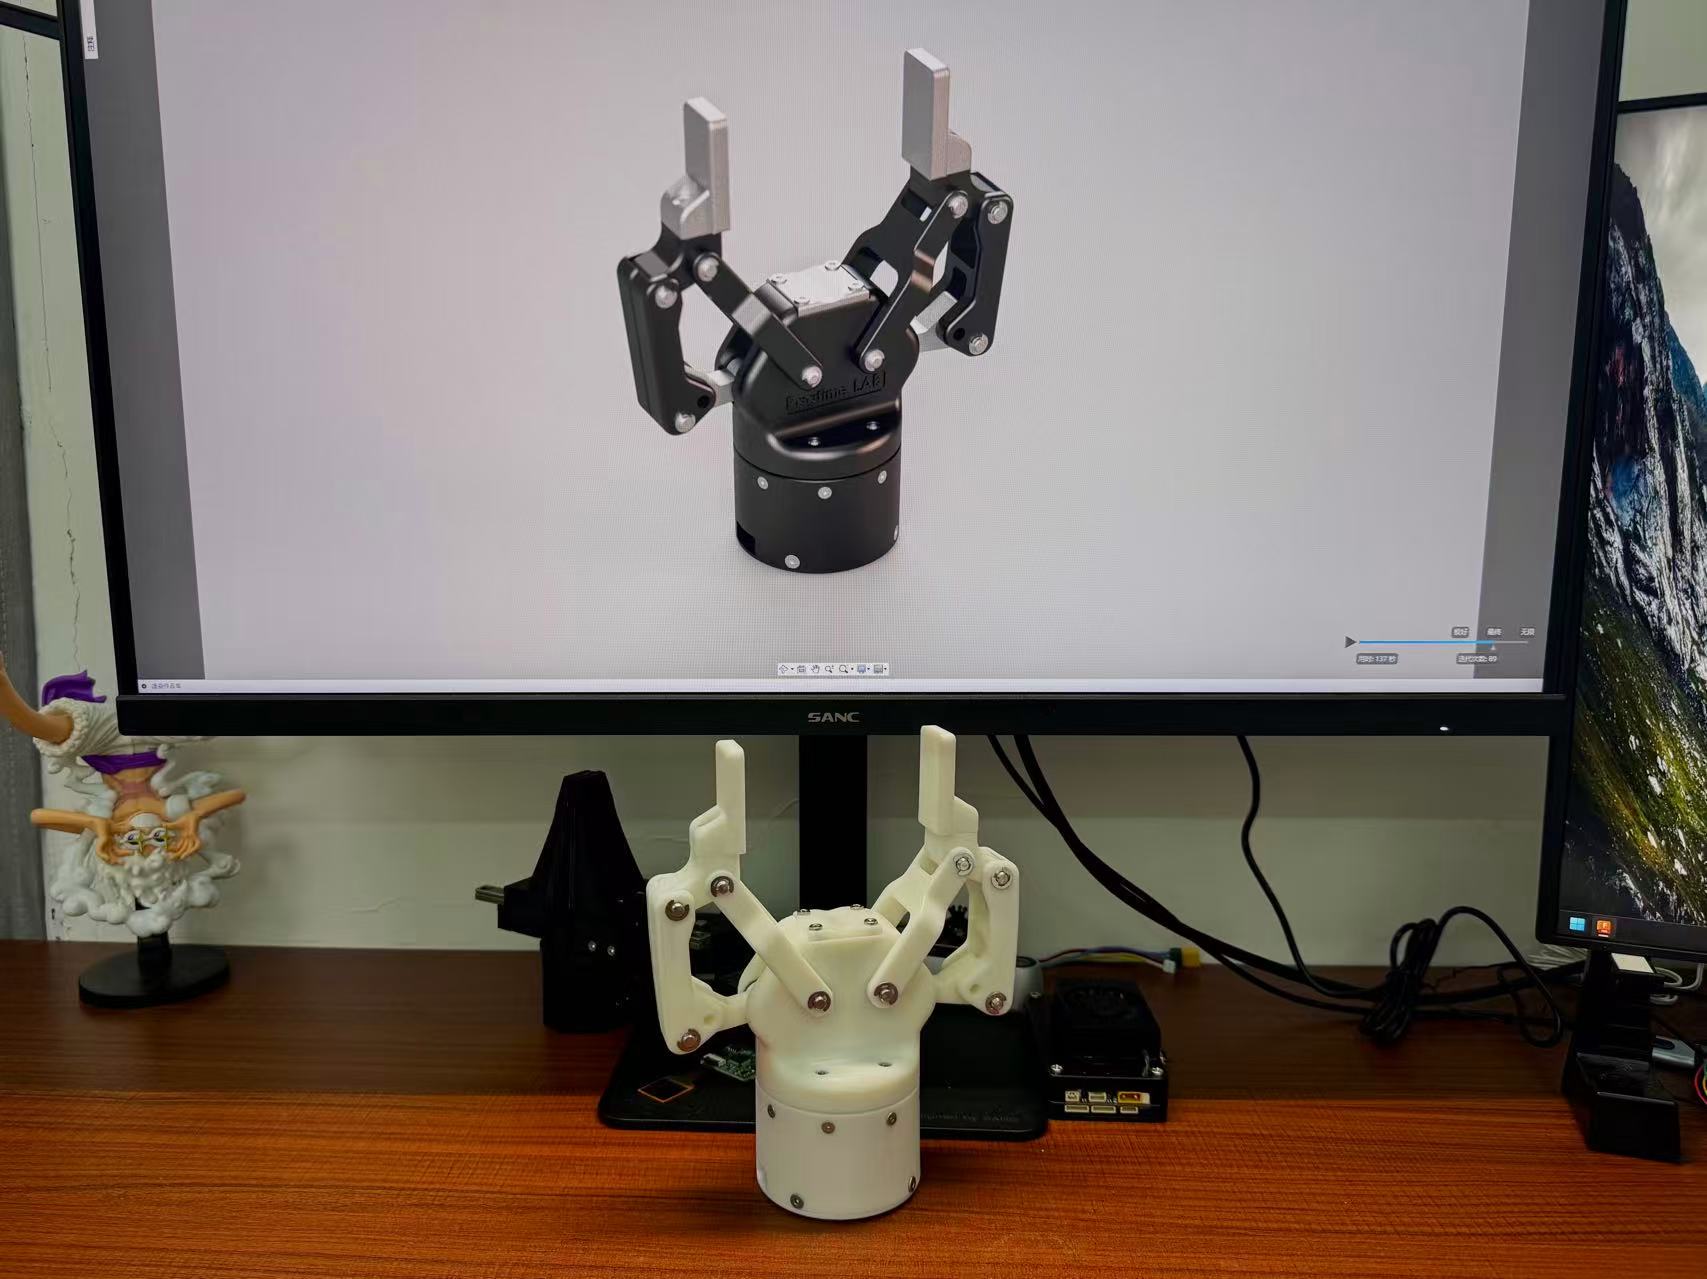
Rhino V2 is a two-finger adaptive gripper for builders who can combine printed parts with machining and sheet-metal work. Its repository provides SolidWorks 2025 files, an assembly STEP and a mechanical BOM around a DAMIAO DM4310 motor. The preview shows the upstream assembly geometry, including purchased-component representations. It does not establish their manufacturing source or a finished working build. [1] [2]
Is this for you?
- Known limitations
- Detailed assembly tutorial and some fastener quantities are incomplete.
- Stroke, force and mass are not specified; robot mounting is not verified.
- Root GPL and control-directory learning/research-only notice conflict.
Editorial classification; no physical qualification.
3D preview
Rhino V2 gripper assembly. Assembly geometry; purchased components are represented, not separately source-qualified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Ragtime-LAB, revision 099a3cde0b35ee1f2a6a49e97a60686d2dcaaa3f. Original and preview: GPL-3.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Upstream bill of materials [2]
- Hardware configuration
Underactuated two-finger gripper
- Actuators
- DAMIAO DM4310 motor
- Controller
Linux Python control programs with DM-FDCAN USB-CAN; licensing conflict unresolved.
- Sensors
- Reference 6×6 UART pressure array; integration and calibration not verified.
- Power
24 V DC motor supply required by control README.
Assembly & first use
Open the upstream getting-started guide [1]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Plan fabrication before ordering the motor
The BOM names a CNC rotor-to-leadscrew transmission part, a custom leadscrew and nut, and four nut-linkage pieces. Its note recommends 304 stainless sheet for the latter because strength may otherwise be insufficient. The bottom cover permits PETG printing or CNC fabrication and discourages resin printing because of heat-set insert retention. The list also specifies MF85ZZ and MF128ZZ flanged bearings, grooved pins and torsion springs. Several screw entries lack quantities, and the detailed assembly tutorial is still marked as forthcoming. Reconcile fastener counts and fits against the CAD before placing a complete order. [1] [2]
The README leaves gripping stroke, maximum gripping force and mass unfilled. It describes inspiration from Robotiq 2F-85, which does not establish interchangeable mounts, performance or control interfaces. A cobot or delta adaptation would need its own mounting and integration evidence. No configuration-specific current build total is verified. [1]
The control package needs a separate decision
The documented control route uses Linux, Python 3.8 or later, a DM-FDCAN USB-CAN adapter and 24 V motor power. It also describes a reference 6×6 pressure-sensor array over UART for force feedback. The README places the power adapter in an optional list while requiring 24 V at the motor; provide a suitable motor supply even if a particular adapter is unnecessary. Adapter serial number, CAN IDs and sensor port are configuration values to replace, not settings to copy from the example. [3]
The control directory includes Python programs and precompiled USB-CAN libraries. Their complete build source was not established in this review. More importantly, its license section says the project is for learning and research only, while the root README and GPL-3.0 license state broader reuse terms. This profile therefore covers the mechanical design under the root grant and leaves the control package's reuse scope unresolved. Clarify that conflict before relying on the bundled software for redistribution or commercial integration. [1] [3] [4]
No physical assembly, powered control or gripping test was performed for this profile. [4]
What we checked
Source research only; no hardware build, procurement, calibration or performance testing.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Sep 30, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
099a3cd
Source files and licenses
Licensed mechanical design with purchased components and unresolved integration requirements. Control-subdirectory license notice conflicts with root GPL; no blanket software reuse grant is asserted.
| Layer | Availability / license |
|---|---|
| mechanical design | available · GPL-3.0 Mechanical files and root documentation under repository GPL. Purchased parts are not separately source-qualified. [1] [4] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this layer was not established in the inspected repository; this is not a claim that external components are closed. [1] [3] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this layer was not established in the inspected repository; this is not a claim that external components are closed. [1] [3] |
| software | available · License not fully assessed Python control files are available, but the control README limits use to learning/research despite root GPL terms. Precompiled USB-CAN libraries also leave source completeness unresolved. [1] [3] [4] |
| documentation | available · GPL-3.0 Root mechanical documentation carries GPL terms; the control README contains a conflicting learning/research-only notice, so its reuse scope remains unresolved. [1] [3] [4] |
No learned policy or dataset selected for this mechanical configuration.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Gripper overview
Revision, date & where cited
github.com · revision
099a3cd· README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S002 Mechanical BOM
Revision, date & where cited
github.com · revision
099a3cd· 2_BOM/BOM.xlsx at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S003 Control documentation
Revision, date & where cited
github.com · revision
099a3cd· 3_RhinoV2.0_Gripper_control/README.md at · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, The control package needs a separate decision and 1 more - S004 Root license
Revision, date & where cited
github.com · revision
099a3cd· LICENSE at · Accessed Sep 30, 2026
Used for: The control package needs a separate decision, Source files and licenses
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Replaced duplicate CAD still with an attributed upstream image; image scope and reuse evidence reviewed.