YUBI gripper
Based on published sources · Not tested by us ·
Overview
DYNAMIXEL-driven two-finger gripper with a camera, assembly CAD and robot-specific mounting parts. [S001]
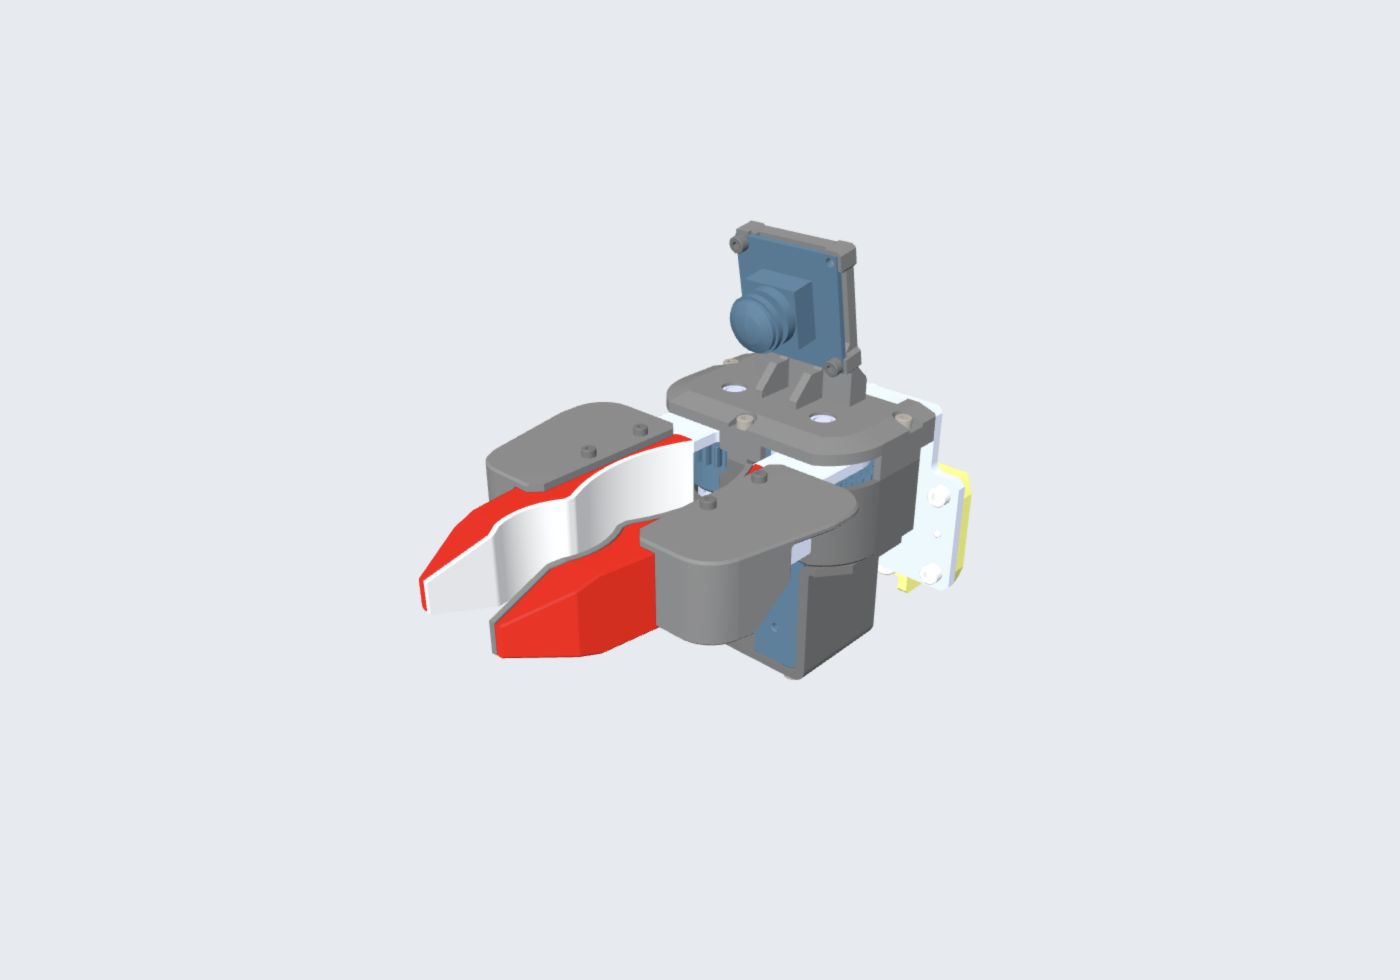
YUBI separates the robot-mounted gripper from its operator glove and data-collection rigs. This profile covers the DYNAMIXEL gripper: the hardware repository supplies an assembly STEP, individual parts, a parts list and an assembly guide. The preview shows the upstream assembly geometry, including representations of purchased components; it is not proof that those components have open manufacturing designs. [S001] [S002]
Specifications
| Detail | Description |
|---|---|
| Type | Robot-mounted two-finger gripper Reported by source [S001] · Checked 2026-09-30 |
| Intended users | Robotics researchers evaluating the gripper and its mounting options. Editorial assessment [S001] · Checked 2026-09-30 |
| Assembly | Version-2 illustrated guide covers servo, gear train, fingers, camera and UR5e attachment. Reported by source [S003] · Checked 2026-09-30 |
| Calibration | Not known |
| Operating system | Not known |
| Computer needed | Not known |
3D preview
YUBI gripper assembly. Assembly geometry from the upstream STEP; purchased components are represented, not separately source-qualified. Confirm scale and manufacturing settings before printing.
Loading preview…
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Keyboard users can use the buttons above.
Download original STEP · Open model viewer and file provenance
Source: Toyota Motor Corporation, revision dd8bd13d2fd8e5003057243576f88be333d95fc5. Original and preview: CERN-OHL-W-2.0. Preview conversion by Open Source Robotics; original file unchanged. STEP preview triangulated in millimetres. No physical part tested.
Assembly and use
Printed parts are only part of the build
The version-2 gripper BOM specifies one XM430-W350-R servo, an ELP-USBFHD01M-L180 camera, two spur gears, three bearings, shafts, inserts, fasteners and rubber contact sheets. The case and several other parts are PLA; the gear shaft is machined A2024 aluminum, while the two finger attachments allow machined or printed alternatives. The UR5e mounting bracket and flange are also listed as machined A2024 parts. Obtain machining and purchased-component quotes before treating the CAD download as a printable complete gripper. No current complete price is established. [S002]
The assembly guide proceeds through inserts and locating pins, servo wheel and shaft, finger pads, gear train, upper plate, flaps, camera and UR5e mounting. One ordering discrepancy needs resolution: the guide names SB-304540 inserts for the upper plate, while the BOM groups four SB-304550 inserts. Confirm the intended insert against the hole geometry before ordering. [S002] [S003]
Choose the mount and control path separately
The current README lists Franka, OpenArm and Unitree G1 flanges; the preserved gripper BOM and assembly guide describe a UR5e configuration. Those are distinct mounting paths, not interchangeable instructions. The cobot tag records documented interface evidence, not a tested fit or a safety certification. [S001] [S002] [S003]
The linked software repository describes operator-side bringup: encoder and camera inputs, Docker/Compose, ROS 2 and separate data-collection services. Its quick setup remains marked under construction. That README does not establish a matched robot-side XM430 control and power setup for this mechanical assembly; resolve the actuator interface, supply and travel calibration before a powered build. [S006]
Toyota releases the hardware under CERN-OHL-W-2.0. Its commercial-use guide permits manufacturing and sale subject to that license and explains source and notice obligations. The original STEP, triangulated preview and shaded image retain attribution and the same hardware license. The image is a CAD render, not a build photograph. No hardware assembly or performance test was performed for this profile. [S004] [S005]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Source files and licenses
Licensed mechanical source is available; purchased components and complete robot integration are not fully open or verified.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-W-2.0 Repository hardware license; purchased components retain their own rights. [S001] [S004] |
| electronics | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. [S001] [S002] |
| firmware | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. [S001] [S002] |
| software | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. The linked operator-side software README is inspected separately (S006); it does not establish matched actuator control. [S001] [S002] [S006] |
| documentation | available · CERN-OHL-W-2.0 Repository hardware license; purchased components retain their own rights. [S001] [S004] |
Mechanical tooling profile without a selected learned controller or dataset.
References
Links identify the documentation and revisions used in this profile. Access dates record when each source was retrieved.
- S001 · Toyota Motor Corporation
Hardware overview
Accessed 2026-09-30 · README.md at dd8bd13d2fd8e5003057243576f88be333d95fc5Source notes
Scoped source claims; no hardware testing.
- S002 · Toyota Motor Corporation
Version-2 gripper BOM
Accessed 2026-09-30 · docs/BOM/YUBI Gripper_DYNAMIXEL_BOM.md at dd8bd13d2fd8e5003057243576f88be333d95fc5Source notes
Scoped source claims; no hardware testing.
- S003 · Toyota Motor Corporation
Gripper assembly guide
Accessed 2026-09-30 · docs/AssemblyInstruction/YUBI Gripper_DYNAMIXEL_AssemblyGuide.pdf at dd8bd13d2fd8e5003057243576f88be333d95fc5Source notes
Scoped source claims; no hardware testing.
- S004 · Toyota Motor Corporation
Hardware license
Accessed 2026-09-30 · LICENSE at dd8bd13d2fd8e5003057243576f88be333d95fc5Source notes
Scoped source claims; no hardware testing.
- S005 · Toyota Motor Corporation
Commercial use guidance
Accessed 2026-09-30 · COMMERCIAL.md at dd8bd13d2fd8e5003057243576f88be333d95fc5Source notes
Scoped source claims; no hardware testing.
- S006 · AIRoA contributors
YUBI operator-side software README
Accessed 2026-09-30 · README.md at 1eccb041efc4d8966b03e4ccf4b402aa79d78be4Source notes
Operator-side stack, not a verified actuator bringup.
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1