OpenROV
Robot / hardware buildHistorical DIY underwater exploration platform; this entry selects the OpenROV 2.8 mechanical files and the corresponding named controller-board package for source research. [1]
Build & first use →Official website
- For
- Researchers and experienced builders able to reconcile historical component and software revisions [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Includes noncommercial terms. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- CC-BY-NC-SA-4.0 (noncommercial) · license not fully assessed for electronics · Details by part
Overview
The preserved OpenROV hardware repository spans several DIY underwater vehicle versions. This entry selects its 2.8 mechanical directory and separately preserves the linked electronics repository, which contains a controller package explicitly named 2.8. That naming gives a useful starting point for matching sources, but does not establish a complete reproduced vehicle. [1] [5] [6] [7]
Is this for you?
- Known limitations
- Mechanical repository uses CC-BY-NC-SA-4.0; electronics rights not established by the mechanical grant
- Upstream warns DXF drawings may need adjustment for a particular laser cutter
- Complete matched vehicle BOM and firmware/application versions remain unresolved
- No fabrication, waterproofing or underwater test performed
3D preview
OpenROV 2.8 mechanical structure assembly. The project-published OpenROV 2.8 Full Assembly STEP export: laser-cut shell, fin, main structure, electronics chassis, electronics tube, end caps and both battery tubes at their source assembly placements. Motors, propellers, electronics, tether and seals are not in this file. Licensed CC BY-NC-SA 4.0 (noncommercial, share-alike); no commercial-use or manufacturing clearance is claimed. Fit, sealing and fabrication accuracy are not verified, and the README warns its DXF files may need adjustment for laser cutting.
Noncommercial license: the upstream README licenses this work under Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International. This preview and the hosted original remain under that license with attribution to OpenROV; no commercial-use or manufacturing clearance is claimed. License: CC BY-NC-SA 4.0 · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP (gzip) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: OpenROV, revision 1268e948fb9c60c38a0b1f7c6450b466558e7342. Original and preview: CC-BY-NC-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Host computer
BeagleBone Black identified by the electronics README for the selected controller family.
Hardware & parts
Assembly & first use
- Assembly
Selected archive contains Inventor, STEP and DXF files for battery tubes, electronics enclosure, main structure, shell and topside adapter.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
The mechanical files have a defined version and fabrication limit
The selected directory includes Inventor parts and assemblies, STEP exports and DXF drawings for battery tubes, the electronics enclosure, main structure, shell and topside adapter. The drawings encode different material thicknesses, including 3 mm and 6 mm parts. Those paths establish available design artifacts, not measured tolerances or a tested pressure enclosure. [5]
The upstream README explicitly warns that it does not guarantee DXF accuracy for direct laser cutting and that different machines can require adjustments. A builder still needs to inspect scale, material, kerf and fit for the chosen process. This review did not open every drawing in CAD, fabricate parts or test seals. [1] [5]
Match the controller family to the vehicle version
The electronics README distinguishes the controller family for OpenROV 2.6, 2.7 and 2.8 from the older 2.5B controller and the BeagleBone Cape for 2.3/2.4. It identifies an ATmega2560 and BeagleBone Black fit for the selected family, while the older cape uses an ATmega328. A shared OpenROV name is insufficient to choose firmware or wiring. [6]
The preserved 2.8 controller package includes schematic and board source files, Gerber outputs, layout PDFs and a board BOM spreadsheet. A controller-board BOM is not the full vehicle shopping list: batteries, motors, sealing parts, tether, topside equipment and the chosen mechanical parts still need configuration-specific reconciliation. No current complete delivered cost was verified. [5] [7]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Mar 13, 2019 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 1268e948fb9c60c38a0b1f7c6450b466558e7342 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-NC-SA-4.0 Explicit noncommercial share-alike grant in mechanical repository. Drawings are not fabrication or depth qualification. [1] [5] [8] |
| electronics | available · License not fully assessed Board and schematic source, Gerber files, layout PDFs and board BOM preserved. Electronics-specific rights and complete vehicle matching not established; mechanical license not copied across repositories. [6] [7] |
| firmware | not found · License not fully assessed Complete matched vehicle application and controller firmware were not established in the two preserved hardware repositories. This does not assert that no separate public source exists. [1] [5] [6] [7] |
| software | not found · License not fully assessed Complete matched vehicle application and controller firmware were not established in the two preserved hardware repositories. This does not assert that no separate public source exists. [1] [5] [6] [7] |
| documentation | available · CC-BY-NC-SA-4.0 Mechanical repository overview and drawing set; complete matched assembly/operation manual not established in this review. [1] |
Selected conventional remotely operated hardware design does not establish a learned policy or dataset requirement.
Source availability and reuse rights are separate checks
The mechanical repository explicitly applies CC BY-NC-SA 4.0. Its noncommercial condition matters when assessing reuse; it is not an unrestricted commercial hardware license. The separate electronics README does not establish that same grant, so this profile leaves electronics licensing unresolved rather than carrying the mechanical license across repositories. [1] [6] [8]
Neither hardware archive establishes a complete matched vehicle application, controller firmware and installation environment in this review. The entry preserves a historical design starting point, with software matching, current sourcing, assembly documentation and underwater qualification still separate. No board manufacture, installation, leak test or dive was performed. [1] [5] [6] [7]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 OpenROV/openrov-hardware: README.md
Revision, date & where cited
github.com · revision
1268e94· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S002 OpenROV/openrov-hardware: commit 1268e94
- S004 OpenROV/openrov-hardware: files
Revision, date & where cited
github.com · revision
1268e94· archive file inventory · Accessed Oct 1, 2026 - S005 Selected OpenROV 2.8 mechanical file inventory
Revision, date & where cited
github.com · revision
1268e94· archive file inventory · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S006 Electronics version mapping
Revision, date & where cited
github.com · revision
080242a· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S007 Selected controller 2.8 package inventory
Revision, date & where cited
github.com · revision
080242a· archive file inventory · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Match the controller family to the vehicle version, Source files and licenses - S008 Noncommercial hardware license legal text
Revision, date & where cited
OpenROV / project contributors · creativecommons.org · CC BY-NC-SA 4.0 text corresponding to explicit mechanical README grant · Accessed Oct 1, 2026
Used for: Is this for you?, Source files and licenses - S009 Upstream image and reuse attribution
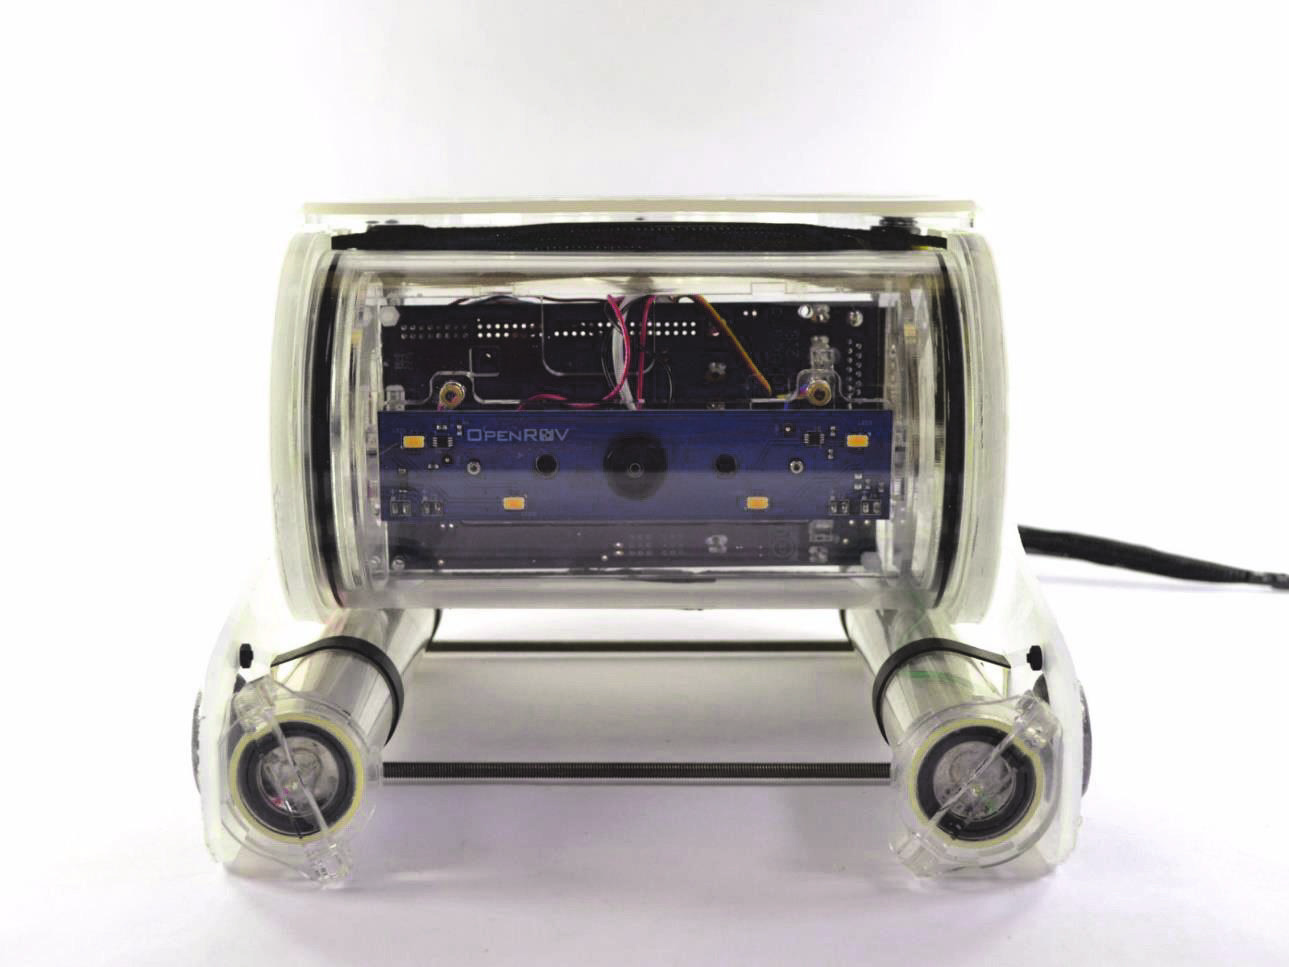
Media-only review: Paper photograph of the OpenROV 2.8 from the front, showing its camera, electronics tube and two battery tubes. Reuse basis: CC-BY-4.0. Section 2.1 and Figure 4 explicitly identify OpenROV 2.8, matching the selected historical 2.8 hardware record. The original figure is an annotated front-view photograph, with no separate third-party restriction or attribution. Actual PDF page 1 gives the author copyright and reuse grant, with two link annotations to CC BY 4.0; version is verified rather than inferred from publisher defaults. Publisher download was blocked; original research PDF retrieved from Semantic Scholar mirror, whose file URL is disclosed. The embedded photograph is extracted without the figure’s separate vector labels; no experiment results or current software claims adopted. Embedded image extracted from page 4 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
M-Mahdi Naddaf-Sh, Harley Myler and Hassan Zargarzadeh · doi.org · Design and Implementation of an Assistive Real-Time Red Lionfish Detection System for AUV/ROVs, 2018, page 4 Figure 4; section 2.1; copyright/license links page 1; image SHA-256 b7fe563539937b00fc1e7ecca341d859158420221fb8e3882d004e76aae19846 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.