PincOpen
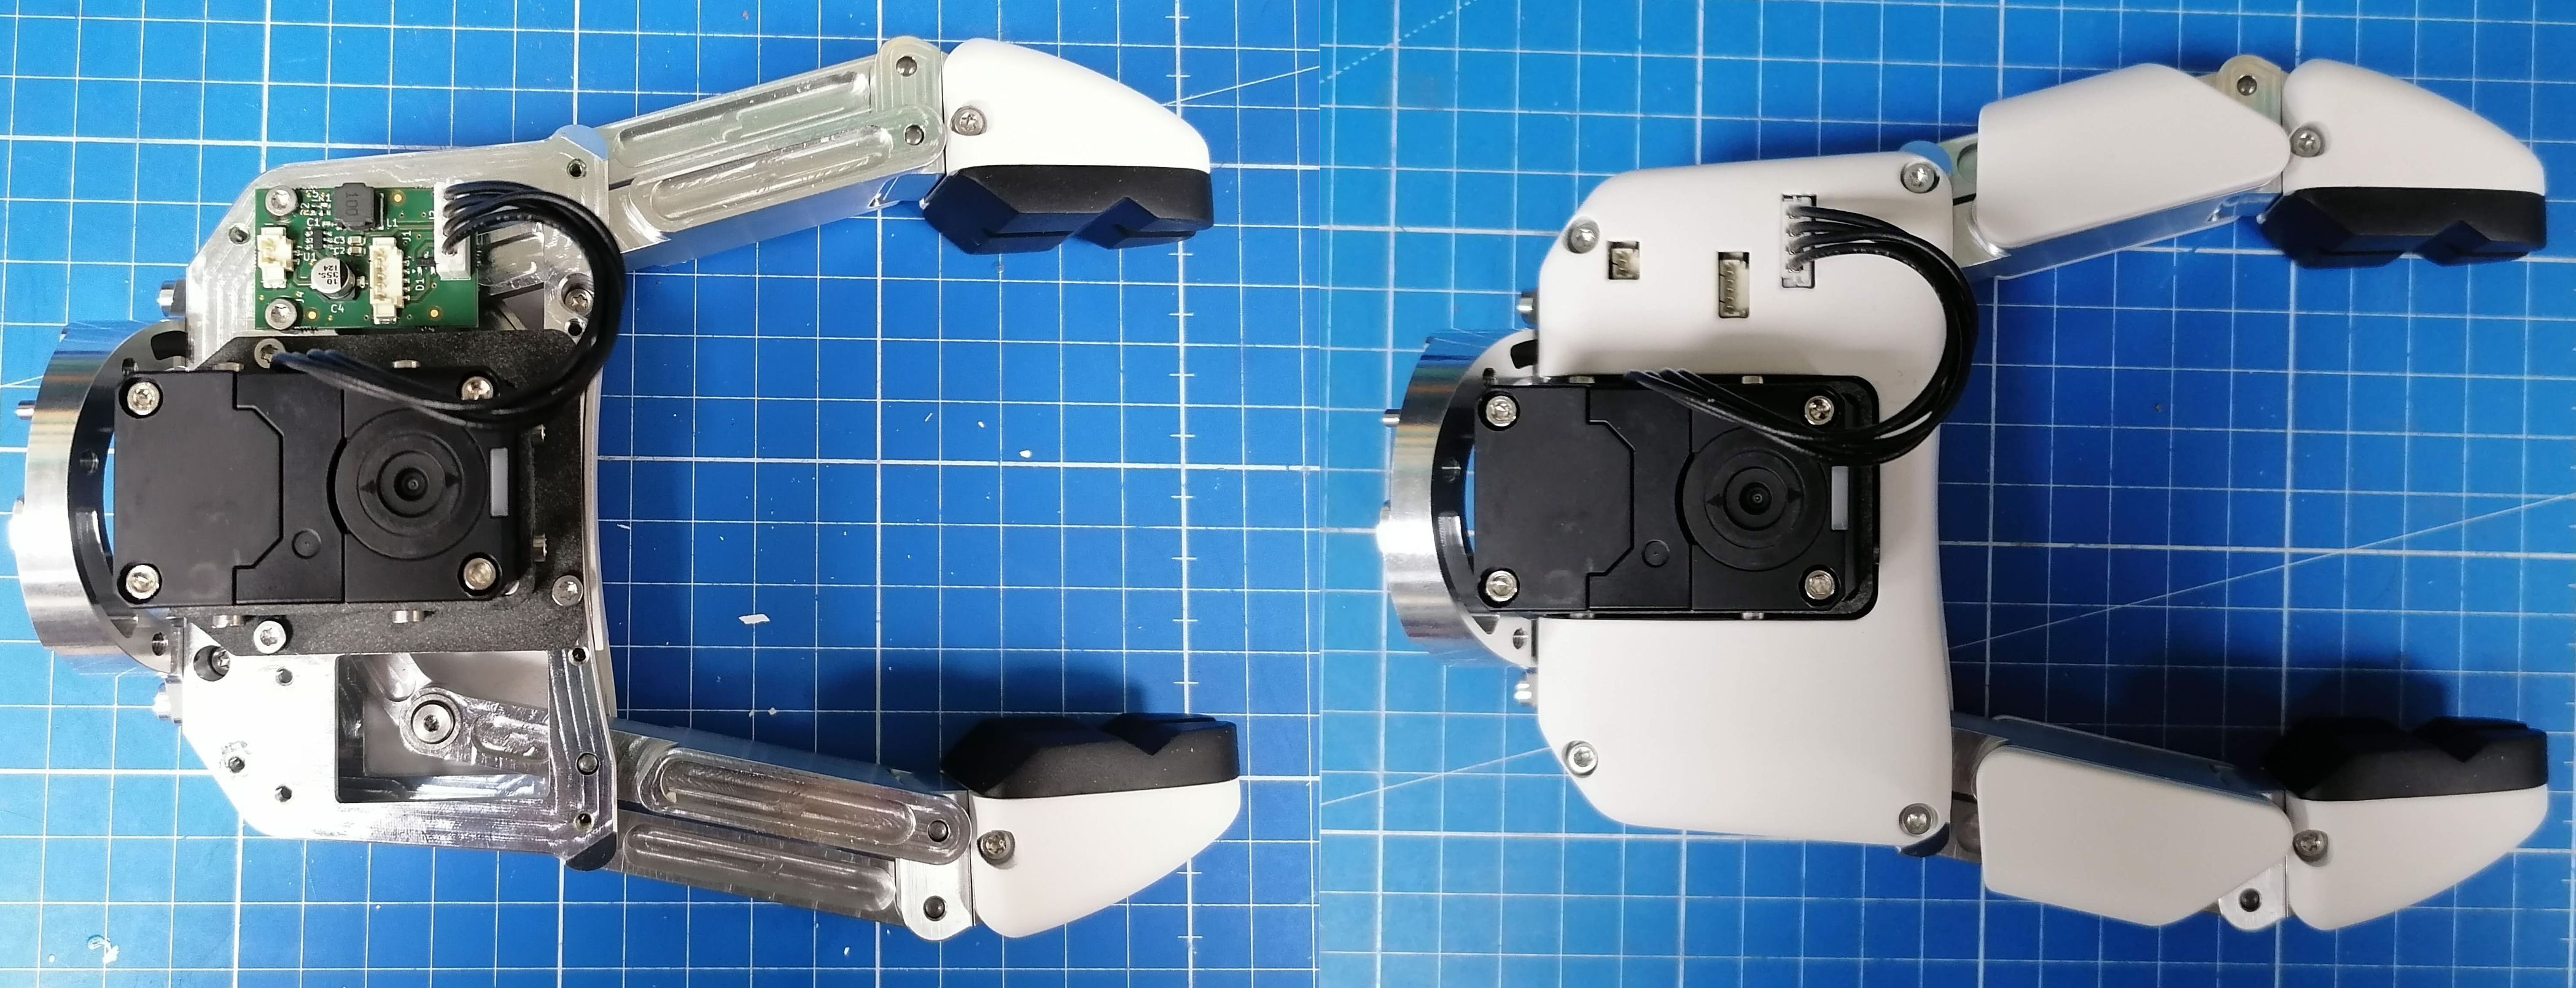
End effectorPrinted parallel fingers with interchangeable tips and a Feetech STS3215; optional camera mount. [1] [2] [3]
Build & first use →Official website
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0 · license not fully assessed for documentation · Details by part
Is this for you?
- Known limitations
- Match standalone versus SO-ARM100 configuration; retrieve linked external BOM and match the motor-control library. The approximately EUR 25 headline is not a complete current setup quote.
- No hardware build or test performed.
Source-researched; no physical verification.
3D preview
PincOpen gripper Onshape assembly (STEP export, default configuration). The complete PincOpen gripper assembly from the official Pollen Robotics Onshape document linked in the README (assembly PincOpen, default configuration), exported anonymously as STEP on October 4, 2026 from the Main workspace at microversion b36b9c4 (last changed June 16, 2026, the date of repository commit 1b5a3dc), with the source mate placements and two tip sub-assemblies: palm plates and shells, the motor flange, both finger linkages (driving, internal, external and distal rods), two tips (tip support, distal shell and removable tip), the cam linkage and the servo, with screws, pins, bushings and brass inserts: 59 bodies. The default configuration suppresses the optional RealSense camera mount and the SO-ARM100 interface, so they are not shown. The servo model (named STS32155 in the source; the README specifies a Feetech STS3215) and the fasteners, pins and inserts are purchased components kept as placed; their third-party terms are unknown. Licensed CC BY-SA 4.0 with attribution to Pollen Robotics; the Onshape licence note also asks users to consult Pollen Robotics. No manufacturing clearance is claimed. Fit and function are not verified.
Share-alike license with an added note: the PincOpen repository LICENSE is the Creative Commons Attribution-ShareAlike 4.0 International license, and the README says the work is licensed under it. The licence note inside the Onshape document (licence_CC_BY_SA.pdf) repeats CC BY-SA 4.0 and adds: “Failure to comply with this license or to consult with Pollen Robotics before using our work will result in legal action.” It does not say what consultation is expected. Open Source Robotics shows this model with attribution to Pollen Robotics, and the preview is shared under the same CC BY-SA 4.0 license. The Feetech servo model (named STS32155 in the source) and the screws, pins, bushings and brass inserts are kept as placed; their third-party terms are unknown. No manufacturing or other clearance is claimed beyond CC BY-SA 4.0. License: CC BY-SA 4.0 (PincOpen LICENSE; Onshape licence note quoted) · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP export of the Onshape assembly (gzip) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Pollen Robotics, revision Onshape microversion b36b9c407b4ac182e3e57caf (repository 1b5a3dc). Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Project documentation [1] [2] [3]
- Assembly
Match standalone versus SO-ARM100 configuration; retrieve linked external BOM and match the motor-control library. The approximately EUR 25 headline is not a complete current setup quote.
Known prerequisites and unresolved assembly decisions; not a complete build instruction.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Mounting and application
SO-ARM100 interface is documented; derived from Reachy 2 geometry. No cobot or delta mount verified. [1] [2] [3]
Before sourcing the build
Choose standalone, SO-ARM100 interface or camera-mount configuration, then follow the README’s external BOM link. The README names LeRobot for configuring the motor before assembly, and pypot’s support-feetech-sts3215 branch for flashing and testing. Match compatible library revisions before following these instructions. The approximately EUR 25 headline is not a complete current setup quote. [1] [2] [3]
Files and reuse terms
The README and license state CC-BY-SA-4.0. Sharing the licensed material requires retaining supplied attribution and license notices and indicating modifications; sharing adaptations also carries ShareAlike conditions. The selected control dependencies and purchased components require their own source and license review. [1] [2] [3]
The source inventory lists STEP and STL files. The external BOM and linked assembly/control resources were not established as a complete configuration-matched package in this review; this does not mean they are absent. Current delivered cost and measured performance are not established; no hardware was built or tested for this profile.
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
1b5a3dc
Source files and licenses
CC-BY-SA-4.0 in README and license. Match standalone versus SO-ARM100 configuration; retrieve linked external BOM and match the motor-control library. The approximately EUR 25 headline is not a complete current setup quote.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 CC-BY-SA-4.0 in README and license. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] |
| software | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] |
| documentation | available · License not fully assessed CC-BY-SA-4.0 in README and license. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] |
This profile scopes hardware tooling, without selecting a learned controller or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 PincOpen pinned tree
Revision, date & where cited
github.com · revision
1b5a3dc· Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S002 PincOpen / LICENSE
Revision, date & where cited
pollen-robotics · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S003 PincOpen / README.md
Revision, date & where cited
pollen-robotics · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S006 Upstream image and reuse attribution
Media-only review: Upstream photograph comparing PincOpen gripper assemblies with different tips. Reuse basis: CC-BY-SA-4.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Pollen Robotics contributors · github.com · revision
1b5a3dc· Image SHA-256 229a914c7041c3359338410f5d38430ee33400abd9099513a59e359bfa96b546; repository · Accessed Oct 25, 2026
Videos
- S004 Pollen Robotics (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Pollen Robotics · youtube.com · Accessed Oct 4, 2026
- S005 PincOpen (YouTube video)
Video from the project’s own channel (Pollen Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Pollen Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 2 YouTube reference(s) (S004, S005): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.