Robonine parallel gripper
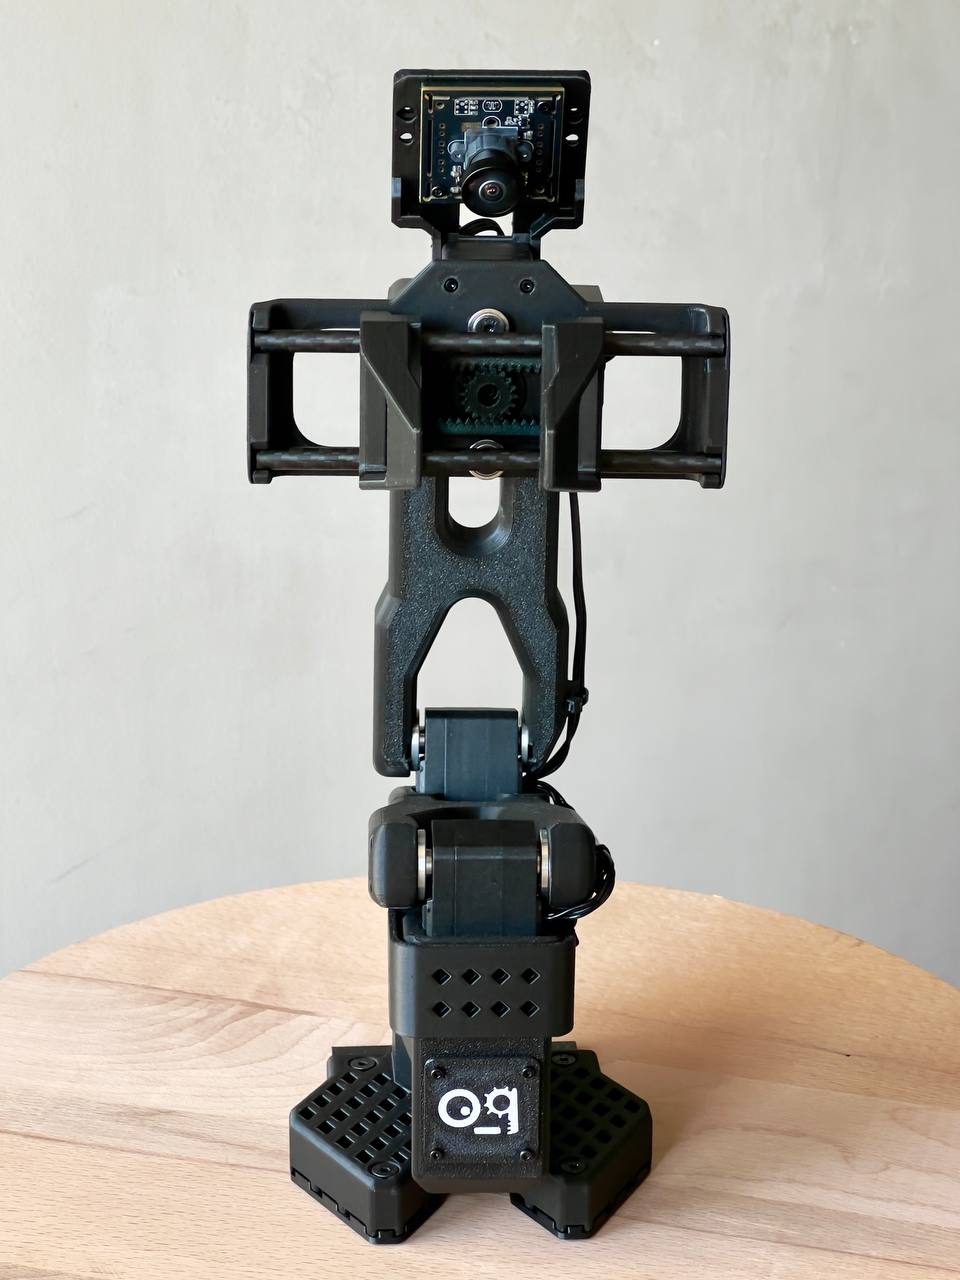
End effectorA parallel gripper for SO-ARM100/101 with selectable guide rods and modular printed parts. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- GPL-3.0 · Details by part
Is this for you?
- Known limitations
- BOM cost-summary rows total 58 although stated total is 62; bulk-pack and prorated costs are mixed. Two 200 mm tubes may be needed to cut two 125 mm rods. Do not sum every rod alternative.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
3D preview
Robonine parallel gripper assembly. Source STEP geometry for the named configuration. Purchased-component representations are included where supplied; this preview does not verify physical fit or a working build.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Robonine contributors, revision fc5fe00ccc8b536aba010c4707c6d8002661ac45. Original and preview: GPL-3.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Electric grippers
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Configuration and sourcing
v0.4.0; follower gripper with selected guide-rod material.
Servo ×1, bus board ×1, MF106ZZ bearings ×2, two 125 mm guide rods of ONE material, printed parts, screws and nuts. [1] [2] [3] [4] [5]
Integration
README reports SO-ARM100/101 compatibility; installed mass, calibration and motor revision still require matching. [1] [2] [3] [4] [5]
Resolve the printed and purchased variants
The BOM lists .020 clamps and .030 racks, while the assembly guide calls for .021 clamps, .031 racks and .100 nails. Both alternatives appear in the inventory. Reconcile a matching clamp, rack and nail set before printing. Follow the pinned assembly guide's order: it positions the servo and sets its torque limit early, before assembling the clamps and mounting the motor on the frame. [3] [4] [5]
The README names a Feetech STS3215 and Waveshare adapter, while the BOM identifies ST-3215-C018. Confirm the selected motor and servo-kit contents: the assembly guide uses screws and a disk supplied with that kit. Guide rods have a 6 mm diameter, with carbon-fiber, aluminium and steel alternatives. [1] [4] [5]
The January 2026 upstream supplier estimates assume home printing and exclude shipping. Listed cost rows total $58 against a stated $62. Its approximately $83 full-pack table also keeps a $2 bearing allowance despite the listed $9.99 pack. Neither table establishes the cash needed for a current checkout. [4]
GPL-3.0 is the repository declaration, not proof that every purchased component's design or firmware is covered. Complete revision-matched electronics, firmware and software source coverage remains unestablished; that does not establish that the components are closed source. [2]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- fc5fe00ccc8b536aba010c4707c6d8002661ac45; v0.4.0; follower gripper with selected guide-rod material
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · GPL-3.0 Root GPL-3.0; purchased components separately scoped. [1] [2] [3] [4] [5] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| documentation | available · GPL-3.0 Root GPL-3.0; purchased components separately scoped. [1] [2] [3] [4] [5] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
Design limits and source rights
BOM cost-summary rows total 58 although stated total is 62; bulk-pack and prorated costs are mixed. Two 200 mm tubes may be needed to cut two 125 mm rods. Do not sum every rod alternative. [1] [2] [3] [4] [5]
Root GPL-3.0; purchased components separately scoped. [1] [2] [3] [4] [5]
This is a source-researched design profile. We have not assembled or tested this configuration; no complete current setup price is established.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 roboninecom/SO-ARM100-101-Parallel-Gripper: README.md
Revision, date & where cited
github.com · revision
fc5fe00· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 4 more - S002 roboninecom/SO-ARM100-101-Parallel-Gripper: LICENSE
Revision, date & where cited
github.com · revision
fc5fe00· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 3 more - S003 roboninecom/SO-ARM100-101-Parallel-Gripper: files
Revision, date & where cited
github.com · revision
fc5fe00· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 3 more - S004 bom
Revision, date & where cited
github.com · revision
fc5fe00· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 3 more - S005 assembly
Revision, date & where cited
github.com · revision
fc5fe00· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 3 more - S007 Upstream image and reuse attribution
Media-only review: Upstream photograph of a parallel gripper mounted on an SO-series arm; the arm is separate from the gripper attachment. Reuse basis: GPL-3.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Robonine contributors · github.com · revision
fc5fe00· Image SHA-256 89c4b8be42a1acbe75d41da07a856b01c0563f5a0aea0d3a7598f215dbe96a3c; repository · Accessed Oct 25, 2026
Videos
- S006 SO ARM 101 parallel gripper with carbon roads (YouTube video)
Video from the project’s own channel (Robonine), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Robonine · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 1 YouTube reference(s) (S006): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.