OpenPodcar
Robot / hardware buildResearch vehicle conversion built around a specific mobility scooter, with Arduino throttle control, actuator steering and a legacy ROS/Gazebo stack. [1]
Build & first use →Official websiteBill of materials
- For
- Experienced research teams able to assess vehicle mechanics, electronics and controlled testing [1]
- Cost
- No current cost yet. Upstream bill of materials [1]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-W, GPL-2.0-only · Details by part
Overview
OpenPodcar documents a research conversion of a Pihsiang TE-889XLSN hard-canopy mobility scooter. The design adds actuator steering, Arduino-based throttle control, a Velodyne VLP-16 lidar and a Linux laptop. Its scope includes joystick control, navigation and Gazebo simulation, but upstream explicitly says the design carries no safety certification. This profile is source research, not qualification for passenger transport or public-road operation. [1]
Is this for you?
3D preview
OpenPodcar simulation assembly. Source simulation visuals at their supplied poses, including the separately credited Kinect sensor. The tree groups visuals by source link; the closed steering linkage is not simulated. This simplified model is not manufacturing CAD or a verified physical build.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original SDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: OpenPodcar contributors; Kinect model by Nathan Koenig, revision cd597fa7d593253b44c954e3edaeb19ded9a373a. Original and preview: GPL-2.0 / CERN-OHL-W-2.0; Kinect CC-BY-3.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. Source model, link and visual poses retained without simulating joints, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Operating system
- Ubuntu 16.04 with ROS Kinetic and Gazebo 7 in the documented route
- Windows computer for the documented Pololu configuration utility
- Host computer
Linux laptop for ROS and a Windows computer for the documented steering-controller setup.
- Dependencies
- ROS Kinetic, Gazebo 7 and catkin
- GMapping, move_base and TEB planner
- Arduino IDE and MCP4725 library
- Pololu configuration tooling
Hardware & parts
Upstream bill of materials [1]
- Hardware configuration
Converted Pihsiang TE-889XLSN hard-canopy mobility scooter, also identified upstream as Shoprider Traveso.
- Actuators
- Existing scooter drive
- Gimson GLA750-P 12 V linear actuator with 250 mm stroke and position feedback
- Controller
Arduino Uno Rev3 with MCP4725 throttle DAC; Pololu JRK 21v3 for steering; separate Linux laptop.
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Preserve the specific conversion
The hardware guide selects an Arduino Uno Rev3, MCP4725 DAC and Pololu JRK 21v3 controller with a Gimson GLA750-P steering actuator. It includes a parts list, vehicle modifications, electronics integration and separate component and integration checks. These instructions apply to the documented scooter and actuator geometry; they do not establish compatibility with an arbitrary replacement vehicle. [1]
The archive preserves KiCad board and schematic files, fabrication outputs and printable enclosure parts. It does not establish complete manufacturing sources for the purchased scooter, lidar, actuator or controller modules. Current component availability and a complete delivered build budget were not verified. [1] [6]
Resolve the serial setting before testing
The setup guide tells the reader to use a serial-monitor baud rate of 115000. The actual preserved Arduino sketch calls Serial.begin(9600), while its adjacent comment says 115200. These are three different values. The active call is evidence of what this sketch configures, not evidence that every host program or flashed board matches it. [1] [5]
The guide also abbreviates the sketch path: the actual file is inside an additional ThrottleControlSerial directory. Locate the preserved file and reconcile the host settings with the firmware actually installed, rather than relying on the conflicting prose. No firmware was uploaded or serial command sent in this review. [5] [6]
A rejected command is not necessarily a stop
The throttle sketch has an explicit stop command that sets its configured neutral DAC value. For an out-of-range fore/aft command, however, it reports that the throttle setting is unchanged. Its main loop processes newly received commands and contains no communication-age check that automatically returns to neutral. Those source behaviors should not be confused with a tested stop-on-disconnection mechanism. [5]
The physical guide separately includes a deadman handle and relay arrangement. It requires drive wheels to be raised for initial speed-control testing and describes component tests before integration. Those are documented procedures, not tests completed for this profile. The configured neutral and steering feedback must be reconciled with the actual vehicle; software inspection alone does not verify stopping behavior. [1] [5]
Keep the legacy environment and simulation separate
The documented software route uses Ubuntu 16.04, ROS Kinetic and Gazebo 7. It also uses a Windows utility for the Pololu setup. Navigation examples combine GMapping, move_base and the TEB planner, and some launch paths require local editing. The simulation instructions mention remote model downloads, so the main archive is not a complete preserved runtime environment. [1]
A successful simulation would not verify the converted vehicle's throttle, steering, braking or deadman circuit. This review did not install the stack, compile the simulation or operate the physical platform. [1]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- May 9, 2022 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- cd597fa7d593253b44c954e3edaeb19ded9a373a (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-W README explicitly assigns CERN-OHL-W to hardware design and build instructions but does not specify version; purchased scooter source and complete native design not established. [1] [6] |
| electronics | available · CERN-OHL-W KiCad schematic/board and fabrication files present under the README hardware-license statement; purchased modules separate. [1] [6] |
| firmware | available · GPL-2.0-only Root contains GPL v2 and README assigns GPL to project software; vendored libraries retain their own licenses. Firmware finding covers Arduino sketch, not complete scooter/Pololu firmware. [1] [3] [4] [5] |
| software | available · GPL-2.0-only Root contains GPL v2 and README assigns GPL to project software; vendored libraries retain their own licenses. Firmware finding covers Arduino sketch, not complete scooter/Pololu firmware. [1] [3] [4] [5] |
| documentation | available · CERN-OHL-W Build instructions explicitly covered by upstream hardware-license statement; version not specified. [1] |
Selected vehicle conversion and basic control/navigation route does not select a trained perception model or dataset; separate pedestrian-tracking experiments not reviewed.
License scope follows the artifact
The README assigns GPL to project software and CERN-OHL-W to hardware design and build instructions. The root software license is GPL version 2; the hardware statement does not specify a version. Vendored dependencies and purchased hardware remain separate. The available Arduino firmware is part of the integration source, not a release of every controller's firmware. [1] [3] [4] [6]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 OpenPodcar/OpenPodcar: README.md
Revision, date & where cited
github.com · revision
cd597fa· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 6 more - S002 OpenPodcar/OpenPodcar: commit cd597fa
- S003 OpenPodcar/OpenPodcar: LICENSE
Revision, date & where cited
github.com · revision
cd597fa· Accessed Oct 1, 2026
Used for: Source files and licenses - S004 OpenPodcar/OpenPodcar: files
Revision, date & where cited
github.com · revision
cd597fa· archive file inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S005 Preserved Arduino throttle implementation
Revision, date & where cited
github.com · revision
cd597fa· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Resolve the serial setting before testing and 2 more - S006 Physical design and control artifact paths
Revision, date & where cited
github.com · revision
cd597fa· Selected paths from complete preserved archive inventory · Accessed Oct 1, 2026
Used for: Assembly & first use, Preserve the specific conversion, Resolve the serial setting before testing, Source files and licenses - S008 Upstream image and reuse attribution
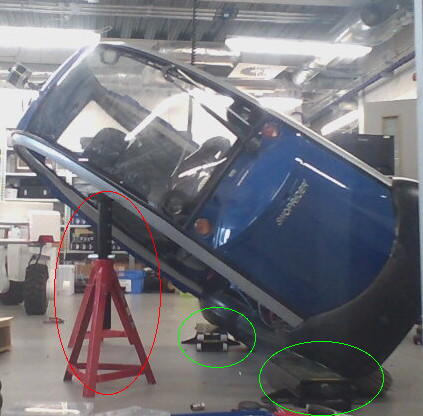
Media-only review: Upstream assembly photograph of the mobility-scooter conversion raised for work on its chassis; this is not a completed or safety-qualified passenger vehicle. Reuse basis: GPL-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
OpenPodcar contributors · github.com · revision
cd597fa· Image SHA-256 fb3ec3806e1fab2d3d22213455658f1fd548d0646c65bbc46e1ce582a3f35c96; repository · Accessed Oct 25, 2026
Videos
- S007 CMP3753M Project - Video Demonstration (YouTube video)
Video uploaded by GreyscaleVixen, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video GreyscaleVixen · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S007): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.