UMI
Robot / hardware buildHandheld gripper-based demonstration collection and diffusion-policy workflow, with separate robot deployment hardware and explicit SLAM, timing and source-artifact gaps. [1] [5] [6] [7]
Build & first use →Official website
- For
- Researchers able to assemble capture hardware and validate robot-specific policy deployment [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for mechanical design · Details by part
Overview
Universal Manipulation Interface uses a handheld parallel-jaw gripper with a camera to collect demonstrations, then processes those observations into policy-training data. The selected repository revision is d095ba9590df789df5189eea5ee7e431689038a6. The handheld capture device and the robot deployment system are distinct builds with different costs and dependencies. [1] [2] [5] [6]
Is this for you?
What you need
Hardware & parts
Assembly & first use
- Calibration
Match robot/gripper addresses, observation/action latency, TCP offset and geometry settings to the actual deployment; example values are not measurements of another rig.
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Model sources
Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Project notes
The hardware guide describes two packages
The capture guide lists printed gripper parts, linear rails, springs, soft fingers, visual tags and a GoPro Hero9 with a Max Lens Mod. It links separate Onshape documents for the gripper and fingers. It also states that left and right grippers use different tags, so bimanual hardware cannot be treated as two unconfigured copies. The public text export was preserved; image-based assembly details and external CAD payloads were not independently inspected. [5]
The deployment section instead lists a UR5-family arm, Weiss WSG-50, camera accessories, an HDMI capture card and workstation connections. Its per-component historical prices do not establish a current complete delivered budget, and the robot is listed by quote. A low capture-device cost therefore should not be presented as the cost of a complete autonomous robot system. [5]
SLAM quality limits the training input
The README provides an example SLAM workflow and explicitly identifies its ORB_SLAM3 fork as a fragile stage. Its example success fraction belongs to that supplied session, not to every new recording. The fork, container and data-collection instructions are separate dependencies. No videos were processed and no SLAM result was reproduced here. [1]
The selected installation instructions report testing only on Ubuntu 22.04 and name an RTX3090 with 24 GB for a tested single-GPU training setup. These are reported environment details, not a catalog-tested minimum specification. The workflow links processed datasets and pretrained checkpoints externally; their complete payloads and applicable licenses were not preserved in this review. [1] [9]
Deployment still requires rig-specific configuration
The example configuration contains robot and gripper addresses, observation and action latencies, a TCP offset, collision-geometry parameters and an inter-arm transform. Those are concrete reasons to match a deployment to the physical rig rather than treating broad calibration-free project language as eliminating all setup. They are examples, not measurements of a reader's hardware. [6] [7]
The UR route uses WSG50 configuration and a camera capture chain. The Franka instructions describe a separate Polymetis server on a real-time-kernel computer and different load settings. Neither route was installed or connected to hardware by this catalog. [1] [5] [8]
The cup-policy download command names cup_wild_vit_l_1img.ckpt, while the shown evaluation command uses cup_wild_vit_l.ckpt. Resolve that filename/configuration mismatch before assuming the example runs unchanged. The README also reports poor performance in direct sunlight for that policy; the project page's broader lighting-robustness claims should not erase this specific limitation. [1] [6]
The repository is MIT-licensed. That license is not automatically assigned to external CAD, hardware-guide media, datasets, checkpoints or the SLAM fork. This profile establishes source-researched workflow coverage, with no fabrication, training, flashing or physical performance test claimed. [1] [3] [5] [9]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- May 26, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- d095ba9590df789df5189eea5ee7e431689038a6 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Official hardware guide links gripper CAD, separate soft-finger CAD and deployment mounts. External CAD payloads, exact revisions and hardware reuse licenses were not independently preserved or established. [5] |
| electronics | not found · License not fully assessed Off-the-shelf camera and robot electronics are described; no complete custom electronics fabrication package established in the selected sources. [5] [9] |
| firmware | not found · License not fully assessed GoPro Labs, robot and gripper firmware are external dependencies; complete matched firmware sources and licenses were not collected. [1] [5] |
| software | available · MIT Selected repository code; external SLAM fork, robot packages and dependencies retain separate terms. [1] [3] |
| model weights | not found · License not fully assessed Official README links external pretrained checkpoints and datasets, but their payloads and licenses were not independently preserved in this review. This is not a claim that the artifacts are unavailable upstream. [1] [9] |
| datasets | not found · License not fully assessed Official README links external pretrained checkpoints and datasets, but their payloads and licenses were not independently preserved in this review. This is not a claim that the artifacts are unavailable upstream. [1] [9] |
| documentation | available · MIT Repository documentation only; external hardware guide, CAD, media and data are not assigned the software license. [1] [3] |
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 real-stanford/universal_manipulation_interface: README.md
Revision, date & where cited
github.com · revision
d095ba9· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 real-stanford/universal_manipulation_interface: commit d095ba9
- S003 real-stanford/universal_manipulation_interface: LICENSE
Revision, date & where cited
github.com · revision
d095ba9· Accessed Oct 1, 2026
Used for: Deployment still requires rig-specific configuration, Source files and licenses - S004 real-stanford/universal_manipulation_interface: files
Revision, date & where cited
github.com · revision
d095ba9· archive file inventory · Accessed Oct 1, 2026 - S005 UMI hardware building guide
Revision, date & where cited
real-stanford / project contributors · docs.google.com · Public text export retrieved October 1 2026; images not included · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 UMI project page
Revision, date & where cited
real-stanford / project contributors · umi-gripper.github.io · Retrieved October 1 2026 · Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Deployment still requires rig-specific configuration - S007 UMI example/eval_robots_config.yaml
Revision, date & where cited
github.com · revision
d095ba9· Accessed Oct 1, 2026
Used for: What you need, Assembly & first use, Deployment still requires rig-specific configuration - S008 UMI franka_instruction.md
Revision, date & where cited
github.com · revision
d095ba9· Accessed Oct 1, 2026
Used for: Deployment still requires rig-specific configuration - S009 Complete UMI archive file inventory
Revision, date & where cited
github.com · revision
d095ba9· archive inventory · Accessed Oct 1, 2026
Used for: Is this for you?, SLAM quality limits the training input, Deployment still requires rig-specific configuration, Source files and licenses - S012 Upstream image and reuse attribution
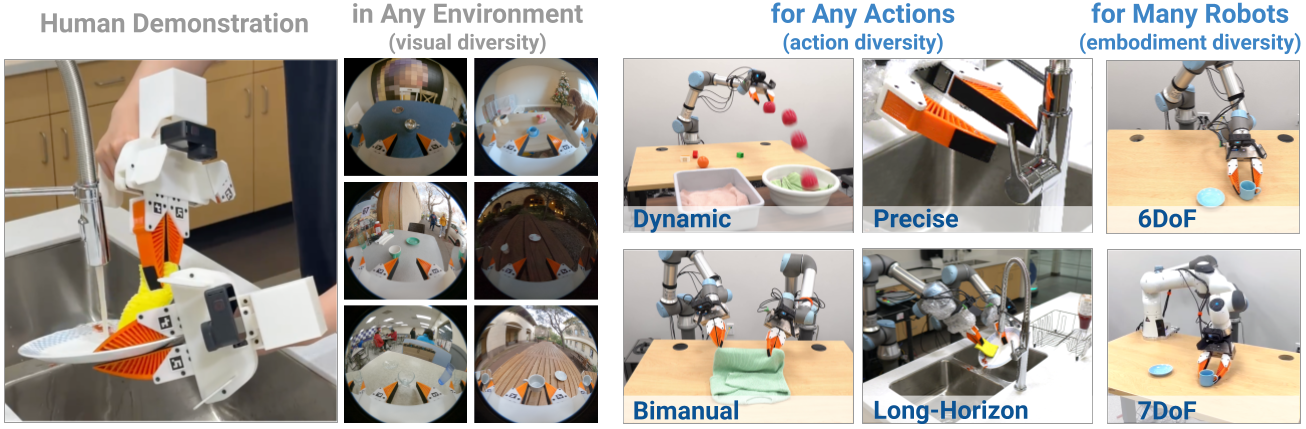
Media-only review: Upstream project illustration showing UMI data collection and deployment examples; the host robots are separate equipment. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Columbia Artificial Intelligence and Robotics Lab and UMI contributors · github.com · revision
d095ba9· Image SHA-256 005eebf64e3b8a0d8c89ea4fe3c71f4a1ac390a2a97dc9e7e76a0c995f86193c; repository · Accessed Oct 25, 2026
Videos
- S010 UMI - 3D Printing Tutorial (YouTube video)
Video from the project’s own channel (Robotics & Embodied Artificial Intelligence Lab), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Robotics & Embodied Artificial Intelligence Lab · youtube.com · Accessed Oct 4, 2026
- S011 UMI - Assembly Tutorial (YouTube video)
Video from the project’s own channel (Robotics & Embodied Artificial Intelligence Lab), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Robotics & Embodied Artificial Intelligence Lab · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S010, S011): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.