OpenBot
Robot / hardware buildSmartphone-controlled wheeled robot platform; the reviewed DIY configuration combines an Arduino Nano and L298N driver, with phone and firmware requirements distinct from the advertised body cost. [1]
Build & first use →Official websiteBill of materials
- For
- Makers with Android, soldering and microcontroller experience [1]
- Cost
- No current cost yet. Upstream bill of materials [5]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Overview
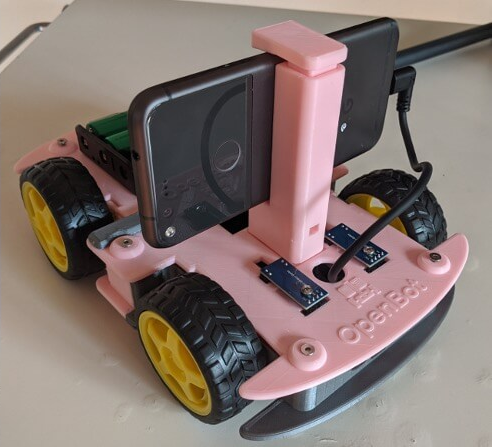
OpenBot uses an Android smartphone for high-level robot functions and a microcontroller for motor control and vehicle sensors. This profile focuses on the documented DIY body with four TT gearmotors, an Arduino Nano and an L298N driver. Lite, custom-PCB, RC-truck and ready-to-run variants are alternatives with different configurations, not interchangeable assembly instructions. The reviewed repository release is v0.8.0. [2] [5] [6] [12]
Is this for you?
- Known limitations
- Headline approximately $50 covers the body, not a complete phone-inclusive setup
- Point-goal navigation requires ARCore and camera permission
- Firmware configuration differs across DIY, PCB, Lite, RC and ready-to-run bodies
- Additional disclaimer contains a use restriction alongside MIT license text
What you need
Hardware & parts
Upstream bill of materials [5]
- Hardware configuration
DIY four-wheel smartphone-controlled vehicle; other body variants have separate configurations.
- Actuators
- Four TT gearmotors in the selected DIY body
- Controller
Android smartphone for high-level control; Arduino Nano and L298N motor driver for selected DIY configuration.
- Power
DIY parts list specifies three 18650 cells and a battery holder.
Assembly & first use
- Assembly
Printed or sourced chassis and phone mount, motor wiring and electronics assembly for the selected DIY body.
Cost
No current, complete configuration-specific build cost has been established for this profile.
The headline cost covers the vehicle body
The project’s approximate $50 figure describes its small electric vehicle body. It does not establish the cost of a complete setup including a compatible smartphone. The DIY list also calls for three 18650 cells, a holder, USB OTG cable, fasteners and wiring; printing or sourcing the chassis and phone mount remains part of the build. Optional sensors and the chosen control device add configuration-specific requirements. A current complete delivered budget was not verified. [1] [5]
Plan for soldering tools and electronics-wiring experience, plus access to a computer with Arduino tooling to upload the firmware. For manual control, the robot-app guide documents a Bluetooth game controller or a second phone running the controller app; this is distinct from a Bluetooth connection to the vehicle’s microcontroller. Android Studio is needed to build or modify the Android apps, while the installation guide also offers downloadable APKs. These prerequisites are not included in a verified complete price here. [5] [6] [7] [8]
3D preview
Preview not available yet. Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Model sources
Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Project notes
Select the firmware configuration before testing
The firmware guide requires the OPENBOT hardware setting to match the assembled vehicle: the L298N build uses DIY, while custom boards and other bodies have distinct settings. Voltage measurement, wheel sensors, sonar and other features have separate flags and dependencies. Bluetooth control of the vehicle is an ESP32 configuration option; it should not be assumed for the selected Nano body. [6]
Upstream’s first firmware checks are performed with wheels removed. Verify motor commands and installed sensor readings before moving to the phone app. The app’s Robot Info screen reports the firmware’s body type and supported features, providing another place to compare the actual build with its configuration. This review did not flash a controller or perform those checks. [6] [8]
Android compatibility depends on the feature
The Android guide specifies a minimum API level of 21; the inspected robot build file uses compile SDK 33 and target SDK 32. Those settings are not a guarantee that every feature works on every eligible phone. The app guide warns of device-dependent crashes and unexpected behavior. Point-goal navigation specifically requires ARCore and camera permission, and the guide says proceeding on an unsupported device causes a crash. [7] [8] [10]
For the selected USB configuration, the app guide gives a default serial rate of 115200. Check the controller-mapping screen before operating: the robot-app and policy-training guides describe different logging buttons, so a copied button name is not a reliable substitute for confirming the connected controller’s mapping. [8] [9]
Learned driving is a separate workflow
The policy guide describes collecting driving demonstrations, organizing training and test data, training in a TensorFlow 2.9-era environment and deploying a TensorFlow Lite model. The existence of that workflow does not establish navigation performance on a new phone, body or environment. This profile selects the physical platform and manual-control route; it does not qualify a particular model, dataset or training environment. No app build, model training or driving test was performed. [8] [9]
The repository contains an MIT license, but its separate disclaimer also prohibits malicious or unethical use. The interaction between that additional wording and the license has not been resolved here. The catalog therefore records source availability with this qualification rather than treating every design, dependency or downloaded model as unconditionally covered by the root MIT file. [3] [11]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Root MIT text exists alongside DISCLAIMER.md use restriction; interaction unresolved. Purchased components and externally supplied models are outside this license claim. [3] [5] [6] [7] [11] [13] |
| electronics | available · MIT Root MIT text exists alongside DISCLAIMER.md use restriction; interaction unresolved. Purchased components and externally supplied models are outside this license claim. [3] [5] [6] [7] [11] [13] |
| firmware | available · MIT Root MIT text exists alongside DISCLAIMER.md use restriction; interaction unresolved. Purchased components and externally supplied models are outside this license claim. [3] [5] [6] [7] [11] [13] |
| software | available · MIT Root MIT text exists alongside DISCLAIMER.md use restriction; interaction unresolved. Purchased components and externally supplied models are outside this license claim. [3] [5] [6] [7] [11] [13] |
| documentation | available · MIT Root MIT text exists alongside DISCLAIMER.md use restriction; interaction unresolved. Purchased components and externally supplied models are outside this license claim. [3] [5] [6] [7] [11] [13] |
Selected physical/manual-control configuration does not select a learned policy or dataset. Optional learned workflows require separate artifact and rights review.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 isl-org/OpenBot: README.de-DE.md
Revision, date & where cited
github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, Cost - S002 isl-org/OpenBot: commit 11bf583
- S003 isl-org/OpenBot: LICENSE
Revision, date & where cited
github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Learned driving is a separate workflow, Source files and licenses - S004 isl-org/OpenBot: files
Revision, date & where cited
github.com · revision
11bf583· archive file inventory · Accessed Oct 1, 2026 - S005 OpenBot v0.8.0: body/diy/README.md
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 2 more - S006 OpenBot v0.8.0: firmware/README.md
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S007 OpenBot v0.8.0: android/README.md
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: What you need, Cost, Android compatibility depends on the feature, Source files and licenses - S008 OpenBot v0.8.0: android/robot/README.md
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Cost and 3 more - S009 OpenBot v0.8.0: policy/README.md
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Android compatibility depends on the feature, Learned driving is a separate workflow - S010 OpenBot v0.8.0: android/robot/build.gradle
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: What you need, Android compatibility depends on the feature - S011 OpenBot v0.8.0: DISCLAIMER.md
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Is this for you?, Learned driving is a separate workflow, Source files and licenses - S012 OpenBot v0.8.0: body/README.md
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· Accessed Oct 1, 2026
Used for: Overview, Hardware & parts - S013 Complete preserved artifact filenames
Revision, date & where cited
isl-org / project contributors · github.com · revision
11bf583· archive inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S017 Upstream image and reuse attribution
Media-only review: Photograph of OpenBot with the glueable four-piece DIY body and a mounted smartphone, as shown in the selected source documentation. The covered electronics and installed software are not established by this image. Reuse basis: MIT. The exact selected v0.8.0 source snapshot includes this photograph as associated documentation of its supported DIY body. The selected DIY guide explicitly lists the regular,slim,glueable andblocky bodies as supported options, and identifies@sloretz as glueable-body contributor. The dedicated glueable guide directly embeds this source image, identifies four glued pieces and lists their source parts. Root MIT Copyright(c)2020IntelISL includes associated documentation; pinned inventory has no separate docs/body/image license override, and this image or guide has no external photo credit/exclusion. This is contributed first-party project documentation, not a photograph copied from an external article. Credit retains officialOpenBot contributors and the documented@sloretz body attribution without inventing a photographer personal name. Photo shows original four-wheelTT-styleDIY shell with moldedOpenBot text,phone mount,battery holder and front sensors, not OpenBotLite,MTV,RTR,RCTruck or thetwo-wheelcommunity build. The DIY guide supports bothL298N/ArduinoNano and optionalcustomPCB assembly; the picture has a closed shell, so no exact hidden electronics configuration or software/firmware version is claimed. This is a documented body-option illustration of the reviewed DIY platform, not verification of its internal stack. Earlier hold on unknown internal electronics is resolved only to this narrower visiblebody scope, not by asserting unseen L298N hardware. The assembled right photo is cropped away from separate part-layout photographs, without retouching, and the complete original montage and MIT copyright/permission notice are retained. Cropped to isolate the assembled OpenBot glueable-body photograph from the source image; no retouching. Full original retained. Technical/cost evidence dates unchanged.Revision, date & where cited
OpenBot documentation contributors (glueable body credited upstream to @sloretz) · github.com · revision
11bf583· Exact selected11bf583dcdb8d8e530967bef9add379bbbc94610 body/diy/README.md links the glueable option and credits@sloretz; body/diy/cad/glue_body/README.md embeds docs/images/glue_body.jpg. Rightmost assembled-robot photograph rectangle1263,0,1755,447.; image SHA-256 5c066952248e94ba9d9ac8a5f8b4f6337a0529e852afa6598ed3a4aff6b8ddcb · Accessed Oct 26, 2026
Videos
- S014 OpenBot: Turning Smartphones into Robots (2022) (YouTube video)
Video from the project’s own channel (OpenBot), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video OpenBot · youtube.com · Accessed Oct 4, 2026
- S015 Real Life Baby Yoda with AI (YouTube video)
Video uploaded by Manuel Ahumada, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Manuel Ahumada · youtube.com · Accessed Oct 4, 2026
- S016 OpenBot: Turning Smartphones into Robots (YouTube video)
Video uploaded by ISL and Collaborators, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ISL and Collaborators · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 3 YouTube reference(s) (S014, S015, S016): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.