RealMan RMG24
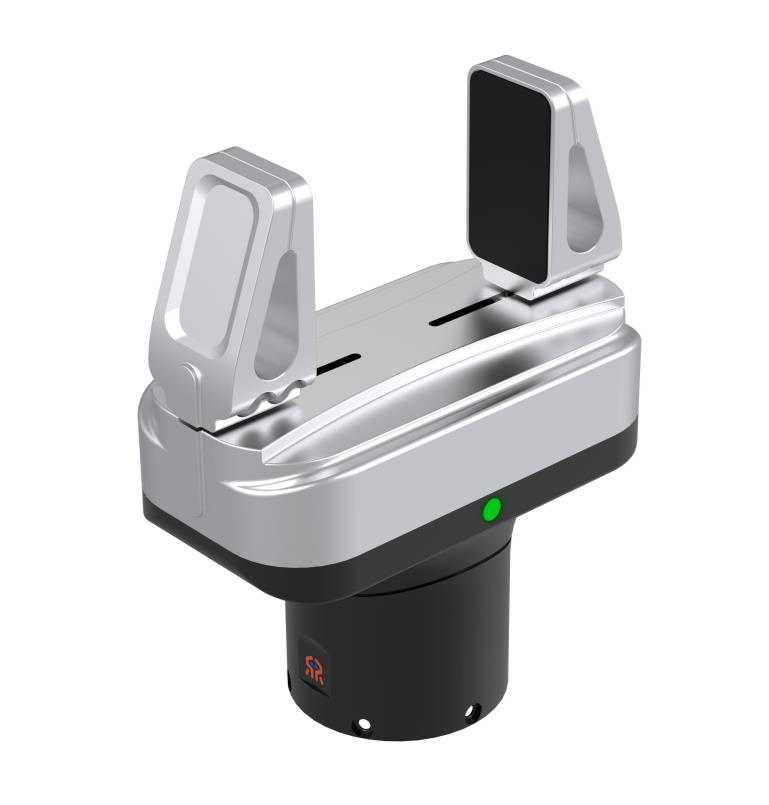
End effectorParallel gripper using the WHJ03 joint module, interface PCB and 24 V RS485/Modbus RTU control. [1] [2] [3] [4]
Build & first use →Official website
- For
- Builders evaluating this tooling design and its integration requirements [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- OpenAtom Open Hardware License 1.0 · license not fully assessed for documentation · Details by part
Overview
Is this for you?
3D preview
RealMan RMG24 gripper model. Source STEP geometry for the named configuration. Purchased-component representations are included where supplied; this preview does not verify physical fit or a working build.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: RealMan Robotics, revision 91f587b1d4efaab235f3d227ee614b28f35060c9. Original and preview: OpenAtom Open Hardware License 1.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Project documentation [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17]
- Assembly
RMG24 STEP is not proof of a complete machinable part set. Core WHJ03 source/sourcing, mechanical BOM and non-RM flange fit remain unresolved.
Known prerequisites and unresolved assembly decisions; not a complete build instruction.
[1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] · Editorial assessment
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Electrical interface versus mechanical fit
The README documents a custom six-pin aviation connector and a six-pin PH2.0 terminal. RM-arm connections are described directly; other manufacturers require pin-sequence adaptation. The PC route uses USB-to-RS485 and a shared power ground. Electrical communication support does not establish the flange geometry or fit of a non-RM arm. [3] [4]
Available sourcing material
The pinned inventory includes an RMG24 STEP model and interface-board BOM. That board list is not a complete mechanical parts list. The README describes board fabrication files and software resources, whose manufacturing suitability and matched revisions have not been validated here. Resolve WHJ03 source/sourcing and the mechanical BOM before treating the model as a reproducible complete gripper. [1] [3]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
91f587b
Source files and licenses
Hardware explicitly under OpenAtom Open Hardware License 1.0; third-party firmware licenses are separate. RMG24 STEP is not proof of a complete machinable part set. Core WHJ03 source/sourcing, mechanical BOM and non-RM flange fit remain unresolved.
| Layer | Availability / license |
|---|---|
| mechanical design | available · OpenAtom Open Hardware License 1.0 Hardware explicitly under OpenAtom Open Hardware License 1.0; third-party firmware licenses are separate. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] |
| software | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] |
| documentation | available · License not fully assessed Hardware explicitly under OpenAtom Open Hardware License 1.0; third-party firmware licenses are separate. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] |
This profile scopes hardware tooling, without selecting a learned controller or training dataset.
Source rights
The hardware license is OpenAtom Open Hardware License 1.0. Included CMSIS files use Apache-2.0; the STM32 HAL notice refers to Package_license with a conditional BSD-3-Clause fallback. These notices do not establish the rights or source availability of the entire purchased WHJ03 module or a complete matched control package. [2] [11] [12]
Current delivered cost and measured performance are not established. No hardware was built or tested for this profile.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 RealMan RMG24 pinned tree
Revision, date & where cited
github.com · revision
91f587b· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S002 RealMan RMG24 / License
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S003 RealMan RMG24 / readme.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S004 RealMan RMG24 / readme_CN.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Electrical interface versus mechanical fit and 1 more - S005 Software/gripper_app/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S006 Software/gripper_boot/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S007 Software/gripper_tool/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S008 Software/gripper_app/Keil/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S009 Software/gripper_boot/Keil/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S010 Software/gripper_app/Code/algo/readme.txt
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S011 Software/gripper_app/Keil/Drivers/CMSIS/LICENSE.txt
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S012 Software/gripper_app/Keil/Drivers/STM32G4xx_HAL_Driver/LICENSE.txt
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S013 Software/gripper_boot/Keil/Drivers/CMSIS/LICENSE.txt
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S014 Software/gripper_boot/Keil/Drivers/STM32G4xx_HAL_Driver/LICENSE.txt
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S015 Software/gripper_app/Code/algo/release/v1.0.1/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S016 Software/gripper_app/Code/algo/release/v1.0.2/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S017 Software/gripper_app/Code/algo/release/v1.0.3/README.md
Revision, date & where cited
RealManRobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S018 Upstream image and reuse attribution
Media-only review: Upstream illustration of the RMG24 two-finger gripper, not a photograph. Reuse basis: OpenAtom Open Hardware License 1.0; inspected License and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
RealMan Robotics contributors · github.com · revision
91f587b· Image SHA-256 928711ffe7f366075559215a61c236770b924ae3f9044ad4fc50e618a8fb1746; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.