Poppy Ergo
Robot / hardware buildA six-axis research arm using Dynamixel MX-28 motors and Python control. [1]
Build & first use →Official website
- For
- Research teams maintaining a Poppy Ergo; Makers familiar with Dynamixel and Python [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0, GPL-3.0 · license not fully assessed for documentation · Details by part
Overview
Poppy Ergo is the six-motor MX-28 research arm, not another name for Ergo Jr. Its README explicitly distinguishes the smaller educational sibling, which uses XL-320 motors. That difference affects the actuator order and control setup before any parts are printed. [1]
The documented physical route uses USB2Dynamixel or USB2AX with pypot and poppy-creature. The README also describes a Python package and optional V-REP simulation. Those references establish a historical setup route, not a tested current Python or simulator compatibility matrix. [1]
The source tree includes hardware and software directories. Its declared hardware license is CC BY-SA 4.0 and software license is GPL v3; use of the Poppy name is separately restricted. Preserve the repository snapshot and identify dependency versions before adapting the design or planning a kit. [1] [2] [4]
A complete MX-28 arm budget, current adapter availability and a reproducible calibration procedure have not been established in this review. We have not assembled or run this configuration.
3D preview
Flat base — simulation mesh. One flat-base mesh from the URDF simulation model. This is not a verified manufacturing file or a complete arm.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STL · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Poppy project contributors, revision cbc06011bfa9d677b958dee7699716aa64d80bfc. Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STL does not declare units; confirm dimensions against the project design. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- pypot
- poppy-creature
- poppy-ergo Python package
- V-REP for the documented optional simulation
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A limitations summary
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- May 3, 2016 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- cbc06011bfa9d677b958dee7699716aa64d80bfc (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 Hardware license declaration; do not substitute Ergo Jr's parts or license scope. [1] [4] |
| electronics | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| firmware | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| software | available · GPL-3.0 Software license declaration; dependencies have separate terms. [1] [4] |
| documentation | available · License not fully assessed Documentation available; reuse terms for external media not established. [1] [4] |
This profile covers the described physical configuration and control route without a particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 poppy-project/poppy-ergo: README.md
Revision, date & where cited
github.com · revision
cbc0601· Accessed Sep 30, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 1 more - S002 poppy-project/poppy-ergo: commit cbc0601
- S004 poppy-project/poppy-ergo: files
Revision, date & where cited
github.com · revision
cbc0601· archive file inventory · Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S007 Upstream image and reuse attribution
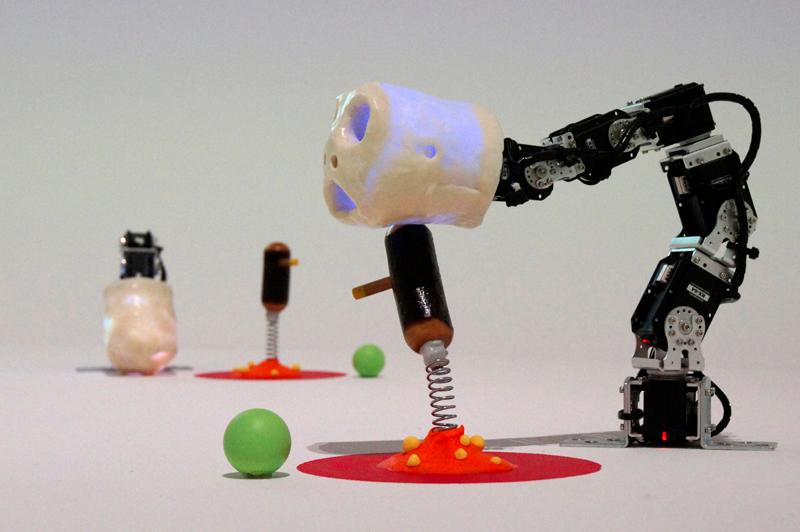
Media-only review: Upstream photograph of a Poppy Ergo arm with its tool; surrounding objects are demonstration context. Reuse basis: CC-BY-SA-4.0; inspected README.md and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Poppy Project and Inria contributors · github.com · revision
cbc0601· Image SHA-256 8c6bad813b2e796b630df42fcad8b6d2098a04e57a4aaac1fb3bfffb63924a14; repository · Accessed Oct 25, 2026
Videos
- S005 Poppy Project (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Poppy Project · youtube.com · Accessed Oct 4, 2026
- S006 The Ergo-Robots (YouTube video)
Video uploaded by Pierre-Yves Oudeyer, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Pierre-Yves Oudeyer · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S005, S006): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.