Open Duck Mini
Based on published sources · Not tested by us ·
Overview
A small printed biped with bus servos, a Raspberry Pi runtime and learned walking policies; the reviewed v2 build still has documentation and configuration gaps. [S001]
Open Duck Mini v2 offers a relatively small printed biped, but its files span the physical design, onboard runtime and a changing training workflow. Start with the standard v2 print list and the 7.4 V servo configuration. STEP files under community modification folders describe alternate heads and other changes; they are not an exported, complete CAD assembly for the standard robot. The primary CAD link remains an external Onshape workspace. [S001] [S005] [S008] [S010]

Specifications
| Detail | Description |
|---|---|
| Type | Open Duck Mini v2 biped; standard print set distinguished from community modifications Reported by source [S005] [S006] [S007] [S008] [S009] · Checked 2026-09-30 |
| Intended users | Experienced makers; Robotics learners with printing, soldering and Linux skills Editorial assessment [S001] · Checked 2026-09-30 |
| Assembly | Print PLA and TPU parts, fit M3 inserts, solder wiring and configure motors before assembly. Reported by source [S005] [S006] [S007] [S008] [S009] · Checked 2026-09-30 |
| Calibration | Check IMU orientation and motors; record individual joint offsets in duck_config.json. Reported by source [S005] [S006] [S007] [S008] [S009] · Checked 2026-09-30 |
| Operating system | Raspberry Pi OS Lite 64-bit documented for onboard runtime Reported by source [S005] [S006] [S007] [S008] [S009] · Checked 2026-09-30 |
| Computer needed | Raspberry Pi Zero 2 W onboard; separate computer for setup and any policy training. Reported by source [S005] [S006] [S007] [S008] [S009] · Checked 2026-09-30 |
Assembly and use
Print the standard parts before selecting modifications
The print guide calls for standard PLA at 15% infill, except the two foot-bottom pads, which use TPU at 40%. It lists quantities for each named part. Keep that list alongside the preserved STL files: the repository also contains optional modifications and simulation meshes, so printing every mesh would not produce one coherent robot. We have preserved the repository at an immutable commit, including its print files and policy files; we have not exported the external standard Onshape assembly. [S005] [S010]
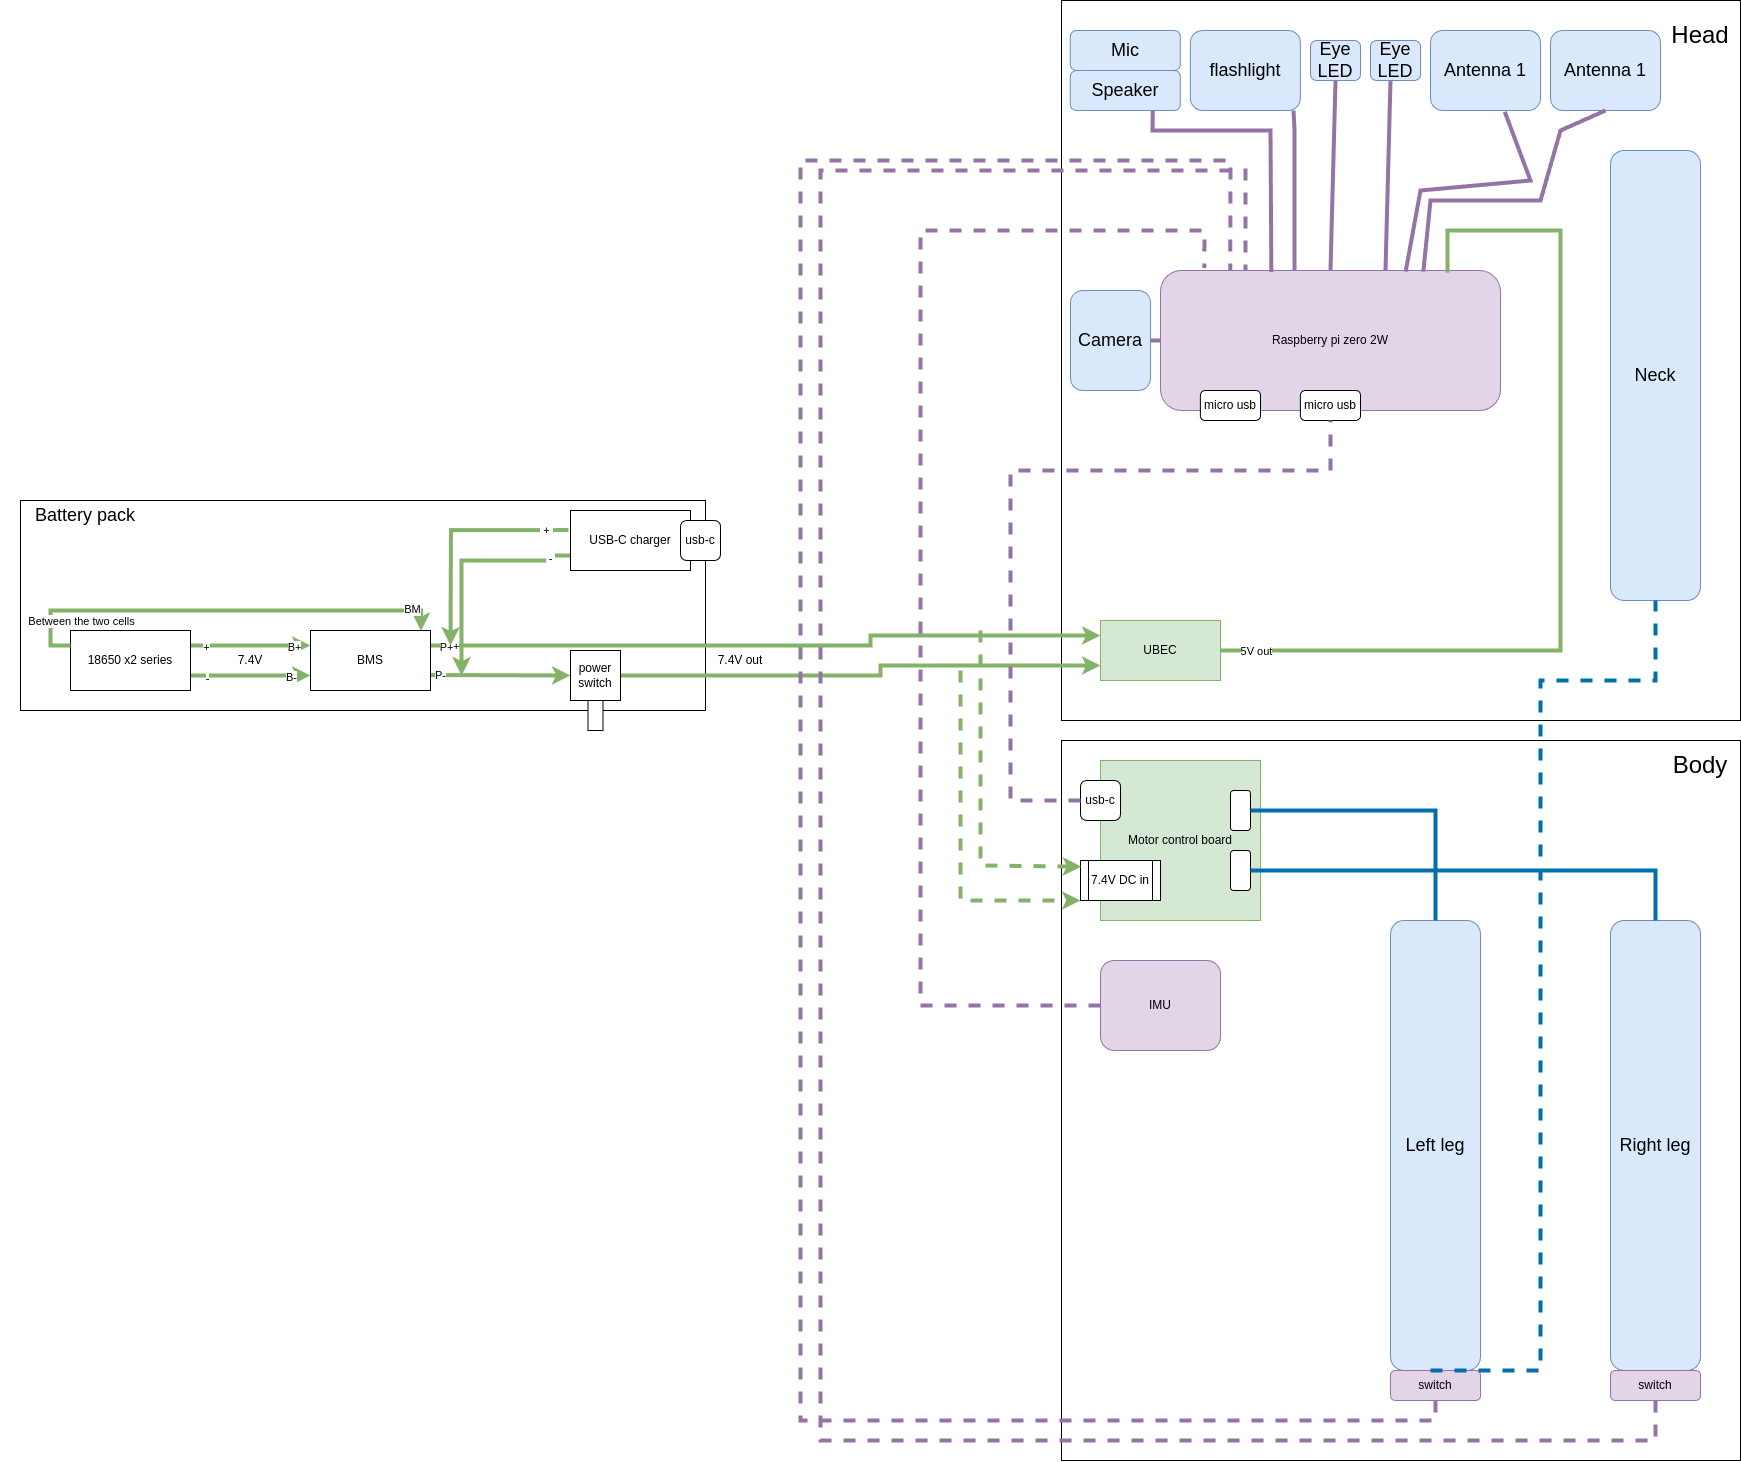
Configure the motors before mechanical assembly. The BOM identifies fourteen Feetech STS3215 servos specifically in the 7.4 V version, plus two small antenna servos, a Pi Zero 2 W, BNO055 IMU and a Waveshare bus-servo adapter. Assembly requires soldering, M3 inserts and threadlocker on specified metal connections. The guide still leaves the overall M3 screw quantity unspecified, so it is not yet a complete purchasing checklist. [S006] [S007] [S008]
The spreadsheet is more useful than the headline price
The README's under-$400 ambition is not a delivered build quote. The captured spreadsheet is denominated in euros: its main total is €398.10, rising to €432.34 with the listed expression package. Its lower €331.10 estimate assumes, among other things, existing PLA and a cheap IMU alternative that the author says still needs testing. Do not use that lower column as a verified equivalent build. [S001] [S008]
The sheet includes cells, a holder, BMS, regulator and charger, but it does not establish a complete delivered price including tools, shipping, tax and all fasteners. Several expression parts require buying packs larger than the quantity used; camera and microphone integration are marked unfinished in the captured sheet. The exact expression configuration therefore needs reconciliation before ordering. [S006] [S008]
Match the runtime, policy and calibration
The separate runtime instructions use Raspberry Pi OS Lite 64-bit and the v2 branch. They cover I2C, controller pairing, motor checks and a per-robot duck_config.json. That file records expression options, IMU orientation and measured joint offsets. The instructions link a walking-policy file from a moving branch; preserve the selected runtime commit and policy checksum together before comparing results across builds. Both repositories are now held locally, but we have not established a tested compatible combination. [S009]
Check IMU orientation explicitly: the assembly guide notes that its photographs show the IMU upside down and explains that configuration must match its installation. The runtime also labels head control experimental and warns that it can damage the head. These are practical limits to retain in any demonstration or support plan. No walking, calibration or hardware test has been performed for this profile. [S006] [S009]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [S003] [S004] [S005] [S006] |
| electronics | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [S003] [S004] [S005] [S006] |
| firmware | not found · License not fully assessed Servo setup is documented; complete source for purchased servo firmware was not established. [S007] [S008] |
| software | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [S003] [S004] [S005] [S006] |
| model weights | available · Apache-2.0 Pinned ONNX payload preserved; compatibility and walking performance have not been tested. [S001] [S003] [S010] |
| documentation | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [S003] [S004] [S005] [S006] |
No training dataset selected or reproduced for this configuration.
References
Links identify the documentation and revisions used in this profile. Access dates record when each source was retrieved.
- S001 · apirrone / project contributors
Upstream project overview
Accessed 2026-09-30 · README.mdSource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S002 · apirrone / project contributors
Repository revision and release metadata
Accessed 2026-09-30 · b23317a485b3cec7d8417f352478778b3475173cSource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S003 · apirrone / project contributors
Repository license
Accessed 2026-09-30 · LICENSESource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S004 · apirrone / project contributors
Pinned repository artifact inventory
Accessed 2026-09-30 · b23317a485b3cec7d8417f352478778b3475173c archive file inventorySource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S005 · apirrone / project contributors
docs/print_guide.md
Accessed 2026-09-30 · docs/print_guide.mdSource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S006 · apirrone / project contributors
docs/assembly_guide.md
Accessed 2026-09-30 · docs/assembly_guide.mdSource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S007 · apirrone / project contributors
docs/configure_motors.md
Accessed 2026-09-30 · docs/configure_motors.mdSource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S008 · apirrone / project contributors
Open Duck Mini component spreadsheet
Accessed 2026-09-30 · Feuille 1, rows 5–41; dated XLSX snapshotSource notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S009 · apirrone / project contributors
Onboard runtime setup
Accessed 2026-09-30 · README.md at 32037347dc43186a017f2116bcfde7c461b81f54Source notes
Source text inspected for the cited scoped claims; see profile claim notes.
- S010 · apirrone / project contributors
Exact print, model and policy filenames
Accessed 2026-09-30 · Pinned archive payload inventorySource notes
Source text inspected for the cited scoped claims; see profile claim notes.
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
September 29, 2026 — First research profile published.