GELLO
Teleoperation inputJoint-matched teleoperation leaders for robot manipulators; selected coverage follows the YAM passive configuration and distinguishes the separate Franka FR3 ROS 2 workflow. [1] [5] [6] [8]
Build & first use →Official website
- For
- Robotics developers matching leader assembly, follower robot and configuration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
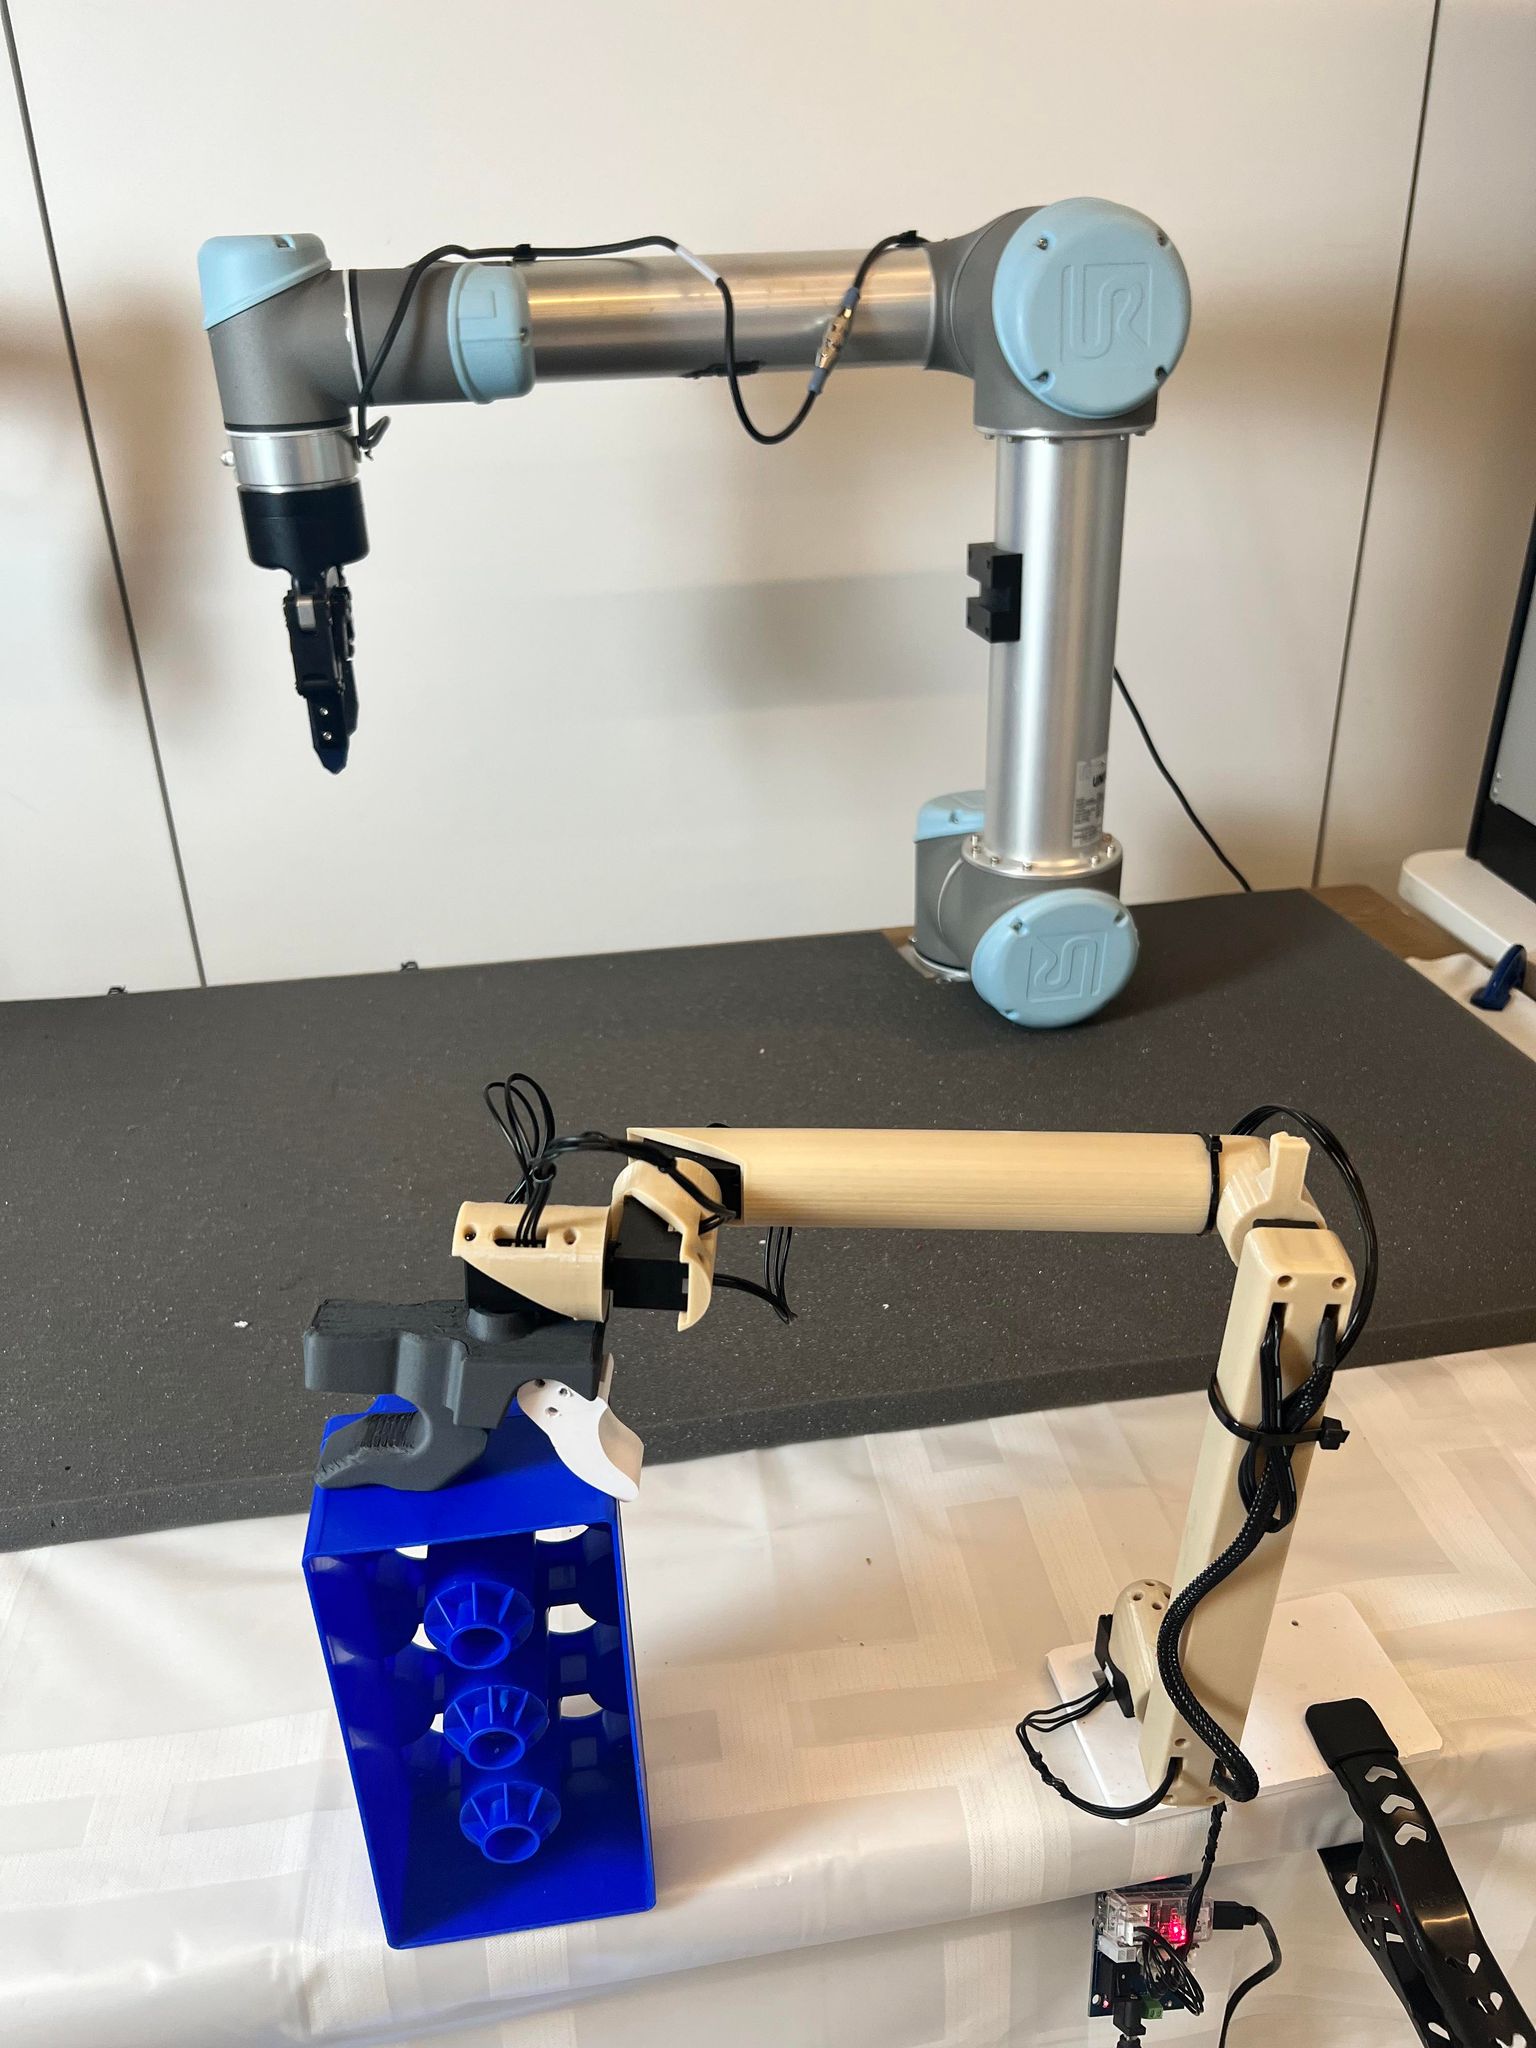
GELLO maps a human-operated jointed leader to a robot manipulator and can record demonstrations. The follower robot, its controller and its operating requirements remain separate dependencies. This review selects the YAM passive-leader route in software commit 204f53a64bef89471a1e483b0f874f755fbd2d3a, alongside mechanical revision 8ea3f2e661b55d4a128683b09227f8e771cd729e. [1] [2] [8]
Is this for you?
- Known limitations
- Passive and active YAM leader parts are separate variants
- Example offsets and device identifiers are assembly-specific
- Mechanical repository links external BOM/assembly instructions
- Root software documentation and referenced dependency payloads are not a complete recursive installation
3D preview
GELLO Lite6 leader model. Lite6 leader configuration only; this is a manual input device, not the follower robot or other GELLO variants.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Philipp Wu / GELLO contributors, revision 8ea3f2e661b55d4a128683b09227f8e771cd729e. Original and preview: MIT. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Printed leader parts are specific to the follower geometry
The mechanical archive has separate folders for robot types and distinct active, large-passive and small-passive YAM leaders. Compatibility of the selected YAML with the large and small passive assemblies remains unverified. Resolve that mapping with variant-specific assembly and calibration documentation before selecting printed parts; the generic GELLO name does not make them interchangeable. Its README links an external BOM and assembly document; that document was not independently preserved in this review. [8] [10]
STLs are available, while editable-source coverage varies: the inventory contains OpenSCAD for AR4 and a STEP model for Lite6, but the root README directs readers to contact the author for CAD access. This profile does not infer complete editable CAD for every leader. The mechanical repository has an MIT license, with a separate MIT notice for the Franka contribution. [8] [9] [10] [11]
Replace example identifiers and calibrate the actual assembly
The selected yam_passive.yaml assigns six joint IDs and a seventh gripper ID, a specific serial path, measured-looking joint offsets and the can_left interface. These are example configuration values, not measurements of a reader's assembly. The README calls for unique Dynamixel IDs, matching poses, joint signs and offset calibration, and provides separate generated configurations for simulation and physical hardware. [1] [5]
The YAM route requires its robot-specific control dependency as well as the leader SDK. The root Git configuration lists DynamixelSDK and MuJoCo Menagerie submodules, but does not by itself provide every dependency named by the installation guide. No environment was installed and no leader or follower was connected here. [1] [7]
Franka FR3 uses a separate ROS 2 workflow
The FR3 implementation is documented under ROS 2 Humble, with robot-system compatibility requirements for libfranka and associated packages. Its publisher documentation distinguishes serial baud rate from publication rate: requesting more publications can repeat old samples rather than create fresh measurements. The same procedure may change servo EEPROM baud settings when the detected chain differs from the requested configuration. These are meaningful integration effects, not merely launch preferences. [6]
The YAM YAML workflow should therefore not be blended with FR3 calibration and launch instructions. Likewise, the optional active gravity-compensation path is distinct from the passive leader selected here; it needs its own configuration and model reconciliation. [1] [5] [6]
Demonstration recording is an output, not proof of learned performance
The software describes recording teleoperation data and launching one or two follower configurations. It does not make the selected leader a pretrained autonomous manipulation policy. Software and mechanical sources support research coverage under their scoped MIT notices, while third-party SDKs and robot packages retain their own terms. [1] [3] [7] [9]
A complete delivered budget must include the selected leader components, host/interface hardware and follower system. No build, calibration, recording session, motion test or control-performance measurement was performed by this catalog. [1] [5] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Sep 14, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 204f53a64bef89471a1e483b0f874f755fbd2d3a (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Robot-specific leader STL files are preserved, including distinct YAM passive and active folders. Some other variants include editable formats; root README asks readers to contact the author for CAD access. This does not establish complete editable CAD for every variant. [8] [9] [10] [11] |
| electronics | not found · License not fully assessed Off-the-shelf servo/interface components identified; no complete custom electronics fabrication package established in the selected archives. [1] [5] [8] |
| firmware | not found · License not fully assessed Selected workflow depends on servo and follower firmware; complete matched firmware sources and licenses are outside the selected leader/software archives. [1] [7] [10] |
| software | available · MIT Repository project code; third-party SDKs, robot dependencies and attributed ROS components require their own notices. No blanket MIT claim for external code. [1] [3] [6] [7] |
| documentation | available · MIT Repository documentation only. Linked external BOM/assembly document and media rights are not independently established. [1] [3] |
Selected teleoperation/data-recording route does not require a learned policy or pre-existing training dataset; recorded demonstrations are outputs.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 wuphilipp/gello_software: README.md
Revision, date & where cited
github.com · revision
204f53a· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 5 more - S002 wuphilipp/gello_software: commit 204f53a
- S003 wuphilipp/gello_software: LICENSE
Revision, date & where cited
github.com · revision
204f53a· Accessed Oct 1, 2026
Used for: Demonstration recording is an output, not proof of learned performance, Source files and licenses - S004 wuphilipp/gello_software: files
Revision, date & where cited
github.com · revision
204f53a· archive file inventory · Accessed Oct 1, 2026 - S005 GELLO configs/yam_passive.yaml
Revision, date & where cited
github.com · revision
204f53a· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 4 more - S006 GELLO ros2/README.md
Revision, date & where cited
github.com · revision
204f53a· Accessed Oct 1, 2026
Used for: What you need, Franka FR3 uses a separate ROS 2 workflow, Source files and licenses - S007 GELLO .gitmodules
Revision, date & where cited
github.com · revision
204f53a· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Replace example identifiers and calibrate the actual assembly, Demonstration recording is an output, not proof of learned performance and 1 more - S008 GELLO mechanical README.md
Revision, date & where cited
github.com · revision
8ea3f2e· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Printed leader parts are specific to the follower geometry and 2 more - S009 GELLO mechanical LICENSE
Revision, date & where cited
github.com · revision
8ea3f2e· Accessed Oct 1, 2026
Used for: Printed leader parts are specific to the follower geometry, Demonstration recording is an output, not proof of learned performance, Source files and licenses - S010 GELLO mechanical inventory.json
Revision, date & where cited
github.com · revision
8ea3f2e· Accessed Oct 1, 2026
Used for: Is this for you?, Printed leader parts are specific to the follower geometry, Source files and licenses - S011 GELLO mechanical franka_fr3/LICENSE
Revision, date & where cited
github.com · revision
8ea3f2e· Accessed Oct 1, 2026
Used for: Printed leader parts are specific to the follower geometry, Source files and licenses - S012 Upstream image and reuse attribution
Media-only review: Upstream photograph comparing a GELLO leader with a host robot arm; the host robot is separate equipment. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Philipp Wu and GELLO contributors · github.com · revision
204f53a· Image SHA-256 d150f2182f62190bf6a47d05462cdd942932b1fae15acd89348f42defed01ec7; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.