OpenCR
Control boardROS-oriented STM32F7 controller with Arduino firmware sources and separate REVH hardware files whose precise reuse license remains unresolved. [1] [5] [6]
Build & first use →Official website
- For
- Robot developers integrating DYNAMIXEL devices and embedded control [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for mechanical design, electronics · Details by part
Overview
OpenCR is an STM32F7-based embedded controller used in the ROBOTIS ROS ecosystem. Its firmware repository contains Arduino board support, libraries, bootloader and loader sources, plus robot-specific firmware releases. The board is a building block: its interfaces and example packages do not establish that every connected robot has the same firmware or power requirements. [1]
Is this for you?
- Known limitations
- Hardware archive does not identify a specific license in a root license file
- Sensor revision changed in2020; older9-axis descriptions do not apply unchanged
- Historical Arduino setup examples are not verified on current host systems
Source-review boundaries.
3D preview
OpenCR Rev H source board assembly. The complete first-party OpenCR Rev H STEP board assembly with source component names, grouping and placements. The hardware README permits distribution under unspecified open-source licenses, but no precise repository or file-level license was identified; this preview records that ambiguity and does not claim manufacturing or redistribution clearance. Electrical behavior, fabrication readiness and physical fit are not verified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP (gzip) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: ROBOTIS / OpenCR-Hardware contributors, revision 4c56093c5aaedbcb98b374f94a8046187834022c. Original and preview: No specific hardware license identified; first-party README permits open-source distribution but exact terms remain unresolved. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
The sensor revision changes the specification
The official manual lists an STM32F746ZGT6 Cortex-M7 processor at 216 MHz, a 105 × 75 mm board and USB, DYNAMIXEL TTL/RS-485, UART, CAN, I2C, SPI and general-purpose interfaces. It explicitly says the MPU9250 was replaced by ICM-20648 in 2020. The newer sensor listing includes gyro and accelerometer functions, while the older one also includes a magnetometer. An older nine-axis description should therefore not be copied onto an unidentified board. [7]
Power also needs configuration-specific checking. The manual lists USB 5 V or a 5–24 V battery/SMPS input. It specifies a 12 V output maximum of 4.5 A and a 5 V output maximum of 4 A, with a shared 55 W ceiling across those outputs. Their individual maxima should not be added into an unrestricted actuator budget. USB communication alone does not establish enough power for an attached robot. [7]
Separate board support from the robot application
The documented Arduino route adds ROBOTIS's package index, installs the OpenCR board package, selects the board and selects the actual USB serial port. Linux instructions include USB access rules and historical 32-bit library requirements. The examples refer to old Arduino versions, so they establish the documented workflow rather than a tested recipe for every current IDE and operating system. [8]
Before uploading, retain the physical board revision, its installed application and the intended robot's firmware pairing. The source tree separates general Arduino support from TurtleBot3 release binaries and loader tools. A successful generic board upload would not verify a complete TurtleBot3 or other robot installation. No host packages or robot firmware were installed during this review. [1] [8]
The manual describes two recovery-related procedures that should not be confused. MCU DFU mode uses the Boot button during reset for bootloader work; application recovery uses PUSH SW2 during reset to enter the existing bootloader and download normal firmware. Match the procedure to the problem rather than treating bootloader replacement as a routine application upload. These procedures were read, not exercised on hardware. [9] [10]
Hardware files are available; precise terms remain unresolved
The separate hardware archive contains 14 files, including a REVH BOM, Gerber ZIP, OrCAD schematic, DXF outlines and STEP/STL layout models. Its README declares open-source distribution but the inspected archive contains no root license document identifying the specific hardware terms. The firmware repository's Apache-2.0 license does not automatically answer that question for a different repository. File availability and confirmed reuse rights are recorded separately here. [3] [5] [6]
The hardware BOM and drawing files were inventoried, but their component rows, geometry and fabrication completeness were not validated. A current complete budget remains unknown, including the board, supply, cables, host and selected robot's actuators. No board was fabricated, firmware flashed, sensor calibrated or robot operated for this profile. [6] [7] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed REVH files preserved. README claims open-source distribution but specific applicable hardware license was not identified; firmware Apache license is not transferred to this separate repository. No geometry or manufacturing verification. [5] [6] |
| electronics | available · License not fully assessed REVH files preserved. README claims open-source distribution but specific applicable hardware license was not identified; firmware Apache license is not transferred to this separate repository. No geometry or manufacturing verification. [5] [6] |
| firmware | available · Apache-2.0 Repository default license, subject to file-specific and bundled third-party notices. External e-manual is not assigned this repository license. [1] [3] [4] |
| software | available · Apache-2.0 Repository default license, subject to file-specific and bundled third-party notices. External e-manual is not assigned this repository license. [1] [3] [4] |
| documentation | available · Apache-2.0 Repository default license, subject to file-specific and bundled third-party notices. External e-manual is not assigned this repository license. [1] [3] [4] |
Selected embedded-control route does not require learned weights or a training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 ROBOTIS-GIT/OpenCR: README.md
Revision, date & where cited
github.com · revision
68ec75d· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 2 more - S002 ROBOTIS-GIT/OpenCR: commit 68ec75d
- S003 ROBOTIS-GIT/OpenCR: LICENSE
Revision, date & where cited
github.com · revision
68ec75d· Accessed Oct 1, 2026
Used for: Hardware files are available; precise terms remain unresolved, Source files and licenses - S004 ROBOTIS-GIT/OpenCR: files
Revision, date & where cited
github.com · revision
68ec75d· archive file inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S005 OpenCR hardware overview
Revision, date & where cited
github.com · revision
4c56093· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware files are available; precise terms remain unresolved, Source files and licenses - S006 Complete hardware archive inventory
Revision, date & where cited
github.com · revision
4c56093· complete14-file inventory · Accessed Oct 1, 2026
Used for: Is this for you?, Hardware files are available; precise terms remain unresolved, Source files and licenses - S007 Official board specifications
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · Preserved manual text lines609-710; fetched2026-10-01 · Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Hardware & parts, The sensor revision changes the specification and 1 more - S008 Arduino installation and board selection
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · Preserved manual text lines2413-2555; fetched2026-10-01 · Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Separate board support from the robot application, Hardware files are available; precise terms remain unresolved - S009 DFU bootloader update
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · Preserved manual text lines4514-4560; fetched2026-10-01 · Accessed Oct 1, 2026
Used for: Separate board support from the robot application - S010 Firmware recovery mode
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · Preserved manual text lines4703-4740; fetched2026-10-01 · Accessed Oct 1, 2026
Used for: Separate board support from the robot application - S015 Upstream image and reuse attribution
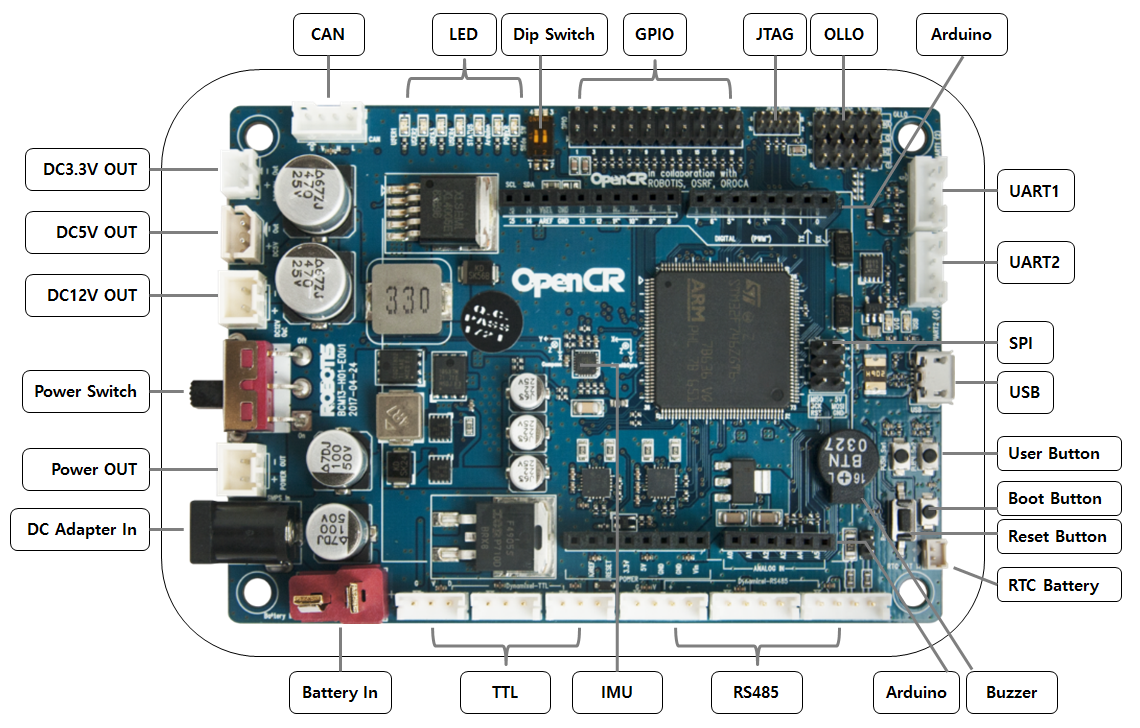
Media-only review: Upstream documentation photograph of an OpenCR 1.0 controller with connector labels. The photograph’s PCB revision is not established as REVH. Reuse basis: CC-BY-4.0. Image is in the TurtleBot3 documentation’s OpenCR1.0 appendix, covered by the TurtleBot3 Documents License, not inferred from the firmware license. Physical OpenCR1.0 board and ports are visible. Caption explicitly avoids identifying this older documentation image as the separately reviewed REVH files. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
ROBOTIS / TurtleBot3 documentation contributors · emanual.robotis.com · TurtleBot3 > More Info > Appendixes > OpenCR1.0; main annotated board photograph; Documents License; image SHA-256 b2e1c7200f3cb0aec2556813c869a765bce760d15ce5d939f15a61ab4c393bd7 · Accessed Oct 26, 2026
Videos
- S011 ROBOTIS (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel ROBOTIS · youtube.com · Accessed Oct 4, 2026
- S012 OpenCR 05 Joystic Example (YouTube video)
Video from the project’s own channel (ROBOTIS OpenSourceTeam), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ROBOTIS OpenSourceTeam · youtube.com · Accessed Oct 4, 2026
- S013 OpenCR 04 Capacitive Touch Sensor Example (YouTube video)
Video from the project’s own channel (ROBOTIS OpenSourceTeam), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ROBOTIS OpenSourceTeam · youtube.com · Accessed Oct 4, 2026
- S014 OpenCR 06 Flame Sensor Example (YouTube video)
Video from the project’s own channel (ROBOTIS OpenSourceTeam), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ROBOTIS OpenSourceTeam · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 4 YouTube reference(s) (S011, S012, S013, S014): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.