MSG gripper
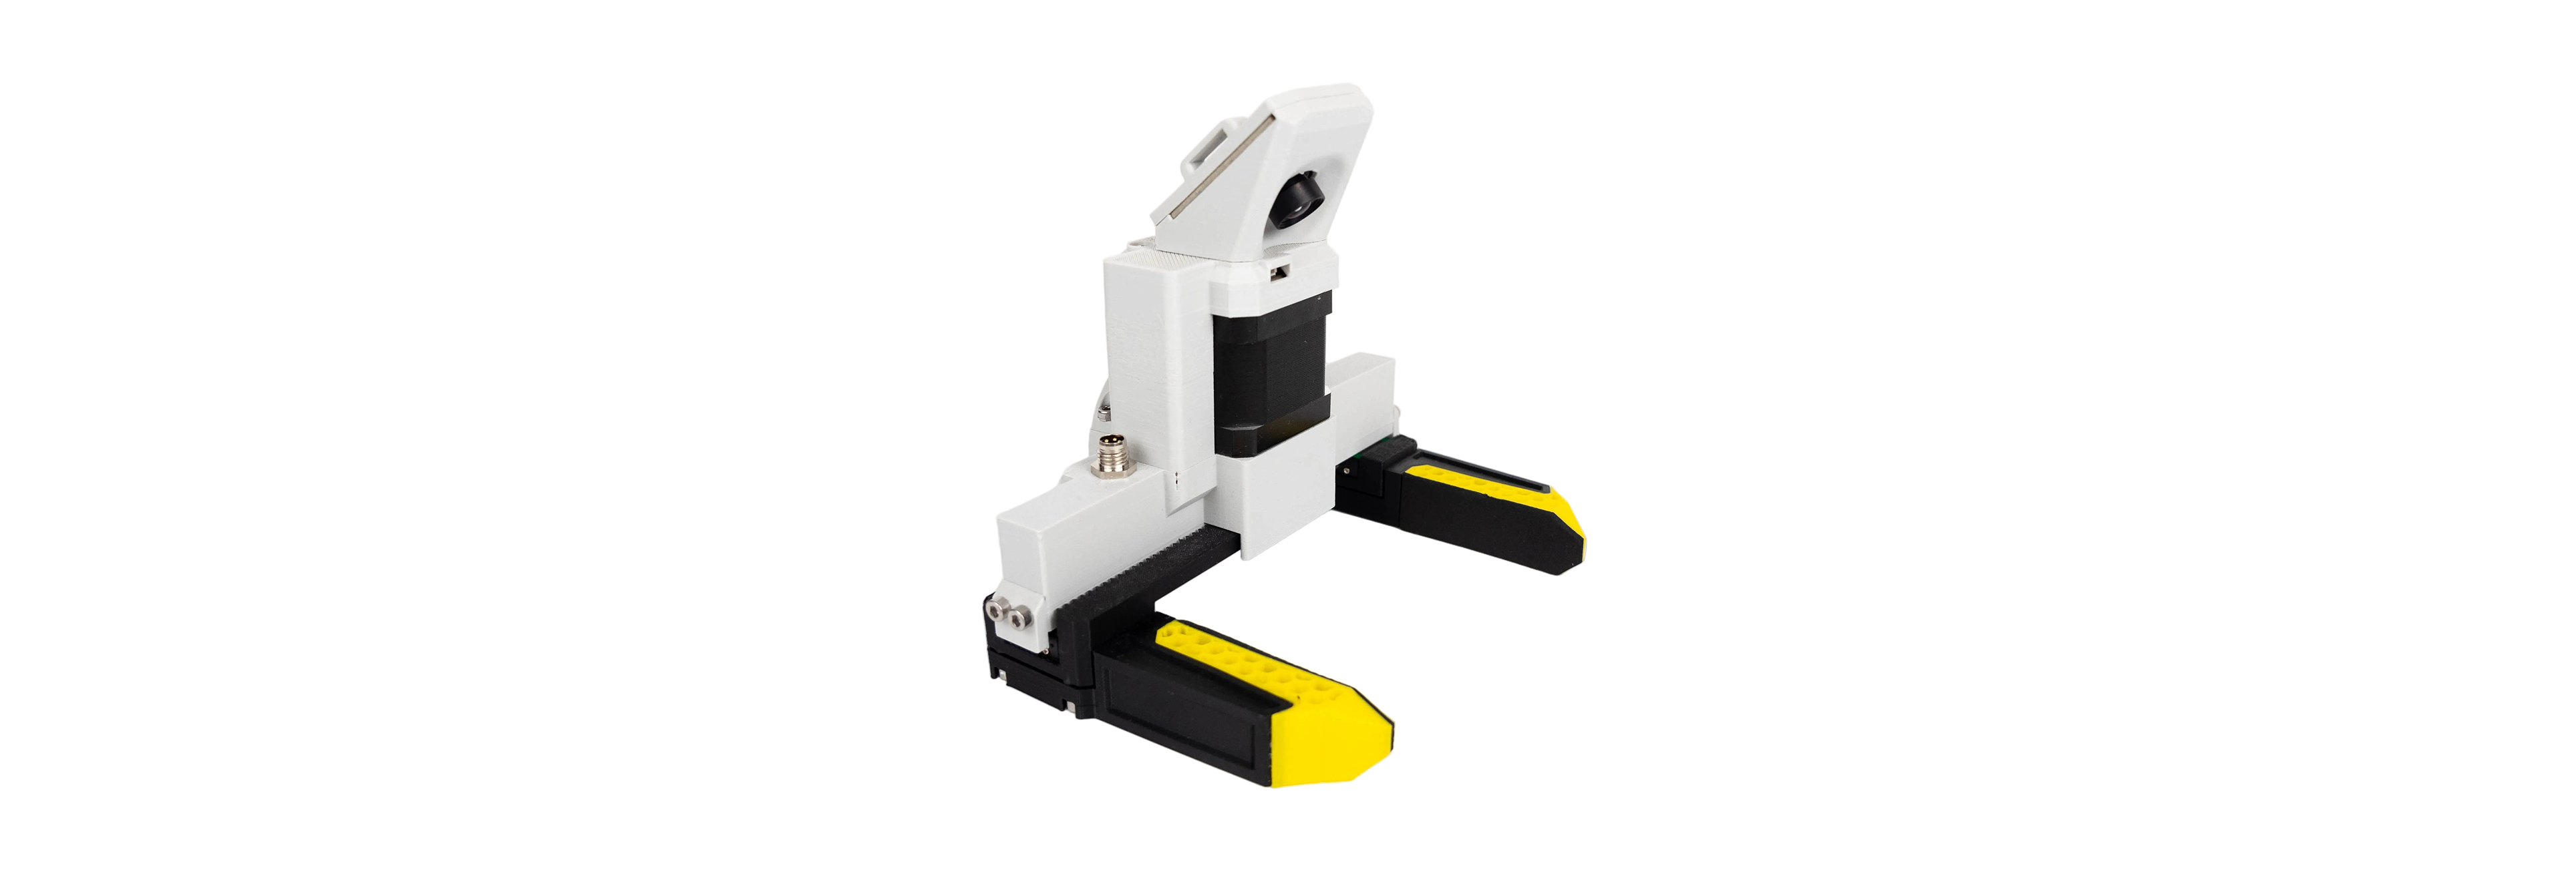
End effectorA modular stepper-driven gripper with selectable rail and motor lengths. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-S-2.0 · Details by part
Is this for you?
- Known limitations
- V1.1 assembly manual is an unfinished placeholder; resolve actual stroke and firmware match. Assembled offer is described as pre-release and excludes a verified complete setup.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
3D preview
MSG gripper simplified robot description (official URDF). The official simplified MSG gripper robot description from Source Robotics: PAR6_MSG.urdf in MSG_gripper_description at commit ca47db3, exported with the SolidWorks-to-URDF exporter (its header comment says the PAR6 arm links were removed). It is shown at zero joint positions: one gripper-body mesh and two jaw meshes on the source prismatic jaw joints (3 links). According to the exporter log in the download, the body mesh fuses components named MSG_Gripper_body_150mm, linearguide_150mm, a 17HS08-1004S stepper motor, two MGN7C carriages, an OV9732 camera and covers, and each jaw mesh fuses the linear_track_URDF and solid_jaws_pinch parts of the SSG-48 gripper model. These component names indicate the 150 mm rail version; other rail and motor lengths are not shown. Purchased components (stepper motor, rail, carriages and camera) are kept as modeled; their third-party terms are not stated. Each link is one mesh, so parts cannot be inspected separately. The model was added after the V1.1 repository revision reviewed for this profile. License notices conflict (repository LICENSE: CERN-OHL-S-2.0; description readme: Apache-2.0; URDF package metadata: BSD), so no manufacturing or redistribution clearance is claimed beyond what the source states. Fit and motion are not verified.
Conflicting license notices: the repository LICENSE file is the “CERN Open Hardware Licence Version 2 - Strongly Reciprocal” (CERN-OHL-S-2.0) and the README says the project is under that licence; the MSG_gripper_description readme says “This model is released under an Apache-2.0 License”, although that folder contains no license file; and the URDF package metadata (package.xml, a SolidWorks exporter default) says “BSD”. The source does not say which governs this model. Open Source Robotics shows it with attribution to Petar Crnjak / Source Robotics and keeps the strongly reciprocal CERN-OHL-S-2.0 notice with the hosted files. Purchased components modeled inside the meshes have unstated third-party terms. No manufacturing or redistribution clearance is claimed beyond what the source states. License: MSG LICENSE (CERN-OHL-S-2.0); description readme states Apache-2.0 · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Petar Crnjak / Source Robotics, revision ca47db35ccb35dbcc33985367f76899fb4804d5a. Original and preview: Conflicting notices: LICENSE CERN-OHL-S-2.0; description readme Apache-2.0; URDF package.xml BSD. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Electric grippers
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Configuration and sourcing
V1.1 repository; README still labels beta; 100/150/200 mm rails and 21.5/40/60 mm motors.
Choose one of three NEMA17 motors; STEPFOC ×1; MGN7C carriages ×2; one selected rail; gear, magnet, thermistor, camera, inserts, printed parts and cables. [1] [2] [3] [4] [5] [6] [7] [8]
Choose rail/motor combination before printing matching folders; assemble and wire STEPFOC; reconcile calibration with matching firmware. [1] [2] [3] [4] [5] [6] [7] [8]
Integration
CAN/Python route. BOM warns PAROL6 and PAR6 use different cables. Vendor stroke choices 55/105/155 mm are not rail lengths. [1] [2] [3] [4] [5] [6] [7] [8]
Configuration checks before ordering
The vendor reports 12–24 V supply and 1 Mbit CAN. The README demonstrates the Spectral_BLDC Python API, but matching that API, controller firmware and the chosen gripper revision remains unresolved. The vendor selects strokes of 55/105/155 mm yet also lists 50–150 mm in its specifications. Confirm the selected usable travel rather than interpreting rail length as stroke. [1] [8]
The cited repository licenses do not establish a complete revision-matched electronics, firmware and software source set for the assembled offer. [1] [2]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 549b5352f3d888b658dbb2776a0b480cb371748b; V1.1 repository; README still labels beta; 100/150/200 mm rails and 21.5/40/60 mm motors
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-S-2.0 Mechanical repository CERN-OHL-S-2.0; separately preserved STEPFOC firmware GPL-3.0. [1] [2] [3] [4] [5] [6] [7] [8] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] [7] [8] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] [7] [8] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] [7] [8] |
| documentation | available · CERN-OHL-S-2.0 Mechanical repository CERN-OHL-S-2.0; separately preserved STEPFOC firmware GPL-3.0. [1] [2] [3] [4] [5] [6] [7] [8] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
Design limits and source rights
V1.1 assembly manual is an unfinished placeholder; resolve actual stroke and firmware match. The vendor describes the assembled product as a pre-release. It explicitly excludes jaws, which must be printed or bought separately, and requires an additional cable for PAROL6. Separately, this review has not verified a complete operating setup. [1] [2] [3] [4] [5] [6] [7] [8]
Mechanical repository CERN-OHL-S-2.0; separately preserved STEPFOC firmware GPL-3.0. [1] [2] [3] [4] [5] [6] [7] [8]
This is a source-researched design profile. We have not assembled or tested this configuration; no complete current setup price is established. The preserved assembled-offer endpoints are EUR 714.00 for 55 mm stroke with a 21.5 mm motor and EUR 892.50 for 155 mm stroke with a 60 mm motor. These are offer prices, not DIY estimates. Shipping is calculated at checkout; jaws, the PAROL6 cable and applicable import charges require separate accounting. [8]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Source-Robotics/MSG-compliant-AI-stepper-gripper: README.md
Revision, date & where cited
github.com · revision
549b535· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 4 more - S002 Source-Robotics/MSG-compliant-AI-stepper-gripper: LICENSE
Revision, date & where cited
github.com · revision
549b535· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 3 more - S003 Source-Robotics/MSG-compliant-AI-stepper-gripper: files
Revision, date & where cited
github.com · revision
549b535· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S004 bom
Revision, date & where cited
github.com · revision
549b535· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S005 manual_status
Revision, date & where cited
github.com · revision
549b535· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S006 firmware
Revision, date & where cited
github.com · revision
46b4911· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S007 firmware_license
Revision, date & where cited
github.com · revision
46b4911· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S008 offer
Revision, date & where cited
Source-Robotics / project contributors · source-robotics.com · text.txt · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 3 more - S013 Upstream image and reuse attribution
Media-only review: Upstream illustration of the MSG compliant gripper, not a photograph. Reuse basis: CERN-OHL-S-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Source Robotics and MSG contributors · github.com · revision
549b535· Image SHA-256 3b8ee47f4cd52f14191e6a29ac60c6b0799dd142677088d853ce4367d8d3d19b; repository · Accessed Oct 25, 2026
Videos
- S009 Source Robotics (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Source Robotics · youtube.com · Accessed Oct 4, 2026
- S010 SSG-48 3D printed gripper assembly (YouTube video)
Video from the project’s own channel (Source Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Source Robotics · youtube.com · Accessed Oct 4, 2026
- S011 MSG 3D Printed Gripper Assembly tutorial (YouTube video)
Video from the project’s own channel (Source Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Source Robotics · youtube.com · Accessed Oct 4, 2026
- S012 MSG Gripper and PAROL6 robotic arm (YouTube video)
Video from the project’s own channel (Source Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Source Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 4 YouTube reference(s) (S009, S010, S011, S012): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.