Mini Pupper
Robot / hardware buildOriginal Mini Pupper quadruped with twelve custom servos, Raspberry Pi hardware and separate movement/ROS stacks; hardware generation, image and calibration route must be matched. [1]
Build & first use →Official websiteBill of materials
- For
- Learners and developers prepared to match kit revision, operating-system image and calibration instructions [1]
- Cost
- No current cost yet. Upstream bill of materials [8]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for mechanical design, documentation · Details by part
Overview
This entry covers the original Mini Pupper, not Mini Pupper 2. The linked BOM names twelve custom servos, a Raspberry Pi 4B/2GB, custom PCBA, display hardware and a 7.4 V battery. Its custom parts are part of the build requirements; a generic small servo should not be assumed equivalent. [8]
Is this for you?
- Known limitations
- Original hardware and Mini Pupper 2 use distinct board support
- Historical setup clones moving branches rather than a fully pinned dependency set
- Current BSP calls ROS 1 end-of-life; historical ROS 1 scripts remain in old release
- Complete hardware reuse terms and current delivered build cost not established
- No installation, calibration or locomotion test performed
Evidence boundaries, not reproduced behavior.
3D preview
Original Mini Pupper simulation assembly. The original Mini Pupper source ROS description at zero joint positions, with its optional camera disabled as supplied. It does not represent Mini Pupper 2 or verify physical fit.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: MangDang contributors, revision c3ad28ce3b368fce8c9eb11dca203332bc753a83. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Upstream bill of materials [8]
- Hardware configuration
Original Mini Pupper four-legged robot; not the Mini Pupper 2 configuration.
- Actuators
- Twelve custom Mini Pupper servos; BOM recommends spare servos separately
- Controller
Raspberry Pi 4B/2GB with custom PCBA, display hardware and microSD in the linked original BOM.
- Power
Original BOM lists a custom 1000 mAh, 7.4 V Li-polymer battery.
Reference BOM specification, not a tested replacement recommendation.
Assembly & first use
- Assembly
Illustrated original-model guide covers legs, hips, body and covers, and distinguishes printed parts from molded body/hip parts introduced after April 15, 2022.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Hardware evidence spans more than one revision
The original-model assembly guide distinguishes older printed body and hip parts from molded parts introduced after April 15, 2022. It provides illustrated leg, hip, frame and cover assembly sections. The design page links a BOM and external CAD, while the inspected Drive folder lists an STL package, STEP/Fusion files and accessory mounts. No geometry or complete manufacturing validation was performed. [5] [6] [9]
The BOM's displayed total is $755.71 and its print-service prices are explicitly references. It groups basic, research and complete-kit components and includes historical vendor links. This is not a current delivered quote or proof that every listed part is currently available. [8]
Preserve the distinction between release and current guidance
The selected main-repository release is v1.0.1. Its README describes ROS 1/Focal and Stanford or ROS 2/Jammy routes, with ROS 2 marked experimental. Its v1 ROS 2 installer requires Jammy, clones external repositories, imports further dependencies and disables heavy Gazebo/navigation packages on the Pi build. It is not a self-contained, fully pinned software distribution. [1] [2] [11]
A separately preserved main-branch snapshot recommends checking basic functions with a non-ROS image before moving to ROS and distinguishes original and v2 board-support repositories. The current original-model BSP overview names Ubuntu 22.04/24.04 and says ROS 1 is no longer supported. Those newer statements should not be read back into the old release as if its scripts had been updated or tested here. [10] [12]
The original calibration guide explicitly marks its desktop leg-calibration procedure as not for the ROS image, and warns that incorrect servo-horn placement can damage a servo. The current BSP has separate GUI/CLI calibration guidance. Choose instructions for the actual hardware and image; no calibration or movement was performed by this catalog. [7] [12]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: host computer, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Listed STL package, STEP/Fusion files and accessory parts; exact external reuse license and geometry completeness not established. [5] [9] |
| electronics | not found · License not fully assessed Custom PCBA/servo and host BSP are identified, but a complete matched board-manufacturing and servo-firmware source set is not established by this review. [8] [12] [13] |
| firmware | not found · License not fully assessed Custom PCBA/servo and host BSP are identified, but a complete matched board-manufacturing and servo-firmware source set is not established by this review. [8] [12] [13] |
| software | available · Apache-2.0 Apache 2.0 is scoped to the main setup repository. External BSP declares most source MIT with EEPROM and PWMController as GPL exceptions. Exact GPL versions and file-level coverage require further notice inspection; parent Apache terms are not extended to dependencies. [1] [3] [10] [12] [13] |
| documentation | available · License not fully assessed Versioned source documentation is preserved; explicit documentation reuse grant not established in this review. [5] [6] [7] |
Selected basic movement/ROS configuration does not identify a distributed learned policy or dataset.
Licensing is scoped to the supplied layer
The main setup repository carries Apache 2.0. That does not establish rights for the externally hosted hardware files or every dependency. The BSP README declares most source MIT and explicitly names EEPROM and PWMController as GPL exceptions. Its archive has no license-named file, so exact GPL versions and complete file-level notice coverage remain to be checked; the README declaration is still substantive licensing evidence. Hardware manufacturing, servo firmware and documentation rights still need more precise mapping. [3] [5] [9] [12] [13]
Mini Pupper has substantial assembly and software documentation, but a source-based profile is not a reproduced build. The useful next decision is which original-model hardware revision and supported image to use, followed by checking its exact components and calibration path. [6] [7] [10] [12]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 mangdangroboticsclub/mini_pupper: README.md
Revision, date & where cited
github.com · revision
de7e71a· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Assembly & first use, Preserve the distinction between release and current guidance and 1 more - S002 mangdangroboticsclub/mini_pupper: commit de7e71a
Revision, date & where cited
github.com · Accessed Oct 1, 2026
Used for: Preserve the distinction between release and current guidance, What we checked - S003 mangdangroboticsclub/mini_pupper: LICENSE
Revision, date & where cited
github.com · revision
de7e71a· Accessed Oct 1, 2026
Used for: Source files and licenses - S004 mangdangroboticsclub/mini_pupper: files
Revision, date & where cited
github.com · revision
de7e71a· archive file inventory · Accessed Oct 1, 2026 - S005 Original Mini Pupper docs/reference/Design.rst
Revision, date & where cited
github.com · revision
5eb9f86· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware evidence spans more than one revision, Source files and licenses - S006 Original Mini Pupper docs/guide/Assembly/MiniPupper.rst
Revision, date & where cited
github.com · revision
5eb9f86· Accessed Oct 1, 2026
Used for: Hardware & parts, Assembly & first use, Hardware evidence spans more than one revision, Source files and licenses - S007 Original Mini Pupper docs/guide/SoftwareCalibration.rst
Revision, date & where cited
github.com · revision
5eb9f86· Accessed Oct 1, 2026
Used for: Assembly & first use, Preserve the distinction between release and current guidance, Source files and licenses - S008 MiniPupperBOMList.xlsx
Revision, date & where cited
mangdangroboticsclub / project contributors · docs.google.com · Drive readable text/folder metadata; not a geometry or pricing validation · Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Hardware evidence spans more than one revision, Source files and licenses - S009 3D printed files
Revision, date & where cited
mangdangroboticsclub / project contributors · drive.google.com · Drive readable text/folder metadata; not a geometry or pricing validation · Accessed Oct 1, 2026
Used for: Is this for you?, Hardware evidence spans more than one revision, Source files and licenses - S010 Main repository current branch overview
Revision, date & where cited
github.com · revision
973538b· ; distinct from v1.0.1 · Accessed Oct 1, 2026
Used for: Preserve the distinction between release and current guidance, Source files and licenses - S011 Original v1 ROS 2 setup script
Revision, date & where cited
github.com · revision
de7e71a· v1.0.1 setup; not executed · Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Preserve the distinction between release and current guidance - S012 Current original-hardware BSP overview
Revision, date & where cited
github.com · revision
b208e00· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Assembly & first use, Preserve the distinction between release and current guidance and 1 more - S013 BSP preserved inventory
Revision, date & where cited
github.com · revision
b208e00· Full archive filename inventory; no license-named file found · Accessed Oct 1, 2026
Used for: Source files and licenses - S015 Upstream image and reuse attribution
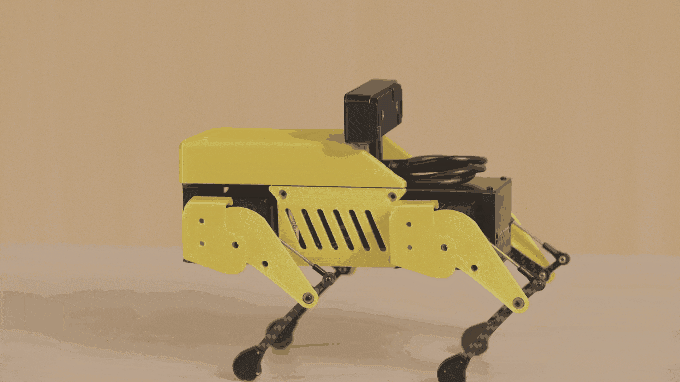
Media-only review: Still from an upstream demonstration: the original Mini Pupper with an added camera module, from MangDang’s OpenCV example. This is a video frame; camera type and software version are not established by the image. Reuse basis: MIT. The creator-authored Hackster project itself displays a copyright MIT notice, rather than relying on a separate software repository license. Its original demonstration is part of that licensed project documentation. The actual displayed OpenCV video URL is the image service MP4 rendition of this same GIF path, preserved in displayed-media.json and a source-page screenshot. The selected frame is an original creator demonstration, not a fan-modification collage, third-party article image or image in the page’s related-project sidebar. Source project credits MangDang and links the actual MangDang QuadrupedRobot source. Although the project page has newer MiniPupper2 content and a mixed-generation hero, those assets are excluded. The selected footage shows the original MiniPupper body, slotted side shell, original leg/frame and RaspberryPi4-era upper assembly matching the original-model guide; the profile explicitly retains earlier printed and later molded original-model hardware. The adjacent story specifies original12 PWM-controlled servos/PCA9685 and distinguishes original2021 MiniPupper from MiniPupper2. Frame60 shows an added small camera; the later OAK-DLite close-up is a different segment and does not prove this frame’s camera model. Caption does not identify hidden controllers, exact subrevision, firmware, software release, gait performance or current availability. No separate media exclusion or third-party credit appears for this own OpenCV example. Full original GIF and all required MIT attribution/permission text retained. Still decoded from zero-based frame 60 of the creator's GIF demonstration and saved to PNG; no cropping or retouching. Full original animation retained. Technical/cost evidence dates unchanged.Revision, date & where cited
MangDang / Mini Pupper project contributors · hackster.io · MangDang creator-authored project, displayed project copyright/license notice PublishedJune2,2021 ©MIT; AI:OpenCV section; original680x382 GIF, zero-based frame60, whole frame unchanged.; image SHA-256 0b80da92ee5988632c6f4eb50adbcaf318100934cd3adf75d54fa5d7acb5f867 · Accessed Oct 26, 2026
Videos
- S014 MangDang (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel MangDang · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S014): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.