GGLDNL Hexapod
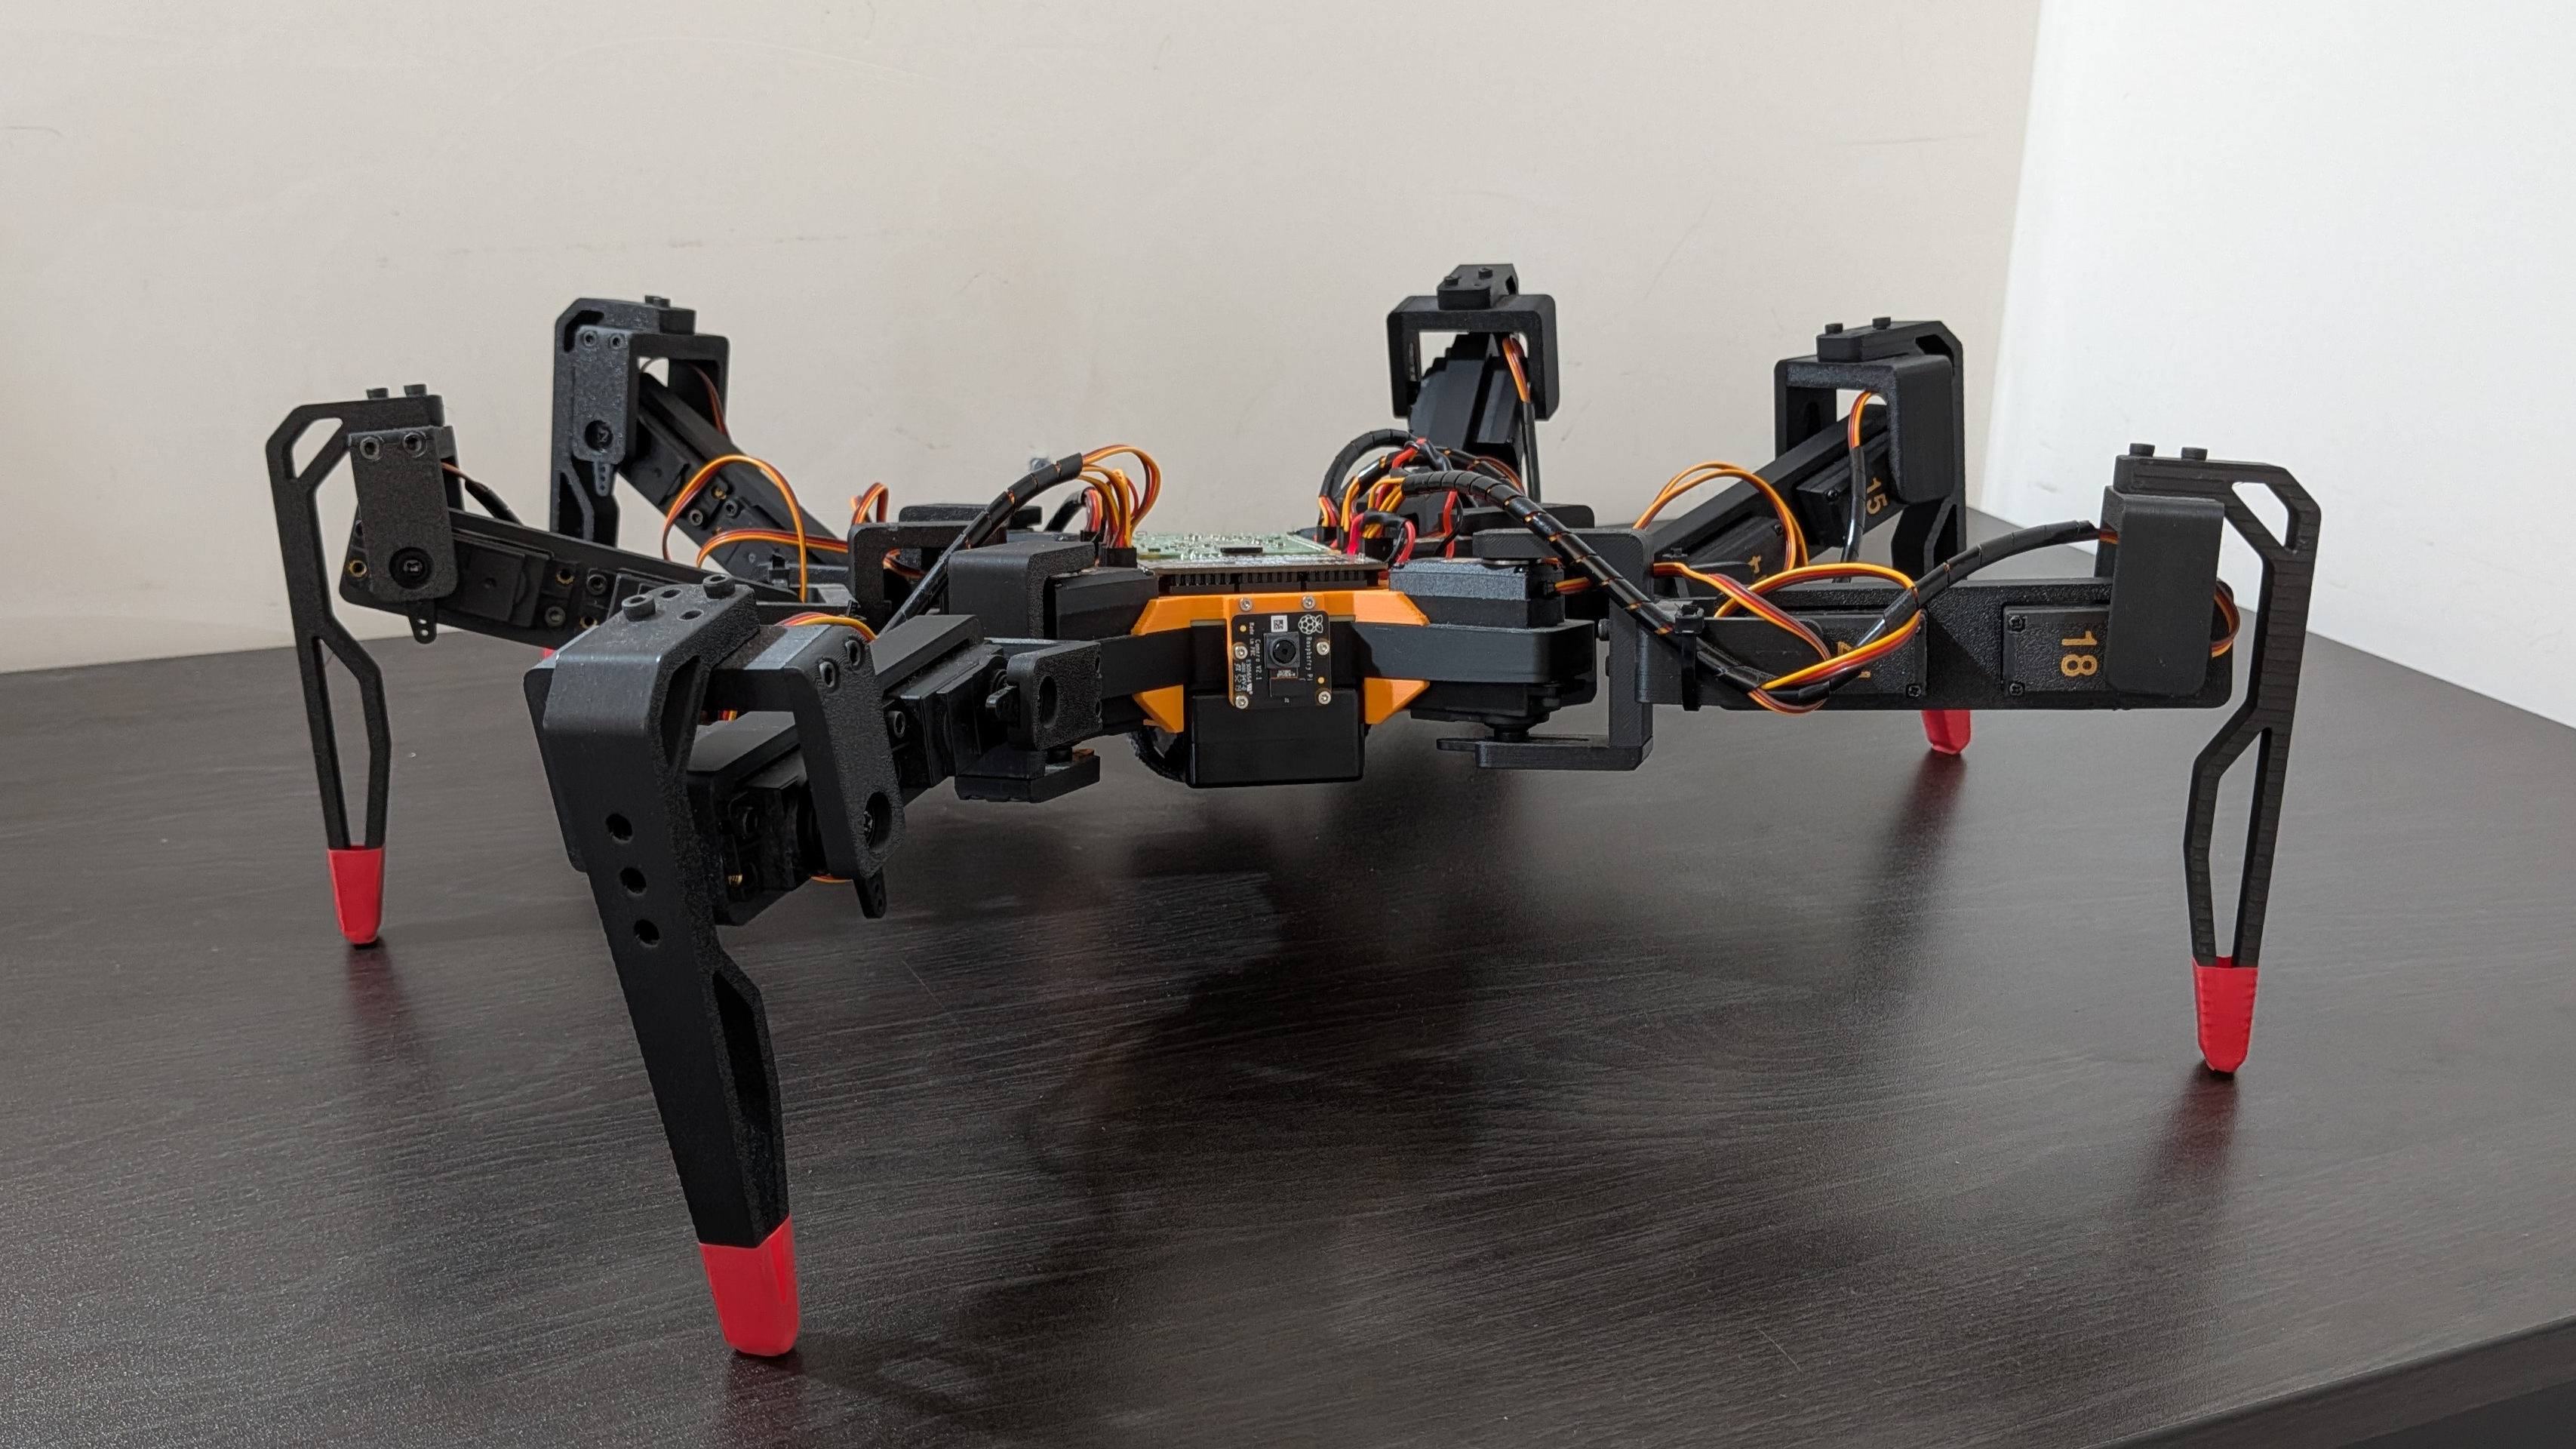
Robot / hardware buildPrinted 18-servo hexapod with separate mechanical designs, Servo2040 firmware and a Raspberry Pi controller. [5] [8] [11]
Build & first use →Official website
- For
- Builders comfortable with printed mechanisms, embedded firmware and Raspberry Pi serial setup [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-W-2.0, GPL-3.0 · license not fully assessed for documentation · Details by part
Overview
GGLDNL's hexapod combines 18 hobby servos, a printed frame, a Servo2040 board and a Raspberry Pi. The main repository is an overview; the mechanical files, embedded control and Python client live in three separate repositories. This profile covers their preserved September 2026 snapshots and the documented no-custom-PCB route. It does not establish a tested release combination. [1] [5] [8] [11]
3D preview
ggldnl hexapod source assembly. Source URDF assembly with six legs and supplied component representations, shown at zero joint positions. Purchased components are visualization geometry, not fabrication files.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: ggldnl / Hexapod contributors, revision f8ee8084d48470283d5ca23394d5a4b9590ad9e8. Original and preview: CERN-OHL-W-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
- Calibration
Measure individual bare-servo pulse endpoints; midpoint is averaged. Joint trims, directions and structural limits remain separate.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Resolve the mechanical count before ordering
The hardware bill of materials lists 18 MG996/MG996R servos, 18 F686ZZ bearings, 92 M3 screws and 92 M3 inserts. Yet its notes call for 12 servo_mod housings while describing one per servo. That conflict remains unresolved: do not turn either count into a verified complete shopping list. The guide also requires top and bottom stiffeners to prevent frame flex. [5]
The archive includes STEP parts and printable STL files. Filenames do not form a complete one-to-one mapping between those formats, and the hardware-shaped STL assets used by the simulation are not parts to print. No geometry, fit or assembly video was inspected. Without the optional PCB, the guide adds an electronics mounting plate, M2 inserts and screws, and servo cable extensions. [5] [7]
The maintainer's approximate €280 total is historical, with an additional €60–70 mentioned for the optional PCB. Those figures are not current checkout quotes and do not establish a delivered first-working budget, including printing, tools, charger and shipping. [5]
Keep logic power and servo power distinct
The BOM specifies a 7.4 V 2S LiPo and two 8 A UBECs. Assembly instructions assign one regulator to the Pi/Servo2040 logic at 5 V and the other to the servo rail, mentioning 6 V subject to the actual servo datasheet. The battery mount is designed around the linked regulator shape; a replacement may require a mechanical change. The guide's alternatives are not verified drop-in substitutions. [5]
The firmware documents UART1 on Servo2040 GP20 TX and GP21 RX, crossed to Raspberry Pi GPIO15 RX and GPIO14 TX, with shared ground. The default link is 921600 baud. The controller guide describes enabling the hardware UART and removing a conflicting serial console. These instructions were read, not applied to a board. [8] [11]
Calibration is not a motionless configuration step
The controller's calibration tool measures each bare servo at minus and plus 90 degrees, computes the midpoint pulse, and writes per-servo triples into the configuration. Structural joint trim, direction and range remain separate. Its “offline” label means separate from the normal robot controller: the raw jog implementation actually energizes the servo rail and drives a selected output even while the state machine is OFF. Calibrate with that behavior understood, rather than interpreting OFF as proof of unpowered servos. [14] [15]
The normal control loop runs on Servo2040: gait generation and inverse kinematics turn high-level commands into joint motion. The Pi provisions configuration and sends setpoints. The active-state watchdog implementation starts a sit-down sequence after the configured command timeout; this is more specific than an instantaneous power cut and has not been physically tested here. [8] [11] [16]
Build dependencies and openness remain layered
The firmware guide uses CMake, an ARM toolchain, the Raspberry Pi Pico SDK and Pimoroni libraries to produce a UF2 image. The Python client needs its serial extra for a real board and its calibration extra for the configuration-writing tool. Ubuntu 24.04 is suggested for a possible later ROS 2 route, but that separate ROS integration and the simulation were not reviewed as working dependencies. [8] [11]
The mechanical repository supplies CERN-OHL-W-2.0 terms; the firmware and controller supply GPL version 3 license texts. Purchased boards, servos and third-party dependencies need their own treatment. The optional PCB is linked but not assessed here. This is source-based build research: no parts were printed, firmware compiled, board flashed, servo calibrated or walking performance measured. [5] [6] [9] [12]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A limitations summary
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Sep 4, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 3c19084e49931cdf4b2ca4ed30d88455ac7cd6e1 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-W-2.0 Selected repository source; external purchased components and dependencies retain their own terms. No geometry, compilation or hardware validation. [5] [6] [7] |
| electronics | not found · License not fully assessed Optional custom PCB is linked separately but not reviewed; selected no-PCB route uses purchased boards and documented wiring. [5] |
| firmware | available · GPL-3.0 Selected repository source; external purchased components and dependencies retain their own terms. No geometry, compilation or hardware validation. [8] [9] [10] |
| software | available · GPL-3.0 Selected repository source; external purchased components and dependencies retain their own terms. No geometry, compilation or hardware validation. [11] [12] [13] |
| documentation | available · License not fully assessed Assembly, firmware and controller guides span three differently licensed repositories; videos and external print profiles not inspected. [5] [8] [11] |
Selected programmed gait and inverse-kinematics route requires no learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 ggldnl/Hexapod: README.md
Revision, date & where cited
github.com · revision
3c19084· Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use - S002 ggldnl/Hexapod: commit 3c19084
- S003 ggldnl/Hexapod: LICENSE.md
Revision, date & where cited
github.com · revision
3c19084· Accessed Oct 1, 2026 - S004 ggldnl/Hexapod: files
Revision, date & where cited
github.com · revision
3c19084· archive file inventory · Accessed Oct 1, 2026 - S005 Hexapod-Hardware README.md
Revision, date & where cited
github.com · revision
f8ee808· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Resolve the mechanical count before ordering and 3 more - S006 Hexapod-Hardware LICENSE.md
Revision, date & where cited
github.com · revision
f8ee808· Accessed Oct 1, 2026
Used for: Build dependencies and openness remain layered, Source files and licenses - S007 Hexapod-Hardware inventory.json
Revision, date & where cited
github.com · revision
f8ee808· Accessed Oct 1, 2026
Used for: Resolve the mechanical count before ordering, Source files and licenses - S008 Hexapod-Firmware README.md
Revision, date & where cited
github.com · revision
82d94e0· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Keep logic power and servo power distinct and 3 more - S009 Hexapod-Firmware LICENSE.md
Revision, date & where cited
github.com · revision
82d94e0· Accessed Oct 1, 2026
Used for: Build dependencies and openness remain layered, Source files and licenses - S010 Hexapod-Firmware inventory.json
Revision, date & where cited
github.com · revision
82d94e0· Accessed Oct 1, 2026
Used for: Source files and licenses - S011 Hexapod-Controller README.md
Revision, date & where cited
github.com · revision
0f68c0c· Accessed Oct 1, 2026
Used for: Overview, What you need, Keep logic power and servo power distinct, Calibration is not a motionless configuration step and 2 more - S012 Hexapod-Controller LICENSE.md
Revision, date & where cited
github.com · revision
0f68c0c· Accessed Oct 1, 2026
Used for: Build dependencies and openness remain layered, Source files and licenses - S013 Hexapod-Controller inventory.json
Revision, date & where cited
github.com · revision
0f68c0c· Accessed Oct 1, 2026
Used for: Source files and licenses - S014 Calibration tool scope
Revision, date & where cited
github.com · revision
0f68c0c· lines 1–35 · Accessed Oct 1, 2026
Used for: Assembly & first use, Calibration is not a motionless configuration step - S015 Raw calibration jog implementation
Revision, date & where cited
github.com · revision
82d94e0· lines 150–177 · Accessed Oct 1, 2026
Used for: Calibration is not a motionless configuration step - S016 Active-state watchdog
Revision, date & where cited
github.com · revision
82d94e0· lines 240–255 · Accessed Oct 1, 2026
Used for: Calibration is not a motionless configuration step - S017 Upstream image and reuse attribution
Media-only review: Upstream photograph of the assembled six-legged robot. Reuse basis: GPL-3.0; inspected LICENSE.md and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
ggldnl and Hexapod contributors · github.com · revision
3c19084· Image SHA-256 9a904e5e10432811dc5c71f572ba55a608db27a479b337f6e9eb32840c953bf8; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.