TipTap
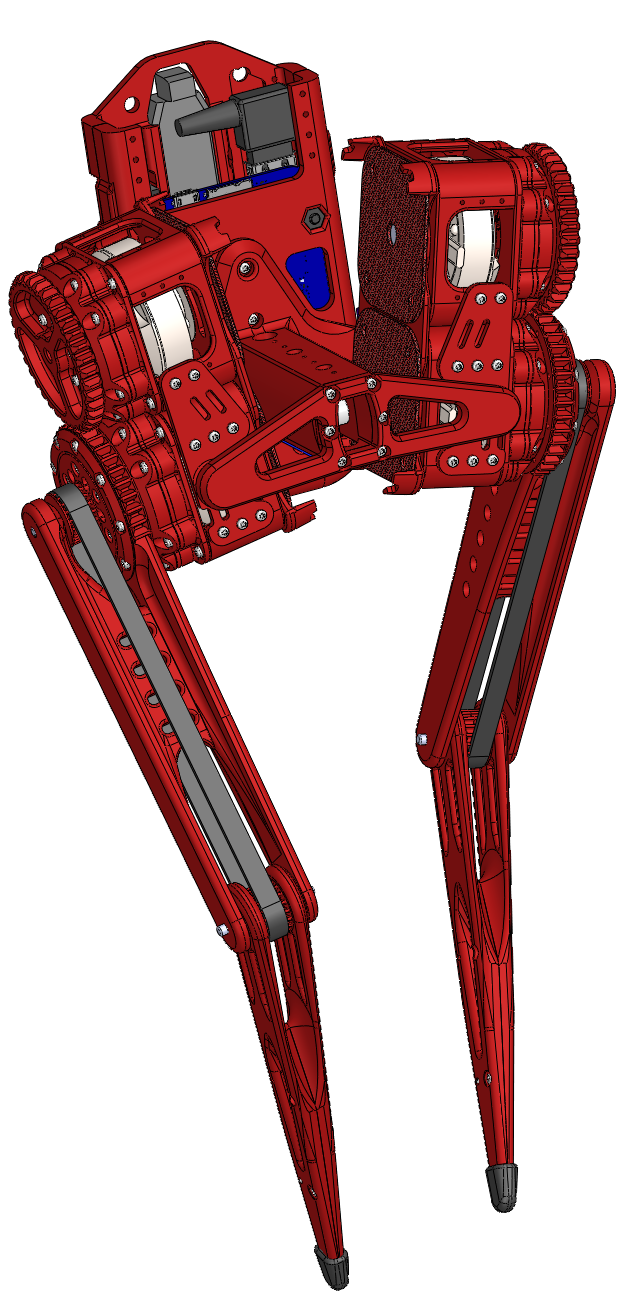
Robot / hardware buildPrinted desktop biped with four custom torque actuators, two positioning servos and a shared Python simulation/hardware interface; controller-source licensing remains unresolved. [1]
Build & first use →Official websiteBill of materials
- For
- Researchers able to manufacture custom actuators and commission embedded motor controllers [1]
- Cost
- No current cost yet. Upstream bill of materials [1]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for electronics, firmware · Details by part
Overview
TipTap is a printed biped intended for desktop walking research. Its Python interface exposes four torque-controlled hip/knee joints and two position-controlled leg servos. The main parts list therefore includes four custom TipTapMotor assemblies as well as two MG92B servos; the motor assemblies are a separate manufacturing task, not four ordinary hobby servos. [1] [5] [9]
Is this for you?
- Known limitations
- rcpy availability selects hardware mode; this is not physical robot detection
- DirectServo board and whole-firmware reuse license not established
- Historical component sourcing, full build cost and current toolchain compatibility not verified
- No simulation run, motor command or walking test performed
Editorial boundaries from inspected sources.
3D preview
TipTap simplified simulation model. Source URDF uses simplified boxes and cylinders, not detailed manufacturing geometry. Links are shown at zero joint positions.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Darren Levine, revision cffe3678b567bb797f57d71d59a13a479c2b3433. Original and preview: MIT. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Upstream bill of materials [1]
- Controller
BeagleBone Blue host, USB-RS485 adapter and DirectServo boards in the four custom actuators.
- Sensors
- DirectServo magnetic motor-angle sensing
- BeagleBone MPU9250 initialization in the hardware branch
Code/source evidence only; no sensor commissioning performed.
- Degrees of freedom
6
Four torque-controlled hip/knee joints plus two position-controlled leg servos in the interface.
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Follow the actuator dependency through to the controller
The robot README lists printed parts, bearings, timing belts, a BeagleBone Blue, power conversion and a USB-RS485 adapter, with assembly-reference images. TipTapMotor adds printed gearbox parts, an iPower GBM3506H-130T motor, bearings, an encoder magnet and a DirectServo PCB. Printing tolerances matter for the gears, according to its instructions. [1] [9]
DirectServo's manufacturing folder supplies named Gerber, BOM and component-position artifacts; its instructions also identify manually assembled parts. Programming guidance targets STM32F031C6Tx, then points to USB-RS485 testing examples. Those are concrete source artifacts, but no PCB fabrication, firmware build or complete robot assembly was reproduced here. A current full build budget and component availability remain unverified. [13] [14]
Shared calls do not mean automatic physical detection
The documented attraction is a common interface for PyBullet and hardware. In the actual implementation, the presence of the rcpy Python module chooses the hardware branch; otherwise the module imports PyBullet. It does not first verify that a physical robot is connected. The hardware branch uses a fixed serial-device name and motor IDs, while pyds imports serial and supplies calibration, zero-angle and torque commands. These dependencies and configuration choices need review before running the examples on hardware. [5] [6]
The README names Python 3.5 or newer, NumPy and PyBullet; the hardware route additionally needs rcpy and the serial interface. Servo calibration constants are present in the implementation. Neither current environment compatibility nor successful motion follows from the shared API design, and no simulation or walking result was reproduced in this review. [1] [5] [6] [7]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Oct 5, 2020 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- cffe3678b567bb797f57d71d59a13a479c2b3433 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Main TipTap repository MIT; separate TipTapMotor repository also declares MIT. DirectServo licensing is assessed separately. [1] [3] [8] |
| electronics | available · License not fully assessed DirectServo archive contains board/firmware artifacts but no root license in its inventory. ST system-file BSD-style notice is scoped to that file and does not establish a complete board or firmware grant. [12] [13] [14] [15] |
| firmware | available · License not fully assessed DirectServo archive contains board/firmware artifacts but no root license in its inventory. ST system-file BSD-style notice is scoped to that file and does not establish a complete board or firmware grant. [12] [13] [14] [15] |
| software | available · MIT Main TipTap repository MIT; separate TipTapMotor repository also declares MIT. DirectServo licensing is assessed separately. [1] [3] [8] |
| documentation | available · MIT Main TipTap repository MIT; separate TipTapMotor repository also declares MIT. DirectServo licensing is assessed separately. [1] [3] [8] |
Selected interface/control examples do not require learned weights or a dataset.
Licensing differs across the stack
TipTap and TipTapMotor each contain an MIT license. DirectServo's preserved archive has board and firmware sources but no root license file in its inventory. A bundled ST system file has its own BSD-style notice, which does not establish the license of the whole controller or board. The catalog therefore records that dependency's reuse terms as unresolved instead of extending TipTap's MIT license across repositories. [3] [10] [14] [15]
TipTap is a useful partial-source research platform with unusually explicit actuator dependencies. Its remaining work is to confirm controller rights, match a buildable toolchain and parts configuration, and commission the hardware; it is not catalog-qualified as a ready-to-run kit. [1] [9] [13] [14]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 DarrenLevine/TipTap: README.md
Revision, date & where cited
github.com · revision
cffe367· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 3 more - S002 DarrenLevine/TipTap: commit cffe367
- S003 DarrenLevine/TipTap: LICENSE
Revision, date & where cited
github.com · revision
cffe367· Accessed Oct 1, 2026
Used for: Source files and licenses - S004 DarrenLevine/TipTap: files
Revision, date & where cited
github.com · revision
cffe367· archive file inventory · Accessed Oct 1, 2026 - S005 Pinned software/tiptap.py
Revision, date & where cited
github.com · revision
cffe367· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S006 Pinned software/pyds.py
Revision, date & where cited
github.com · revision
cffe367· Accessed Oct 1, 2026
Used for: What you need, Assembly & first use, Shared calls do not mean automatic physical detection - S007 Pinned software/example_OperatingTipTap.py
Revision, date & where cited
github.com · revision
cffe367· Accessed Oct 1, 2026
Used for: Shared calls do not mean automatic physical detection - S008 Pinned TipTap filenames
Revision, date & where cited
github.com · revision
cffe367· Complete archive inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S009 TipTapMotor overview
Revision, date & where cited
github.com · revision
1e1361d· Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Follow the actuator dependency through to the controller and 1 more - S010 TipTapMotor license
Revision, date & where cited
github.com · revision
1e1361d· Accessed Oct 1, 2026
Used for: Source files and licenses - S011 TipTapMotor preservation and inventory
Revision, date & where cited
github.com · revision
1e1361d· Accessed Oct 1, 2026 - S012 DirectServo overview
Revision, date & where cited
github.com · revision
01ffecc· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware & parts, Source files and licenses - S013 DirectServo manufacturing instructions
Revision, date & where cited
github.com · revision
01ffecc· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Assembly & first use, Follow the actuator dependency through to the controller and 1 more - S014 DirectServo preservation and inventory
Revision, date & where cited
github.com · revision
01ffecc· Accessed Oct 1, 2026
Used for: Is this for you?, Follow the actuator dependency through to the controller, Source files and licenses - S015 DirectServo ST system-file notice
Revision, date & where cited
github.com · revision
01ffecc· File-specific BSD-style notice, not a whole-project grant · Accessed Oct 1, 2026
Used for: Is this for you?, Source files and licenses - S016 Upstream image and reuse attribution
Media-only review: Upstream illustration of the TipTap biped assembly, not a photograph. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Darren Levine and TipTap contributors · github.com · revision
cffe367· Image SHA-256 b4c5976c7dcffeeb3beab495dd4e59b478251cef47b57d788c8390eed08fbf1b; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.