OpenScout
Robot / hardware buildFour-wheel mobile base built from aluminum extrusions, with a documented articulated chassis, radio control and encoder-based motor control. [1] [5] [9]
Build & first use →Official websiteBill of materials
- For
- Builders comfortable with mechanical assembly, Arduino wiring and motor tuning [1]
- Cost
- No current cost yet. Upstream bill of materials [5]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- GPL-3.0-only · license not fully assessed for mechanical design, electronics, documentation · Details by part
Overview
OpenScout supplies a modular four-wheel chassis and radio-controlled differential drive. This review selects the documented configuration with front and rear frames joined by a lazy Susan bearing. The preserved v1.0.0 source describes ROS, ROS 2 and Gazebo integration as future work; those are not treated here as working features of the release. [1] [2] [5]
Is this for you?
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The STEP assembly includes vendor-numbered fastener models. Their separate permission for redistribution has not been established, so the project hardware license alone does not clear this complete download.
Model sources
The STEP assembly includes vendor-numbered fastener models. Their separate permission for redistribution has not been established, so the project hardware license alone does not clear this complete download.
Project notes
Choose a chassis before pricing it
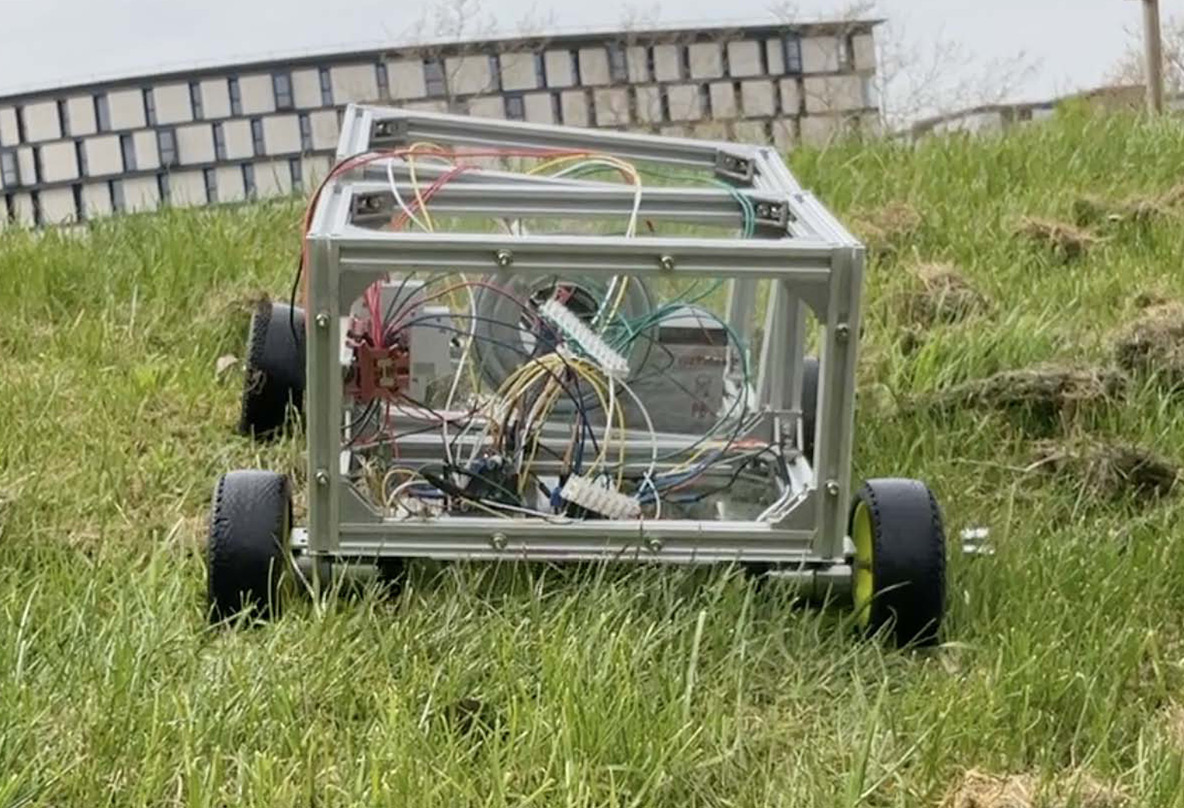
The build uses 20 × 20 mm aluminum extrusions in 200 mm and 300 mm lengths, acrylic panels and a revolute hinge. Its instructions list four 90:1, 12 V geared motors with encoders, 112 mm wheels and their adapters. The complete parts list depends on that configuration; changing the frame or drive components changes the build rather than merely changing its appearance. [1] [5]
Upstream's $350 headline and 15 kg payload figure are project claims, not a current quotation or a load test performed for this profile. The detailed parts list still leaves some fastener information and wire or breadboard quantities unspecified. A delivered budget needs those gaps resolved, as well as current prices, fabrication and shipping. [1] [5]
STEP assemblies, DXF panel files and an illustrated assembly manual are present in the preserved archive. This establishes available design artifacts, not verified dimensions, successful machining or fit. The selected hardware guide is the starting point for assembling a configuration-specific checklist. [4] [5] [12]
Match the wiring to the controller
The electronics route uses an Arduino Mega, two L298N motor drivers, a radio receiver, a 12 V lead-acid battery, a 10 A circuit breaker and a buck converter. The overview calls for the Mega because the encoders and receiver need enough interrupt inputs. The wiring guide gives motor lead colors, receiver channel pins and separate front and rear driver connections. [1] [6]
The upload guide points to Software/simple_pid.ino in Arduino IDE. That sketch samples encoder counts and uses a per-motor PID controller to drive the wheels. Its geometry, encoder-count conversion and receiver pulse limits are fixed values in source, so alternate motors or a resized frame require checking those values before assuming equivalent behavior. No firmware upload or radio-control test was performed here. [8] [9]
Reconcile the PID instructions with the sketch
The tuning guide describes comparing target and actual motor speed in the Arduino serial plotter and adjusting proportional, integral and derivative gains. It reports a derivative gain of 1 for the authors' implementation. The active sketch instead defines DGAIN as 0.015 and passes that value into each motor controller during setup. The constructor's default derivative value of 1 is overwritten there. [7] [9]
The sketch also actively prints throttle and steering values, while the target and measured wheel-speed print statements are commented out. Its serial output therefore needs adjustment before it can supply the speed comparison described in the tuning guide. That adjustment was not made or tested here. [7] [9]
These are distinct source values, not interchangeable recommended settings. A builder should retain the selected sketch revision, confirm the physical wheel and encoder configuration, and tune against the documented measurements. This review identifies the discrepancy but does not establish which gain works on a particular build. [7] [9]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed STEP, DXF and assembly instructions present. CERN-OHL-W-2.0 is bundled, but the root overview lists several licenses without a precise per-artifact map. [1] [4] [10] |
| electronics | available · License not fully assessed Integration schematics present; purchased boards and motors are separate. Exact license allocation across artifacts not resolved. [4] [6] [10] |
| firmware | available · GPL-3.0-only GPL v3 is stated at project level; the same Arduino sketch is the robot control software/firmware. No claim that this licenses external boards or toolchains. [1] [3] [9] |
| software | available · GPL-3.0-only GPL v3 is stated at project level; the same Arduino sketch is the robot control software/firmware. No claim that this licenses external boards or toolchains. [1] [3] [9] |
| documentation | available · License not fully assessed CC BY-SA 2.0 text is bundled; root lists GPL v3, CERN-OHL-W and CC BY-SA without an explicit per-document allocation. [1] [4] [11] |
Selected radio-controlled motor-control build does not use a learned policy or dataset.
Several licenses need a clearer artifact map
The overview lists GPL v3, CERN-OHL-W and CC BY-SA. The preserved files contain GPL v3, CERN-OHL-W version 2 and CC BY-SA 2.0 texts. The hardware license file is actually named OSH LICENSE, although the README's link targets LICENCE. The source therefore preserves the terms even where that relative link is wrong. [1] [3] [4] [10] [11]
The overview does not precisely allocate all three licenses to individual mechanical, electronics and documentation artifacts. Those layers retain an explicit licensing gap in this profile. Purchased components and external tooling also remain separate from the project source. No assembly, electrical, tuning, terrain or payload test is claimed. [1] [4] [5]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 cbedio/OpenScout: README.md
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S002 cbedio/OpenScout: commit 26346a3
- S003 cbedio/OpenScout: LICENSE
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: Source files and licenses - S004 cbedio/OpenScout: files
Revision, date & where cited
github.com · revision
26346a3· archive file inventory · Accessed Oct 1, 2026
Used for: Choose a chassis before pricing it, Source files and licenses - S005 OpenScout: Hardware/robot_with_lazy_susan_bearing/README.md
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 OpenScout: Hardware/robot_with_lazy_susan_bearing/circuit_assembly_instructions.md
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Match the wiring to the controller and 1 more - S007 OpenScout: Hardware/robot_with_lazy_susan_bearing/pid_calibration.md
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Assembly & first use, Reconcile the PID instructions with the sketch - S008 OpenScout: Software/README.md
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: What you need, Match the wiring to the controller - S009 OpenScout: Software/simple_pid.ino
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, Match the wiring to the controller, Reconcile the PID instructions with the sketch and 1 more - S010 OpenScout license: OSH LICENSE
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: Source files and licenses - S011 OpenScout license: CC-BY-SA_LICENCE
Revision, date & where cited
github.com · revision
26346a3· Accessed Oct 1, 2026
Used for: Source files and licenses - S012 OpenScout CAD artifact paths
Revision, date & where cited
github.com · revision
26346a3· Pinned archive paths · Accessed Oct 1, 2026
Used for: Choose a chassis before pricing it - S013 Upstream image and reuse attribution
Media-only review: Upstream paper photograph of OpenScout traversing a grassy incline (Figure 1, 2023 platform). Reuse basis: CC-BY-4.0. Inspected the source image, its caption and the actual reuse declaration; no image-specific exception or different credit was found for this selected image. The grant is used only for this media, not as a new hardware/software license. Embedded image extracted from page 3 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
Samuel J. Carter, Nikolaos C. Tsagkopoulos, Garry Clawson and Charles Fox · doi.org · Version of record, Figure 1 / PDF page 3; image SHA-256 2bc2d59a7ef287695552ebe1cbc9586d9e3fff16ab909259253980a67569de77 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.