OpenMANIPULATOR-X
Robot / hardware buildA four-joint DYNAMIXEL arm with a separate gripper axis, documented for PC-based ROS control or standalone OpenCR operation. [1]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- ROS developers; Robotics educators [1]
- Source rights
- Some licenses are unresolved. Review licenses
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- Ecosystem
- ROS 2
- License
- Apache-2.0 · license not fully assessed for mechanical design, documentation · Details by part
Overview
OpenMANIPULATOR-X RM-X52-TNM is a compact DYNAMIXEL arm for learning and developing manipulation workflows. Its five-axis specification includes one gripper axis: there are four arm joints, which matters when choosing tasks that need a particular tool orientation. The official parts list calls for five XM430-W350-T actuators. This entry covers X; the shared software repository also documents OMY, which is a different platform. [1] [5] [6] [7]
Is this for you?
3D preview
OpenMANIPULATOR-X simulation assembly. The official OpenMANIPULATOR-X robot-description model at zero joint positions. Source meshes and coupled gripper links are retained; this is not a verified manufacturing package.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: ROBOTIS, revision d31000d90c679af9c982e73de8b12d777c5ff7dd. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Operating system
- ROS 2 Jazzy: Ubuntu 24.04
- ROS 2 Humble: Ubuntu 22.04; separate branch/instructions
- Dependencies
- Select the matching ROS distribution and package branches
- DynamixelSDK, dynamixel_interfaces and dynamixel_hardware_interface
- Pinned Dockerfile also fetches robotis_interfaces and other dependencies from separate repositories
Hardware & parts
Upstream bill of materials [5] [6] [7] [8] [9]
Assembly & first use
Open the upstream getting-started guide [5] [6] [7] [8] [9] · Project documentation [5] [6] [7] [8] [9]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Choose the control route before buying accessories
For ROS control, the PC runs the controller and communicates through a U2D2 with power hub, or through an OpenCR configured as a USB-to-DYNAMIXEL interface. OpenCR can alternatively run a standalone Arduino program. Those are different setups, even though both mention OpenCR. The quick start recommends a 12 V, 5 A supply; the product overview says the base plate is not included. Account for the interface, power and mounting arrangement when comparing an arm-only price with a working setup. No current complete delivered budget is verified here. [5] [8]
The unassembled kit also requires mechanical work. The assembly page supplies component quantities and lists a screwdriver and 1.5, 2.0 and 2.5 mm wrenches. It links CAD separately through Onshape and Thingiverse. Those links establish a manufacturing-source route, but we have not yet preserved and reconciled that editable design pack or its license; visualization meshes in the ROS archive do not resolve that gap. [4] [7]
Keep software versions and dependencies together
The e-Manual separates Jazzy on Ubuntu 24.04 from Humble on Ubuntu 22.04. Its Jazzy route includes DYNAMIXEL SDK and interface repositories, dependency installation, a workspace build and USB permissions. The preserved OpenMANIPULATOR package release is 5.1.3. Its Dockerfile uses Jazzy but still clones several moving branch heads, so preserving this one release does not produce a fully locked environment. [2] [8] [9]
The inspected ROS package license is Apache 2.0. That does not establish manufacturing rights or firmware availability for every purchased actuator and interface. Our next reproduction would need an exact X hardware configuration, pinned dependencies and a verified controller startup; no installation, assembly or motion test has been performed for this profile. [3] [8] [9]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A step-by-step setup summary
Updates
- Upstream last updated
- Sep 28, 2026 [2]
- Latest release
- Sep 28, 2026 [2]
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- d31000d90c679af9c982e73de8b12d777c5ff7dd (ROS package release 5.1.3); OpenMANIPULATOR-X e-Manual checked separately. Dependency branch heads and manufacturing CAD are not a locked complete build. · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Official page links separate Onshape/Thingiverse CAD. Editable manufacturing files and their exact license were not acquired/verified in this review; repository visualization meshes are not asserted to be a full print pack. [7] |
| electronics | not found · License not fully assessed Complete layer not established in this ROS archive. OpenCR and purchased DYNAMIXEL components require separate artifact and revision review. [4] [8] |
| firmware | not found · License not fully assessed Complete layer not established in this ROS archive. OpenCR and purchased DYNAMIXEL components require separate artifact and revision review. [4] [8] |
| software | available · Apache-2.0 Applies to the inspected package repository; external dependencies have their own terms. [3] [4] |
| documentation | available · License not fully assessed Public e-Manual; reuse license for these pages not established in this review. [5] [7] [8] |
The reviewed X arm configuration does not select a learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 ROBOTIS-GIT/open_manipulator: README.md
- S002 ROBOTIS-GIT/open_manipulator: commit d31000d
Revision, date & where cited
github.com · Accessed Sep 30, 2026
Used for: Keep software versions and dependencies together, What we checked - S003 ROBOTIS-GIT/open_manipulator: LICENSE
Revision, date & where cited
github.com · revision
d31000d· Accessed Sep 30, 2026
Used for: Keep software versions and dependencies together, Source files and licenses - S004 ROBOTIS-GIT/open_manipulator: files
Revision, date & where cited
github.com · revision
d31000d· archive file inventory · Accessed Sep 30, 2026
Used for: Choose the control route before buying accessories, Source files and licenses - S005 ROBOTIS OpenMANIPULATOR-X overview
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · ROBOTIS e-Manual; distro tabs distinguished in prose · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 ROBOTIS OpenMANIPULATOR-X specification
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · ROBOTIS e-Manual; distro tabs distinguished in prose · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 1 more - S007 ROBOTIS OpenMANIPULATOR-X assembly
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · ROBOTIS e-Manual; distro tabs distinguished in prose · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S008 ROBOTIS OpenMANIPULATOR-X quick start guide
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · ROBOTIS e-Manual; distro tabs distinguished in prose · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S009 Pinned dependency and container definitions
Revision, date & where cited
github.com · revision
d31000d· Dockerfile, dependency list and bringup package · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 1 more - S015 Upstream image and reuse attribution
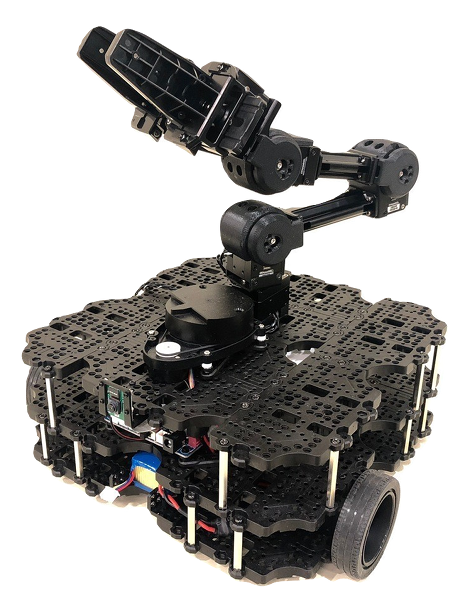
Media-only review: Upstream documentation photograph of OpenMANIPULATOR-X mounted on a TurtleBot3 Waffle Pi base; the mobile base is additional hardware. Reuse basis: CC-BY-4.0. The TurtleBot3 manipulation page identifies TB3 & OpenMANIPULATOR-X. The image shows the four-joint black DYNAMIXEL arm and gripper on a separate Waffle Pi mobile base. Caption distinguishes the arm from the extra base. Source page is inside the explicitly CC BY 4.0 TurtleBot3 documentation; no inference from software license. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
ROBOTIS / TurtleBot3 documentation contributors · emanual.robotis.com · Manipulation > Hardware Assembly, hardware_setup.png; image SHA-256 d9f0c8c80367b6adde6e1b8810dbdb432477863f2b09d807d154b760531f8636 · Accessed Oct 26, 2026
Videos
- S010 ROBOTIS OpenSourceTeam (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel ROBOTIS OpenSourceTeam · youtube.com · Accessed Oct 4, 2026
- S011 ROBOTIS (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel ROBOTIS · youtube.com · Accessed Oct 4, 2026
- S012 OpenManipulator 01 : Chain (YouTube video)
Video from the project’s own channel (ROBOTIS OpenSourceTeam), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ROBOTIS OpenSourceTeam · youtube.com · Accessed Oct 4, 2026
- S013 OpenManipulator 03 : Assembling the OpenManipulator (YouTube video)
Video from the project’s own channel (ROBOTIS OpenSourceTeam), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ROBOTIS OpenSourceTeam · youtube.com · Accessed Oct 4, 2026
- S014 OpenManipulator 05 : Manipulation with OpenCR (YouTube video)
Video from the project’s own channel (ROBOTIS OpenSourceTeam), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ROBOTIS OpenSourceTeam · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 5 YouTube reference(s) (S010, S011, S012, S013, S014): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.