MABEL Mobile Manipulator
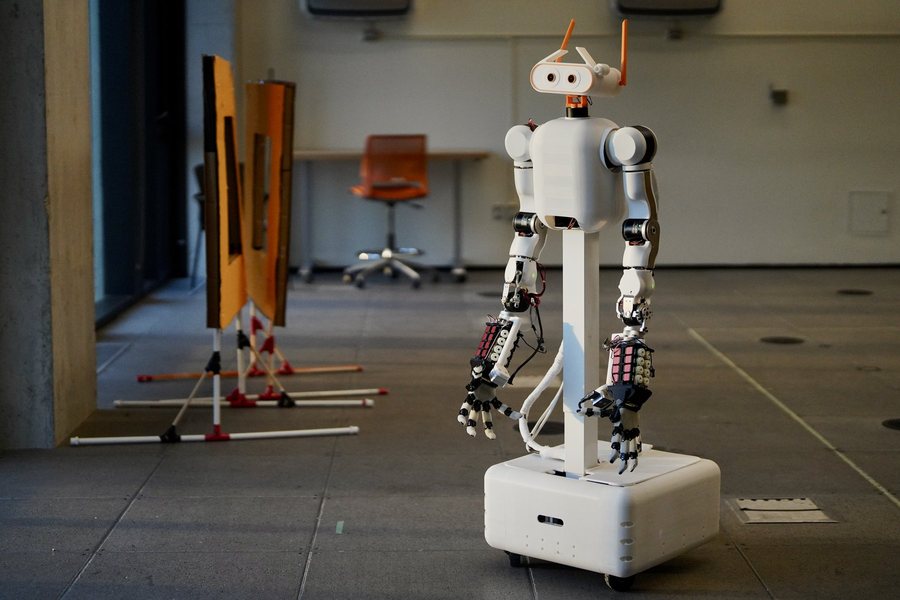
Robot / hardware buildWheeled bimanual research robot with dexterous hands, a lifting torso, and teleoperation and learning software. [1]
Build & first use →Official websiteSource codeUpstream build guideBill of materials
- For
- Robot builders researching wheeled mobile manipulator with two arms and dexterous hands. [1]
- Cost
- No current cost yet. Upstream bill of materials [1] [2]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-S-2.0, Apache-2.0, CC BY 4.0 · Details by part
Overview
MABEL combines a swerve base, lift, two arms and two ORCA hands. To judge whether that configuration fits your task, start with the MuJoCo model. The repository lists Python 3.10 or later with macOS or Ubuntu for simulation. Mock mode supplies synthetic hand input without a headset. Real-robot bring-up uses Ubuntu 24.04 on an NVIDIA Jetson, and the software offers subsystem options such as --only-hands and --no-base. Those options document software support for bringing up subsets. [1]
The project links full-robot STEP, a build guide and a costed BOM. Essential, Recommended and Maximum differ across five choices: compute, wrist cameras, head camera, base depth camera and LiDAR. Pick those options after checking the interfaces required by your task. Consult the BOM’s open-items list before ordering because the source flags disputed and unpriced lines. A current delivered budget has not been established. [1] [2] [3]
The authors declare CERN-OHL-S-2.0 for hardware, Apache-2.0 for software and CC BY 4.0 for documentation and media. This is a source review without an independent hardware build, simulation run or deployment test. [1]
Is this for you?
- Known limitations
- Supplier prices, third-party component terms and replication of the integrated platform remain unverified.
Scoped to the inspected sources and verification performed.
[1] · Editorial assessment
Hardware & parts
Upstream bill of materials [1] [2]
- Hardware configuration
Wheeled mobile manipulator with two arms and dexterous hands
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The upstream design is linked below. An interactive preview has not been prepared for this profile.
Model sources
The upstream design is linked below. An interactive preview has not been prepared for this profile.
What we checked
Source review only. No physical build or runtime test. Image credited to upstream.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Nov 15, 2026
- Sources last checked
- Nov 15, 2026
- Next review
- Dec 15, 2026
- Reviewed revision
d0181f0
Source files and licenses
Includes a documented physical robot design with scope and reuse terms described by artifact.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-S-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
| electronics | not found · License not fully assessed No separately licensed implementation located for this layer in the reviewed sources. [1] |
| firmware | available · Apache-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
| software | available · Apache-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
| documentation | available · CC BY 4.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
This entry scopes the physical robot and its build documentation.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 robotmabel/open_mabel README.md
Revision, date & where cited
The MABEL Authors · github.com · revision
d0181f0· README.md at · Accessed Nov 15, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S002 robotmabel/open_mabel hardware/bom/README.md
Upstream hardware/bom/README.md for this project.Revision, date & where cited
The MABEL Authors · github.com · revision
d0181f0· hardware/bom/README.md at · Accessed Nov 15, 2026
Used for: Overview, Hardware & parts - S003 robotmabel/open_mabel hardware/bom/data/core.csv
Upstream hardware/bom/data/core.csv for this project.Revision, date & where cited
The MABEL Authors · github.com · revision
d0181f0· hardware/bom/data/core.csv at · Accessed Nov 15, 2026
Used for: Overview
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-11-15 — Initial source-reviewed hardware profile and attributed upstream image.