OpenParallelGripper — XL330 version
End effectorParallel-jaw gripper for the LITE 6 using a Dynamixel XL330 servo, printed housings, machined claws and OpenRB control examples with a serial-rate mismatch to resolve. [2] [3] [5] [6] [7]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Builders able to inspect CAD, source parts and reconcile control integration. [1]
- Cost
- No current cost yet. Upstream bill of materials [3]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
OpenParallelGripper has two actuator-specific designs. This profile covers the Dynamixel XL330-M288-T version for UFACTORY LITE 6, not the heavier SCS3045M version. The maintainer reports 0–65 mm stroke and about 270 g for XL330, and describes its thinner structure as a tradeoff against rigidity. Those are upstream reports, not measurements from our build. [1] [2]
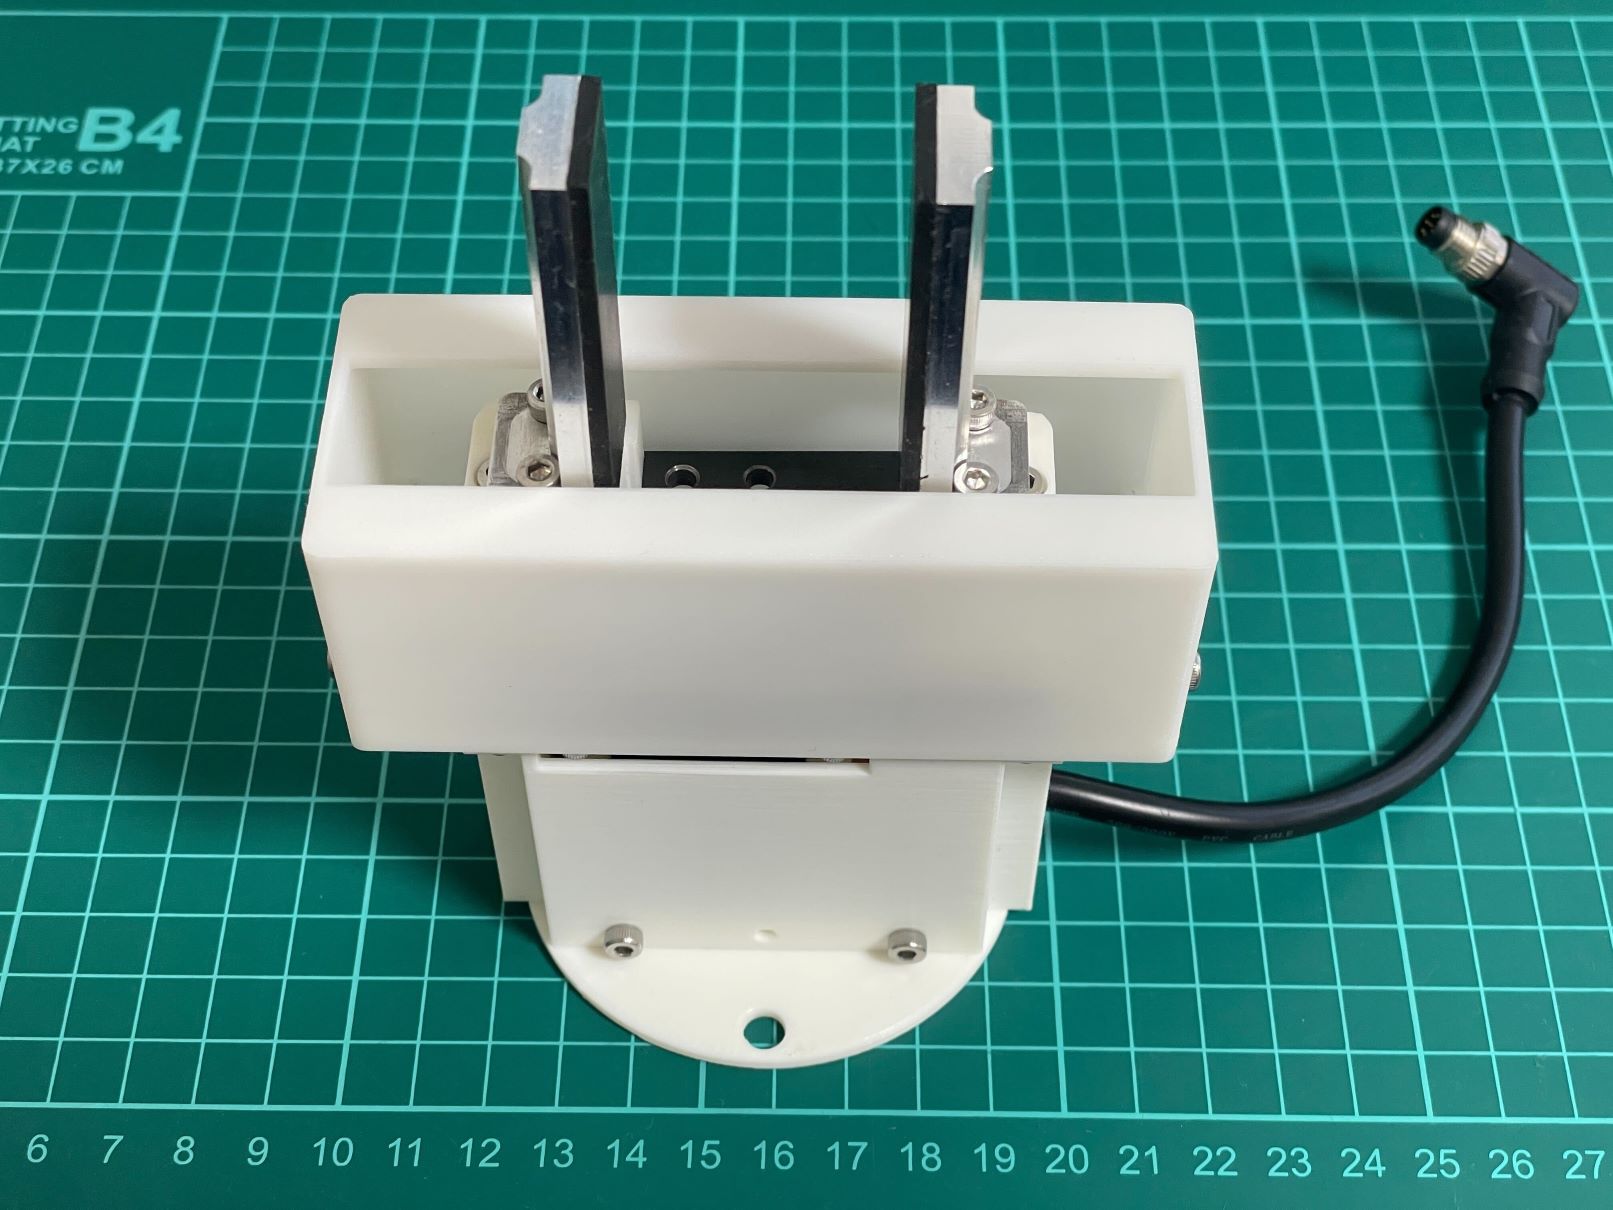
The photograph shows the maintainer’s XL330-version build, with a white housing, metal claws and attached tool cable. It is separate from the interactive assembly model and is not hardware tested by us. [9]
Is this for you?
- Known limitations
- Assembly guide unavailable; electronics and software explicitly under development.
- Firmware uses 57600 baud; Python Modbus example requests 115200.
- Metal gear fabrication and aluminum claws required by recommended configuration; costs and physical performance unverified.
Editorial synthesis of inspected sources; not physical qualification.
3D preview
OpenParallelGripper XL330 assembly. XL330-version assembly geometry, including purchased-component representations. The LITE 6 arm and a verified powered setup are not included.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: hygradme, revision 659f8fa6a5ec498c10ee06df4e0bfafdb04946e6. Original and preview: MIT. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- Dynamixel2Arduino
- modbus-esp8266
- xArm Python SDK
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [3] · Project documentation [1]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Plan for machined and purchased parts
The XL330 BOM separates printed housings and adapters from an aluminum claw pair, a purchased rail and two racks. It strongly recommends metal printing for the 20-tooth gear and says the author used SLM. The design therefore is not an all-plastic desktop print: price metal fabrication, the XL330 servo, the SSE2B6-100 rail, two RGEAL0.8KA-55-A5-B10-C10-D10 racks, fasteners and electronics separately. The BOM lists quantities but no current delivered total. [3]
The linked claw STEP path in the BOM omits the stp directory; the preserved file is XL330_version/hardware/cnc_miling_parts/stp/Claw_50mm.step. An assembly STEP and individual STEP/STL files are present. The project README still says the assembly instructions are not available, so use the model and BOM to plan fit checks rather than assuming a complete assembly sequence exists. [2] [3] [9]
Reconcile the serial settings before commissioning
The documented control choices are two LITE 6 tool digital inputs for open/close, or Modbus-RTU over RS485 for intermediate positions. The reference electronics use OpenRB-150 and an RS485-to-TTL module, with soldering and a crossed Grove TX/RX connection. The electronics guide warns that connections may be unstable; it also retains an ATOM Lite/debug-board sentence despite describing OpenRB-150 elsewhere. Check the XL330 wiring diagram against the selected board instead of combining the two versions' instructions. [4] [5]
There is a concrete mismatch in the pinned Modbus examples: the OpenRB sketch initializes Serial2 at 57,600 baud, while the Python example actively requests 115,200. These must agree before the pair can communicate. The sketch uses servo ID 1 and example targets of 0 and 250 degrees; reconcile those limits with the assembled mechanism before enabling motion. The software README lists Dynamixel2Arduino, modbus-esp8266 and the xArm Python SDK, but a matched dependency build and hardware calibration have not been verified here. [5] [6] [7]
The MIT-licensed repository includes mechanical files, wiring documentation and example control source. That does not make the purchased servo and boards open manufacturing designs. The LITE 6 documentation supports a platform-interface tag; the README's suggestion that other cobots might work is not evidence of Universal Robots or delta compatibility. No physical assembly, gripping performance or safety certification is claimed. [1] [4] [8]
What we checked
Source and geometry review only. No procurement, assembly, firmware build, calibration or physical performance testing.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Sep 30, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
659f8fa
Source files and licenses
Licensed first-party mechanical design and documentation; purchased components and a matched working build remain separate checks.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT First-party project files under root license; vendor artifacts and purchased-component manufacturing not included in this grant assessment. [8] [9] |
| electronics | available · MIT Wiring documentation for purchased boards; board manufacturing sources not established. [4] [8] |
| firmware | available · MIT Example source only; external dependencies not fully preserved or compiled; serial-rate mismatch unresolved upstream. [6] [8] |
| software | available · MIT Example source only; external dependencies not fully preserved or compiled; serial-rate mismatch unresolved upstream. [7] [8] |
| documentation | available · MIT First-party project files under root license; vendor artifacts and purchased-component manufacturing not included in this grant assessment. [8] [9] |
No learned model or dataset required by the documented mechanical design.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Version comparison
Revision, date & where cited
github.com · revision
659f8fa· README.md at · Accessed Sep 30, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Reconcile the serial settings before commissioning - S002 XL330 configuration
Revision, date & where cited
github.com · revision
659f8fa· XL330_version/README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Assembly & first use, Plan for machined and purchased parts - S003 XL330 bill of materials
Revision, date & where cited
github.com · revision
659f8fa· XL330_version/hardware/BOM.md at · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Plan for machined and purchased parts - S004 XL330 wiring and development caveats
Revision, date & where cited
github.com · revision
659f8fa· XL330_version/electronics/README.md at · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Reconcile the serial settings before commissioning, Source files and licenses - S005 Control dependencies and setup
Revision, date & where cited
github.com · revision
659f8fa· XL330_version/software/README.md at · Accessed Sep 30, 2026
Used for: What you need, Reconcile the serial settings before commissioning - S006 OpenRB firmware settings
Revision, date & where cited
github.com · revision
659f8fa· XL330_version/software/arduino_sketch/OpenRB_modbusRTU.ino at · Accessed Sep 30, 2026
Used for: Is this for you?, Assembly & first use, Reconcile the serial settings before commissioning, Source files and licenses - S007 Python Modbus example settings
Revision, date & where cited
github.com · revision
659f8fa· XL330_version/software/examples/control_openRB150_with_modbus_rtu.py at · Accessed Sep 30, 2026
Used for: Is this for you?, Assembly & first use, Reconcile the serial settings before commissioning, Source files and licenses - S008 hygradme/OpenParallelGripper: LICENSE
Revision, date & where cited
github.com · revision
659f8fa· LICENSE at · Accessed Sep 30, 2026
Used for: Reconcile the serial settings before commissioning, Source files and licenses - S009 Preserved artifact inventory and media inspection
Revision, date & where cited
github.com · revision
659f8fa· @inventory at · Accessed Sep 30, 2026
Used for: Overview, Hardware & parts, Plan for machined and purchased parts, Source files and licenses
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1