NICO
Robot / hardware buildA humanoid interaction research platform with distinct FDM and SLS-oriented mechanical designs and a separate software repository. [1]
Build & first use →Official websiteUpstream build guide
- For
- Human–robot interaction laboratories; Builders with fabrication and integration experience [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
Overview
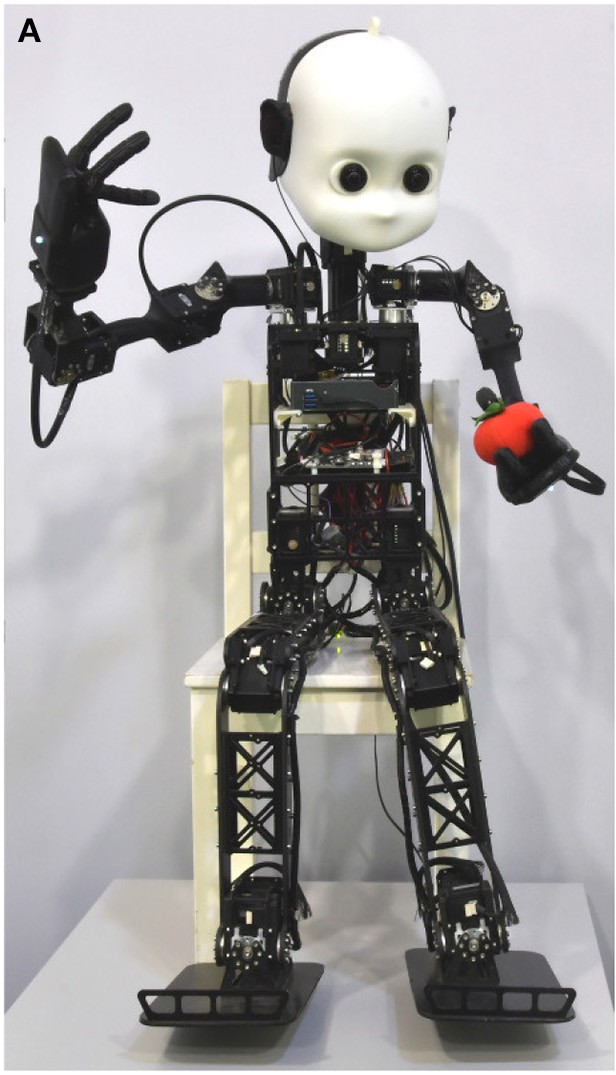
NICO is a humanoid platform for multimodal interaction research. Its CAD archive includes a regular design and a separate collection optimized by Seed Robotics for SLS or similar printing processes. The optimized README explicitly directs FDM builders to the regular models. The two sets should therefore be treated as manufacturing choices rather than interchangeable print files. [1] [5]
Is this for you?
3D preview
NICO source simulation assembly. The complete.urdf simulation configuration with its supplied visual meshes, at zero joint positions. This is not verification of the current physical robot or a complete fabrication package.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP, LZMA compression) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Knowledge Technology, University of Hamburg / NICO contributors, revision 7098cceb2be6617d6d999bfc56d2d989119931d5. Original and preview: CC-BY-SA-4.0 / GPL-3.0-or-later. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1] [5] [6] · Project documentation [1] [5] [6]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
The SLS route includes laser-cut parts
The optimized design requires an SLS or Multijet service or machine and five laser-cut pieces from two designs. Its instructions call for four shoulder reinforcements and an upper plate, preferably in 2 mm aluminum. They also distinguish printable STL parts from auxiliary CAD and an upper-plate model intended only for visualization. This matters when preparing a fabrication order: exporting every CAD object as a print would not follow the documented build. [5]
The same notes identify separate camera, LED-matrix and cable-management supports, plus a bracket for Seed Robotics RH4D hands. These are interfaces to a larger component set, not proof that the CAD download includes every actuator, hand, sensor and board. A complete configuration-specific BOM, delivered cost and compatible electronics set remain to be reconciled. [5]
Keep software and attribution with their own artifacts
We preserved the CAD and NICO-software repositories at separate immutable commits. The software overview points to its wiki for simulation and to separate build documentation; no installation or matching physical setup was reproduced here. [1] [2] [6]
Licenses also differ by source. The SLS contribution and ear attribution declare CC BY-SA 3.0, while the root CAD overview credits an iCub-derived head. The software repository assigns GPL v3-or-later to code and CC BY-SA 4.0 to other files. Those software terms should not be extended automatically to every CAD component. A future build or support offer needs the per-part provenance and chosen manufacturing route resolved alongside calibration and maintenance work. [1] [5] [6]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer
- A step-by-step setup summary
Updates
- Upstream last updated
- Mar 19, 2020 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- CAD 161109bf2f9c58d9f3f2f8fe8232f2299ef79354 and software 7098cceb2be6617d6d999bfc56d2d989119931d5 (separate commit snapshots, no stable GitHub releases selected). · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Component-scoped CC-BY-SA-3.0 declarations SLS contributor README and ear attribution declare CC-BY-SA-3.0; full CAD provenance, including iCub-derived head and purchased components, still needs per-part reconciliation. [1] [5] |
| electronics | not found · License not fully assessed Complete matched manufacturing/firmware sources for purchased components not established in CAD and overview review. [4] [5] [6] |
| firmware | not found · License not fully assessed Complete matched manufacturing/firmware sources for purchased components not established in CAD and overview review. [4] [5] [6] |
| software | available · GPL-3.0-or-later Software repository explicitly distinguishes code from other files. [6] |
| documentation | available · CC-BY-SA-4.0 Non-code files in the software repository only; not a blanket CAD or external wiki license. [6] |
This platform review selects no particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 knowledgetechnologyuhh/NICO-cad: README.md
Revision, date & where cited
github.com · revision
161109b· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 knowledgetechnologyuhh/NICO-cad: commit 161109b
Revision, date & where cited
github.com · Accessed Sep 30, 2026
Used for: Keep software and attribution with their own artifacts, What we checked - S004 knowledgetechnologyuhh/NICO-cad: files
Revision, date & where cited
github.com · revision
161109b· archive file inventory · Accessed Sep 30, 2026
Used for: Source files and licenses - S005 SLS manufacturing and attribution notes
Revision, date & where cited
github.com · revision
161109b· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S006 Separate NICO software overview and license
Revision, date & where cited
github.com · revision
7098cce· README and LICENSE at · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S009 Upstream image and reuse attribution
Media-only review: Upstream paper photograph of NICO sitting on child-sized furniture (Figure 2A, 2020). Reuse basis: CC-BY-4.0. Inspected the source image, its caption and the actual reuse declaration; no image-specific exception or different credit was found for this selected image. The grant is used only for this media, not as a new hardware/software license. Cropped to isolate the NICO photograph in panel A from the source image; no retouching. Full original retained. Technical/cost evidence dates unchanged.Revision, date & where cited
Matthias Kerzel, Theresa Pekarek-Rosin, Erik Strahl, Stefan Heinrich and Stefan Wermter · doi.org · Figure 2A; image SHA-256 5c0f384e3caeb2dec139586834f4801a51199229983e06469bb969826e3763b7 · Accessed Oct 26, 2026
Videos
- S007 Knowledge Technology, University of Hamburg (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Knowledge Technology, University of Hamburg · youtube.com · Accessed Oct 4, 2026
- S008 Express The Skills (YouTube video)
Video from the project’s own channel (Knowledge Technology, University of Hamburg), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Knowledge Technology, University of Hamburg · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S007, S008): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.