Thor
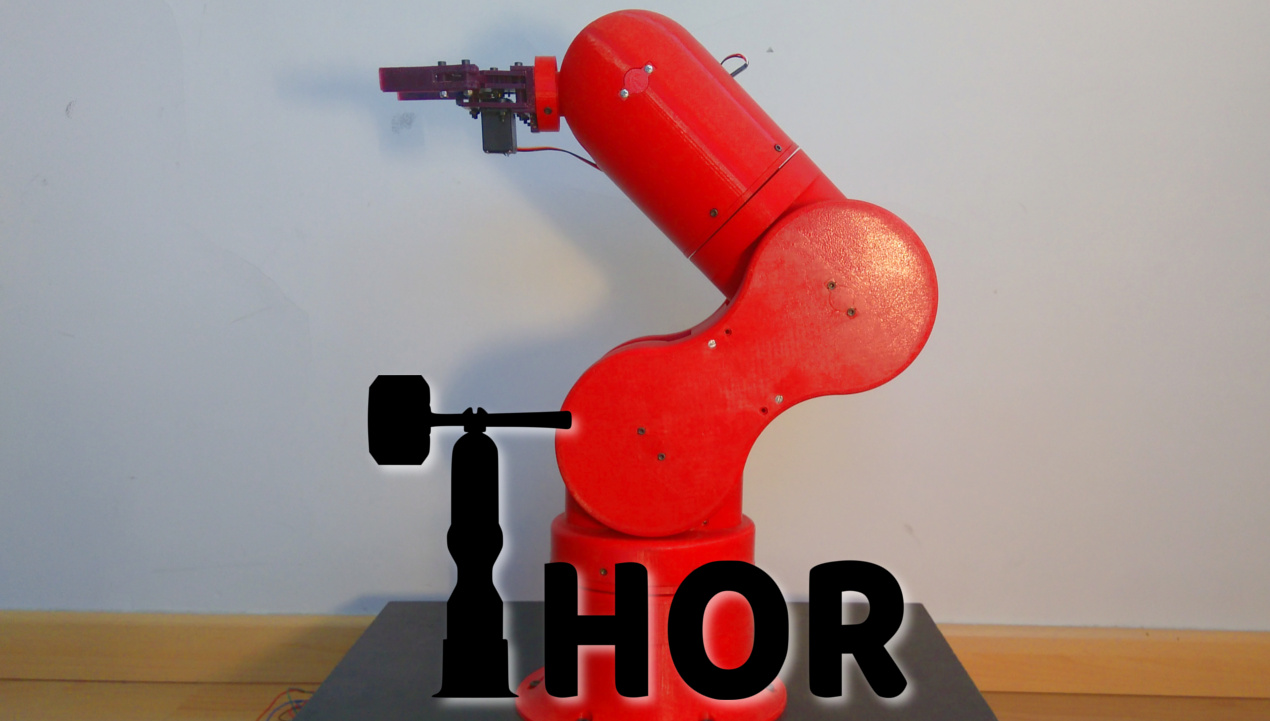
Robot / hardware buildA printable six-degree-of-freedom teaching arm with editable FreeCAD, STEP and STL mechanical sources. [1]
Build & first use →Official website
- For
- Robotics educators; Makers able to assemble and configure an arm [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0 · Details by part
Overview
Is this for you?
- Known limitations
- Repository wiki is explicitly deprecated
- Reported height and payload are upstream claims, not tests by this publication
- Mechanical source release alone does not freeze electronics and firmware
3D preview
Art1 body. This preview shows one component, not the complete robot.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Ángel Larrañaga and Thor contributors, revision dee17a7205da548f60bd1bdc3f25506a7af50ad8. Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- FreeCAD for editable mechanical designs
- KiCad for the documented PCB design workflow
- GRBL-based control firmware
Named upstream tools; complete versions and external repositories are not frozen by the mechanical release.
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Start from the release, not the README's branch links
The README's directory links point at the development branch. For a reproducible build, use the design files from the pinned release and record any later changes separately. The README also marks its wiki as deprecated and directs builders to the project website for updated manuals; an old wiki parts list should not silently become a current procurement plan. [1] [2]
A mechanical archive is not a complete controller configuration
Upstream names FreeCAD, KiCad and GRBL as design/control tools. The mechanical release does not by itself establish the exact PCB, firmware revision, host software or calibration procedure for a working arm. Those need matching before ordering electronics or promising a supported setup. [1]
The overview's material-cost claim and payload description are upstream estimates and specifications, not a current delivered quote or our measurements. We have not established the cost of an exact first-working configuration, printed its parts or verified its motion. [1]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 README explicitly applies CC BY-SA 4.0 to files in this repository; external firmware/tools have separate terms. [1] [3] |
| electronics | not found · License not fully assessed Not found in the inspected primary mechanical archive. README references external controller tools; their complete artifacts and licenses remain to be collected. [1] |
| firmware | not found · License not fully assessed Not found in the inspected primary mechanical archive. README references external controller tools; their complete artifacts and licenses remain to be collected. [1] |
| software | not found · License not fully assessed Not found in the inspected primary mechanical archive. README references external controller tools; their complete artifacts and licenses remain to be collected. [1] |
| documentation | available · CC-BY-SA-4.0 Repository documentation scope only; linked website not covered by this inference. [1] [3] |
This reviewed configuration covers the arm, without a specific learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 AngelLM/Thor: README.md
Revision, date & where cited
github.com · revision
dee17a7· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 AngelLM/Thor: commit dee17a7
Revision, date & where cited
github.com · Accessed Sep 30, 2026
Used for: Overview, Start from the release, not the README's branch links, What we checked - S003 AngelLM/Thor: LICENSE
Revision, date & where cited
github.com · revision
dee17a7· Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S004 Upstream image and reuse attribution
Media-only review: Upstream photograph of the Thor robot arm. Reuse basis: CC-BY-SA-4.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
AngelLM and Thor contributors · github.com · revision
dee17a7· Image SHA-256 e0b1657615493308983c3847317dac72793b04c098494fc0a3c28c50c87a6f06; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.