SoAG soft gripper
End effectorA pneumatic soft gripper made with cast elastomer and printed molds. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
This profile covers the soft actuator subsystem of the SoAG aerial robot. The gripper uses cast elastomer, printed molds and pneumatic actuation; aircraft dimensions and mass must not be treated as gripper specifications. [1]
Is this for you?
- Known limitations
- Define gripper-only BOM, elastomer and pressure specification, leak/recovery protocol and current suppliers. Aircraft mass must not be reported as gripper mass.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
What you need
Hardware & parts
- Hardware configuration
Soft grippers
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. CAD files were identified. A configuration-matched assembly and its file-level reuse scope have not yet been verified for this preview.
Model sources
CAD files were identified. A configuration-matched assembly and its file-level reuse scope have not yet been verified for this preview.
Project notes
Fabrication route
The documented process uses PLA molds and bases printed in flexible 80A resin. It involves mixing and degassing elastomer, casting and curing, then bonding layers with Sil-Poxy. Access to a degassing chamber is part of that route. The base-layer process also uses silicone surrounding the flexible base; distinguish the PLA mold, resin base and cast material when selecting fabrication equipment. [1]
Start with Hardware/Actuator/STL and Hardware/Actuator/Solidworks at the cited revision. These provide a design starting point, not a reconciled gripper-only shopping list. The pneumatic system described by the project includes two micro pumps, a valve, a MOSFET module and Arduino Nano. [1] [3]
Control and integration
Software/Arduino/actuation/actuation.ino and Software/ROS/flying_gripper are the documented control starting points. The original aircraft uses Arduino and ROS 1/rosserial; other host integration has not been verified here. As an editorial recommendation, establish a fixture-test procedure before host integration; a validated leak, recovery and pressure-test protocol is not supplied by this review. [1] [3]
Open questions and terms
This review has not established a complete gripper-only BOM, exact elastomer and operating-pressure specifications, current suppliers or a complete delivered cost. File availability does not establish a compatible mechanical and control configuration. No hardware was built or tested. [1] [3]
The repository's root license is MIT, with copyright and permission-notice retention. The evidence does not establish the reuse terms of externally linked GrabCAD aircraft designs; the repository license does not resolve those external rights. [2]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- a72c7fbb500426955e7b81f4e0155c3ceeac6807; Soft actuator subsystem of SoAG aerial robot, not entire aircraft
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Root MIT; external GrabCAD aircraft designs are separately scoped. [1] [2] [3] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] |
| documentation | available · MIT Root MIT; external GrabCAD aircraft designs are separately scoped. [1] [2] [3] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 UCR-Robotics/SoAG: README.md
Revision, date & where cited
github.com · revision
a72c7fb· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 5 more - S002 UCR-Robotics/SoAG: LICENSE
Revision, date & where cited
github.com · revision
a72c7fb· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Open questions and terms and 1 more - S003 UCR-Robotics/SoAG: files
Revision, date & where cited
github.com · revision
a72c7fb· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Fabrication route and 3 more - S007 Upstream image and reuse attribution
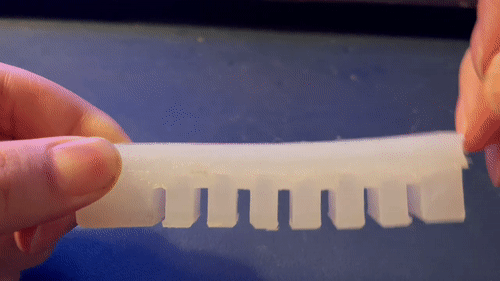
Media-only review: Still from an upstream demonstration: a soft actuator segment used by SoAG; this is not the complete gripper or an aerial robot. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Still taken from the upstream animation; no other changes. This does not refresh technical or cost evidence.Revision, date & where cited
Zhichao Liu and SoAG contributors · github.com · revision
a72c7fb· Image SHA-256 6ab90919fa38e377e937c351f115740b6b28e13cbd531a145bbecb9eb5a7a5bc; repository · Accessed Oct 25, 2026
Videos
- S004 video3 frontiers (YouTube video)
Video uploaded by Zhichao Liu, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Zhichao Liu · youtube.com · Accessed Oct 4, 2026
- S005 video1 frontier (YouTube video)
Video uploaded by Zhichao Liu, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Zhichao Liu · youtube.com · Accessed Oct 4, 2026
- S006 frontier22-Catching (YouTube video)
Video uploaded by Zhichao Liu, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Zhichao Liu · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 3 YouTube reference(s) (S004, S005, S006): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.