Faze4
Robot / hardware buildA six-axis printed arm built around cycloidal gearboxes, with separate mechanical and control documentation. [1]
Build & first use →Official websiteBill of materials
- For
- Experienced makers; Robotics educators [1]
- Cost
- No current cost yet. Upstream bill of materials [1]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- not fully assessed for mechanical design, electronics, firmware, software, documentation · Details by part
Overview
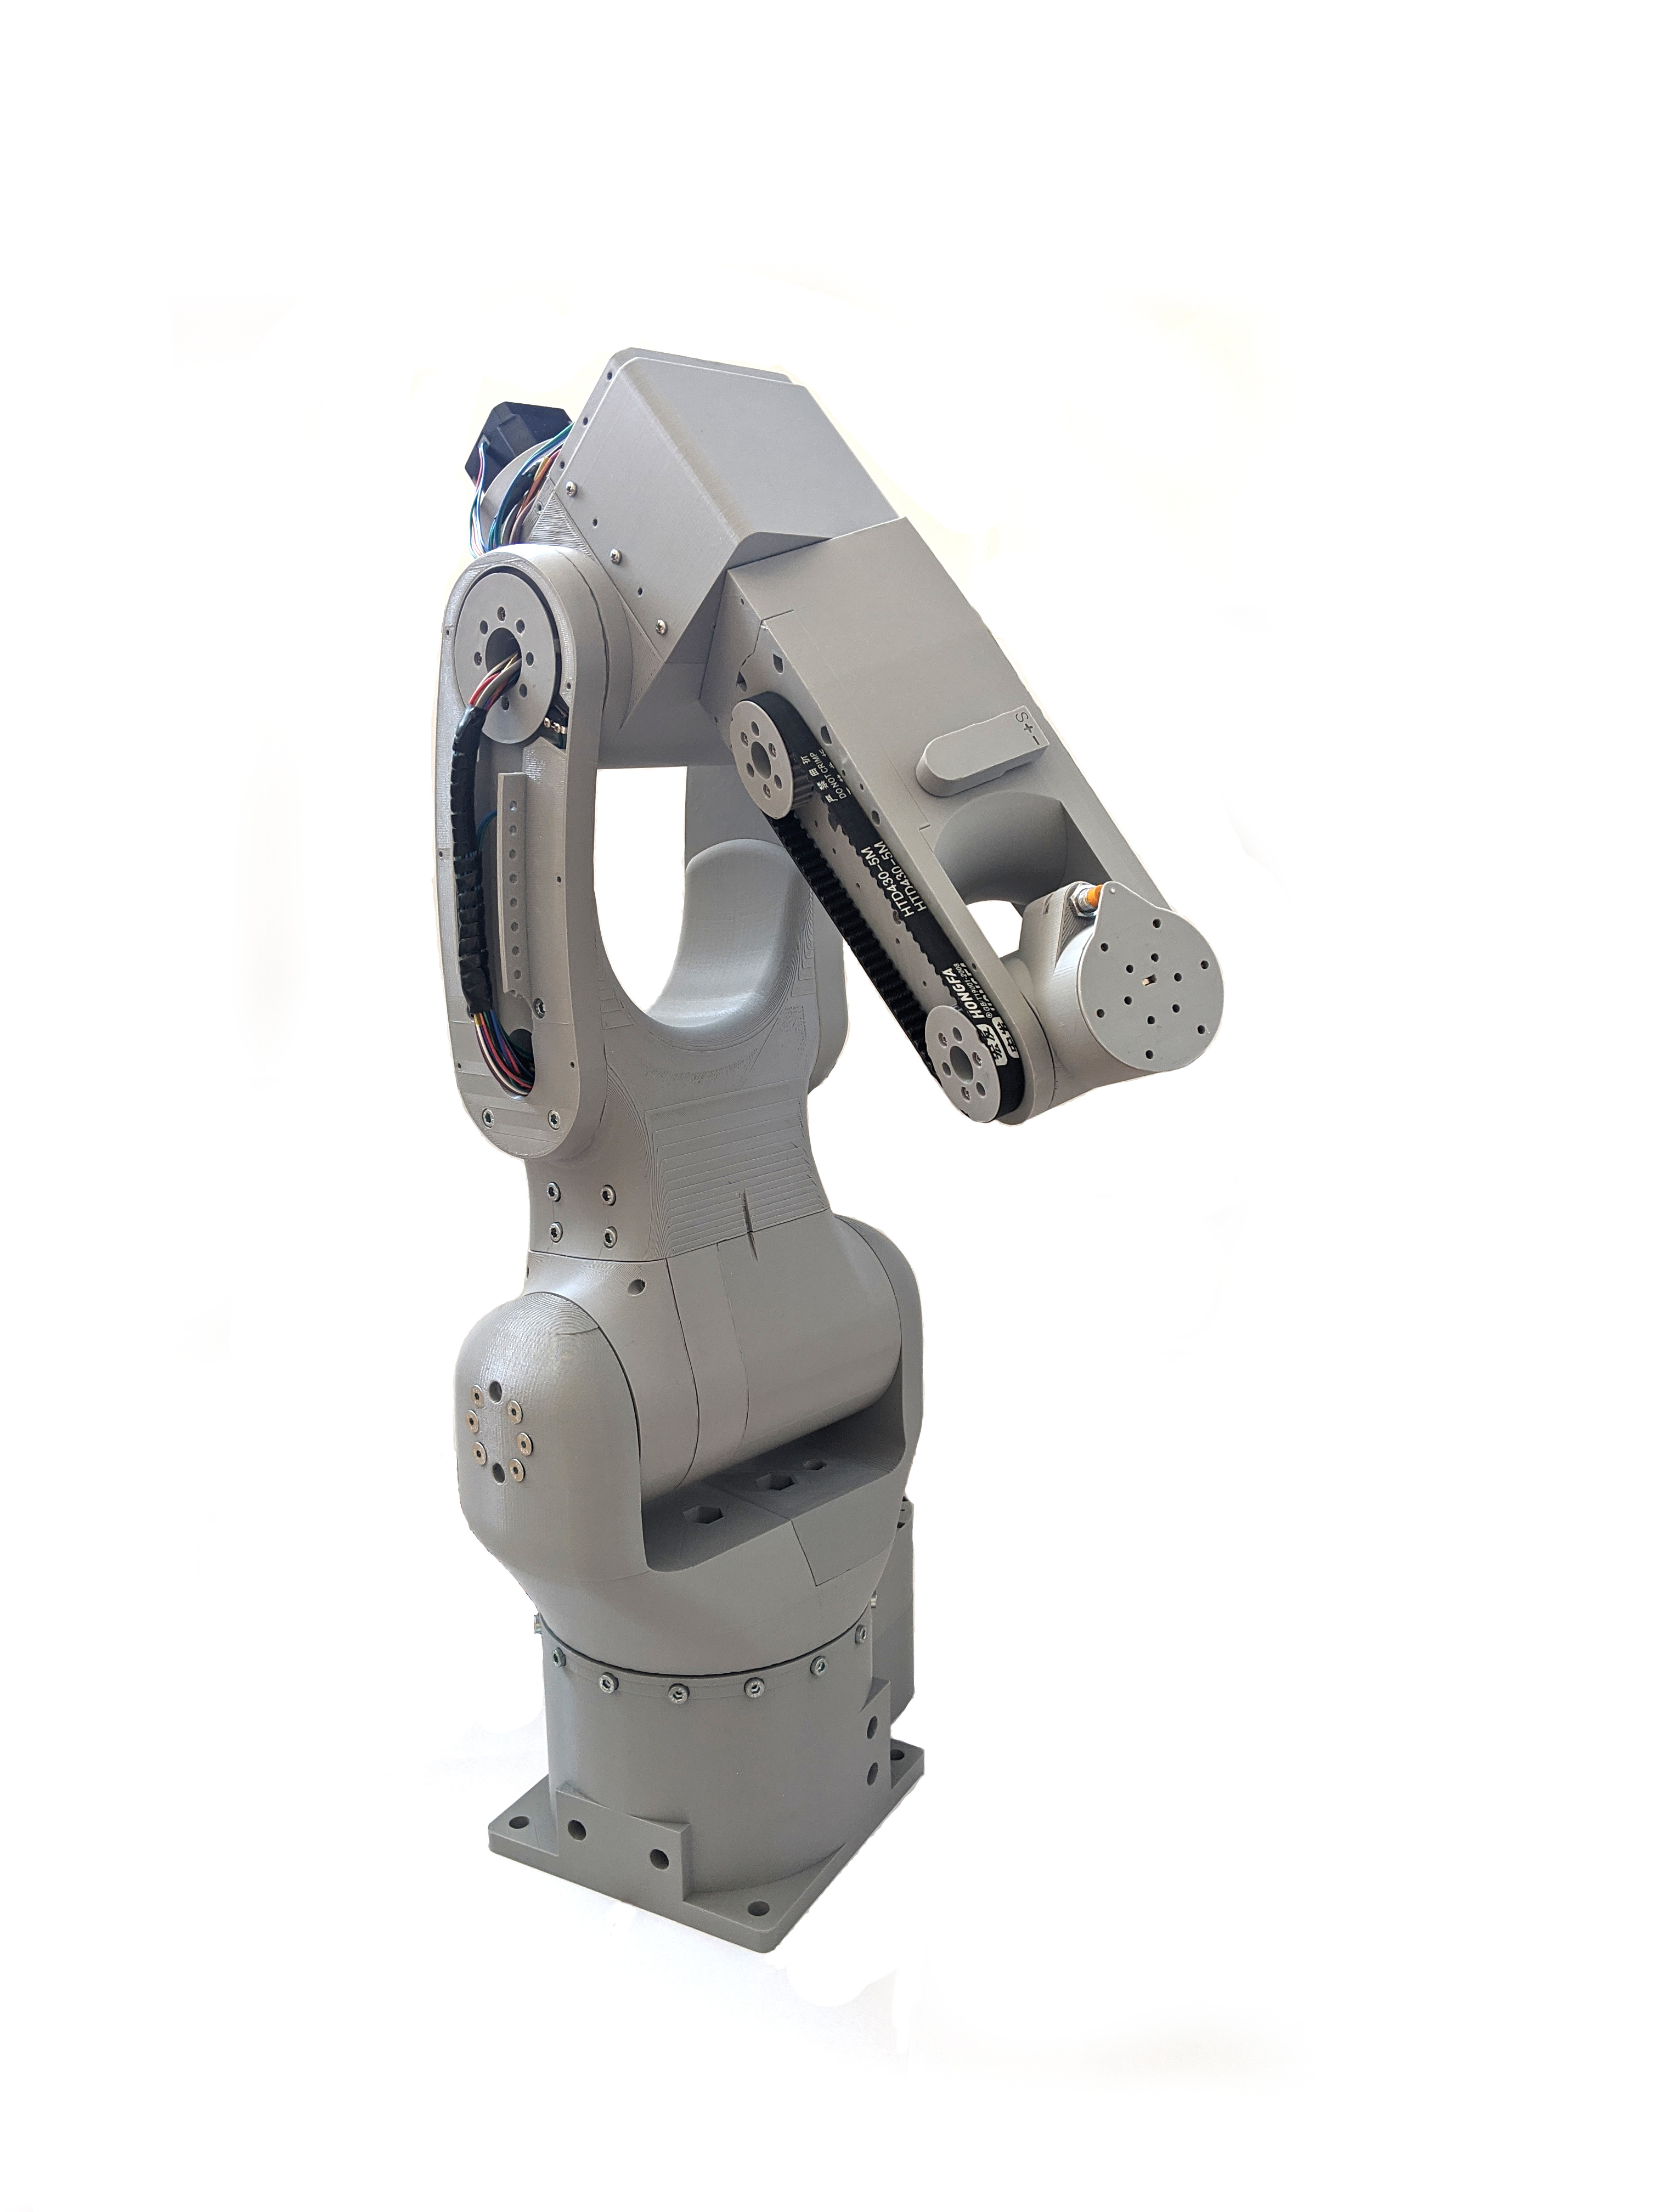
Faze4 is a six-axis arm using printed cycloidal gearboxes. Its build is substantial: the upstream overview describes roughly 1,000 parts, including screws and bearings. That makes fastener organization and gearbox assembly relevant planning work, even though much of the structure is printable. [1]
Is this for you?
- Known limitations
- License file and README name different licenses
- Rough upstream headline cost is not a delivered, configuration-specific budget
- Build spans mechanical instructions and separate electrical/control documentation
3D preview
Faze4 simplified arm robot description (Final_light_assembly_URDF). The project URDF package (URDF_FAZE4, Final_light_assembly_URDF.urdf at commit 674f46c) at zero joint positions: 7 link meshes (base, rotary base, upper arm, elbow, forearm, wrist and gripper) on the source chain of 6 continuous joints. It is a simplified light assembly: each link is one exported mesh, so cycloidal gearbox internals, motors, fasteners, electronics and cables are not modeled as separate parts. The repository license notices conflict (LICENSE: CERN-OHL-S-2.0; README: MIT; URDF package metadata: BSD), and the source does not say which governs this model, so no manufacturing or redistribution clearance is claimed beyond what the source states. Fit and motion are not verified.
Conflicting license notices: the Faze4 repository LICENSE file is the “CERN Open Hardware Licence Version 2 - Strongly Reciprocal” (CERN-OHL-S-2.0), the README states “Project is under MIT Licence” with an MIT badge, and the URDF package metadata (package.xml, generated by the SolidWorks exporter) says “BSD”. The source does not say which governs this model. Open Source Robotics shows it with attribution to Petar Crnjak / Source Robotics and keeps the strongly reciprocal CERN-OHL-S-2.0 notice with the hosted files; no manufacturing or redistribution clearance is claimed beyond what the source states. License: Faze4 LICENSE (CERN-OHL-S-2.0); README states MIT · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Petar Crnjak / Source Robotics, revision 674f46cb608d25899c46fc2ea67741f008a8f016. Original and preview: Conflicting notices: LICENSE CERN-OHL-S-2.0; README MIT; URDF package.xml BSD. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Tools
- Printer build volume 250 × 210 × 200 mm in upstream guidance
Hardware & parts
Assembly & first use
- Assembly
Use Assembly instructions 3.1.pdf together with the separate electrical/control documentation; neither is the entire build guide.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Mechanical assembly is only one part of the instructions
The repository links an assembly PDF and a dated BOM workbook, while electrical wiring and low- and high-level control setup live in separate documentation. Read those together before treating the mechanical assembly as a complete build plan. ROS and MATLAB routes are mentioned, but this review has not reconciled their versions or host requirements with a specific controller configuration. [1]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer
- A step-by-step setup summary
Updates
- Upstream last updated
- Dec 28, 2025 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 674f46cb608d25899c46fc2ea67741f008a8f016 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed README says MIT while LICENSE contains CERN-OHL-S-2.0. Applicable licensing is unresolved; do not treat the badge as commercial clearance. [1] [3] |
| electronics | available · License not fully assessed Files present in the pinned archive; MIT versus CERN-OHL-S root licensing conflict remains unresolved. No execution or completeness claim. [3] [4] |
| firmware | available · License not fully assessed Files present in the pinned archive; MIT versus CERN-OHL-S root licensing conflict remains unresolved. No execution or completeness claim. [3] [4] |
| software | available · License not fully assessed Files present in the pinned archive; MIT versus CERN-OHL-S root licensing conflict remains unresolved. No execution or completeness claim. [3] [4] |
| documentation | available · License not fully assessed Same repository license conflict; linked documentation may have separate terms. [1] [3] |
This reviewed configuration covers the arm, without a specific learned policy or dataset.
The license statements disagree
The README presents MIT licensing, including its badge and closing statement. The LICENSE file at the same pinned commit contains CERN-OHL-S-2.0. These are materially different source statements, and this review does not choose one on the maintainer's behalf. Resolve the applicable terms before a commercial parts or kit offer. [1] [3]
The overview's low-cost claim is not a current shopping quote. The dated BOM, exact electronics, printing, host equipment and delivery still need a configuration-specific reconciliation. No complete delivered budget or build time has been established here. [1]
The pinned printing guide recommends PETG and a 250 × 210 × 200 mm build volume. Its low-level guide names Teensy 3.5, but the First startup page contains only a placeholder. A complete startup and calibration procedure is still a build blocker. [4]
The local copy is a commit snapshot, not a published stable release. We have not printed, assembled or run this arm. [2]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Source-Robotics/Faze4-Robotic-arm: README.md
Revision, date & where cited
github.com · revision
674f46c· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S002 Source-Robotics/Faze4-Robotic-arm: commit 674f46c
Revision, date & where cited
github.com · Accessed Sep 30, 2026
Used for: What we checked, Source files and licenses - S003 Source-Robotics/Faze4-Robotic-arm: LICENSE
Revision, date & where cited
github.com · revision
674f46c· Accessed Sep 30, 2026
Used for: Source files and licenses - S004 Pinned archive design and setup files
Revision, date & where cited
github.com · revision
674f46c· Distribution_PCB.zip, Software1, docs · Accessed Sep 30, 2026
Used for: What you need, Hardware & parts, Source files and licenses - S008 Upstream image and reuse attribution
Media-only review: Historical photograph of the Faze4 six-axis arm, published in October 2020 and retained unchanged in the selected source snapshot. The bare wrist has no gripper, and the control cabinet and installed software are not shown. Reuse basis: MIT. Actual original-upload revision of this creator photograph includes the MIT license Copyright(c)2019PetarCrnjak, whose grant includes associated documentation; its README explicitly saysProjectisunderMITLicence. HistoricalcompleteGit tree has onlyrootLICENSE and no narrower image/docslicense. Originaluploaddate2020-10-01 andlicensehistory are preserved. The image bytes are identical in the selected2025 source snapshot674f46cb608d25899c46fc2ea67741f008a8f016. The later2025-09-24 rootlicense change toCERN-OHL-S-2.0 is recorded, not used as thephoto permission basis; noassertionis made thatallcurrenthardwareorfilesareMIT. SeparatecreatorPrintablesNCpublicationisnotusedaspermission and notextendedtootherassets. Imageisphysically photographedprintedFaze4arm,not aCADrender orPAROL6;layertexture,bolts,wires,beltsandwristarevisible. Captiondiscloses2020historicaldate andunchangedretentionintheexactselectedsnapshot,withoutclaimingthephoto proves2023BOMupdates,assemblyguide3.1changes,currentcontrolcabinet,hiddenelectronicsorsoftwareversion. Barewrist/gripperabsenceexplicit. Originalphotographunchanged,propercreatorcredit/fullhistoricalcopyrightandpermissionnoticeincluded. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Petar Crnjak / Faze4 project contributors · github.com · revision
21db0bb· Original upload21db0bb7bf7f6a11da550f94926ce32d0210d375,2020-10-01; ruka_good_slika.jpg Gitblob359881bde55cd45caa0072a64a082a10cf31eb50, identicalSHA256774c6ddd3a75fe49fe2c5373d82e77f7d12844a59626c757ef67eedb72fa71cb inselected674f46cb608d25899c46fc2ea67741f008a8f016.; image SHA-256 774c6ddd3a75fe49fe2c5373d82e77f7d12844a59626c757ef67eedb72fa71cb · Accessed Oct 26, 2026
Videos
- S005 Source Robotics (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Source Robotics · youtube.com · Accessed Oct 4, 2026
- S006 Faze4 - 3D printed 6 axis robot arm (YouTube video)
Video from the project’s own channel (Source Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Source Robotics · youtube.com · Accessed Oct 4, 2026
- S007 Faze4 Robotic arm , test 2 (YouTube video)
Video from the project’s own channel (Source Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Source Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 3 YouTube reference(s) (S005, S006, S007): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.