PAROL6
Robot / hardware buildA printed desktop arm with a separate Commander application and a required PAROL6 control board. [1]
Build & first use →Official websiteBill of materials
- For
- Experienced makers; Robotics educators [1]
- Cost
- No current cost yet. Upstream bill of materials [4]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- GPL-3.0 · Details by part
Overview
PAROL6's robot repository contains printable parts, a BOM, assembly instructions and control-board firmware. Commander, its programming and control application, lives in a separate repository. Commander's README explicitly requires the PAROL6 control board; public STL and software files do not eliminate that hardware dependency. [1] [4] [5]
Start with BOM/PAROL6 BOM.xlsx and the Building instructions in the pinned robot snapshot. Match that selection to the control board and Commander revision before buying parts. The current delivered cost, board availability and exact version compatibility have not been established here. [1] [2] [4] [5]
Commander documents Python 3.10.12, platform-specific installation guides and a working-dependency directory. Its built-in simulator and GUI are distinct from the separately linked Python API. The overview also warns that its experimental kinematics branch introduces potentially dangerous conditions; that branch is not the control configuration evaluated here. [5]
Both inspected repositories declare GPL v3. That establishes the stated repository terms, not a complete manufacturing license or editable design pack for every purchased component. No assembly, startup, calibration or performance test was carried out. [3] [5]
3D preview
Joint 1 bottom lid. One joint-1 bottom-lid component from the upstream STL printing files, not a complete arm. Print settings and physical fit have not been validated by us.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STL · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Source Robotics contributors, revision 8a045051808ddc2351b1a57eef829522b8808340. Original and preview: GPL-3.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STL does not declare units; confirm dimensions against the project design. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- Commander documents Python 3.10.12
- requirements.txt and platform-specific installation instructions
Hardware & parts
Assembly & first use
- Assembly
Follow the BOM and Building instructions, then the separate startup documentation.
Cost
No current, complete configuration-specific build cost has been established for this profile.
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A limitations summary
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Mar 6, 2025 [2]
- Latest release
- Mar 8, 2025 [2]
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- Hardware/control archive 8a045051808ddc2351b1a57eef829522b8808340; Commander 65c844fd5e0e5ec20c30352092ac4fb29b997bd5 (commit snapshot, no stable release found); configuration compatibility not tested. · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · GPL-3.0 Repository-level declaration; purchased components retain separate rights and constraints. [1] [3] [4] |
| electronics | not found · License not fully assessed Complete control-board manufacturing design was not established in the inspected robot archive or Commander overview. Required purchased board is explicitly documented. [4] [5] |
| firmware | available · GPL-3.0 Repository-level declaration; purchased components retain separate rights and constraints. [1] [3] [4] |
| software | available · GPL-3.0 Commander repository; dependencies and hardware have separate scope. [5] |
| documentation | available · GPL-3.0 Repository-level declaration; purchased components retain separate rights and constraints. [1] [3] [4] |
This profile covers a programmed arm, not a specified learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Source-Robotics/PAROL6-Desktop-robot-arm: README.md
Revision, date & where cited
github.com · revision
8a04505· Accessed Sep 30, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Source files and licenses - S002 Source-Robotics/PAROL6-Desktop-robot-arm: commit 8a04505
- S003 Source-Robotics/PAROL6-Desktop-robot-arm: LICENSE
Revision, date & where cited
github.com · revision
8a04505· Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S004 Source-Robotics/PAROL6-Desktop-robot-arm: files
Revision, date & where cited
github.com · revision
8a04505· archive file inventory · Accessed Sep 30, 2026
Used for: Overview, Hardware & parts, Source files and licenses - S005 Commander setup, board requirement and license
Revision, date & where cited
github.com · revision
65c844f· README and LICENSE at · Accessed Sep 30, 2026
Used for: Overview, What you need, Hardware & parts, Source files and licenses - S007 Upstream image and reuse attribution
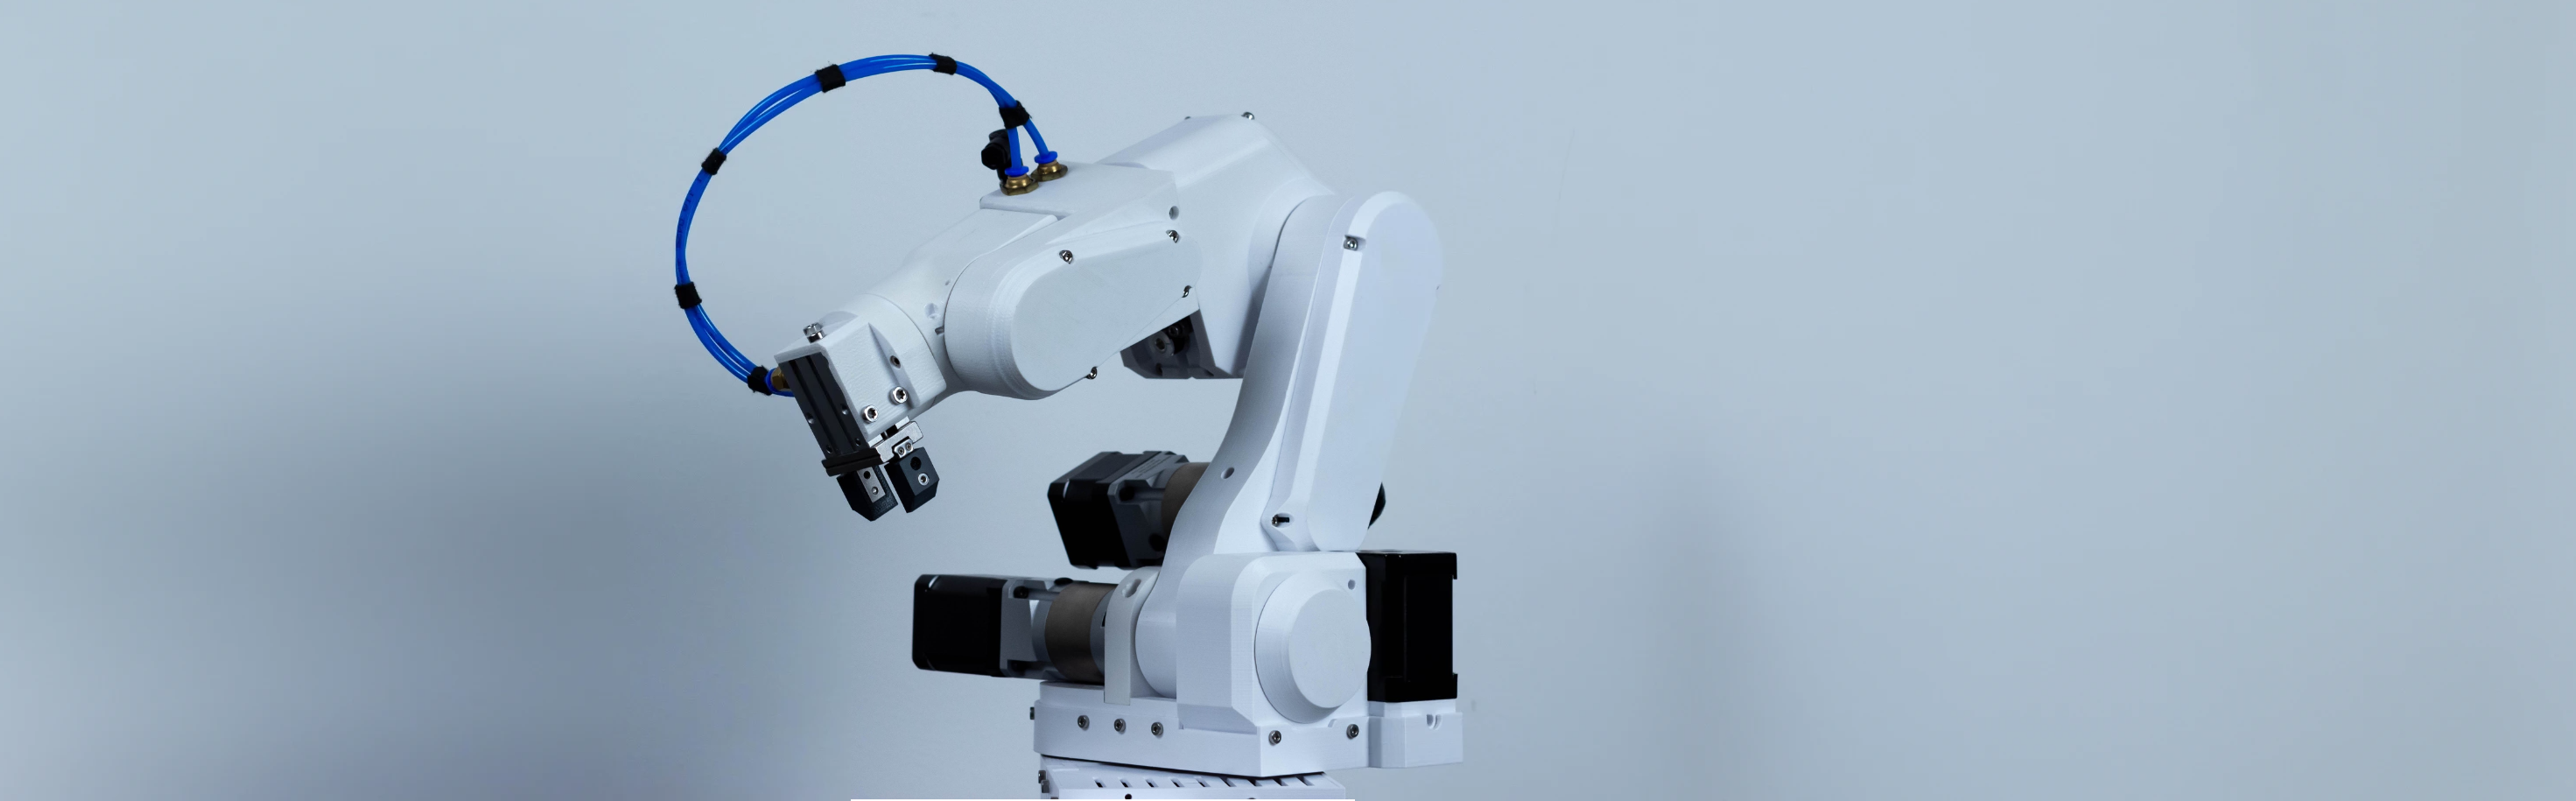
Media-only review: Upstream image of the PAROL6 robot arm; no physical assembly or motion test was performed by us. Reuse basis: GPL-3.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Source Robotics and PAROL6 contributors · github.com · revision
8a04505· Image SHA-256 9f3c183f51ac1a6d33b9ece8992806afd05594475480ed0a6270991f45469d6f; repository · Accessed Oct 25, 2026
Videos
- S006 Source Robotics (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Source Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S006): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.