Pi-puck
Controller extensionRaspberry Pi extension for e-puck and e-puck2 robots, with Linux integration, separate controller firmware and an optional YRL expansion board. [1] [5] [11] [14] [15]
Build & first use →Official website
- For
- Researchers matching e-puck generation, Pi-puck board and software image [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- CC-BY-SA-4.0, MIT · license not fully assessed for firmware, documentation · Details by part
Overview
Pi-puck adds Raspberry Pi computing to e-puck and e-puck2 robots. The selected documentation names Raspberry Pi Zero W, Zero WH and Zero; other compatible boards are described only as potential alternatives. This is an extension ecosystem for an existing robot, not a complete replacement robot fabricated from this repository. [1] [5]
Is this for you?
- Known limitations
- Main archive omits firmware submodule payloads; exact two gitlinks were collected separately
- YRL expansion-board EAGLE files are not the entire Pi-puck/base-robot fabrication package
- Firmware notices require separate source-rights review
- Kernel-dependent device-tree options and image compatibility need matching
What you need
- Host computer
Selected documentation names Raspberry Pi Zero W, Zero WH or Zero; other compatible boards are only described as potential alternatives.
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Model sources
Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Project notes
Linux integration has a specific hardware and image context
The preserved integration revision is 9cb1a25f0ff13c01091213f553bb8e2a44b537a2. It contains a device-tree overlay, Linux configuration and utilities, Python control code, examples and documentation. The YRL software overview also points to separate Raspbian-image, Debian-package and ROS repositories. Those external dependencies are not all included in the selected archive. [2] [4] [7]
The overlay enables the board's I2C buses, battery inputs, LEDs and audio interfaces, with optional settings for Bluetooth/UART and software I2C. Some ADC options are explicitly limited to kernels older than 5.4. The documented software-I2C alternative has additional CPU cost. These details make the image, kernel and peripheral configuration part of the reproduction task; current distribution compatibility was not tested. [6]
Two firmware components have different jobs
The main repository pins separate e-puck1 and FT903 firmware submodules. Their exact commits were collected independently: cd5e278cbd01cb05722c3483324c2ff667e0cc8e and e62e97edb60315419b7aeed9eee11a816c9639e1. This preserves the documented source relationship without claiming that the binary files were rebuilt or matched byte-for-byte. [14] [15] [17]
The e-puck1 firmware targets the dsPIC30F6014A and exposes robot control over I2C. Its build instructions name MPLAB X, XC16 and a legacy peripheral library. Its Pi-based bootloader route also calls for a board modification that disables the dsPIC Bluetooth UART; that is a consequential hardware choice, not merely a software setting. The FT903 firmware instead provides a USB camera interface and I2C control for RGB LEDs, using a separate Bridgetek toolchain. No programming, board modification or hardware test was performed. [14] [15]
The optional expansion board is a separate design
The linked YRL expansion adds an IMU, XBee socket, navigation switch, RGB LED and Raspberry Pi-compatible header. Its separately preserved revision f3f1298ef8ea4a860a84cc0bfd2ad1cf67c0a893 contains EAGLE board and schematic files plus a BOM. These files describe the optional expansion, not the complete GCtronic Pi-puck carrier or base e-puck robot. [10] [11] [13]
The main software declaration is MIT unless otherwise specified; the YRL hardware design uses CC BY-SA 4.0. FT903 source files carry vendor-specific notices and other component terms, so this profile leaves the whole firmware license unresolved rather than assigning MIT to everything. Documentation and media rights also require artifact-specific confirmation before reuse. [1] [8] [9] [11] [12] [16]
A complete budget still requires the base robot, Pi-puck hardware, Raspberry Pi and selected optional peripherals. No current delivered package cost, installation result, camera throughput or robot-control performance was established by this review. [5] [7] [11]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Oct 15, 2020 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 9cb1a25f0ff13c01091213f553bb8e2a44b537a2 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | not found · License not fully assessed No complete base-robot or mounting fabrication package established by these integration and optional expansion-board archives. [4] [5] [13] |
| electronics | available · CC-BY-SA-4.0 Optional YRL expansion board includes EAGLE design files and BOM; this does not license or establish the full base robot or GCtronic carrier fabrication package. [10] [11] [12] [13] |
| firmware | available · License not fully assessed Both exact firmware gitlinks preserved separately. FT903 files contain vendor-specific notices and other component terms; no blanket MIT or normalized whole-firmware license assigned. [14] [15] [16] [17] |
| software | available · MIT Main repository software is MIT unless otherwise specified; separate firmware and external distribution dependencies are outside that blanket claim. [1] [8] |
| documentation | available · License not fully assessed Documentation available; root declarations distinguish hardware and software but do not establish a single explicit license for every documentation/media artifact. [1] [8] [9] |
Selected conventional extension/control stack does not require a learned policy or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 yorkrobotlab/pi-puck: README.md
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, The optional expansion board is a separate design and 1 more - S002 yorkrobotlab/pi-puck: commit 9cb1a25
Revision, date & where cited
github.com · Accessed Oct 1, 2026
Used for: Linux integration has a specific hardware and image context, What we checked - S003 yorkrobotlab/pi-puck: LICENSE-CC-BY-SA
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026 - S004 yorkrobotlab/pi-puck: files
Revision, date & where cited
github.com · revision
9cb1a25· archive file inventory · Accessed Oct 1, 2026
Used for: Linux integration has a specific hardware and image context, Source files and licenses - S005 Pi-puck docs/about.rst
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, The optional expansion board is a separate design and 1 more - S006 Pi-puck device-tree/README.md
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Linux integration has a specific hardware and image context - S007 Pi-puck docs/software/overview.rst
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026
Used for: What you need, Linux integration has a specific hardware and image context, The optional expansion board is a separate design - S008 Pi-puck LICENSE-MIT
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026
Used for: The optional expansion board is a separate design, Source files and licenses - S009 Pi-puck LICENSE-CC-BY-SA
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026
Used for: The optional expansion board is a separate design, Source files and licenses - S010 Pi-puck docs/extensions/yrl-expansion/hardware.rst
Revision, date & where cited
github.com · revision
9cb1a25· Accessed Oct 1, 2026
Used for: Is this for you?, The optional expansion board is a separate design, Source files and licenses - S011 YRL expansion board README.md
Revision, date & where cited
github.com · revision
f3f1298· Accessed Oct 1, 2026
Used for: The optional expansion board is a separate design, Source files and licenses - S012 YRL expansion board LICENSE-CC-BY-SA
Revision, date & where cited
github.com · revision
f3f1298· Accessed Oct 1, 2026
Used for: The optional expansion board is a separate design, Source files and licenses - S013 YRL expansion board inventory.json
Revision, date & where cited
github.com · revision
f3f1298· Accessed Oct 1, 2026
Used for: Is this for you?, The optional expansion board is a separate design, Source files and licenses - S014 e-puck1 firmware README
Revision, date & where cited
github.com · revision
cd5e278· Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, Two firmware components have different jobs, Source files and licenses - S015 FT903 firmware README
Revision, date & where cited
github.com · revision
e62e97e· Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, Two firmware components have different jobs, Source files and licenses - S016 FT903 source notices
Revision, date & where cited
github.com · revision
e62e97e· preserved source file headers · Accessed Oct 1, 2026
Used for: Is this for you?, The optional expansion board is a separate design, Source files and licenses - S017 Firmware gitlink revisions
Revision, date & where cited
github.com · revision
9cb1a25· recursive Git tree · Accessed Oct 1, 2026
Used for: Is this for you?, Two firmware components have different jobs, Source files and licenses - S018 Upstream image and reuse attribution
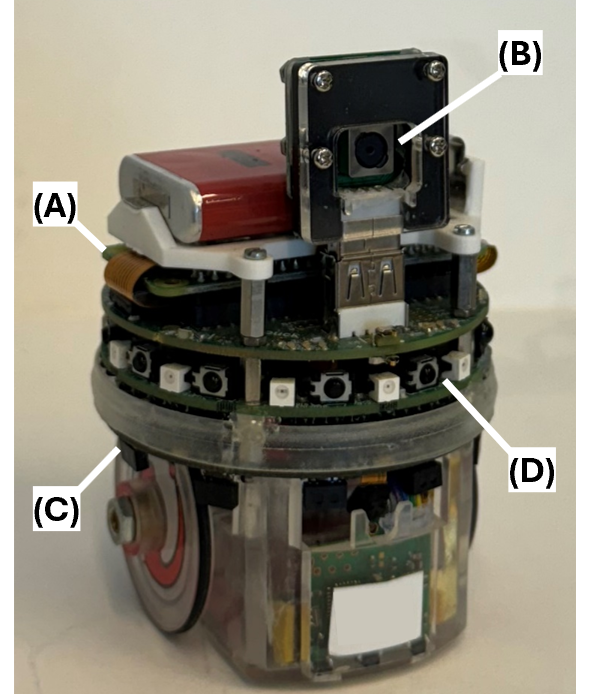
Media-only review: Annotated paper photograph of a Pi-puck on an e-puck base, with a Raspberry Pi Zero W, front camera and the study’s range-and-bearing board. Reuse basis: CC-BY-4.0. Actual arXiv v1 record explicitly selects CC BY 4.0, not the default nonexclusive arXiv distribution permission. Paper page 34 Figure 12 identifies the own-experiment physical Pi-puck with Pi Zero W, front camera, infrared sensors and an additional range-and-bearing board. Hardware matches the profile’s Pi-puck/e-puck and Pi Zero family; caption discloses the experiment’s board rather than implying a bare standard extension. Photograph and letter annotations retained; no third-party restriction or credit is attached to this original figure. No blockchain/runtime performance claim adopted. Embedded image extracted from page 34 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
Alexandre Pacheco, Hanqing Zhao, Volker Strobel, Tarik Roukny, Gregory Dudek, Andreagiovanni Reina and Marco Dorigo · arxiv.org · Swarm Oracle, arXiv:2509.15956v1, page 34 Figure 12; arXiv record Rights to this article link; image SHA-256 b550f28e02ce035e69644fbfaac9f02b60ce9598616d8f829597d047227ed633 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.