ODrive v3.x
Motor controllerLegacy dual-axis brushless motor control with public v3.x firmware; v3.6 board designs and newer-generation firmware have different openness boundaries. [1] [6] [8]
Build & first use →Official website
- For
- Developers maintaining or researching legacy ODrive v3.x systems [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
This profile covers the legacy ODrive v3.x platform, using the preserved fw-v0.5.6 source release and its v3.6 hardware documentation. The current upstream README says v3.x firmware is no longer actively developed. It separately states that firmware for newer products including Pro, S1 and Micro is not publicly available. The legacy repository cannot establish the openness or compatibility of those products. [2] [6] [8]
Is this for you?
- Known limitations
- Public legacy firmware does not imply public Pro, S1 or Micro firmware
- v3.6 board files and schematics are described as closed source
- Historical host installation instructions need compatibility checking
Version and artifact boundaries from upstream sources.
3D preview
ODrive v3.5 board assembly. The official ODrive v3.5 board STEP linked by the v3.x documentation. It does not represent the v3.6 board or newer ODrive Pro, S1 and Micro products; component sourcing and physical operation are not verified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Oskar Weigl / ODrive contributors, revision 079f30ac58f193226fcc552e4d6ba24553027ee1. Original and preview: MIT. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Operating system
- Windows
- macOS
- Linux
Historical documentation; current host dependency compatibility not tested.
- Host computer
Computer running Python-based odrivetool; historical setup covers Windows, macOS and Linux
- Dependencies
- One or two brushless motors and matching encoders
- Power source matched to the board voltage variant
- Braking-energy management, wiring and host computer
Hardware & parts
- Power
v3.6 variants: 12–24 V or 12–56 V input; identify the actual board variant
Assembly & first use
- Calibration
Configure motor and encoder parameters, save/reboot, run calibration without gravity or spring bias, inspect errors and tune closed-loop control.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Identify the board before using its limits
The v3.6 documentation distinguishes 24 V and 56 V variants, with listed input ranges of 12–24 V and 12–56 V respectively. It also says board files and schematics after v3.5 are closed source. Its linked v3.5 schematic and STEP model are therefore not a v3.6 manufacturing package. Public firmware, a board model and reproducible electronics are separate questions. [6]
The controller supports two motor axes, but the getting-started guide recommends beginning with one motor and encoder. Budget for the motor, feedback device, power source, wiring and braking arrangement as well as the controller. The complete delivered cost and current availability of a matched legacy setup were not verified. [5]
Commissioning depends on the motor and power system
USB does not power the board: the main supply is needed even for USB communication. Motor phase connections and a rigid encoder coupling must be established before calibration. Braking can return energy to the supply; the guide discusses a brake resistor and supply regeneration limits rather than assuming every power source can absorb that energy. [5]
The setup requires motor current and velocity limits, suitable calibration current, pole pairs, torque constant and encoder counts per revolution. Encoder counts are not interchangeable with pulses per revolution. Parameters are saved to persistent memory through a save operation that reboots the board. Brake-resistor configuration also requires saving and rebooting to take effect. [5]
Calibration measures motor electrical properties and encoder alignment while moving the rotor. The documented procedure allows inertia and weak friction but excludes a gravity or spring bias. Errors should be investigated before retrying; successful calibration is followed by closed-loop tuning. A communications watchdog exists but must be explicitly configured and enabled, so its presence in the code is not proof of an active stop-on-disconnection behavior. [5]
Preserve the software pairing
The archive contains Python-based odrivetool instructions for Windows, macOS and Linux. Those instructions include old Python examples and historical package-management advice. They are useful evidence of the original setup, not confirmation that an unpinned install works on a current computer. Record the board revision, firmware and host-tool versions together before changing an existing system. [2] [5]
The guide also distinguishes older boards requiring initial ST-Link flashing from later boards described as preflashed. That historical shipment description does not establish the state of a used board today. No firmware was built or flashed, host tool installed, or motor operated during this review. [5]
The selected firmware and repository software carry MIT licenses, with separate notices applying where present. This is a useful open legacy control stack for research and maintenance, with explicit limits on hardware design access and ongoing development. It is not a claim that every product sold under the ODrive name shares these sources. [3] [7] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | not found · License not fully assessed Selected v3.6: upstream says board files and schematics after v3.5 are closed source. Linked v3.5 schematic/STEP are a different revision and are not treated as v3.6 fabrication evidence. [6] |
| electronics | not found · License not fully assessed Selected v3.6: upstream says board files and schematics after v3.5 are closed source. Linked v3.5 schematic/STEP are a different revision and are not treated as v3.6 fabrication evidence. [6] |
| firmware | available · MIT Selected legacy repository sources; bundled third-party code and dependencies retain separate terms. [3] [4] [7] |
| software | available · MIT Selected legacy repository sources; bundled third-party code and dependencies retain separate terms. [3] [4] [7] |
| documentation | available · MIT Selected legacy repository sources; bundled third-party code and dependencies retain separate terms. [3] [4] [7] |
Selected motor-control route does not require a learned policy or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 odriverobotics/ODrive: README.md
Revision, date & where cited
github.com · revision
a308314· Accessed Oct 1, 2026
Used for: Assembly & first use - S002 odriverobotics/ODrive: commit a308314
Revision, date & where cited
github.com · Accessed Oct 1, 2026
Used for: Overview, Preserve the software pairing, What we checked - S003 odriverobotics/ODrive: LICENSE.md
Revision, date & where cited
github.com · revision
a308314· Accessed Oct 1, 2026
Used for: Preserve the software pairing, Source files and licenses - S004 odriverobotics/ODrive: files
Revision, date & where cited
github.com · revision
a308314· archive file inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S005 docs/getting-started.rst
Revision, date & where cited
github.com · revision
a308314· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S006 docs/specifications.rst
Revision, date & where cited
github.com · revision
a308314· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Identify the board before using its limits and 1 more - S007 Firmware/LICENSE
Revision, date & where cited
github.com · revision
a308314· Accessed Oct 1, 2026
Used for: Preserve the software pairing, Source files and licenses - S008 Current upstream maintenance and source-scope statement
Revision, date & where cited
github.com · revision
3a2e4dd· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Preserve the software pairing - S013 Upstream image and reuse attribution
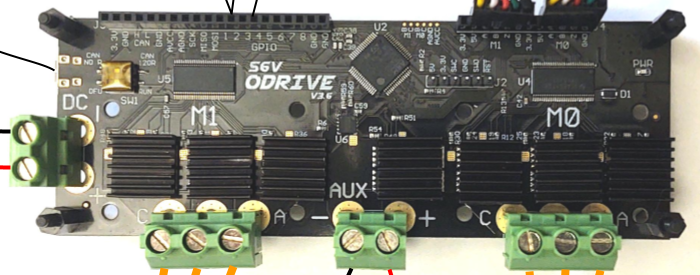
Media-only review: Photographic detail of the 56 V ODrive V3.6 board, cropped from the upstream basic-wiring illustration. Diagram lines remain at the edges; the firmware version is not established by the image. Reuse basis: MIT. This is an original board photograph incorporated into first-party basic-wiring documentation in the exact selected source snapshot. Root MIT notice expressly includes associated documentation; no narrower docs/ or image-specific license, exclusion or external photo credit appears in the pinned inventory or image. Full original wiring illustration retained, and original2016–2018 ODriveRobotics copyright/permission notice reproduced. This is not a relicense of a third-party product page or externally hosted image. The board itself visibly reads56V andV3.6, matching the selected3.6 generation; external wires, drawn connection lines and heatsinks remain visible. Earlier STLink photo readsV3.4 and is excluded. GUI voltage thumbnails show only labels and were excluded. Crop removes surrounding separate motors/power-supply photos without altering board pixels or diagram lines. No claim is made about installed firmware0.5.6, electrical testing, hidden components, current availability, or endorsement. Cropped to isolate the visibly marked56V ODriveV3.6 controller board from its wiring illustration from the source image; no retouching. Full original retained. Technical/cost evidence dates unchanged.Revision, date & where cited
ODrive Robotics / ODrive documentation contributors · github.com · revision
a308314· Pinned source , docs/figures/ODriveBasicWiring.png, board photograph rectangle x535..1235 y475..750; visible56V andV3.6 silkscreen.; image SHA-256 89857bd8b241770015b0d41910f100048131fd814b76bfdf198fcb7be5454f9e · Accessed Oct 26, 2026
Videos
- S009 High speed servo motor demo 2. (YouTube video)
Video from the project’s own channel (ODrive Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ODrive Robotics · youtube.com · Accessed Oct 4, 2026
- S010 ODrive two motor test (YouTube video)
Video from the project’s own channel (ODrive Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ODrive Robotics · youtube.com · Accessed Oct 4, 2026
- S011 ODrive powered shopping cart at MakerFaire 2018 (YouTube video)
Video from the project’s own channel (ODrive Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video ODrive Robotics · youtube.com · Accessed Oct 4, 2026
- S012 ODrive Robotics (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel ODrive Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 4 YouTube reference(s) (S009, S010, S011, S012): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.