MABEL
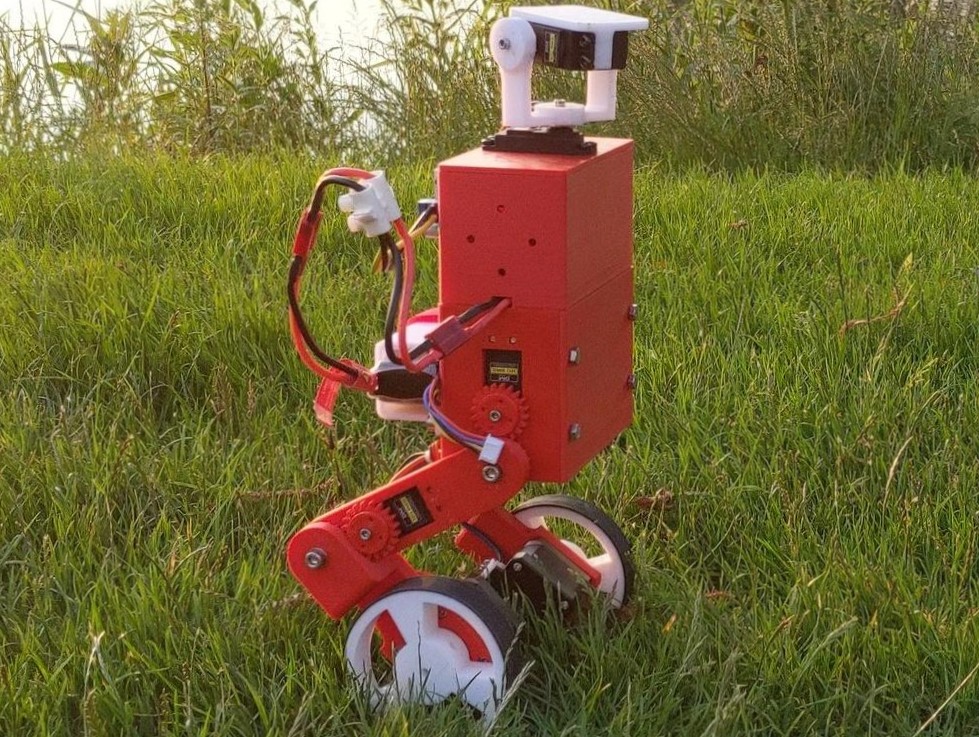
Robot / hardware buildWheeled balancing robot with articulated servo legs, Arduino balance firmware and Raspberry Pi inverse-kinematics examples; electronics and controller integration remain incomplete. [1]
Build & first use →Official websiteBill of materials
- For
- Builders able to complete electronics integration and tune balancing and servo control [1]
- Cost
- No current cost yet. Upstream bill of materials [1]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- GPL-3.0-only · license not fully assessed for firmware · Details by part
Overview
MABEL is a wheeled balancing robot with articulated legs. Its README assigns balance control to an Arduino using an MPU-6050, while Raspberry Pi code provides leg inverse kinematics and planned host functions. The available files make a useful mechanism and control reference, but the documentation does not establish a complete ready-to-run robot. [1] [4]
Is this for you?
- Known limitations
- Electronics assembly section is unfinished
- Input-controller code is described as future work
- IKDemo prints computed angles and does not by itself drive servos
- README board spelling PCA9865 needs reconciliation with the actual ServoKit-compatible hardware
- No physical balance, mobility or terrain-performance test performed
Direct source inspection; no assumed replacement board specification.
3D preview
MABEL assembly. Assembly geometry from the upstream STEP. Purchased components are represented; their manufacturing sources and physical fit are not established by this preview.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: raspibotics contributors, revision 81a43d78d79966e294b32c773acf14214ad88278. Original and preview: GPL-3.0-only. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Upstream bill of materials [1]
- Hardware configuration
Two-wheeled balancing robot with articulated servo legs.
- Actuators
- Two 38 mm NEMA17 stepper motors for wheels
- Six MG996R servos in the README BOM; four used in the documented leg assembly
- Controller
Arduino Uno for balancing and Raspberry Pi Zero W for host-side functions; purchased servo and stepper-driver boards.
- Power
README lists an 11.1 V 2800 mAh 3S LiPo and voltage regulation; complete electronics construction instructions are a placeholder.
Source BOM, not a verified power design or current sourcing recommendation.
Assembly & first use
- Inspect the provided CAD and mechanical BOM
- Complete the missing electronics plan for the chosen driver boards
- Determine build-specific servo homes and balancing calibration
- Explore IKSolve output separately from physical servo actuation
- Implement and test the remaining host/controller integration
Editorial work sequence for incomplete source project; not a reproduced build guide.
- Assembly
README provides five illustrated mechanical steps for bearings, servos, gears, stepper motors and leg joining; electronics assembly remains unfinished.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
What the build sources contain
The archive includes STL parts and files named MABEL.step and MABEL.f3z, plus a README BOM and five illustrated mechanical assembly stages. The CAD files have not been opened or checked for assembly completeness in this review. Those stages cover bearings, servo installation, gears, stepper motors and joining the leg sections. The BOM names a Raspberry Pi Zero W, Arduino Uno, two NEMA17 steppers, six MG996R servos, stepper drivers and an MPU-6050. Four servos appear in the described leg assembly, so the full BOM count should not be confused with the four leg-control angles. [1] [4] [9]
The electronics construction section is still a placeholder. The README also spells the servo controller as PCA9865 while linking to Adafruit ServoKit guidance; the exact board needs reconciliation with the selected hardware rather than silently correcting the document into an assumed specification. Its battery and regulator list is not a verified wiring or power design. No current complete delivered cost is established. [1]
An inverse-kinematics example is not the full controller
IKDemo.py reads requested coordinates, calls IKSolve and prints the returned angles. It does not itself command the servos. The README discusses optional input libraries and says controller code remains under development, so a builder still needs to complete that integration. [1] [7] [8]
The home angles in the example are explicitly build-specific. The supplied balance sketch likewise contains accelerometer calibration and PID parameters; copying those values is not evidence that another assembly is calibrated. No servo motion, sensor setup, balance test or terrain experiment was performed here. [1] [5] [7]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
Updates
- Upstream last updated
- Aug 18, 2020 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 81a43d78d79966e294b32c773acf14214ad88278 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · GPL-3.0-only Root repository GPL version 3 text; external components and inherited sources require separate provenance checks. [1] [3] [4] |
| electronics | not found · License not fully assessed Purchased-component BOM exists, but electronics construction section is placeholder text; no complete board-manufacturing set established. [1] |
| firmware | available · License not fully assessed YABR-derived sketches contain a warranty disclaimer while root repository carries GPL-3.0. Exact inherited-source licensing provenance is not fully resolved; do not treat the disclaimer alone as a complete license grant. [1] [3] [5] [6] |
| software | available · GPL-3.0-only Root repository GPL version 3 text; external components and inherited sources require separate provenance checks. [1] [3] [4] |
| documentation | available · GPL-3.0-only Root repository GPL version 3 text; external components and inherited sources require separate provenance checks. [1] [3] [4] |
Selected workflow uses PID balancing and inverse kinematics, not a trained model or dataset.
Source rights and completeness
The root repository contains GPL version 3 text. The balancing sketches derive from YABR according to the README and carry an embedded warranty disclaimer; this review has not fully resolved the inherited-source license chain. A disclaimer alone should not be treated as a complete reuse license. Purchased electronics and independent libraries also remain outside a blanket repository-license claim. [1] [3] [5] [6]
The practical distinction is between a documented mechanical starting point and a fully commissioned balancing robot. The first is present; the second requires electronics completion, controller integration and build-specific calibration beyond the evidence established here. [1] [7]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 raspibotics/MABEL: README.md
Revision, date & where cited
github.com · revision
81a43d7· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 raspibotics/MABEL: commit 81a43d7
- S003 raspibotics/MABEL: LICENSE
Revision, date & where cited
github.com · revision
81a43d7· Accessed Sep 30, 2026
Used for: Source files and licenses - S004 raspibotics/MABEL: files
Revision, date & where cited
github.com · revision
81a43d7· archive file inventory · Accessed Sep 30, 2026
Used for: Overview, What the build sources contain, Source files and licenses - S009 Complete pinned archive filename inventory
Revision, date & where cited
github.com · revision
81a43d7· filenames; presence does not establish completeness · Accessed Sep 30, 2026
Used for: What the build sources contain - S005 Pinned MABEL: arduino_code/Balancing_robot.ino
Revision, date & where cited
github.com · revision
81a43d7· Accessed Sep 30, 2026
Used for: What you need, Hardware & parts, Assembly & first use, An inverse-kinematics example is not the full controller and 1 more - S006 Pinned MABEL: arduino_code/YABR_hardware_test.ino
Revision, date & where cited
github.com · revision
81a43d7· Accessed Sep 30, 2026
Used for: Source files and licenses - S007 Pinned MABEL: raspi_code/IKDemo.py
Revision, date & where cited
github.com · revision
81a43d7· Accessed Sep 30, 2026
Used for: Is this for you?, Assembly & first use, An inverse-kinematics example is not the full controller, Source files and licenses - S008 Pinned MABEL: raspi_code/IKSolve.py
Revision, date & where cited
github.com · revision
81a43d7· Accessed Sep 30, 2026
Used for: Assembly & first use, An inverse-kinematics example is not the full controller - S010 Upstream image and reuse attribution
Media-only review: Upstream photograph of a MABEL robot build outdoors. Reuse basis: GPL-3.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
raspibotics and MABEL contributors · github.com · revision
81a43d7· Image SHA-256 41b24ae16a9c52080a7fd00353e1e25920b1586df587ead139c4b42d591605ed; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.