MAGPIE gripper
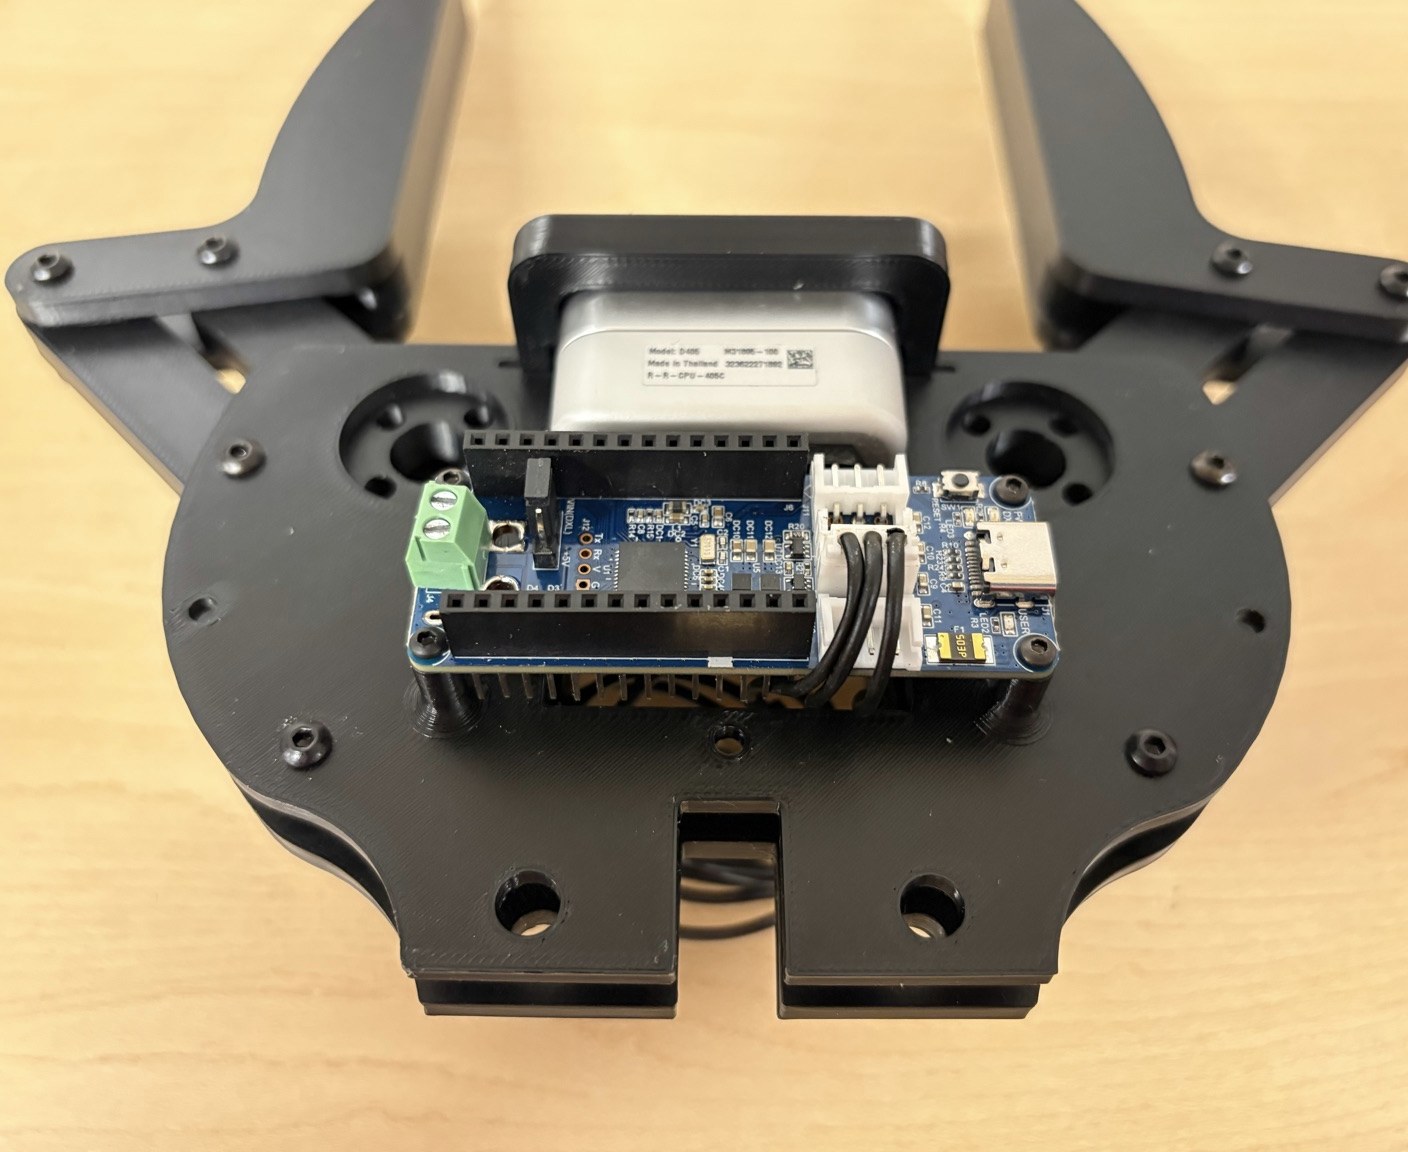
End effectorTwo AX-12A servos drive parallel fingers through four-bar linkages; OpenRB-150 control and a palm RealSense D405. [1] [2] [3] [4] [5] [6]
Build & first use →Official website
- For
- Builders evaluating this tooling design and its integration requirements [1] [2] [3] [4] [5] [6] [7] [8]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for documentation · Details by part
Overview
Is this for you?
- Known limitations
- V2 README flags identical top/bottom base exports despite differing assembly descriptions. Resolve that geometry before quoting or building. Software and host-arm mounting must match V2.
- No hardware build or test performed.
Source-researched; no physical verification.
Hardware & parts
Assembly & first use
Project documentation [1] [2] [3] [4] [5] [6] [7] [8]
- Assembly
V2 README flags identical top/bottom base exports despite differing assembly descriptions. Resolve that geometry before quoting or building. Software and host-arm mounting must match V2.
Known prerequisites and unresolved assembly decisions; not a complete build instruction.
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. Mesh files were identified. Their source inventory does not by itself establish assembly hierarchy or component placement.
Model sources
Mesh files were identified. Their source inventory does not by itself establish assembly hierarchy or component placement.
Project notes
Select the V2 parts
Start with Documentation/BOM.md and Documentation/assembly.md in the pinned hardware repository. The V2 list includes printed PLA parts, six bearings and M2/M3 fasteners. The upstream approximate total is $455.28; the displayed line amounts add to $455.27. The one-cent discrepancy does not make either number a current delivered quote. Currency region, supplier stock, tax, shipping and the full host-arm integration budget have not been verified. [4] [5]
The CAD README warns that the top and bottom base exports are identical even though their assembly descriptions differ. Check corrected geometry with the maintainer before printing or pricing a complete V2 build. [7]
Mounting and controls
The lab documents a UR5 setup, but that application does not establish that the pinned V2 parts fit an arbitrary Universal Robots arm. The hardware README points to correlllab/MAGPIE for control software; match that software revision, wiring and host-arm mount to V2 before operating it. [6] [3]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
030623a
Source files and licenses
MIT; current hardware README explicitly covers models and build documentation. V2 README flags identical top/bottom base exports despite differing assembly descriptions. Resolve that geometry before quoting or building. Software and host-arm mounting must match V2.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT MIT; current hardware README explicitly covers models and build documentation. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] [5] [6] [7] [8] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] |
| software | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] |
| documentation | available · License not fully assessed MIT; current hardware README explicitly covers models and build documentation. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] [5] [6] [7] [8] |
This profile scopes hardware tooling, without selecting a learned controller or training dataset.
Source rights and limits
The hardware README applies MIT terms to the models and build documentation, consistent with the root license. It also identifies separate MIT software. The matching control revision and source coverage of purchased servos, electronics and camera remain separate checks. No assembly or performance test has been performed for this profile. [2] [3]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 MAGPIE gripper pinned tree
Revision, date & where cited
github.com · revision
030623a· Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S002 MAGPIE gripper / LICENSE
Revision, date & where cited
correlllab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S003 MAGPIE gripper / README.md
Revision, date & where cited
correlllab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S004 MAGPIE gripper / Documentation/BOM.md
Revision, date & where cited
correlllab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Select the V2 parts and 1 more - S005 MAGPIE gripper / Documentation/assembly.md
Revision, date & where cited
correlllab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Select the V2 parts and 1 more - S006 magpie-ur
Revision, date & where cited
www.colorado.edu · colorado.edu · Captured 2026-09-30 · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and controls and 1 more - S007 CAD/README.md
Revision, date & where cited
correlllab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Overview, Assembly & first use, Select the V2 parts, Source files and licenses - S008 Documentation/README.md
Revision, date & where cited
correlllab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S009 Upstream image and reuse attribution
Media-only review: Upstream photograph of the MAGPIE gripper assembly. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Correll Robotics Lab and MAGPIE contributors · github.com · revision
030623a· Image SHA-256 6412e227855079f16abb812fdf1c9301ff420a8df7f32489671121de0206d078; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.