ROMI Rover
Robot / hardware buildAgricultural weeding rover with published prototype V3 design files and an adapted CNC weeding tool; unfinished electronics and steering details require configuration work. [5] [6]
Build & first use →Official website
- For
- Research builders able to reconcile prototype fabrication, electronics and field-operation requirements [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- CC-BY-SA-4.0 · Details by part
Overview
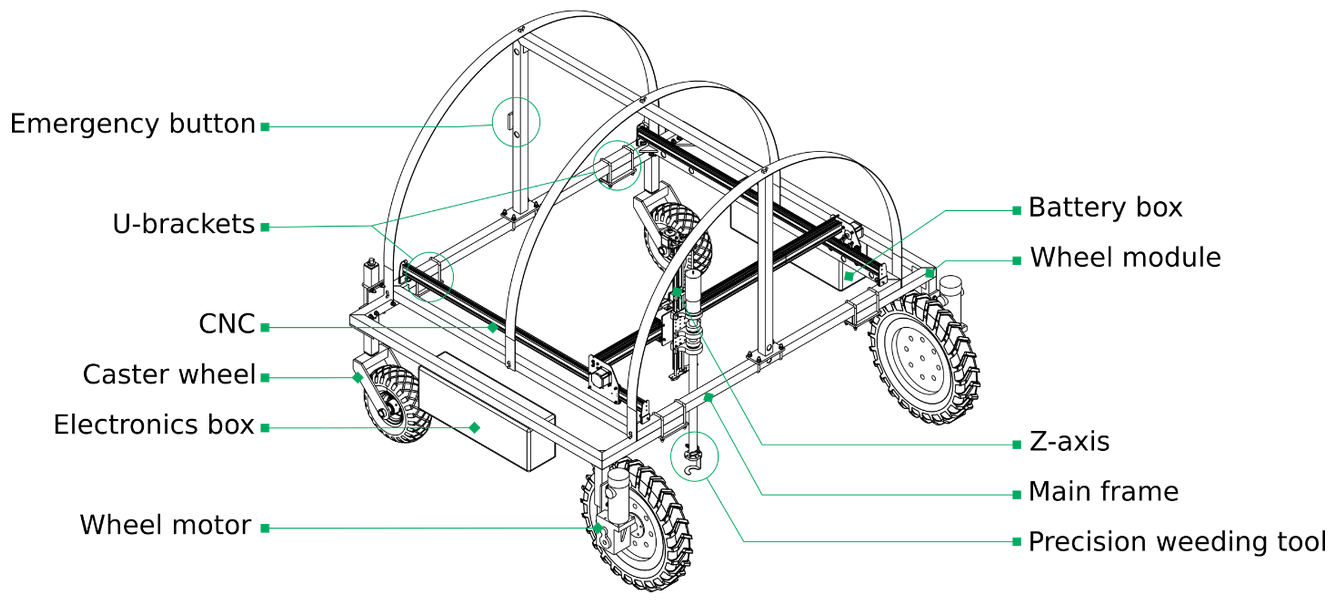
ROMI's hardware documentation identifies the selected design as the third rover prototype. It divides the system into a mobile rover and a weeding tool based on a 1000 mm X-Carve CNC, with a replacement z-axis and rotating hoe. The preserved design repository contains frame drawings, printed housings, steering parts, wiring diagrams and weeding-tool designs. [5] [6]
Is this for you?
- Known limitations
- Documentation mixes swivel-caster navigation with a provisional powered-steering design
- Wiring diagram marked for update and several custom PCB files unresolved
- Waterproof electronics housing is not established by the documented wooden prototype housing
- Separate rover and controller software payloads not preserved by this design review
What you need
- Host computer
Raspberry Pi 4 main computer; camera subsystem uses Raspberry Pi Zero 2 W.
Hardware & parts
- Hardware configuration
Field rover carrying an adapted 1000 mm X-Carve CNC and replacement weeding z-axis.
- Actuators
- 24 V brushed wheel motors, specified at minimum 200 W
- CNC stepper axes and rotating weeding hoe
- Separately described front-wheel steering uses NEMA 23 steppers with 1:77 gearboxes
- Controller
Raspberry Pi 4 with separate Arduino Uno controllers, Controllino power sequencing and Sabertooth 2x60A drive stage in the documented prototype.
- Sensors
- Wheel incremental encoders
- Pi Camera V2 in the documented camera module
- Absolute encoders in the separately described steering design
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. CAD files were identified. A configuration-matched assembly and its file-level reuse scope have not yet been verified for this preview.
Model sources
CAD files were identified. A configuration-matched assembly and its file-level reuse scope have not yet been verified for this preview.
Project notes
The fabrication files do not describe one finished production machine
The frame is documented through PDFs, including a replacement straight caster fork. Other components use a mixture of STL, DXF, SolidWorks, FreeCAD and OpenSCAD files. That is a useful source collection, but it is not evidence that every part has an editable native model or that every drawing belongs to a fully reconciled assembly. No CAD reconstruction or fabrication was performed here. [5] [6]
The hardware page specifies 24 V brushed wheel motors of at least 200 W and discusses incremental encoders and agricultural tires. It also records a mismatch between a four-hole wheel rim and a five-hole shaft interface that the authors addressed by drilling new holes. A buyer should not assume the named purchased parts join without modification. No current complete delivered BOM cost was verified. [5]
Reconcile the navigation and steering descriptions
One section describes differential drive with two powered rear wheels and front swivel casters. Another describes front steering using NEMA 23 steppers, 1:77 gearboxes and absolute encoders, while calling its couplings provisional and its controller not yet integrated into the electronics housing. Those sections should not be combined into a claim of a finished steering configuration. [5]
The same documentation says the battery and electronics housing was built from wood because an inexpensive waterproof solution had not been found. Its wiring diagram is marked for update, and several custom PCB files remain unfinished in the documentation. The preserved wiring SVGs establish diagram availability, not a complete waterproof or production-qualified electronics package. [5] [6]
The rover computer and tool controller have separate roles
The documented main computer is Raspberry Pi 4. The drive chain uses an Arduino Uno and Sabertooth 2x60A, while Controllino sequences the logic and motor-power circuits. The camera module is described separately with Pi Zero 2 W and Camera V2. These are prototype choices, not a validated set of current replacements. [5]
For the CNC, the authors prefer the older Arduino Uno and gShield arrangement using STEP/DIR control and Oquam firmware. They replace the original spindle with the weeding tool and its longer z-axis. The hardware page says some alternative tool-head designs have not been tested; their inclusion in the archive must not be read as field validation. [5]
The design repository uses CC BY-SA 4.0. Purchased hardware and separate software keep their own terms, and this review did not preserve a complete matched rover software or firmware stack. No fabrication, assembly, tool operation or field weeding trial was performed. [1] [3] [5] [6]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Sep 20, 2022 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 51f158eede08f50ac148ff24dee66763d6031d4a (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 Prototype frame PDFs, DXF, printed-part STL and some editable SolidWorks/FreeCAD/OpenSCAD designs; complete matching fabrication set not validated. [1] [3] [5] [6] |
| electronics | available · CC-BY-SA-4.0 Wiring SVGs preserved. Complete editable board/manufacturing sources are not established; documentation itself identifies unfinished board files and wiring updates. [3] [5] [6] |
| firmware | not found · License not fully assessed Separate rover, motor-controller and Oquam CNC firmware sources identified by official documentation but complete matched payload not preserved in this design review. [5] [6] |
| software | not found · License not fully assessed Separate rover, motor-controller and Oquam CNC firmware sources identified by official documentation but complete matched payload not preserved in this design review. [5] [6] |
| documentation | available · CC-BY-SA-4.0 Repository design drawings and overview. External hardware page preserved as evidence; its blanket licensing is not inferred from this separate repository. [1] [3] [6] |
Selected mechanical/electrical prototype profile does not assess perception models or training datasets.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 romi/romi-rover-design: README.md
Revision, date & where cited
github.com · revision
51f158e· Accessed Oct 1, 2026
Used for: Assembly & first use, The rover computer and tool controller have separate roles, Source files and licenses - S002 romi/romi-rover-design: commit 51f158e
- S003 romi/romi-rover-design: LICENSE.txt
Revision, date & where cited
github.com · revision
51f158e· Accessed Oct 1, 2026
Used for: The rover computer and tool controller have separate roles, Source files and licenses - S004 romi/romi-rover-design: files
Revision, date & where cited
github.com · revision
51f158e· archive file inventory · Accessed Oct 1, 2026 - S005 ROMI prototype V3 hardware documentation
Revision, date & where cited
romi / project contributors · docs.romi-project.eu · official hardware page preserved 2026-10-01T06:21:40.156260+00:00 · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 5 more - S006 Preserved ROMI design file inventory
Revision, date & where cited
github.com · revision
51f158e· complete archive file inventory · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Assembly & first use, The fabrication files do not describe one finished production machine and 3 more - S007 Upstream image and reuse attribution
Media-only review: Upstream annotated illustration of the ROMI Rover V3, showing its frame, wheel modules, CNC and precision weeding tool. This is a technical illustration, not a photograph. Reuse basis: CC-BY-SA-4.0. Actual official user manual identifies Rover V3 both in its opening edition statement and technical specification section, matching the selected prototype V3 hardware record. The same manual explicitly credits Sony CSL and grants CC BY-SA 4.0. Its own overview illustration has no separate exclusion; annotations retained. This replaces no prior image and is explicitly labeled an illustration, not a photographed or tested rover. Earlier 2018 first-prototype photographs remain excluded as wrong generation. No manual performance/price claims adopted. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Sony Computer Science Laboratories / ROMI · docs.romi-project.eu · ROMI Rover User Manual, Draft v2 - Rover V3 - Summer 2022, copyright/license near opening and Overview of the components illustration; image SHA-256 a9cb029a215b42a9d52618bde1b7f7ce821001620c7b1c1c1a728afc7f433930 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.