HRI Hand
End effectorSix linear actuators drive five fingers with coupled joints; NUCLEO-F303K8 control, Bluetooth and ROS support. [1]
Build & first use →Official website
- For
- Builders evaluating this tooling design and its integration requirements [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for documentation · Details by part
Overview
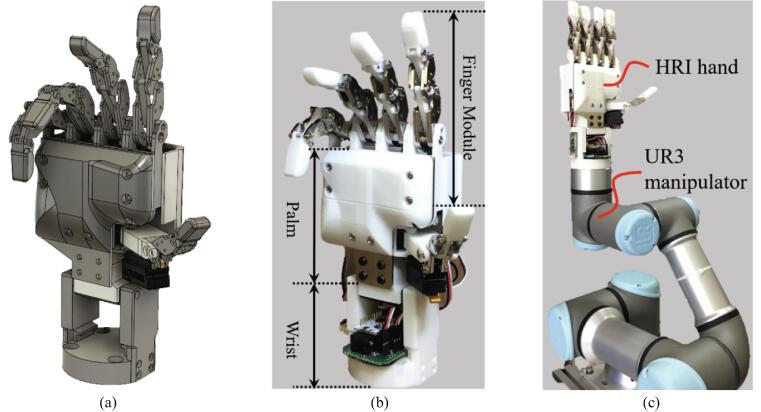
The HRI Hand paper describes five modular fingers driven by six linear actuators, with NUCLEO-F303K8 control, Bluetooth and ROS. It demonstrates mounting on a UR3 and specifies an ISO 9409-1-50-4-M6 wrist interface. That published configuration is distinct from a verified fit on another cobot. [1]
Is this for you?
- Known limitations
- The paper lists 19 hardware design entries including STEP files; match six-motor BOM, machined versus printed configuration and control revision. Paper prices are historical.
- No hardware build or test performed.
Source-researched; no physical verification.
[1] · Editorial assessment
3D preview
HRI Hand complete assembly. The complete HRI_Hand_all_asm STEP published by the project, including the palm, thumb, four repeated finger groups, wrist and ISO 9409-1-50-4-M6 interface. Source assembly groups and colors are retained. The UR3 arm, controller electronics, cabling and physical operation are not represented or verified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Hyeonjun Park, revision OSF file version 1, 2019-09-03. Original and preview: MIT. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
- Hardware configuration
Dexterous hands
Source-researched; no physical verification.
[1] · Editorial assessment
Assembly & first use
- Assembly
The paper lists 19 hardware design entries including STEP files; match six-motor BOM, machined versus printed configuration and control revision. Paper prices are historical.
Known prerequisites and unresolved assembly decisions; not a complete build instruction.
[1] · Editorial assessment
Cost
No current, complete configuration-specific build cost has been established for this profile.
Cost, measurements and source rights
Historical prices are internally scoped differently: the specifications table gives $400 for SUS304 processing, while the BOM lists $440.73 for processing alone and $420 for six actuators. Reconcile the printed or machined fabrication route and full BOM before treating any of those figures as a build total. [1]
Section 7 reports fingertip-force and joint-speed experiments for the authors’ configuration. Those are upstream results; neither the published performance nor an adapted build has been independently verified for this profile. [1]
The paper lists hardware, firmware, schematics and ROS resources under MIT. Confirm the notices and revisions of the selected artifacts before reuse; the paper’s list is distinct from independent verification of every current file. No hardware assembly or test was performed here. [1]
Project notes
Reproduce the paper’s configuration first
The BOM specifies PQ12 linear actuators with 20 mm travel, 100:1 gearing, 12 V and RC control. The paper’s power architecture uses a 12 V, 2 A supply and a step-down regulator for the controller. Its software procedure names Ubuntu 16.04 and ROS Kinetic; current compatibility is unverified. [1]
Begin with Tables 4–6 and the operation instructions. The paper lists 19 hardware design entries, including STEP files, and links a BOM spreadsheet, firmware and schematic repository and ROS repository. These are paper-listed resources; their present contents and cross-revision compatibility still need checking. [1]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- Upstream document snapshot accessed 2026-09-30
Source files and licenses
Paper explicitly lists hardware design files under MIT; reconcile artifact-specific OSF notices. The paper lists 19 hardware design entries including STEP files; match six-motor BOM, machined versus printed configuration and control revision. Paper prices are historical.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Paper explicitly lists hardware design files under MIT; reconcile artifact-specific OSF notices. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] |
| software | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] |
| documentation | available · License not fully assessed Paper explicitly lists hardware design files under MIT; reconcile artifact-specific OSF notices. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] |
This profile scopes hardware tooling, without selecting a learned controller or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 HRI Hand upstream documentation
Revision, date & where cited
pmc.ncbi.nlm.nih.gov · pmc.ncbi.nlm.nih.gov · Captured 2026-09-30 · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S002 Upstream image and reuse attribution
Media-only review: Upstream Figure 2 from the HRI Hand paper: a CAD view, the physical hand and the hand mounted on a UR3 arm. The UR3 is separate equipment. Reuse basis: CC-BY-4.0; inspected the published page, image caption and reuse footer; no image-specific exception found for this selected image. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Hyeonjun Park and Donghan Kim · cdn.ncbi.nlm.nih.gov · Image SHA-256 a569eab8985abe9ef6b199b5f16f5890d90c1dbf080b3b76036afdf14e2f19b1; source revision page SHA-256 e44afe9224c779d1ccca7ec0d5db8712255d247a454dee413fee750a61b72da3 · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.