LoCO AUV
Robot / hardware buildResearch autonomous underwater vehicle with Pixhawk, Raspberry Pi and Jetson TX2; this review selects the documented LoCO 1.0 configuration and separates later internal structure alternatives. [6] [8] [10]
Build & first use →Official website
- For
- Research teams able to fabricate, seal, ballast and maintain an underwater vehicle [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0, GPL-3.0-or-later · Details by part
Overview
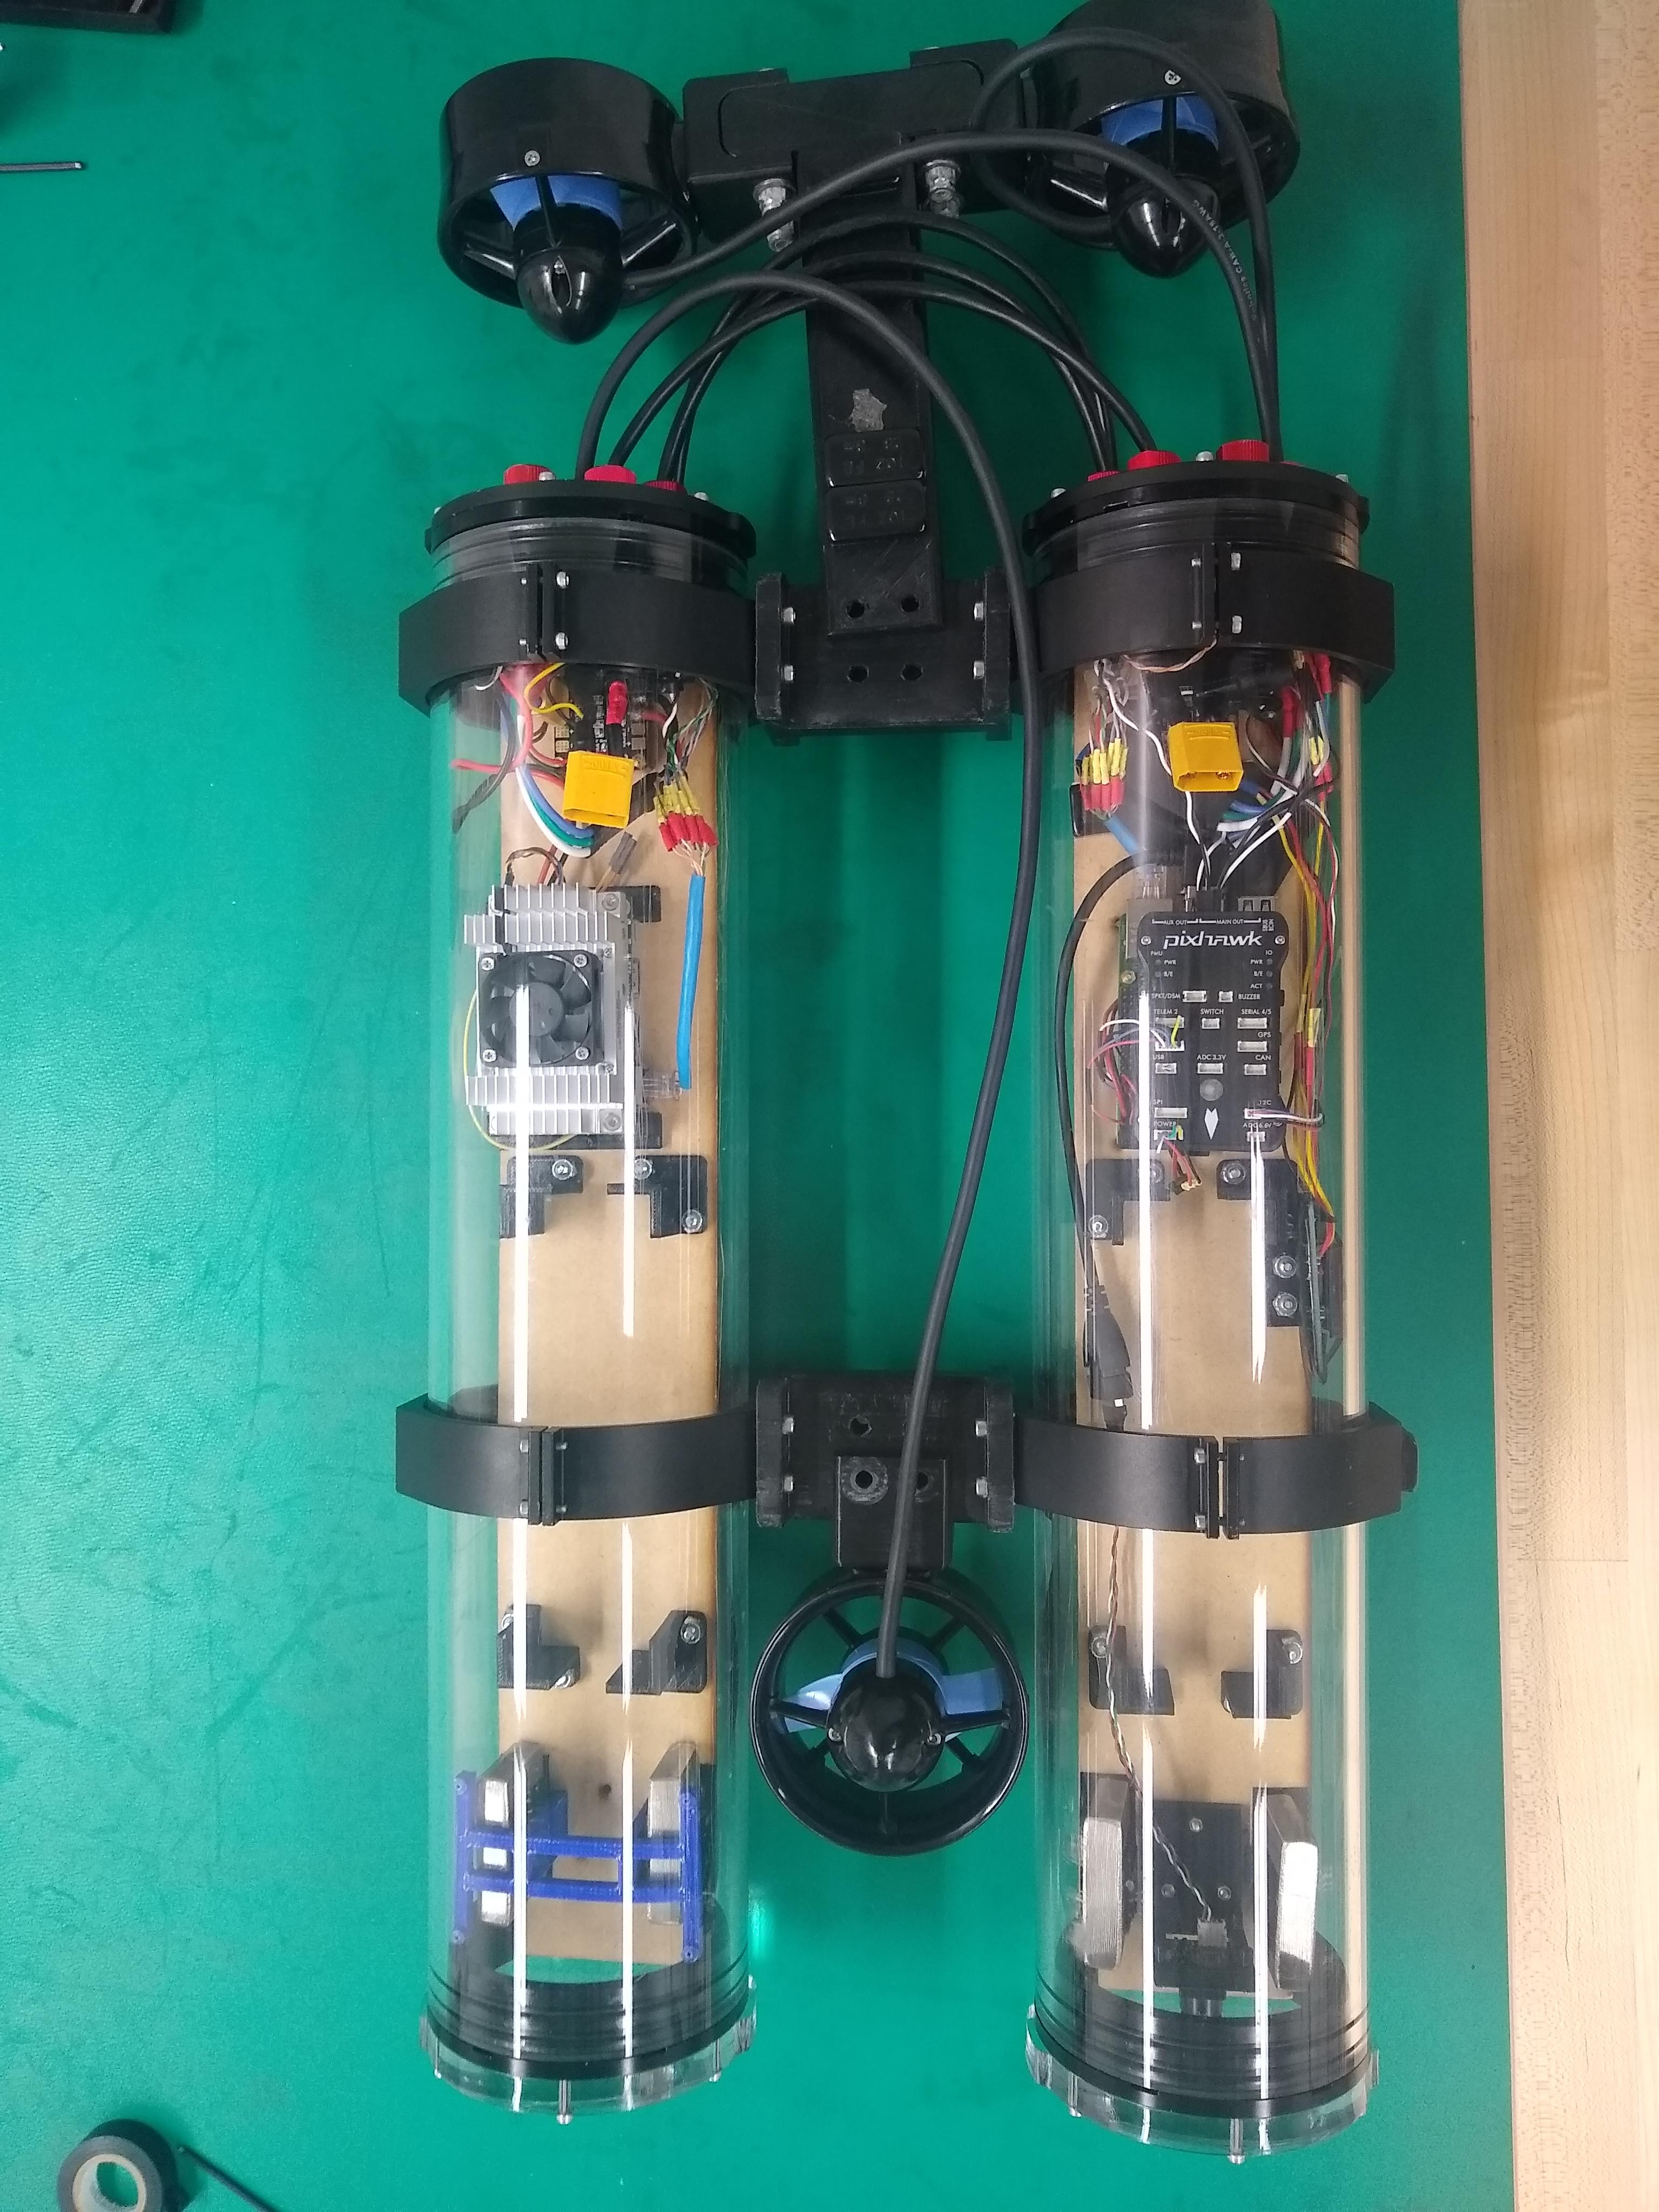
LoCO's configuration repository and separately preserved wiki document a research underwater vehicle. This entry selects the LoCO 1.0 route with Raspberry Pi 4, Pixhawk and Jetson TX2 on an Orbitty carrier. The wiki identifies itself as LoCO 1.0 documentation, but also includes alternative internal structures. Those alternatives need deliberate selection before purchasing or printing parts. [6] [8] [10]
Is this for you?
- Known limitations
- LoCO 1.0 capability page reports immature software, unsynchronized cameras and best-guess velocity autopilot
- External printed parts can take on water and change ballast
- Repository and wiki do not constitute a complete pinned software dependency set
- Upstream explicitly does not promise commercial-level support
3D preview
LoCO-AUV source visualization model. The first-party LoCO-AUV visualization model at zero thruster-joint positions. It combines the source shell mesh with simplified camera and thruster visuals; internal electronics, ballast and sonar geometry are not shown, and physical fit has not been verified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: LoCO-AUV contributors, revision a8c7efda7678d6e08a6be596cb55f32d00ebaf45. Original and preview: GPL-3.0 / CC-BY-SA-4.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
File units and internal structures need matching
The model archive contains SolidWorks parts and assemblies, printable STL files and laser-cut drawings. Its directory labels explicitly distinguish DXF files in inches, shell STL in meters and other STL files in millimeters. A file opening successfully in a fabrication tool does not establish that its scale is correct. No CAD dimensions or manufactured parts were validated here. [17]
The original internal structure uses laser-cut bases and printed mounts. The wiki's alternative uses printed sections for the computers, batteries and HREye electronics, with M3 screws and heatset inserts. It specifically describes the computer section as interfacing with the old-style Blue Robotics 4-inch flange. That is a compatibility boundary, not a promise that every current enclosure fits. [8]
The fabrication guide discusses print orientation, warping and drilling holes to final size. A later design note reports that small differences in battery dimensions can make the electronics difficult to slide into the tubes. The parts list alone cannot resolve those fit questions. [9] [14]
The computers, network and autopilot are separate integrations
The selected arrangement mounts the Pixhawk above the Raspberry Pi and places the Jetson TX2 on an Orbitty carrier. The Pixhawk guide calls for ArduSub and the SimpleROV-3 frame configuration, with sensor calibration and motor-direction checks. Its instruction to use the latest firmware is not an immutable version pin; this review did not flash or qualify a firmware release. [10] [11]
The network guide connects the Pi and TX2 internally and routes an external command computer through the Pi. It calls for connectivity checks before installation inside the enclosures. It also contains a subnet-description inconsistency: the prose repeats the external subnet name for the internal network, while the listed addresses distinguish them. Treat the saved configurations and actual network design as items to reconcile, not commands to copy without inspection. [12]
The TX2 package list includes separate repositories for launch files, robot description, menus, target detection and a diver-following CNN. Preserving loco_config does not preserve all of those packages, their revisions or model weights. No complete current software environment or delivered build budget was established. [13]
Research capabilities have documented limits
The LoCO 1.0 capability page reports unsynchronized cameras, an immature software stack and an autopilot based on estimated velocities. It also reports water uptake in external printed parts that can change ballast over time. These are upstream limitations for the selected documentation, not claims that every later implementation has the same behavior. [7]
The deployment guide covers ballast, seals, connectivity and bench checks; this review did not perform them or validate a depth rating. The project explicitly says it cannot guarantee help or provide commercial-level support. Hardware reproduction, underwater qualification and a support commitment therefore remain separate from source availability. [6] [16]
Project code uses GPLv3, with a later-version option in the wiki notice, while design documentation uses CC BY-SA 4.0. Purchased components and external software retain their own rights. No printing, assembly, installation, leak test or underwater trial was performed. [1] [3] [5] [15]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Jul 1, 2025 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- cf30cb1b4c875db19aa9e471c4fdbc30f248cd88 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 Project design grant; purchased-component CAD and rights require their own review. Unit labels and alternative internal structures must be reconciled. [1] [5] [8] [17] |
| electronics | not found · License not fully assessed Component integration described, but complete matching board manufacturing or firmware payload not established in this review. [10] [11] [17] |
| firmware | not found · License not fully assessed Component integration described, but complete matching board manufacturing or firmware payload not established in this review. [10] [11] [17] |
| software | available · GPL-3.0-or-later Configuration files and helper scripts; complete external ROS, perception and autopilot source set not preserved. Later-version permission stated in wiki license notice. [1] [3] [15] |
| model weights | not found · License not fully assessed External diver-following CNN is named; complete matching weights, data and licenses were not assessed in this hardware/configuration profile. [13] |
| datasets | not found · License not fully assessed External diver-following CNN is named; complete matching weights, data and licenses were not assessed in this hardware/configuration profile. [13] |
| documentation | available · CC-BY-SA-4.0 Design documentation license stated in wiki; wiki snapshot preserved separately from primary repository. [5] [6] [15] |
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 LoCO-AUV/loco_config: README.md
Revision, date & where cited
github.com · revision
cf30cb1· Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, Research capabilities have documented limits, Source files and licenses - S002 LoCO-AUV/loco_config: commit cf30cb1
- S003 LoCO-AUV/loco_config: LICENSE_GPLV3
Revision, date & where cited
github.com · revision
cf30cb1· Accessed Oct 1, 2026
Used for: Research capabilities have documented limits, Source files and licenses - S004 LoCO-AUV/loco_config: files
Revision, date & where cited
github.com · revision
cf30cb1· archive file inventory · Accessed Oct 1, 2026 - S005 Design license
Revision, date & where cited
github.com · revision
cf30cb1· Accessed Oct 1, 2026
Used for: Research capabilities have documented limits, Source files and licenses - S006 LoCO wiki: Home
Revision, date & where cited
github.com · preserved wiki Home.md · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Research capabilities have documented limits, Source files and licenses - S007 LoCO wiki: LoCO-1.0-Capabilities-and-Limitations
Revision, date & where cited
github.com · preserved wiki LoCO-1.0-Capabilities-and-Limitations.md · Accessed Oct 1, 2026
Used for: Is this for you?, Hardware & parts, Research capabilities have documented limits - S008 LoCO wiki: Fabricating-Internal-Structures
Revision, date & where cited
github.com · preserved wiki Fabricating-Internal-Structures.md · Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, File units and internal structures need matching and 1 more - S009 LoCO wiki: Fabricating-Structures
Revision, date & where cited
github.com · preserved wiki Fabricating-Structures.md · Accessed Oct 1, 2026
Used for: Assembly & first use, File units and internal structures need matching - S010 LoCO wiki: Computing-System-Assembly
Revision, date & where cited
github.com · preserved wiki Computing-System-Assembly.md · Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, The computers, network and autopilot are separate integrations and 1 more - S011 LoCO wiki: Configuring-the-PixHawk
Revision, date & where cited
github.com · preserved wiki Configuring-the-PixHawk.md · Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, The computers, network and autopilot are separate integrations, Source files and licenses - S012 LoCO wiki: Network-Configuration
Revision, date & where cited
github.com · preserved wiki Network-Configuration.md · Accessed Oct 1, 2026
Used for: What you need, The computers, network and autopilot are separate integrations - S013 LoCO wiki: TX2:-Required-ROS-Packages
Revision, date & where cited
github.com · preserved wiki TX2:-Required-ROS-Packages.md · Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Hardware & parts, The computers, network and autopilot are separate integrations and 1 more - S014 LoCO wiki: Design-Improvements
Revision, date & where cited
github.com · preserved wiki Design-Improvements.md · Accessed Oct 1, 2026
Used for: File units and internal structures need matching - S015 LoCO wiki: License-Information
Revision, date & where cited
github.com · preserved wiki License-Information.md · Accessed Oct 1, 2026
Used for: Research capabilities have documented limits, Source files and licenses - S016 LoCO wiki: Preparing-for-Deployment
Revision, date & where cited
github.com · preserved wiki Preparing-for-Deployment.md · Accessed Oct 1, 2026
Used for: Research capabilities have documented limits - S017 Model file paths and explicit unit labels
Revision, date & where cited
github.com · revision
cf30cb1· archive model inventory · Accessed Oct 1, 2026
Used for: File units and internal structures need matching, Source files and licenses - S018 Upstream image and reuse attribution
Media-only review: Upstream photograph of a LoCO autonomous underwater vehicle assembly. Reuse basis: CC-BY-SA-4.0; inspected LICENSE_SHAREALIKE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
LoCO AUV contributors · github.com · revision
cf30cb1· Image SHA-256 8124de223730e4922be5e1c14375f8dc64a027bf0174cca634f00a2e19f2a564; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.