Grip4SO101
End effectorA printable replacement gripper for SO-101 that reuses the original gripper motor. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
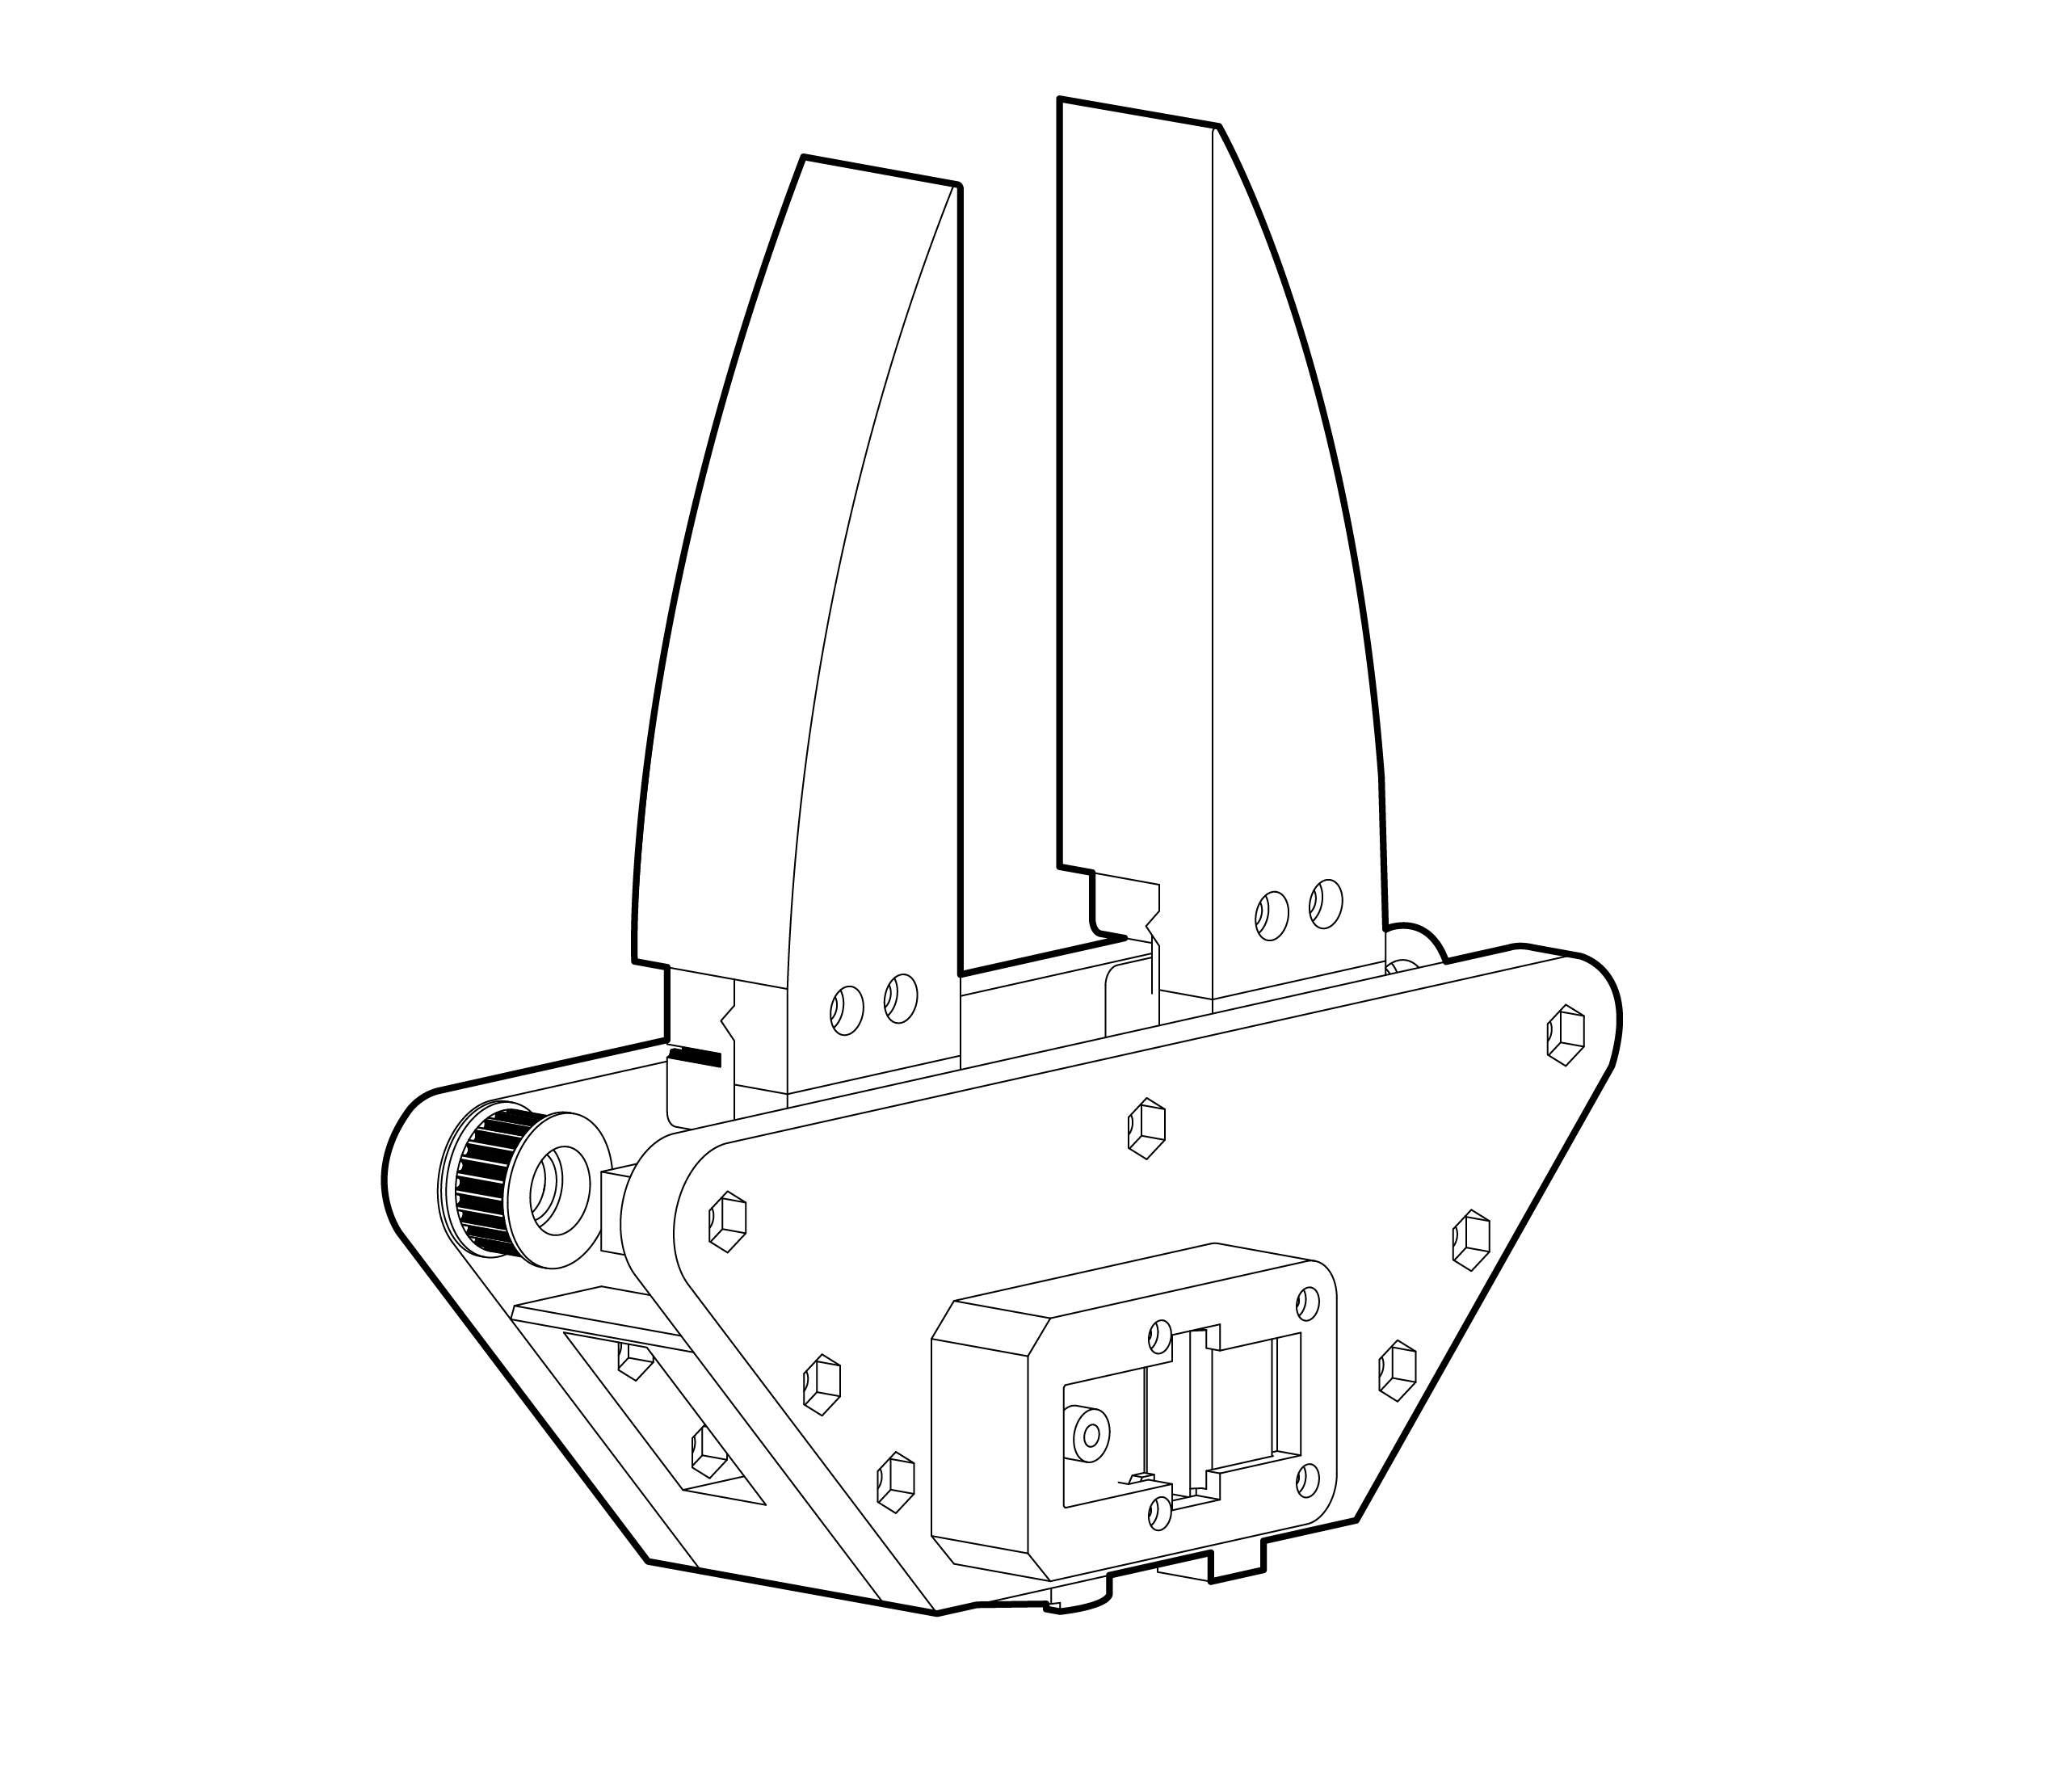
Grip4SO101 is a replacement end effector for an existing SO-101 arm. Its materials list explicitly reuses the arm's motor and M2 × 6 mm screws, so a shopping list for this attachment is not a complete standalone gripper or robot budget. The repository includes a STEP assembly, printable meshes and an image-based assembly sequence. [1] [3]
Is this for you?
- Known limitations
- Reconcile rail/carriage quantities and screw assortment; measure installed mass/stroke and calibration limits; quote components and printing separately from the existing arm.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
3D preview
Grip4SO101 gripper model. Assembly geometry from the upstream STEP. Purchased components are represented; their manufacturing sources and physical fit are not established by this preview.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: XiujinLiu contributors, revision 8dd3a2328e7eee866abd5aa85895ca51c1c2a643. Original and preview: MIT. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Electric grippers
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Parts to reconcile before ordering
The README lists five 12 × 18 × 4 mm bearings, four 3 × 10 × 4 mm bearings, a 6 mm GT2 belt, a screw-and-nut assortment and two entries' worth of the specified 150 mm MGN7C rail/carriage item. Check the linked item's package contents against the assembly before treating that quantity as an orderable rail-and-carriage specification. The fastener assortment also needs an exact count for a reproducible hardware pack. [1]
Print files are separated into parts requiring 15% and 100% infill. After assembly, the upstream procedure replaces the original SO-101 gripper and directs the builder to SO-101 calibration and teleoperation instructions. That documents the intended integration; it does not establish tested compatibility across motor, arm and software revisions. [1]
What remains unknown
No configuration-specific cost, delivered supplier quote, installed mass, grip force or usable stroke has been verified here. A useful first build check would reconcile the hardware quantities, verify mechanical travel and repeat calibration before measuring grasp performance. The repository states MIT licensing; that statement applies to its project files and does not relicense the purchased servo or the rest of the arm. This profile is source research only. [1] [2]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 8dd3a2328e7eee866abd5aa85895ca51c1c2a643; Pinned repository commit; SO-101 replacement using its existing motor
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Root MIT license and README project-license statement. Purchased motor/electronics remain separately scoped. [1] [2] [3] |
| electronics | not found · License not fully assessed A complete configuration-matched source set for this layer is not established by this review; purchased parts and linked repositories must be assessed separately. This is not a claim that the layer is closed source. [1] [2] [3] |
| firmware | not found · License not fully assessed A complete configuration-matched source set for this layer is not established by this review; purchased parts and linked repositories must be assessed separately. This is not a claim that the layer is closed source. [1] [2] [3] |
| software | not found · License not fully assessed A complete configuration-matched source set for this layer is not established by this review; purchased parts and linked repositories must be assessed separately. This is not a claim that the layer is closed source. [1] [2] [3] |
| documentation | available · MIT Root MIT license and README project-license statement. Purchased motor/electronics remain separately scoped. [1] [2] [3] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 XiujinLiu/Grip4SO101: README.md
Revision, date & where cited
github.com · revision
8dd3a23· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 XiujinLiu/Grip4SO101: LICENSE
Revision, date & where cited
github.com · revision
8dd3a23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, What remains unknown and 1 more - S003 XiujinLiu/Grip4SO101: files
Revision, date & where cited
github.com · revision
8dd3a23· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Assembly & first use and 1 more - S005 Upstream image and reuse attribution
Media-only review: Upstream line illustration of the Grip4SO101 gripper attachment, not a photograph. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Xiujin Liu and Grip4SO101 contributors · github.com · revision
8dd3a23· Image SHA-256 a8ead4ca32d8fe82e26992dc496efae1bbdb5a0a96a6825687707d5a9a28df30; repository · Accessed Oct 25, 2026
Videos
- S004 How to make a Robot Arm Gripper (YouTube video)
Video uploaded by Skyentific, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Skyentific · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 1 YouTube reference(s) (S004): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.