FlexiCup
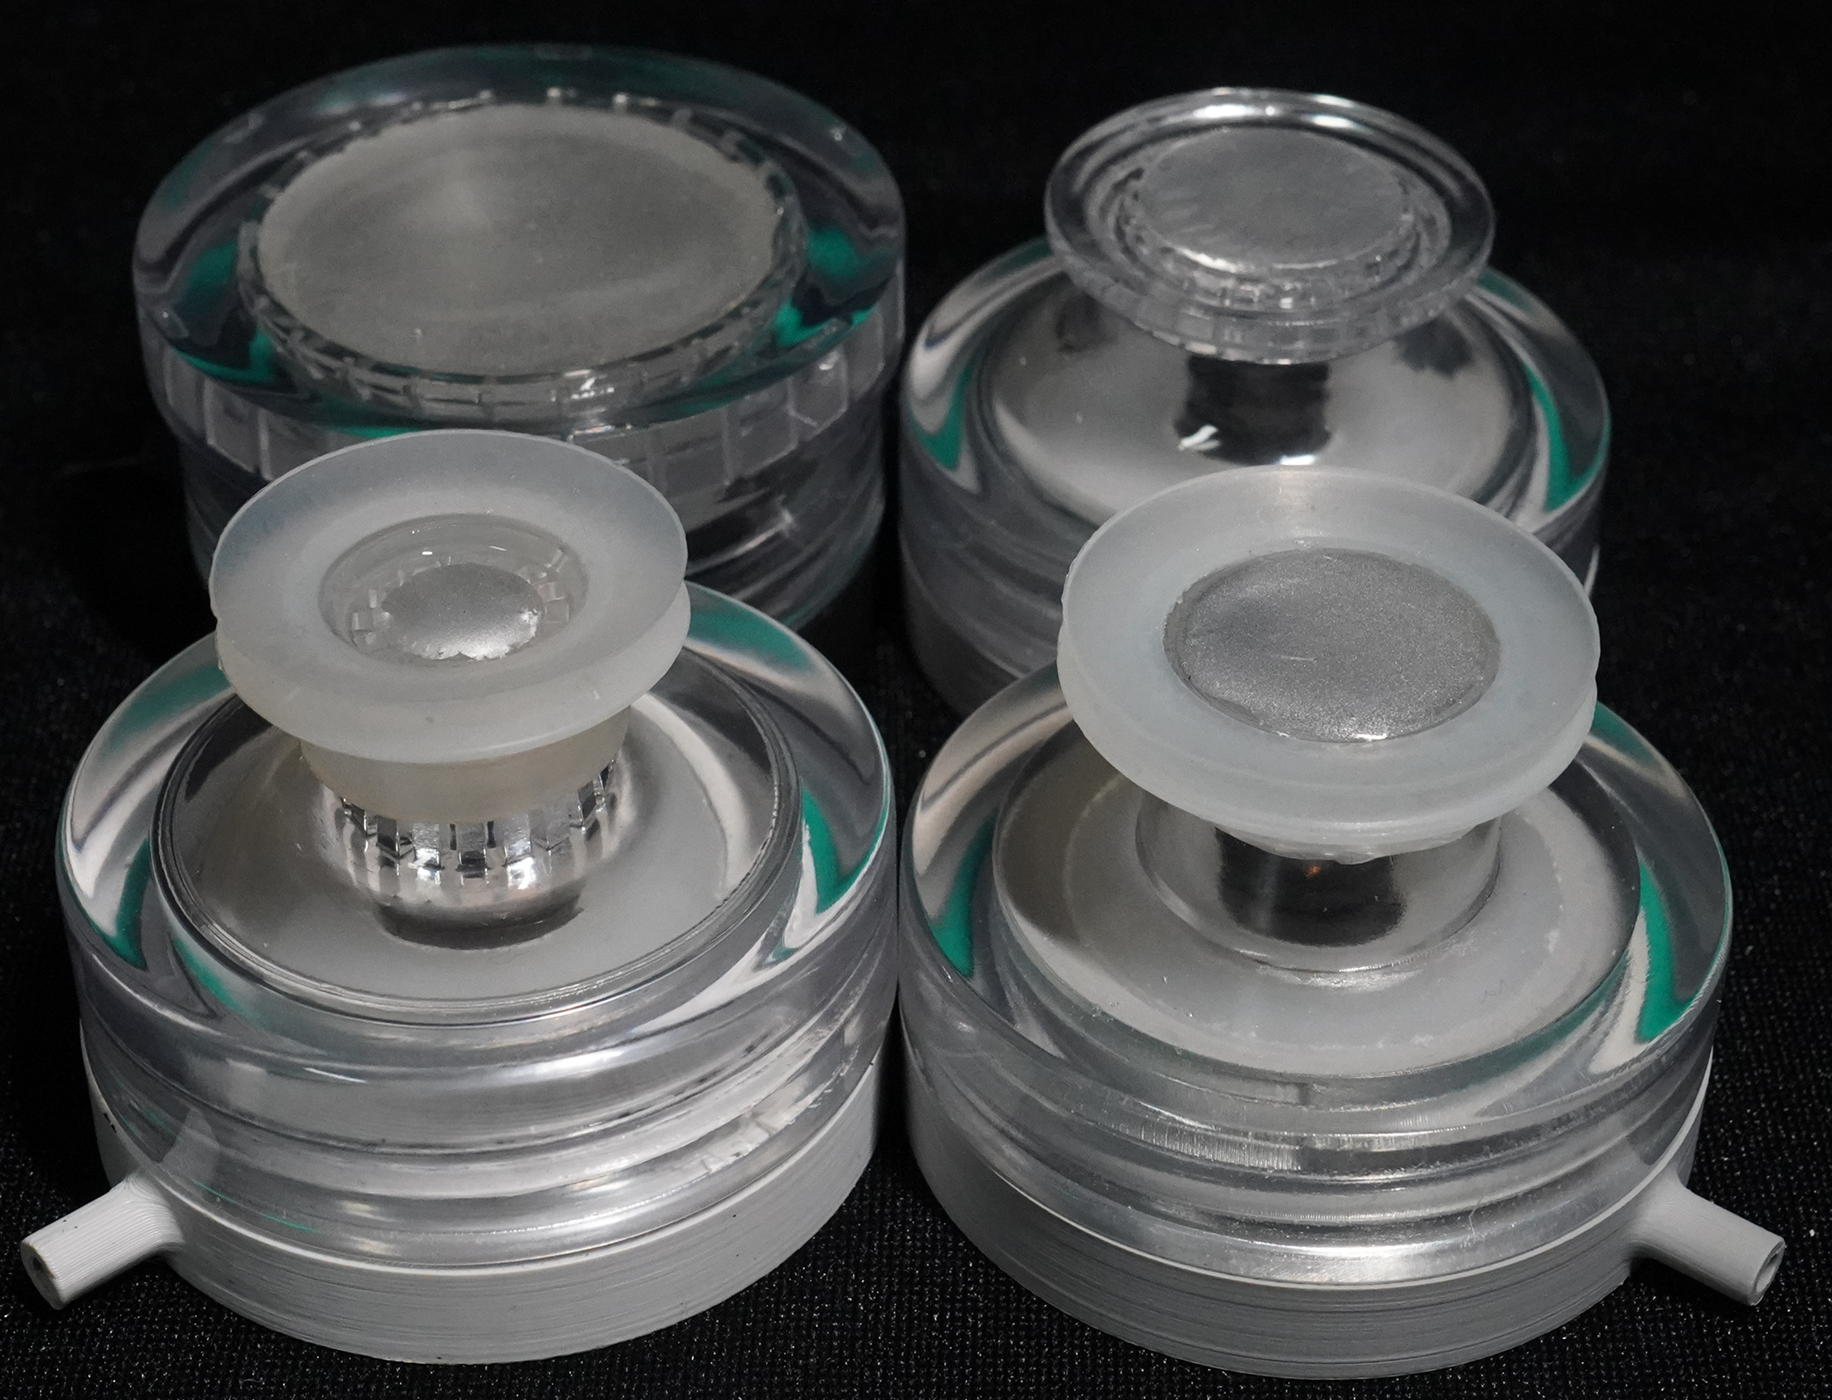
End effectorA suction cup combining vision and tactile sensing with wireless electronics. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0 · Details by part
Overview
FlexiCup combines suction with vision and tactile sensing. Its shared sensing structure supports two different pneumatic routes: vacuum for sustained-contact adhesion and Bernoulli actuation for contactless lifting. Select the actuation mode before sourcing air equipment or choosing the bottom assembly. [1] [4]
Is this for you?
3D preview
Suction cup top. One suction-cup top component. The complete gripper, camera and pneumatic system are not included in this selected file.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: FlexiCup project contributors, revision 0a23196e7b3afa5f6bdf7738558609f956016b69. Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Suction and sensing
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
- Assembly
Choose suction mode, fabricate resin and silicone/optical elements, fabricate PCB, flash ESP32-S3 firmware, configure Wi-Fi and calibrate sensing; learning pipeline is a separate setup.
Research synopsis of upstream route; not independently executed instructions.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Start with the selected assembly
The reviewed revision is 0a23196e7b3afa5f6bdf7738558609f956016b69. Start with Hardware/Fabrication/CAD/FlexiCup_CAD_BOM.xlsx and Hardware/Fabrication/PCB/FlexiCup_PCB_BOM.xlsx, then match the assembly and circuit to that revision. Bottom configurations I–II are for vacuum and III–IV for Bernoulli operation. [1] [3] [4]
Upstream describes a 750 W, 140 L/min vacuum pump with −90 kPa maximum vacuum, and an 800 W, 65 L/min compressor at 0.8 MPa for the other mode. These describe its reported equipment, not independently verified minimum requirements. Solenoid valves, connections and the selected supply still need procurement reconciliation. The fabrication guide describes a PLA FDM top housing; other optical and elastomer parts require their own material and fabrication checks. [4] [5]
Electronics and reuse boundaries
The repository lists PCB manufacturing files, ESP32-S3 firmware and a learning pipeline. File presence does not establish a complete revision-matched electronics, firmware or software setup; matching weights and data also remain unverified. No universal arm mount or pneumatic interface is assumed. [1] [3]
CC BY-SA 4.0 is the README's project-level declaration. Bundled diffusion and camera components have separate license files, whose terms were not fully assessed here; do not treat the README declaration as blanket coverage for those components. Consult those notices before reuse. No current complete cost, hardware build or performance test is established by this profile. [1] [3]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 0a23196e7b3afa5f6bdf7738558609f956016b69; Commit snapshot; vacuum and Bernoulli modes retained separately
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 README states CC BY-SA 4.0 project license; bundled diffusion and camera components contain separate licenses. [1] [2] [3] [4] [5] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| model weights | not found · License not fully assessed No complete matched external training-data/weight set verified for this configuration. [1] [2] [3] [4] [5] |
| datasets | not found · License not fully assessed No complete matched external training-data/weight set verified for this configuration. [1] [2] [3] [4] [5] |
| documentation | available · CC-BY-SA-4.0 README states CC BY-SA 4.0 project license; bundled diffusion and camera components contain separate licenses. [1] [2] [3] [4] [5] |
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 JUMP-HOWL/FlexiCup: README.md
Revision, date & where cited
github.com · revision
0a23196· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 JUMP-HOWL/FlexiCup: README.md
Revision, date & where cited
github.com · revision
0a23196· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Source files and licenses - S003 JUMP-HOWL/FlexiCup: files
Revision, date & where cited
github.com · revision
0a23196· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Start with the selected assembly and 2 more - S004 hardware
Revision, date & where cited
github.com · revision
0a23196· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Assembly & first use and 2 more - S005 fabrication
Revision, date & where cited
github.com · revision
0a23196· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Start with the selected assembly and 1 more - S006 Upstream image and reuse attribution
Media-only review: Upstream photograph of FlexiCup suction-cup assemblies. Reuse basis: CC-BY-SA-4.0; inspected README.md and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
JUMP-HOWL and FlexiCup contributors · github.com · revision
0a23196· Image SHA-256 1a6d77afb9b1d2ac9fa7cc492965594d06eaec6d8f7b1aab2d469407f525379b; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.