K-Bot
Robot / hardware buildA public-alpha humanoid project whose CAD, operating system, simulation and inference code live in separate sources. [1]
Build & first use →Official website
- For
- Experienced humanoid developers; Research teams able to maintain an evolving platform [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- CERN-OHL-S-2.0, Conflicting declarations: README GPL v3; root LICENSE MIT · license not fully assessed for documentation · Details by part
Overview
K-Bot's primary README describes the project as public alpha and warns of breaking changes. Its mechanical notes emphasize replaceable hands and head hardware, but those design goals are not evidence of measured repair time or a complete self-build kit. The main repository points to an external Onshape publication and electrical documentation; it does not itself contain a complete robot manufacturing pack. [1] [4] [5] [6]
Is this for you?
3D preview
K-Bot v2 simplified simulation model (kbot-v2-lw-feet). The simplified K-Bot v2 simulation model kbot-v2-lw-feet (robot.mjcf, loaded through scene.mjcf) from the K-Scale Labs kscale-assets repository at commit 4aa9ff9. This is the exact asset revision pinned by the K-Bot hardware repository at commit 76aba70 through its ksim-kbot training submodule (commit e7681a1), whose standing task loads this folder. Shown at the source reference pose with the 20 hinge joints at zero: 23 bodies with 20 link meshes, the two box feet and the 10 mm base marker sphere defined by the model (188,496 triangles, no further decimation). The STL headers say Created by Open3D and every link mesh has at most 10,000 triangles: this is simplified simulation geometry, not the Onshape publication CAD. Link meshes named after RS03 actuators may include modeled vendor actuator housings whose third-party terms are unknown. The asset repository has no license notice; see the license note. No manufacturing or redistribution clearance is claimed. Fit and motion are not verified.
No license identified: the kscale-assets repository at commit 4aa9ff9 contains no LICENSE, NOTICE or license statement. The K-Bot hardware repository that pins it (kbot at commit 76aba70) states “The hardware components of this project are licensed under CERN-OHL-S while the software components are licensed under GPL v3, unless otherwise specified” (LICENSE-HW: CERN Open Hardware Licence Version 2 - Strongly Reciprocal), and the ksim-kbot training repository is MIT-licensed (“Copyright (c) 2023 K-Scale Labs”). Which notice, if any, governs these simulation meshes is not stated. Open Source Robotics shows the model for reference with attribution to K-Scale Labs under its policy for missing or ambiguous licenses and keeps the CERN-OHL-S-2.0 notice with the hosted files. Modeled vendor actuator housings have unknown third-party terms. No manufacturing or redistribution clearance is claimed. License: none in kscale-assets; parent K-Bot hardware LICENSE-HW (CERN-OHL-S-2.0) · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original MJCF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: K-Scale Labs, revision 4aa9ff9118eb479411b276b549732c8daaea4b75. Original and preview: No license identified in kscale-assets (parent kbot: CERN-OHL-S-2.0 hardware / GPL-3.0 software; ksim-kbot: MIT). Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. Source visual shapes and body transforms evaluated at the reference pose by MuJoCo, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Keep the three software components at known revisions
The project references kos-kbot, ksim-kbot and kbot-inference as submodules. Its development instructions suggest updating submodules to their latest master branches. For catalog preservation, we captured parent commit 76aba70e3372 and its referenced components: inference 9c7e382115c9, OS 3669244d6b67 and simulation e7681a1b908f. The full hashes are retained in the linked source references. That retains the starting point without claiming those versions have been tested together. The simulation component also requests a recursive assets checkout, so nested dependencies still need separate preservation. [1] [7] [9] [10] [11]
The operating-system component draws a useful distinction between a native build with stub features and a hardware cross-build targeting aarch64 Linux. A successful stub build would not establish robot operation. The inference overview also defines actuator-direction conventions, which would need to agree with the hardware and calibration before a future motion test. No code was built or executed during this review. [9] [10]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Nov 7, 2025 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 76aba70e3372fecf3583ed6dbe5f379d44c8511c (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-S-2.0 Root hardware declaration; external editable CAD export and complete BOM not preserved/matched here. [1] [5] [8] |
| electronics | available · CERN-OHL-S-2.0 Primary archive links external electrical documentation; its current contents and manufacturing pack remain unverified. [1] [6] [8] |
| firmware | not found · License not fully assessed Complete matched actuator firmware source and update procedure not established by this review. [4] [7] |
| software | available · Conflicting declarations: README GPL v3; root LICENSE MIT README declares GPL v3 but root LICENSE contains MIT text; parent scope unresolved. Pinned kos-kbot and ksim-kbot have MIT terms. [1] [3] [10] |
| model weights | not found · License not fully assessed Complete payload and license set for a specified learned behavior not established in inspected overview/submodules. [4] [9] [11] |
| datasets | not found · License not fully assessed Complete payload and license set for a specified learned behavior not established in inspected overview/submodules. [4] [9] [11] |
| documentation | available · License not fully assessed Primary overview and mechanical notes; detailed external guide not fully inspected. [1] [5] [6] |
Preserve license boundaries and missing build inputs
The parent README declares CERN-OHL-S for hardware and GPL v3 for software unless otherwise specified, but its root LICENSE contains MIT text. That parent software-license conflict remains unresolved. The pinned kos-kbot and ksim-kbot components separately contain MIT terms. Clarify the conflicting parent declarations and retain each component's terms before relying on them for redistribution or an offer. [1] [3] [8] [10] [11]
A build-selection decision still needs an exact CAD export, electrical pack, configuration-specific BOM, firmware set and current delivered cost. The available source references support further research; our assembly, repair and support capability remains untested. [4] [5] [6] [7]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 kscalelabs/kbot: README.md
Revision, date & where cited
github.com · revision
76aba70· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 kscalelabs/kbot: commit 76aba70
- S003 kscalelabs/kbot: LICENSE
Revision, date & where cited
github.com · revision
76aba70· Accessed Sep 30, 2026
Used for: Source files and licenses - S004 kscalelabs/kbot: files
Revision, date & where cited
github.com · revision
76aba70· archive file inventory · Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S007 .gitmodules
Revision, date & where cited
github.com · revision
76aba70· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S008 LICENSE-HW
Revision, date & where cited
github.com · revision
76aba70· Accessed Sep 30, 2026
Used for: Source files and licenses - S006 electrical/README.md
Revision, date & where cited
github.com · revision
76aba70· Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S005 mechanical/README.md
Revision, date & where cited
github.com · revision
76aba70· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S009 Pinned kbot-inference
Revision, date & where cited
github.com · revision
9c7e382· Exact submodule commit; nested dependencies not guaranteed included · Accessed Sep 30, 2026
Used for: Keep the three software components at known revisions, Source files and licenses - S010 Pinned kos-kbot
Revision, date & where cited
github.com · revision
3669244· Exact submodule commit; nested dependencies not guaranteed included · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S011 Pinned ksim-kbot
Revision, date & where cited
github.com · revision
e7681a1· Exact submodule commit; nested dependencies not guaranteed included · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S013 Upstream image and reuse attribution
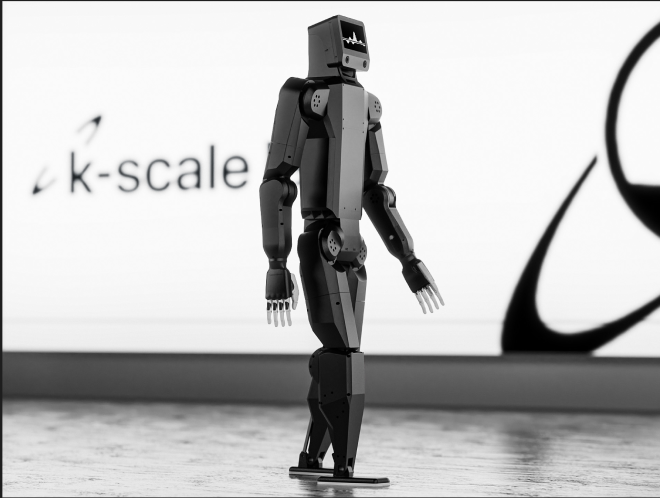
Media-only review: Upstream studio illustration of K-Bot from the selected public-alpha repository snapshot. This is not a physical-build photograph. Reuse basis: MIT. This is an original first-party K-Bot illustration directly embedded by the README in the exact selected public-alpha source snapshot, not a later robot generation or independently sourced image. AllsixWEBPimages were visually inspected: CGI/studio-style views, not establishedphysicalrobotphotographs. It is therefore explicitly labeledillustration and notPhoto. The exactselectedrootLICENSE containsMITCopyright(c)2025KScaleLabs and includesassociateddocumentationfiles. README retains olderCERNhardware/GPLsoftware wording, while actualrootLICENSE was explicitly changedtoMIT inJune2025; mediareuse reliesonactualspecificMITfile coveringassociatedREADMEillustration,notmanufacturingrights. LICENSE-HW remainsseparateCERNhardwareterms;nomedia-specificexclusionornarrowerassetslicenseappearsinselectedtreeorimage. No claim is made that allhardwareisMITor thatrenderedhands,joints,dimensions,internalassembly,electronics or softwarewerebuilt/tested. ProjectidentificationcomesfromREADMEimagealtK-Bot at exactreviewedpin. Cropisolatesonecompleteupstreamstudioimagefromitscollage,withoutretouching;fulloriginalWEBP retainedandMITcopyright/permissionnotice reproduced. Noothercardusesthisimage. Cropped to isolate one complete K-Bot studio illustration from the source image; no retouching. Full original retained. Technical/cost evidence dates unchanged.Revision, date & where cited
K-Scale Labs / K-Bot project contributors · github.com · revision
76aba70· Exactselected76aba70e3372fecf3583ed6dbe5f379d44c8511cREADME embedsassets/pics/e.webp asK-Bot; fullrobotupperrightpanelcrop955,7,1615,505; rootMITCopyright(c)2025KScaleLabs.; image SHA-256 4ca4ae5fea851e9179a1d28cea2e6f574e4b3223c2adb17710481e4bacafefe2 · Accessed Oct 26, 2026
Videos
- S012 What’s Inside K-Bot? Full Hardware Breakdown (YouTube video)
Video from the project’s own channel (K-Scale Labs), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video K-Scale Labs · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S012): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.