Yeah Hand
End effectorYeah Hand/Rebelia lineage: humanlike hand with separate robot/prosthetic firmware and commercial servos. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11]
Build & first use →Official website
- For
- Builders evaluating this tooling design and its integration requirements [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- CERN-OHL-S-2.0 · license not fully assessed for documentation · Details by part
Overview
Yeah Hand provides robotic and prosthetic hand configurations with different controls. This entry also retains the related Rebelia V1 lineage as version context, rather than treating it as a separate independent design. Select the configuration before matching firmware, electronics and released geometry. [3] [5] [9]
Is this for you?
3D preview
Yeah Hand v1.2 left robotic configuration. The Yeah Hand v1.2 left-side robotic configuration assembled from 16 official hierarchic STL groups in their shared source coordinate frame. Optional robot-arm flanges, right-side alternatives, molds, tools and the prosthetic silicone-palm alternative are excluded. Meshes are reduced for interactive display; colors only distinguish source groups, and no component placement or physical operation is inferred.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original source-positioned STL bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Vittorio Lumare, OPSOBOT and Yeah Hand contributors, revision e31fb0e219bd1bc90a19fbc6237eaff9766a3c31. Original and preview: CERN-OHL-S-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. All source STL components retain the shared assembly-coordinate vertices exported by the project; directory groups and assembly-path names are retained, and no component placement was inferred. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Project documentation [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22]
- Assembly
Select robotic or prosthetic electronics and match the released geometry, actuator BOM and firmware; compatibility remains unverified.
Known prerequisites and unresolved assembly decisions; not a complete build instruction.
[1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22] · Editorial assessment
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Robotic versus prosthetic build
The V2 BOM lists five WaveShare ST3215 servos. The robotic version uses a purchased WaveShare ESP32 Servo Driver; the prosthetic version uses a custom PCB and EMG sensors. Start with hardware/BOM.md and hardware/Electronics/Readme.md to distinguish these routes. Neither electronics route establishes a cobot or delta mounting flange. [4] [15]
Fabrication uses different materials for different parts, including flexible fingers in TPU with PLA/ABS, a PLA/PETG thumb base and PLA covers. Tendon material and the selected geometry must match. The BOM still leaves wrist-fastener details unfinished, so it does not yet provide a fully reconciled shopping list. [4]
CAD is distributed through release assets. Match the chosen release to the current documentation and firmware before fabrication; the reviewed documents do not establish that every release and branch combination is compatible. [5]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
e31fb0e
Source files and licenses
CERN-OHL-S-2.0 hardware; GPL firmware; CC-BY-SA documentation. CAD is in release assets, not the default-branch tree. Match v1.2 asset and current docs before building; native Blender file is over 400 MB and not preserved here. Rebelia V1 is a related version, not an additional independent family.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-S-2.0 CERN-OHL-S-2.0 hardware; GPL firmware; CC-BY-SA documentation. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22] |
| software | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22] |
| documentation | available · License not fully assessed CERN-OHL-S-2.0 hardware; GPL firmware; CC-BY-SA documentation. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] [11] [12] [13] [14] [15] [16] [17] [18] [19] [20] [21] [22] |
This profile scopes hardware tooling, without selecting a learned controller or training dataset.
Rights and control dependencies
The project declares CERN-OHL-S-2.0 for hardware, GPL terms for firmware and Creative Commons terms for documentation. Read the particular file notices rather than applying one license to the entire build. [2] [12] [14]
The firmware instructions list external libraries, including modified ESP32FFT material described as having a custom license. Pin those dependencies and obtain their license texts before relying on reuse rights. The project’s GPL declaration does not settle every dependency or the source rights of the purchased controller. No complete delivered cost, hardware build or performance test is established here. [13] [15]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Yeah Hand pinned tree
Revision, date & where cited
github.com · revision
e31fb0e· Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S002 Yeah Hand / LICENSE
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S003 Yeah Hand / Readme.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S004 Yeah Hand / hardware/BOM.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Robotic versus prosthetic build and 1 more - S005 Yeah Hand / hardware/README.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S006 Yeah Hand / hardware/Electronics/Prosthetic Version/GerberFiles_ServoBoard Slim/BOM.TXT
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S007 Rebelia hand pinned tree
Revision, date & where cited
github.com · revision
52d87a2· Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S008 Rebelia hand / LICENSE
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S009 Rebelia hand / Readme.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S010 Rebelia hand / hardware/BOM.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S011 Rebelia hand / hardware/Electronics/Prosthetic Version/GerberFiles_ServoBoard Slim/BOM.TXT
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Source files and licenses - S012 firmware/LICENSE.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S013 firmware/README.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S014 hardware/LICENSE.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S015 hardware/Electronics/Readme.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Robotic versus prosthetic build, Source files and licenses - S016 hardware/Renders/LICENSE.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S017 firmware/src/RebeliaHuman/LICENSE.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S018 firmware/src/RebeliaRobot/COPYING.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S019 hardware/Electronics/Prosthetic Version/Readme.md
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S020 hardware/Electronics/Prosthetic Version/ServoBoardSlim Netlist.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S021 hardware/Electronics/Prosthetic Version/ServoBoardSlim Partlist.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S022 hardware/Electronics/Prosthetic Version/GerberFiles_ServoBoard Slim/HoleReport.txt
Revision, date & where cited
opsobot · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Assembly & first use, Source files and licenses - S023 Upstream image and reuse attribution
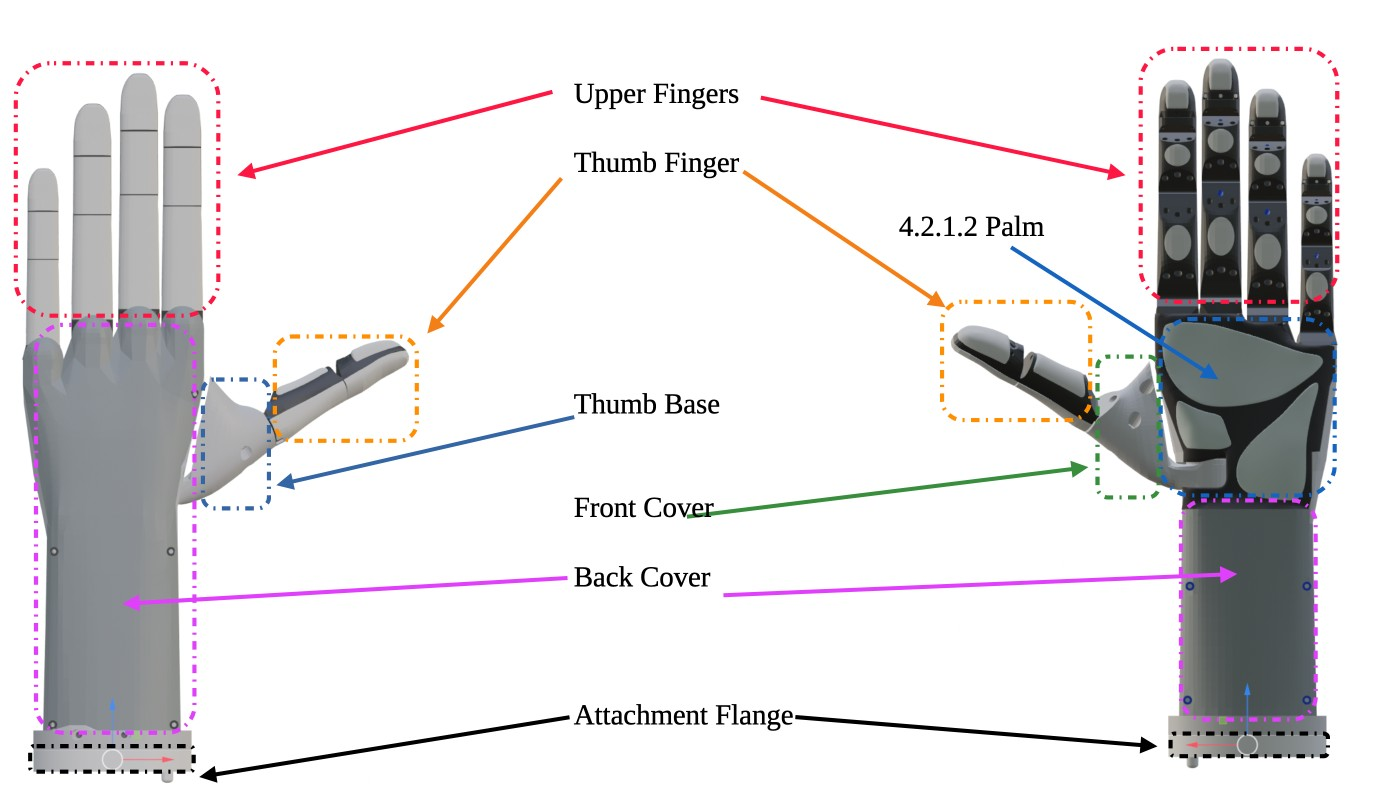
Media-only review: Illustration of Yeah Hand, front and back external views from page 21 of the selected Rev 1.7 English assembly manual. These are annotated CAD views, not photographs of a built hand; Rev 1.7 identifies the manual revision. Reuse basis: CC-BY-SA-4.0. Exact selected manual freshly downloaded, byte-identical to prior preserved5341671-byte Rev1.7EN source; no currentRev1.8 source substitution. Page21 rendered and visually inspected; PDF image object1252 is the complete annotated front/back external-view CAD illustration. Poppler independently lists object1252 as the page21 image,1384x795. Its all-zero soft mask uses Decode[1,0], so it is fully opaque; RGBJPEG pixels losslessly decoded toPNG, no crop/retouch. Manualrevision1.7 is not claimed as a separate hardwareversion. RootLICENSE explicitly grants pictures/photos CC-BY-SA, exactReadme linksby-sa4.0 and exacthardware/Renders/LICENSE.txt is fullAttribution-ShareAlike4.0, with noNCcondition. Priorprivate notes wrongly called that renderlicenseNC; actualpreservedterms reread and correction recorded. FirstpartyownmanualCADviews have no separate thirdpartycredits/narrowerexclusions. Currentexternalwebsite has conflictingBYSAandARRfooters and is excluded. Actualbuilt-handphoto remainsunestablished; clearly labeledIllustration. No changes to historicalrobotfacts/costs/source dates, no hardware/runtime test. Embedded image extracted from page 21 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
Vittorio Lumare / RobotGarage · github.com · revision
e31fb0e· Exact selected e31fb0e PDF, Rev1.7 EN, page21 Machine overview / Overall Technical Drawing - External View, JPEG XObject1252 size1384x795; rootPictures grant, ReadmeBYSA4link and RendersfullBYSA4.; image SHA-256 b013530735f4c736d6c12fd0cb027f586bccbbec789c0a98b597a188ae9a6ab6 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.