YAM
Robot / hardware buildA family of six-axis YAM arms supported by a Python and CAN control library with revision-specific models. [1]
Build & first use →Official website
- For
- Robot-learning developers integrating purchased YAM hardware [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Overview
The preserved I2RT release v1.3.6 is a Python control library, with models and examples for YAM hardware. Its six-axis variants map to these selectors: YAM (yam), YAM Pro (yam_pro), YAM Ultra (yam_ultra), YAM Ultra 2 (yam_ultra_2) and Big YAM (big_yam). Select through --arm or arm_type=; no_arm covers a gripper-only robot. Ultra 2 keeps Ultra's kinematics but changes link inertials and the joint-four motor; a shared shape is not enough to select the model. [1] [2]
Gripper selection is separate. The identifiers are crank_4310, linear_3507, linear_4310, flexible_4310, yam_teaching_handle and no_gripper; the last selects a bare terminal mount. Linear grippers require a closed starting position or calibration because motor travel exceeds one revolution. The documented host route uses Python 3.11, Linux dependencies and CAN at 1 Mbit/s. [1]
Read the specification labels literally: arm mass excludes the gripper and tips, and chain length sums joint-origin translations rather than measuring reach. Neither should be copied into a complete-arm specification without its qualification. [1]
The MIT license covers this software repository. A complete hardware manufacturing pack, its rights and a current configuration-specific price were not established here. No robot code was executed and no physical calibration or support workload was measured. [3]
Is this for you?
- Known limitations
- Arm variant and gripper type must match the physical configuration
- Chain length is not reach
- Reported arm mass excludes gripper and tips
3D preview
YAM v1 simulation assembly. The YAM v1 arm model supplied for simulation, at zero joint positions. This is not a fabrication CAD package and does not depict YAM Pro, Ultra or Big YAM variants.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: I2RT Robotics, revision 120c3c81400171174604e503943f8d1ebc891058. Original and preview: MIT. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- Python 3.11 and uv in the documented Linux installation
- MuJoCo for documented simulation and gravity compensation
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| electronics | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| firmware | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| software | available · MIT Python API and repository models; no complete hardware manufacturing license established. [1] [4] [3] |
| documentation | available · MIT Repository instructions, not a complete manufacturing and assembly pack. [1] [4] [3] |
This profile covers the described physical configuration and control route without a particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 i2rt-robotics/i2rt: README.md
Revision, date & where cited
github.com · revision
120c3c8· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S002 i2rt-robotics/i2rt: commit 120c3c8
- S003 i2rt-robotics/i2rt: LICENSE
Revision, date & where cited
github.com · revision
120c3c8· Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S004 i2rt-robotics/i2rt: files
Revision, date & where cited
github.com · revision
120c3c8· archive file inventory · Accessed Sep 30, 2026
Used for: Source files and licenses - S005 Upstream image and reuse attribution
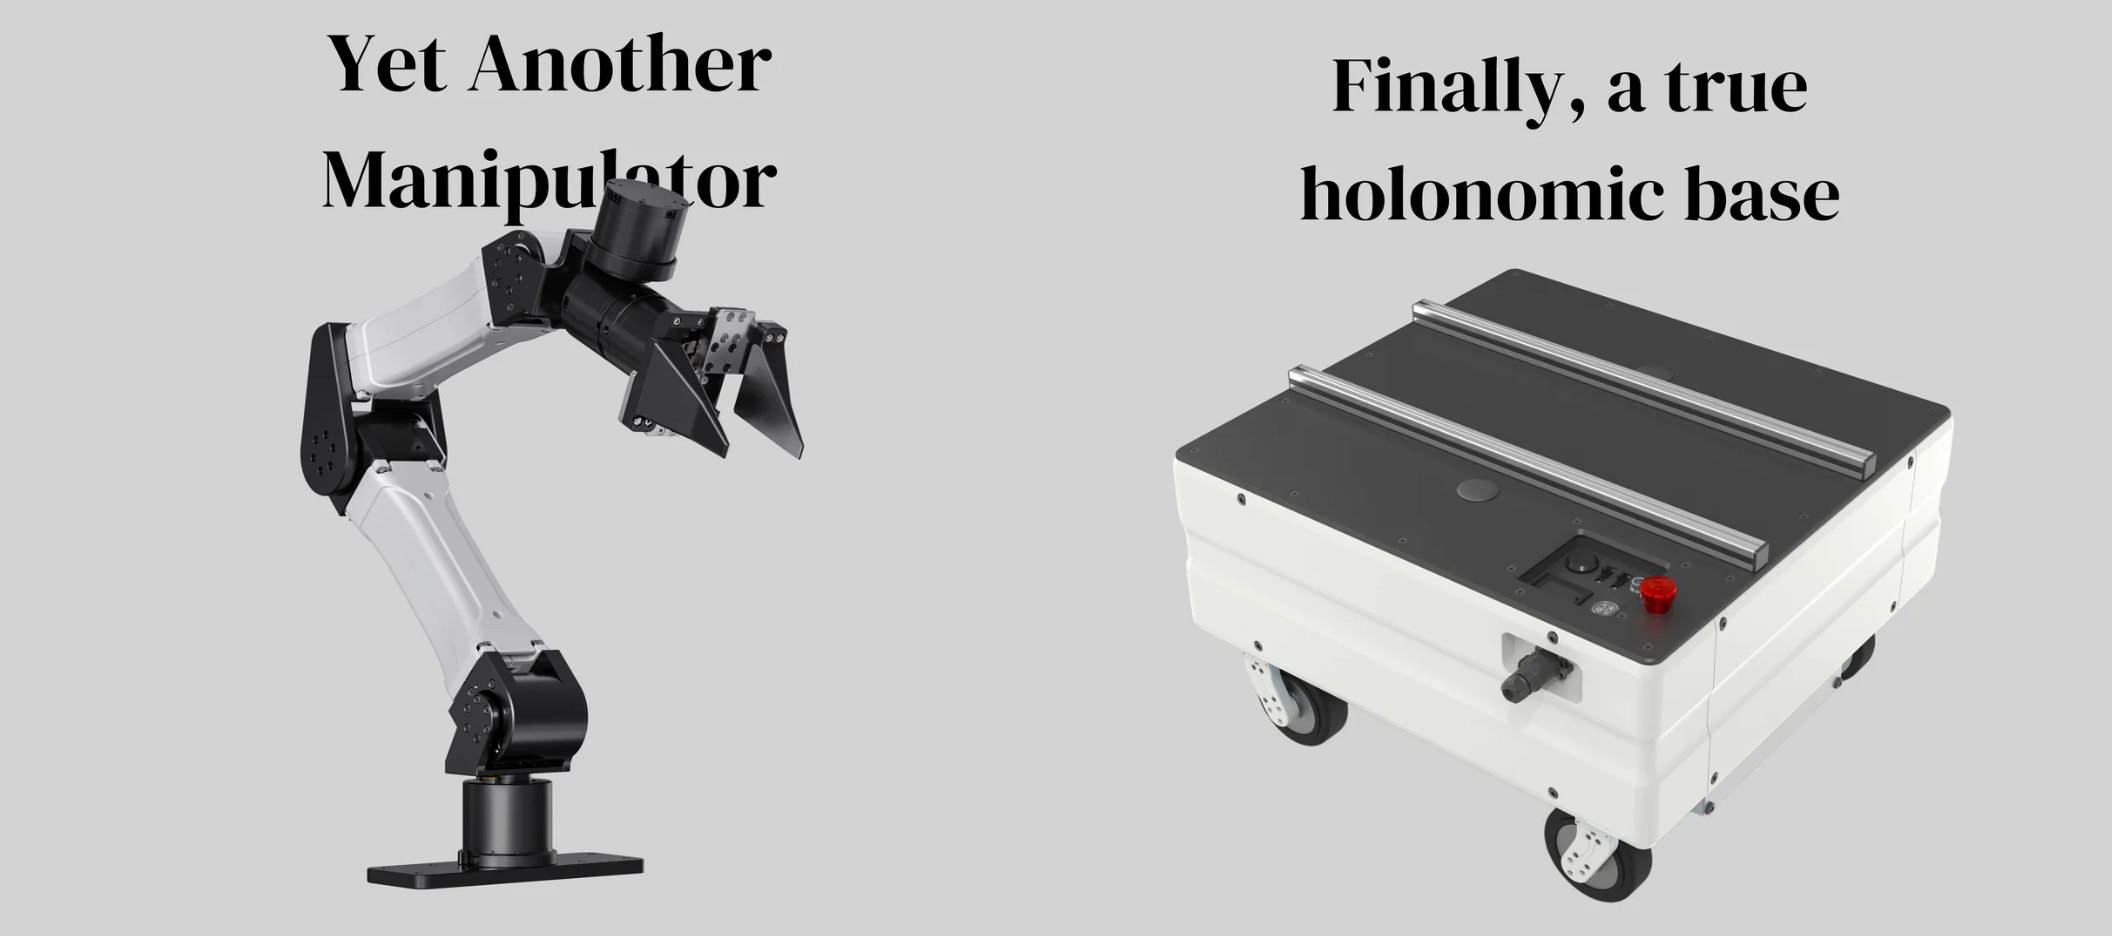
Media-only review: Upstream comparison illustration of the YAM manipulator and the related Flow mobile base; the Flow base is separate equipment. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
I2RT Robotics contributors · github.com · Image SHA-256 19e467cd35d3696c7cac116b1c8ddc2699a5d8f874854f71734b44ea890ee41d; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.