Poppy Ergo Jr
Robot / hardware buildA six-axis educational arm using printable parts, Dynamixel XL-320 servos and Raspberry Pi control. [1]
Build & first use →Official websiteBill of materials
- For
- Robotics educators; Makers comfortable with Raspberry Pi setup [1]
- Cost
- No current cost yet. Upstream bill of materials [1]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0, GPL-3.0 · license not fully assessed for documentation · Details by part
Overview
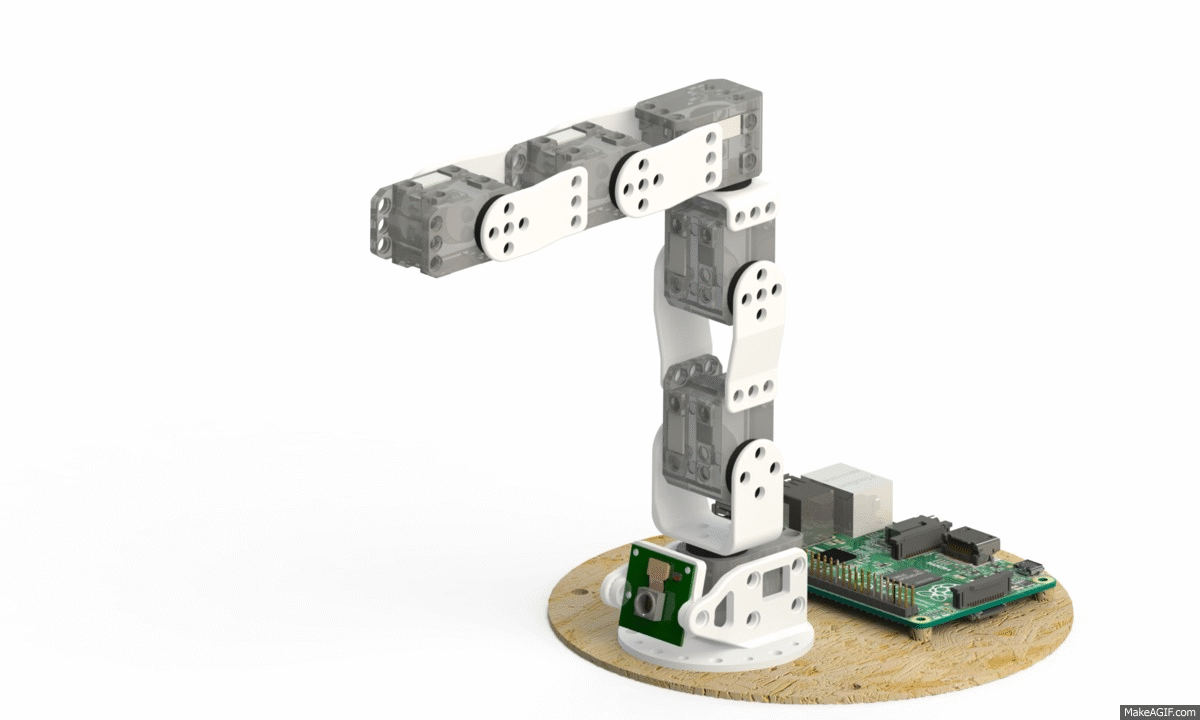
Ergo Jr combines six degrees of freedom, Dynamixel XL-320 servos and printed parts. The repository includes hardware, software and documentation, and the overview describes grasper, pen-holder and lampshade tools. Choose the tool and task before treating the arm as a complete teaching setup. [1] [4]
The reviewed repository release is 4.0.1, but its README still points to a Raspberry Pi image dated 2017 and describes Pi 2/3 hardware. The alternative uses Raspoppy setup scripts and calls for Linux knowledge and at least an 8 GB SD card. A newer package release does not, by itself, establish that this board-image route works on a current Pi or operating system. [1] [2]
Use the pinned BOM and assembly documentation to reconcile the servo, board and printed-part configuration. Hardware and software have different declared licenses—CC BY-SA 4.0 and GPL v3—and the Poppy name has separate restrictions. [1]
We have not reproduced the image installation, assembled the arm or measured its calibration and support needs. Current parts availability and the complete delivered setup cost remain unverified.
3D preview
Base. This preview shows one component, not the complete robot.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Poppy project contributors, revision 7df3cc668276f5e19b8ccf79fe8b94034ee816f3. Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A limitations summary
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 Hardware license is stated separately from software; Poppy name usage is restricted. [1] [4] |
| electronics | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| firmware | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| software | available · GPL-3.0 README software license declaration; dependencies retain separate terms. [1] [4] |
| documentation | available · License not fully assessed Documentation present; no blanket media reuse permission assigned. [1] [4] |
This profile covers the described physical configuration and control route without a particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 poppy-project/poppy-ergo-jr: README.md
Revision, date & where cited
github.com · revision
7df3cc6· Accessed Sep 30, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 1 more - S002 poppy-project/poppy-ergo-jr: commit 7df3cc6
- S004 poppy-project/poppy-ergo-jr: files
Revision, date & where cited
github.com · revision
7df3cc6· archive file inventory · Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S007 Upstream image and reuse attribution
Media-only review: Still from an upstream demonstration: a Poppy Ergo Jr arm with a gripper attachment. Reuse basis: CC-BY-SA-4.0; inspected README.md and the pinned file inventory for nearer notices. Still taken from the upstream animation; no other changes. This does not refresh technical or cost evidence.Revision, date & where cited
Poppy Project and Inria contributors · github.com · revision
7df3cc6· Image SHA-256 66215901806bdf369427fe6bc821f829d72c378f167a407d1f731e6f6d6ac06a; repository · Accessed Oct 25, 2026
Videos
- S005 Poppy Project (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Poppy Project · youtube.com · Accessed Oct 4, 2026
- S006 Record movement by demonstration on a Poppy Ergo Jr (YouTube video)
Video from the project’s own channel (Poppy Project), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Poppy Project · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S005, S006): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.