Open Source Leg
Leg subassemblyModular knee-and-ankle research platform with published assembly documentation, externally hosted design downloads and a separately licensed Python SDK. [1] [5] [6]
Build & first use →Official website
- For
- Research laboratories with mechanical fabrication and embedded control experience [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- LGPL-2.1 · license not fully assessed for mechanical design, documentation · Details by part
Overview
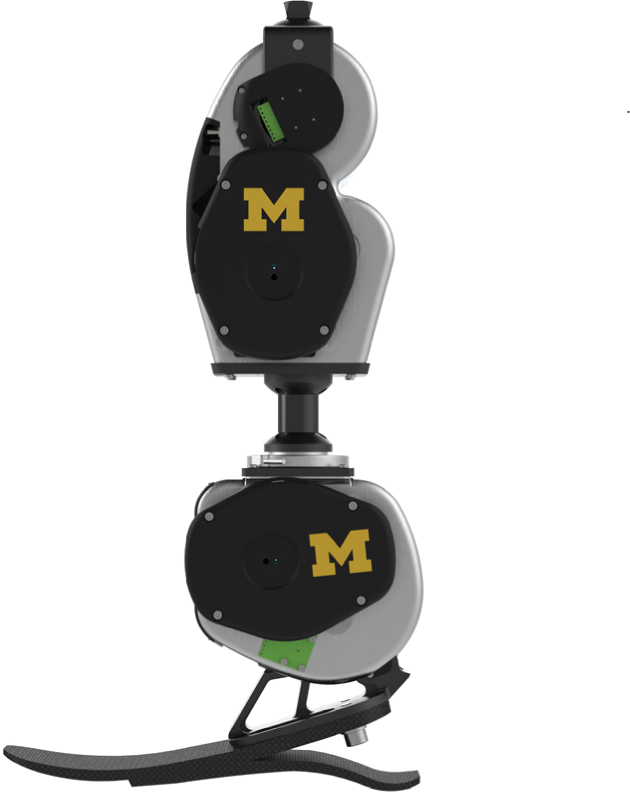
Open Source Leg is a research platform that can be built as a knee, an ankle, or a combined system, with or without series elasticity. Its physical design, purchased actuators, electronics and Python SDK are separate parts of the evidence. Installing the SDK does not establish that a leg has been built, calibrated or qualified for use by a person. [1] [5] [6]
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
The listed price is a planning reference
The hardware page gives an approximate $10,500–$23,000 range and a separate itemized total of $23,100. These are upstream estimates with configuration differences, not a fresh delivered quote. The BOM also contains quote-dependent actuators and optional sensing. Machining, the selected foot, shipping, tax, tools and integration work need their own scope before a complete budget can be stated. No current checkout total was verified. [5] [8]
3D preview
Preview not available yet. Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Model sources
Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Project notes
Choose a configuration before using the BOM
The hardware page describes version 2's single-stage external belt transmission and shared knee/ankle drivetrain design. The referenced BOM names Dephy Actpack 4.1 actuators with 9:1 gearing, batteries, docks, encoders, machined components and stock hardware. Its foot sizes are alternatives, and several fastener packs are explicitly shared between knee and ankle orders. Spare-part recommendations should not be confused with installed quantities. [5] [8]
The load cell and strain amplifier are optional in that BOM. An LED component is marked no longer in production, so even a faithful parts-list copy needs substitution review. The newer electronics page describes a Raspberry Pi Compute Module 5 carrier; that description should not silently replace the Raspberry Pi wiring assumptions in the assembly tutorials. [7] [8] [9] [10]
Assembly text is available, but diagrams still matter
The instructions cover bearings, aligned pulley subassemblies, housings, actuator attachment and foot mounting. They describe tight fits and alignment requirements; this review did not inspect CAD geometry or test fabrication tolerances. The official downloads page links STEP/drawing archives and an Onshape document. Retrieval of the linked knee archive failed with HTTP 403 in this review, so archive completeness and its exact hardware license remain unverified. A failed retrieval is not evidence that the design is closed. [6] [13] [14] [15] [16]
Belt maintenance uses eccentric-cap adjustment followed by manual range, tracking and binding checks. The reviewed pages do not supply a numerical pretension or tightening-torque target. The electronics steps depend on diagrams for the load-cell connections, a horizontally flipped ribbon-cable pinout and encoder address options. Those diagrams were not inspected, so this profile does not reproduce a supposedly verified wiring map. [9] [10] [11] [12]
Match Python and hardware interfaces explicitly
The preserved SDK README says version 3.3.0 onward requires Python 3.11 or newer, points Python 3.9 users to version 3.2.1, and explicitly excludes Python 3.10. It also offers hardware-specific installation extras. These version-specific statements are more useful than treating the platform name as a single compatible software environment. No package was installed or connected to an actuator here. [1]
The SDK's own interface table distinguishes complete, partial and unavailable hardware tests and benchmarks across Dephy, moteus and TMotor support. Those are maintainer-reported statuses, not tests performed for this catalog. A supported class name alone does not qualify an arbitrary actuator, firmware revision or complete leg configuration. [1]
Openness is assessed by layer
The SDK includes LGPL version 2.1 terms. That software license does not establish the hardware archive's license or the availability of purchased actuator firmware. The current review establishes official build documentation, a readable BOM and SDK sources, while leaving mechanical-download contents, electronics design files and exact hardware reuse terms unresolved. No manufacturing, wiring, calibration, walking or human-use testing was performed. [3] [5] [6] [7] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A limitations summary
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Official design downloads and Onshape links exist, but linked knee archive retrieval returned HTTP403. Archive contents, geometry and exact hardware license not verified. [5] [6] |
| electronics | not found · License not fully assessed Wiring text and board descriptions available; complete board design files and license not established in inspected sources. [7] [9] [10] |
| firmware | not found · License not fully assessed SDK interfaces with purchased actuators; corresponding actuator firmware source/license not established by this review. [1] [8] |
| software | available · LGPL-2.1 Python SDK license only; does not establish rights for hardware designs or purchased actuator firmware. [1] [3] [4] |
| documentation | available · License not fully assessed Assembly text reviewed; website text and media reuse terms not established. [5] [9] [10] [11] [12] [13] [14] |
Selected mechanical platform and direct SDK-interface scope does not depend on a particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 neurobionics/opensourceleg: README.md
Revision, date & where cited
github.com · revision
31e2743· Accessed Oct 1, 2026
Used for: Overview, What you need, Assembly & first use, Match Python and hardware interfaces explicitly and 1 more - S002 neurobionics/opensourceleg: commit 31e2743
- S003 neurobionics/opensourceleg: LICENSE
Revision, date & where cited
github.com · revision
31e2743· Accessed Oct 1, 2026
Used for: Openness is assessed by layer, Source files and licenses - S004 neurobionics/opensourceleg: files
Revision, date & where cited
github.com · revision
31e2743· archive file inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S005 hardware
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Preserved official text; BOM readable extraction does not preserve workbook topology or hyperlink targets · Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Cost and 3 more - S006 downloads
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Preserved official text; BOM readable extraction does not preserve workbook topology or hyperlink targets · Accessed Oct 1, 2026
Used for: Overview, Assembly text is available, but diagrams still matter, Openness is assessed by layer, Source files and licenses - S007 electronics
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Preserved official text; BOM readable extraction does not preserve workbook topology or hyperlink targets · Accessed Oct 1, 2026
Used for: What you need, Choose a configuration before using the BOM, Openness is assessed by layer, Source files and licenses - S008 bom-readable
Revision, date & where cited
neurobionics / project contributors · docs.google.com · Preserved official text; BOM readable extraction does not preserve workbook topology or hyperlink targets · Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, Cost, Choose a configuration before using the BOM and 2 more - S009 electronics assembly step 1
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: What you need, Choose a configuration before using the BOM, Assembly text is available, but diagrams still matter, Source files and licenses - S010 electronics assembly step 2
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Choose a configuration before using the BOM and 2 more - S011 belt assembly step 2
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: Assembly & first use, Assembly text is available, but diagrams still matter, Source files and licenses - S012 belt assembly step 3
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: Assembly & first use, Assembly text is available, but diagrams still matter, Source files and licenses - S013 knee assembly step 1
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: Assembly text is available, but diagrams still matter, Source files and licenses - S014 ankle assembly step 7
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: Assembly text is available, but diagrams still matter, Source files and licenses - S015 knee assembly step 6
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: Assembly text is available, but diagrams still matter - S016 knee assembly step 3
Revision, date & where cited
neurobionics / project contributors · opensourceleg.org · Text instructions only; diagrams not inspected · Accessed Oct 1, 2026
Used for: Assembly text is available, but diagrams still matter - S020 Upstream image and reuse attribution
Media-only review: Upstream paper illustration of the 2020 Open Source Leg (Figure 1A); later hardware revisions may differ. Reuse basis: CC-BY-4.0. Inspected the source image, its caption and the actual reuse declaration; no image-specific exception or different credit was found for this selected image. The grant is used only for this media, not as a new hardware/software license. Embedded image extracted from page 2 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
Alejandro F. Azocar, Luke M. Mooney, Jean-François Duval, Ann M. Simon, Levi J. Hargrove and Elliott J. Rouse · doi.org · Figure 1A, PDF page 2; image SHA-256 748909de3b45891c647e192977f053aadb14cd66de4d2005c26ac489416755fc · Accessed Oct 26, 2026
Videos
- S017 OSL v2.0 | Step III | Adding the Timing Belt (YouTube video)
Video from the project’s own channel (Neurobionics Lab, University of Michigan), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Neurobionics Lab, University of Michigan · youtube.com · Accessed Oct 4, 2026
- S018 OSL v2.0 | Step V | Installing the Shaft-Caps (YouTube video)
Video from the project’s own channel (Neurobionics Lab, University of Michigan), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Neurobionics Lab, University of Michigan · youtube.com · Accessed Oct 4, 2026
- S019 OSL v2.0 | Step VII | Assembling the Knee (YouTube video)
Video from the project’s own channel (Neurobionics Lab, University of Michigan), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Neurobionics Lab, University of Michigan · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 3 YouTube reference(s) (S017, S018, S019): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.