Actuated UMI
End effectorXL430-W250-T drives a belt/rail gripper with constant-force springs; U2D2 and power hub are listed. [1] [2] [3] [4]
Build & first use →Official website
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for documentation · Details by part
Is this for you?
- Known limitations
- Two 80 mm MGN7C rail/carriages, belt, spring and fastener pack quantities need a configuration-specific quote. Pin separate Dynamixel API and reconcile v1/v2 folders.
- No hardware build or test performed.
Source-researched; no physical verification.
3D preview
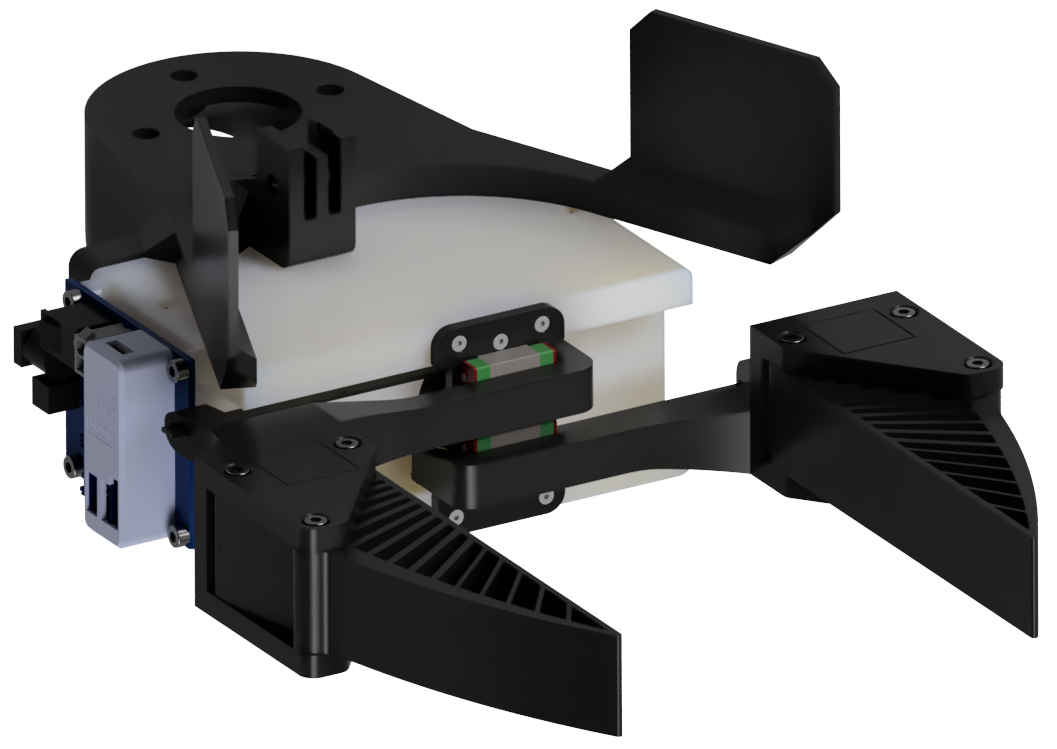
Actuated UMI gripper v1 STEP assembly. Version 1 of the gripper: actuated-UMI-v1-assy.step at commit 8e9e957, the configuration of the README parts list and print table that this profile describes (soft gripper fingers and the UMI WSG50-Franka mount). The v2 assembly in the same folder, with GelSight Mini fingers and an Intel RealSense D405 camera mount that the README does not list, is not shown. Source placements are kept for the printed structure, carriage mount, jaws, fingers and Franka mount, the OpenGrip-derived spring idlers and drive pulley, and the modeled purchased components: a DYNAMIXEL XL430-W250-T servo and horn, a U2D2 and Power Hub board model, two MGN7 rails and carriages, constant-force springs, screws and heat-set inserts. The third-party terms of those purchased component models are unknown. Licensed MIT with an MIT notice for UMI Gripper content. Fit and function are not verified.
MIT license with third-party content: the repository LICENSE is MIT (“Copyright (c) 2024 actuated-umi”) and LICENSE_THIRD_PARTY is the MIT notice for UMI Gripper content (“Copyright (c) 2023 Columbia Artificial Intelligence and Robotics Lab”). The assembly also models purchased and third-party components that these notices do not cover: a ROBOTIS U2D2 and Power Hub board model that the README credits to Stan Markwell on GrabCAD (no license given), the DYNAMIXEL XL430 servo and horn, MGN7 rails and carriages, constant-force springs, and McMaster-Carr, DIN and ruthex screws and heat-set inserts. They are kept as placed in the source assembly; their third-party terms are unknown. The README credits OpenGrip as the starting point of the mechanism; the terms of the OpenGrip-derived idler and pulley are not traced. No manufacturing or redistribution clearance is claimed beyond the MIT notices. License: MIT (Actuated-UMI LICENSE and UMI Gripper LICENSE_THIRD_PARTY) · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP (gzip) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Actuated-UMI (Erik Helmut, Niklas Funk, Tim Schneider, Jan Peters), revision 8e9e9572a9021aab0a06f049f4bce96fe4de8ab4. Original and preview: MIT (with MIT UMI Gripper third-party notice). Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Project documentation [1] [2] [3] [4]
- Assembly
Two 80 mm MGN7C rail/carriages, belt, spring and fastener pack quantities need a configuration-specific quote. Pin separate Dynamixel API and reconcile v1/v2 folders.
Known prerequisites and unresolved assembly decisions; not a complete build instruction.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Mounting and application
Franka mount is explicitly listed in the print table and files; no delta application verified. [1] [2] [3] [4]
Before sourcing the build
The README lists two 80 mm MGN7C rail/carriages, two constant-force springs specified as 0.1×8×110, and one belt 5 mm wide, 1 mm thick and 300 mm long. Fastener assortment links do not establish installed quantities. Select a mechanical version, match the README print list to its versioned files, then verify individual fastener sizes and obtain current prices. The recommended Dynamixel API also needs separate review and a pinned revision. [1] [2] [3] [4]
Files and reuse terms
The root MIT license and a third-party MIT notice naming Columbia Artificial Intelligence and Robotics Lab are supplied; preserve their copyright and permission notices. The README identifies UMI material as MIT and credits OpenGrip as the mechanism’s starting point. The rights and attribution scope of incorporated OpenGrip material still need tracing. [1] [2] [3] [4]
The pinned inventory lists v1/v2 printable STL folders and STEP assemblies. The README links unversioned print paths, so resolve that mapping before fabrication. Fabrication suitability and a complete matched mechanical/control package have not been verified. Current delivered cost and measured performance are not established; no hardware was built or tested for this profile.
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
8e9e957
Source files and licenses
MIT root license; trace UMI/OpenGrip derivative attribution separately. Two 80 mm MGN7C rail/carriages, belt, spring and fastener pack quantities need a configuration-specific quote. Pin separate Dynamixel API and reconcile v1/v2 folders.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT MIT root license; trace UMI/OpenGrip derivative attribution separately. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] |
| software | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] [4] |
| documentation | available · License not fully assessed MIT root license; trace UMI/OpenGrip derivative attribution separately. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] [4] |
This profile scopes hardware tooling, without selecting a learned controller or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Actuated UMI pinned tree
Revision, date & where cited
github.com · revision
8e9e957· Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S002 Actuated UMI / LICENSE
Revision, date & where cited
actuated-umi · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S003 Actuated UMI / LICENSE_THIRD_PARTY
Revision, date & where cited
actuated-umi · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S004 Actuated UMI / README.md
Revision, date & where cited
actuated-umi · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S005 Upstream image and reuse attribution
Media-only review: Upstream illustration of the Actuated UMI gripper, not a photograph of a tested build. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Erik Helmut, Niklas Funk, Tim Schneider, Jan Peters and Actuated UMI contributors · github.com · revision
8e9e957· Image SHA-256 999bb7d87cf80c1bb583d15b3147ede5e49344b1e1959a4d07ee4338f42a36e4; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.