Galileo 2 Extruder (G2E)
End effectorPlanetary-geared filament feeder for a Stealthburner toolhead, with custom gearbox parts, selectable printed housings and a detailed assembly manual. [1] [2] [5]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Builders evaluating a sourced mechanical design and its integration requirements. [1]
- Cost
- No current cost yet. Upstream bill of materials [5]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
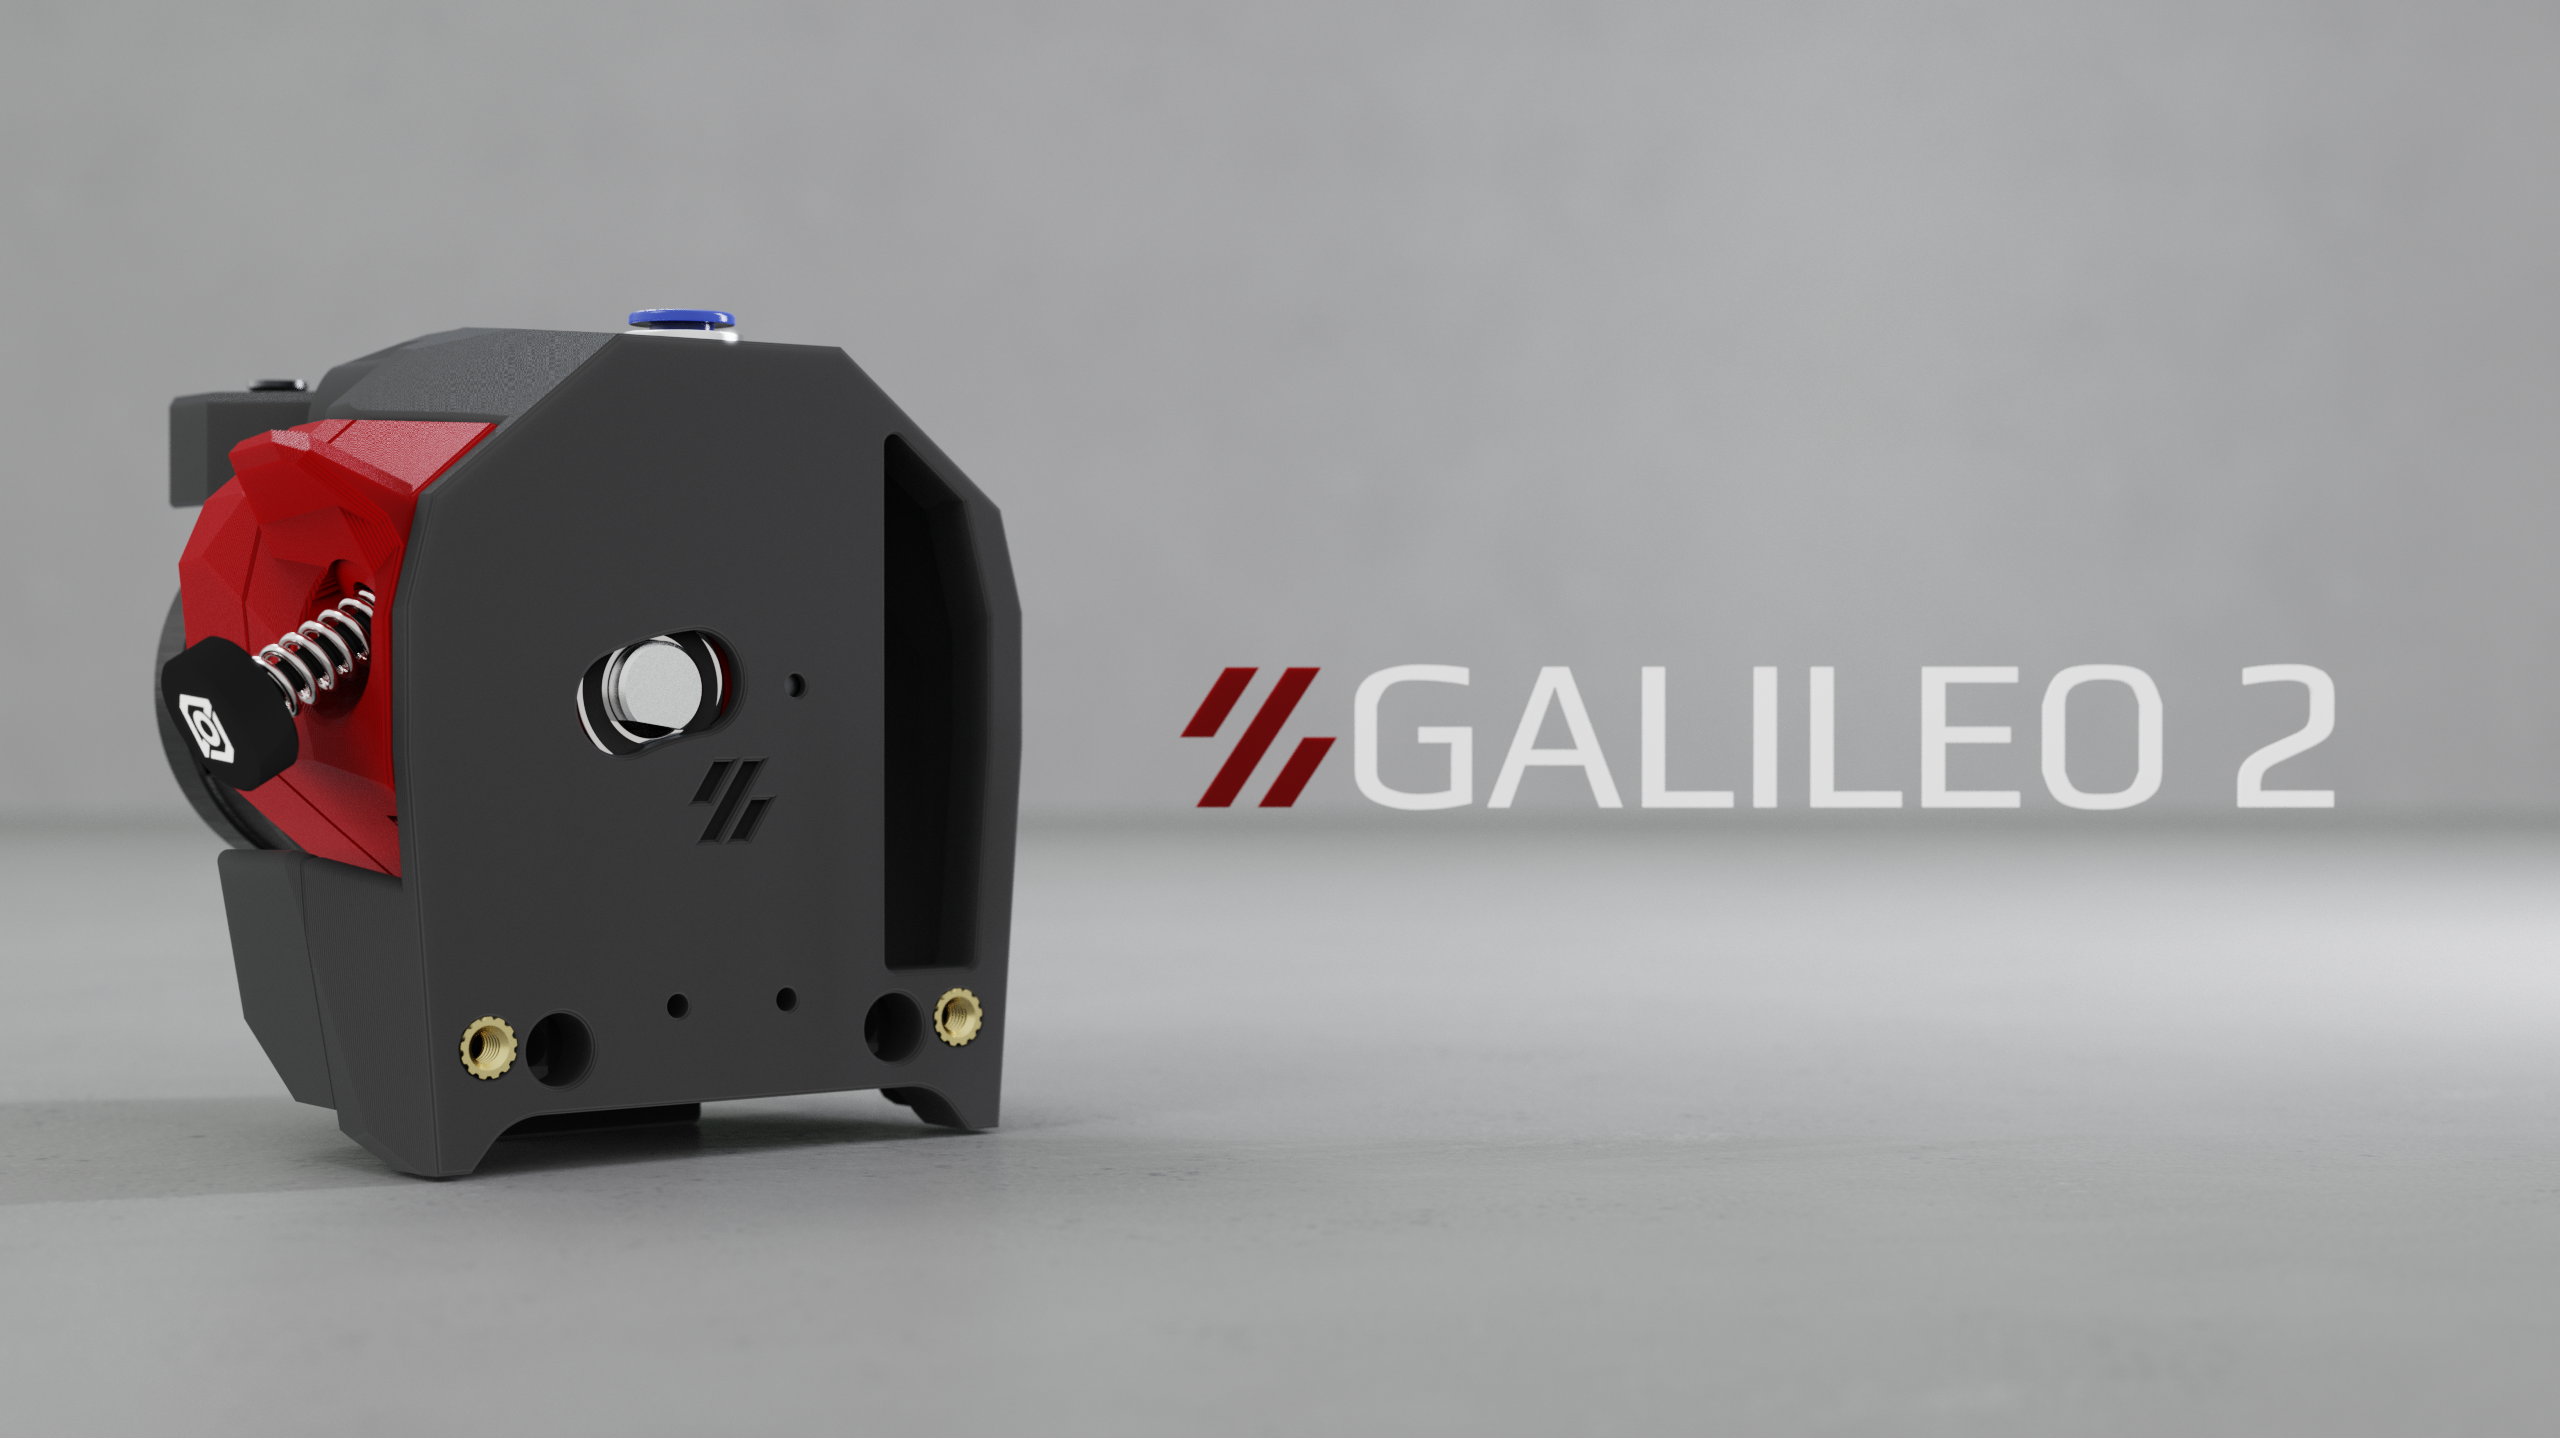
G2E is the filament-feeding part of a printer toolhead, with a 9:1 planetary gearbox and a separate hotend downstream. This profile covers the Stealthburner version. The same repository also contains standalone extruders and Z-axis drives, which should not be combined into one build list. The root README calls G2E released while the standalone G2SA remains public beta. [1] [2]
Is this for you?
- Known limitations
- Hotend, host electronics and complete current kit contents/cost are separate requirements.
- Do not mix G2E, standalone G2SA and Z-drive configurations.
- No physical calibration, print result or robot-arm compatibility verified.
Editorial classification; not physical qualification.
3D preview
Galileo 2 Extruder assembly. G2E feeder assembly geometry; hotend and host printer are separate. Purchased parts are represented, not separately source-qualified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: JaredC01 and contributors, revision 98f8a37944d7277cd37231776400553cc402219f. Original and preview: GPL-3.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Choose housings before printing
The STL guide requires one front body: either an ECAS-coupler version or a friction-fit Bowden-tube version. It also requires one cable-chain attachment, selected for two-hole or three-hole chains. Printing every alternative would produce spare options rather than one matched assembly. The manual specifies ABS or ASA, 0.2 mm layers, four walls, five top/bottom layers and 40% infill. [3] [5]
Purchased gearbox parts matter as much as the printed housings. The manual identifies a custom 9-tooth NEMA 14 pancake stepper, 31-tooth MJF planet gears, a 72-tooth ring housing, aluminum carrier, 16 mm filament drive gear and bearings. Its assembly sequence locates the carrier and shim before securing the drive gear. Use the illustrated sequence to reconcile a kit's contents; a generic stepper and downloaded STLs do not establish an equivalent gearbox. [5]
Match the host and recalibrate
The documented mechanical target is a Stealthburner MGN12 toolhead, including the listed Tap or inductive-probe carriage arrangements. That is printer-interface evidence, not cobot or delta-robot compatibility. The hotend, heater, temperature sensing and host controller must be selected separately from this feeder. No complete extrusion-system price is established. [1] [5]
Upstream requires changes to Klipper's gear ratio, rotation distance and motor current, followed by extruder calibration. Its example uses 9:1, rotation distance 47.088, 16 microsteps and 0.6 A for a TMC2209. Treat those as settings for the documented configuration, not universal values for substituted motors or drivers. [1] [5]
The repository carries GPL-3.0. No physical assembly, extrusion calibration or performance testing was performed. [4]
What we checked
Source review only. No assembly, procurement, control bringup or physical performance testing.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Sep 30, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
98f8a37
Source files and licenses
Mechanical design files are licensed; purchased components, source completeness and a working matched configuration remain separate checks.
| Layer | Availability / license |
|---|---|
| mechanical design | available · GPL-3.0 First-party repository files; no manufacturing source for purchased components inferred. [1] [4] |
| electronics | not found · License not fully assessed Complete revision-matched source for this layer was not established in this mechanical repository; external host components require separate assessment. [1] |
| firmware | not found · License not fully assessed Complete revision-matched source for this layer was not established in this mechanical repository; external host components require separate assessment. [1] |
| software | not found · License not fully assessed Complete revision-matched source for this layer was not established in this mechanical repository; external host components require separate assessment. [1] |
| documentation | available · GPL-3.0 First-party repository files; no manufacturing source for purchased components inferred. [1] [4] |
No learned model or dataset selected for this mechanical configuration.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Project variants and control settings
Revision, date & where cited
JaredC01 and contributors · github.com · revision
98f8a37· README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S002 G2E intended host
Revision, date & where cited
JaredC01 and contributors · github.com · revision
98f8a37· galileo2_extruder/README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you? - S003 Printed-part option selection
Revision, date & where cited
JaredC01 and contributors · github.com · revision
98f8a37· galileo2_extruder/stl/README.md at · Accessed Sep 30, 2026
Used for: Is this for you?, Choose housings before printing - S004 JaredC01/Galileo2: LICENSE
Revision, date & where cited
JaredC01 and contributors · github.com · revision
98f8a37· LICENSE at · Accessed Sep 30, 2026
Used for: Match the host and recalibrate, Source files and licenses - S005 G2E assembly manual, 14 May 2024
Revision, date & where cited
JaredC01 and contributors · github.com · revision
98f8a37· manuals/Galileo_2_Extruder_Assembly_Manual.pdf at · Accessed Sep 30, 2026
Used for: Hardware & parts, Assembly & first use, Choose housings before printing, Match the host and recalibrate
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Replaced duplicate CAD still with an attributed upstream image; image scope and reuse evidence reviewed.