RC_WheelLeg / Bonjour
Robot / hardware buildA 16-actuator Robocon wheel-legged quadruped with STEP designs and ROS 2 control sources; final-workspace assets, electronics/firmware coverage and licensing need reconciliation. [1] [2] [3] [4] [5] [7] [8]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Advanced teams with CAN motor-control, mechanical fabrication and Jetson/ROS 2 integration experience [1] [5] [6]
- Cost
- No current cost yet. Upstream bill of materials [4]
- Source rights
- Some licenses are unresolved. Review licenses
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- not fully assessed for mechanical design, software, model weights, documentation · Details by part
Overview
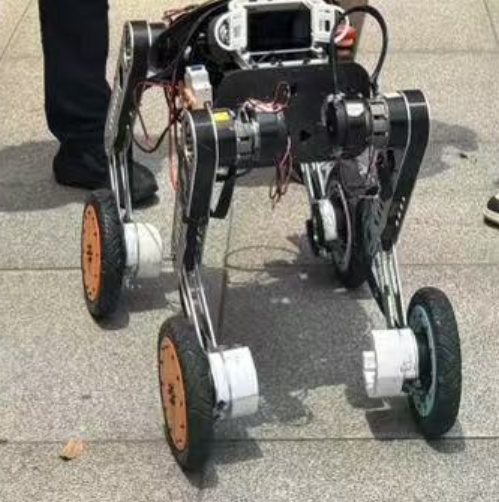
RC_WheelLeg documents Bonjour, a 16-actuator wheel-legged quadruped developed for a Robocon obstacle course. Each of its four legs has three leg joints and one driven wheel. The repository supplies mechanical designs and substantial control implementation, but its detailed release boundaries are narrower than the main README's broad completeness claim. This entry is a source-available hardware/control reference with explicit build and rights gaps. [1] [2] [3] [4] [5]
Is this for you?
- Known limitations
- Detailed docs say 16DOF custom electronics and MCU firmware are unarchived, despite broader top-level completeness claims.
- Root MIT declaration conflicts with Proprietary metadata and the final-workspace licensing warning; third-party SDK and derived mechanical rights remain separate.
- Final v3 policy folder contains only a README at the pinned revision; matching ONNX hashes were located in an older-named workspace, requiring reconciliation before use.
- Required 1hao.bin relocalization map is missing; sample PCD/routes do not establish reproduced relocalization.
- Authors report belt radial-loading/overheating risks and printed outer wheel-hub failure; CAD fit and alternative linkage redesign were not validated.
- No complete delivered 16DOF build budget or runtime/hardware validation by Open Source Robotics.
Editorial assessment from inspected sources.
What you need
- Operating system
- Ubuntu 22.04 / ROS 2 Humble on Jetson documented target
- Host computer
Jetson Orin Nano 8G for deployment; separate compatible training workstation for the learning workflow.
Editorial assessment from inspected sources.
- Dependencies
- ROS 2 Humble
- Linux SocketCAN and matched motor/CAN configuration
- Odin driver and separately scoped SDK static library
- TensorRT/ONNX policy runtime matched to target environment
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1]
- Select the 16DOF mechanical and deployment snapshot; do not mix the old 8DOF firmware/BOM assumptions.
- Inspect complete STEP assembly and reported belt and hub limitations before fabrication.
- Reconcile v3 policy locations and hashes, motor contract and target environment; begin with driver-disabled source checks.
- Obtain a genuine relocalization map before using relocal mode; missing 1hao.bin is not replaced by a sample PCD.
Editorial assessment from inspected sources.
- Assembly
Mechanical drawings and source are available, with reported belt-loading/heating and printed wheel-hub breakage limitations; complete electronics and commissioning reproducibility is unestablished.
Editorial assessment from inspected sources.
- Calibration
Author instructions require wheel-off-ground checks of CAN mapping, directions, zero positions, emergency stop and limits; not reproduced here.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Licensing and cost remain scoped
The root license declares MIT, but several final-workspace package manifests say Proprietary, and the v3 README says their licensing still needs a project-owner decision. The Odin driver's Apache-2.0 declaration, precompiled SDK and mechanically derived parts have separate scopes. These conflicting declarations remain unresolved rather than being flattened into a blanket MIT label. [2] [7]
No complete delivered cost has been established for the 16DOF robot, fabrication, computing, sensors, power, tools, tax and shipping. No controller compilation, policy execution, fabrication or physical robot test was performed. [4] [5]
3D preview
Preview not available yet. Mechanical source files are available, but model reuse scope remains unresolved. No 3D model is hosted; the separately credited documentation photograph uses the root MIT grant. Mechanical fit and complete build reproduction have not been validated.
Model sources
Mechanical source files are available, but model reuse scope remains unresolved. No 3D model is hosted; the separately credited documentation photograph uses the root MIT grant. Mechanical fit and complete build reproduction have not been validated.
Project notes
Choose the 16DOF snapshot
This review pins 1bc9aa5999f2cd13f729dc647ed0b8b5e0879e8e. The project evolved from an 8DOF platform; current main describes a 16DOF RS02-actuator configuration with Jetson Orin Nano 8G. Native mechanical sources and STEP assemblies are supplied, including 02_mechanical/STEP/WEEKDOG.STEP. The complete STEP and component payloads were inspected as geometry-file data, without validating fit or strength. [1] [3]
The mechanical notes report carbon-fiber body changes and adaptations to the leg and wheel interfaces. They also report rear-leg motor heating associated with belt tension/radial loading and breakage where a printed outer wheel hub joins the motor shaft. The authors suggest a linkage transmission and a fiber-board outer hub, but those suggestions are not verified redesigns by us. Their attribution to earlier mechanical and wheel projects remains relevant to reuse rights. [2]
The preliminary purchase workbook gives an author-reported rough 16DOF cost of approximately CNY 18,000, including structural trial-and-error costs. This is a historical project estimate, without a reconciled current BOM or complete delivered-cost scope. The detailed electronics README explicitly says custom 16DOF schematics, PCB files and formal wiring are not archived. The firmware directory is also reserved rather than a supplied current MCU project; the older 8DOF firmware belongs to a different branch/version. These limits take precedence over treating every top-level folder as a finished open build package. [4]
Reconcile the final control workspace before running
The documented final workspace is 05_software/real/sim2real_ros2_v3, targeting Ubuntu 22.04, ROS 2 Humble and Jetson. Its source implements SocketCAN motor communication and a deployment contract for motor mapping/action scaling. The guide describes a 53-observation/16-action policy interface, 50 Hz inference and a 200 Hz motor loop. These are source/documentation findings, not rates measured by Open Source Robotics. [5] [6]
At the pinned revision, the v3 policies directory contains its README but not the policy payloads that README says it retains. The named Rough and Wall ONNX files were found in the older-named, unsuffixed sim2real_ros2/policies directory. Their downloaded hashes match the values documented for v3. That provides a way to investigate the gap, but does not make a fresh v3 checkout self-contained or establish numerical equivalence on another machine. The authors also warn that TensorRT engines depend on the target JetPack/TensorRT/GPU configuration. [5] [8]
A second missing asset is the Odin relocalization map 1hao.bin. The guide explicitly says it is absent and documents an odometry-mode alternative. Sample PCD files and routes are not substitutes for that map or evidence of reproduced relocalization. Begin with the source's driver-disabled checks and resolve policy placement, motor mapping, zero positions and emergency-stop behavior before considering powered operation. We did not build or execute that route. [5] [6] [8]
What we checked
Source research only; no fabrication, EDA import, firmware/controller compilation, environment installation, policy inference/training, numerical benchmark or physical robot testing. No affiliate links. No upstream media or CAD redistributed.
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 25, 2026
- Next review
- Nov 25, 2026
- Reviewed revision
1bc9aa5
Source files and licenses
Include narrowly as a 16DOF hardware/control design reference. Actual STEP assembly and SocketCAN/ROS 2 implementations provide distinct inspectible robotics value beyond an announcement or wrapper. Broad completeness claims are limited by the specific subdirectory evidence: missing current electronics/firmware, policy-location mismatch, missing map and conflicting rights. No complete verified build claim.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed STEP and native mechanical sources exist; root MIT/derived-design scope unresolved. [3] |
| electronics | not found · License not fully assessed 16DOF custom electronics archive and formal wiring explicitly unprovided. [4] |
| firmware | not found · License not fully assessed 16DOF MCU firmware project unarchived; 8DOF branch is outside this scope. [4] |
| software | available · License not fully assessed Root MIT declaration conflicts with Proprietary package fields and README warning; Odin Apache-2.0/SDK terms separate. [7] |
| model weights | available · License not fully assessed Two matching ONNX payloads inspected outside v3; no policy execution or settled complete weight-license claim. [8] |
| documentation | available · License not fully assessed Root MIT declaration exists but scope conflicts remain; source documentation available. [1] |
Outside this entry’s scoped hardware/design or simulation contribution.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Project scope and upstream workflows
Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· README.md at · Accessed Oct 25, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 Mechanical design changes and reported failure modes
16DOF Bonjour design adaptations, belt-load/heating and printed hub breakage reports, carbon-fiber body changes and unprovided protective enclosures.Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· 02_mechanical/README.md at · Accessed Oct 25, 2026
Used for: Overview, Is this for you?, What you need, Assembly & first use and 2 more - S003 STEP design payloads
Complete WEEKDOG.STEP and component STEP payloads inspected; no mechanical fit or operating test.Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· 02_mechanical/STEP at · Accessed Oct 25, 2026
Used for: Overview, Is this for you?, Assembly & first use, Choose the 16DOF snapshot and 1 more - S004 Electronics/firmware and preliminary BOM scope
Detailed docs limit current electronics/firmware release; preliminary purchase sheet is not a matched 16DOF complete BOM.Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· 03_hardware/README.md at · Accessed Oct 25, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S005 Final ROS 2 workspace and missing relocalization map
53-observation/16-action runtime, documented rates and explicit absent 1hao.bin; v3 policy directory inventory differs from README claims.Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· 05_software/real/sim2real_ros2_v3/README.md at · Accessed Oct 25, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 Hardware bridge and action-contract implementation
Real SocketCAN motor I/O and deployment contract source inspected; no runtime test or safety certification.Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· 05_software/real/sim2real_ros2_v3/src/sim2real_common/include/sim2real_common/deployment_contract.hpp at · Accessed Oct 25, 2026
Used for: Is this for you?, What you need, Assembly & first use, Reconcile the final control workspace before running - S007 MIT declaration and contradictory package metadata
Root MIT declaration coexists with Proprietary package fields and v3 README licensing warning; complete rights need reconciliation.Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· LICENSE at · Accessed Oct 25, 2026
Used for: Is this for you?, Cost, Source files and licenses - S008 Pinned final-policy location and artifact audit
Supplied ONNX artifacts can be found elsewhere with matching hashes; physical/model compatibility and relocalization remain unverified.Revision, date & where cited
zeitvex/RC_WheelLeg contributors · github.com · revision
1bc9aa5· 05_software/real/sim2real_ros2_v3 at · Accessed Oct 25, 2026
Used for: Is this for you?, Assembly & first use, Reconcile the final control workspace before running, Source files and licenses - S009 Upstream image and reuse attribution
Media-only review: Upstream photograph of an RC_WheelLeg robot configuration. The documentation image’s MIT reuse grant does not settle the separate driver-package license conflicts described in this profile. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
RC_WheelLeg contributors · github.com · revision
1bc9aa5· Image SHA-256 a4e71dafb138c4e503545103d57bfc564a1aeda2001fc2915890644dd933aca7; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.