Ada robotic hand V1.1
End effectorFive-actuator robotic development hand with a flexible printed palm, rigid covers and separate Almond controller and Artichoke firmware sources. [1] [2] [3] [4] [5]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Builders evaluating a sourced mechanical design and its integration requirements. [1]
- Cost
- No current cost yet. Upstream bill of materials [3]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Overview
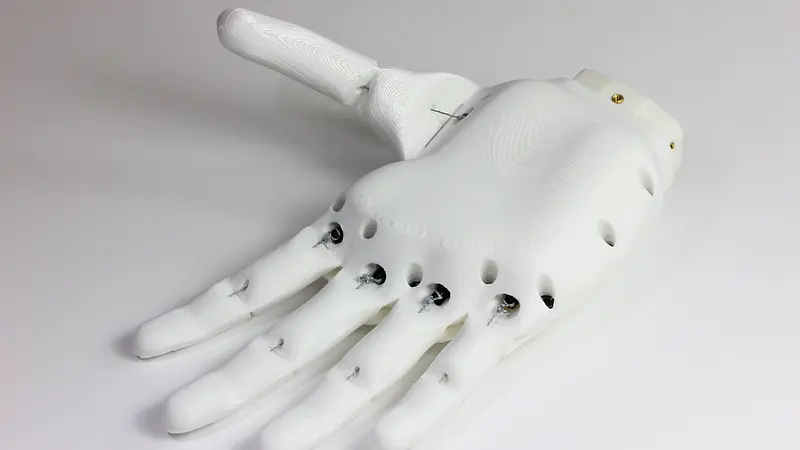
Ada is a robotic development hand whose flexible palm and fingers are printed as one component. The V1.1 repository supplies left- and right-hand STL sets and editable Blender files. Choose one side before collecting its palm, back cover and two controller trays; the preview here shows only the right palm-and-fingers component. Motors and electronics are separate. Upstream explicitly describes Ada as a development kit, not a medical device. [1] [2] [3] [7]
Is this for you?
- Known limitations
- Legacy assembly/tutorial links fail; matched tendon routing and calibration remain unresolved.
- Almond BOM may be incomplete; current actuator availability and complete delivered cost not verified.
- No cobot or delta mounting/control qualification.
Editorial classification; not physical qualification.
3D preview
Ada V1.1 right palm and fingers. Single flexible palm-and-fingers component; excludes actuators, electronics, trays and back cover.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STL · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Open Bionics, revision 2dbf3cc6c5df112066f12c11af1d001e319a766f. Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STL does not declare units; confirm dimensions against the project design. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Flexible fingers, rigid electronics housing
The datasheet specifies NinjaFlex for the palm and PLA or ABS for the back cover and controller trays. Substituting one rigid material for every part would therefore depart from the documented design. The manufacturer's component list calls for five PQ12-30-12-P linear actuators, an Almond board, tendon string, threaded inserts, screws and fingertip grips. That historical list identifies a configuration, not current stock or a delivered quote. Confirm actuator availability and the required feedback variant before pricing a build. [2] [3]
The May 2016 datasheet reports five degrees of freedom and 12 V operation, and includes a dimensioned wrist interface with four M3 fasteners. A drawing is useful for designing a mount, but it does not establish a cobot or delta interface. The interactive model shows geometry only; it does not establish print quality or grip performance. The separate photograph shows an upstream assembled hand and is not independently version-dated. [2]
Reconcile the controller before assembling
The hand datasheet names Almond V1.2. Its separate repository includes the board and schematic, but the maintainer warns that the later-uploaded BOM may be incorrect or incomplete. Reconcile that draft list with the board revision before fabrication or component orders. Artichoke V1.2 is the corresponding firmware family for Almond and requires FingerLib; its README documents 38,400-baud serial control and a command-help prompt. A matched firmware/dependency build was not verified here. [2] [4] [5] [8]
The older assembly and firmware tutorial links returned errors during this review. Until a complete guide is recovered, tendon routing, tensioning and calibration remain build gaps rather than verified instructions. No current kit availability, complete setup cost or physical test is claimed. [6]
The design repository, datasheet, Almond README and Artichoke README declare CC-BY-SA-4.0. Those grants do not make the purchased actuators open manufacturing designs. [1] [2] [4] [5]
What we checked
Source review only. No assembly, procurement, control bringup or physical performance testing.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 4, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
2dbf3cc
Source files and licenses
Mechanical design files are licensed; purchased components, source completeness and a working matched configuration remain separate checks.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 First-party repository files; no manufacturing source for purchased components inferred. [1] [2] |
| electronics | available · CC-BY-SA-4.0 Separate upstream repository; matching build and dependencies not tested. Almond BOM is explicitly draft and potentially incomplete. [4] [8] |
| firmware | available · CC-BY-SA-4.0 Separate upstream repository; matching build and dependencies not tested. Artichoke requires FingerLib; matched compilation not verified. [5] |
| software | not found · License not fully assessed Complete revision-matched source for this layer was not established in this mechanical repository; external host components require separate assessment. [1] |
| documentation | available · CC-BY-SA-4.0 First-party repository files; no manufacturing source for purchased components inferred. [1] [2] |
No learned model or dataset selected for this mechanical configuration.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Mechanical design and license
Revision, date & where cited
Open Bionics · github.com · revision
2dbf3cc· README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S002 Ada V1.1 datasheet
Revision, date & where cited
Open Bionics · github.com · revision
2dbf3cc· Ada_v1_1_Datasheet.pdf at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S003 Open Bionics component list
Revision, date & where cited
Open Bionics · youmagine.com · Open Bionics component list; accessed 2026-09-30 · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Flexible fingers, rigid electronics housing - S004 Almond controller and BOM caveat
Revision, date & where cited
Open Bionics · github.com · revision
34d1181· README.md at · Accessed Sep 30, 2026
Used for: Hardware & parts, Reconcile the controller before assembling, Source files and licenses - S005 Artichoke firmware and dependencies
Revision, date & where cited
Open Bionics · github.com · revision
676c67a· README.md at · Accessed Sep 30, 2026
Used for: Reconcile the controller before assembling, Source files and licenses - S006 Legacy tutorial retrieval checks
Revision, date & where cited
Open Bionics · openbionicslabs.com · Legacy tutorial retrieval checks; accessed 2026-09-30 · Accessed Sep 30, 2026
Used for: Assembly & first use, Reconcile the controller before assembling - S007 Preserved mechanical artifact inventory
Files present in the preserved pinned archive; not an executed build.Revision, date & where cited
Open Bionics · github.com · revision
2dbf3cc· Accessed Sep 30, 2026
Used for: Overview - S008 Preserved Almond artifact inventory
Files present in the preserved pinned archive; not an executed build.Revision, date & where cited
Open Bionics · github.com · revision
34d1181· Accessed Sep 30, 2026
Used for: Reconcile the controller before assembling, Source files and licenses
Videos
- S009 Open Bionics (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Open Bionics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Replaced duplicate CAD still with an attributed upstream image; image scope and reuse evidence reviewed.
2026-10-04 — Added 1 YouTube reference(s) (S009): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.