Thymio
Robot / hardware buildEducational wheeled robot; this profile selects Thymio II PCB version 2.1 design sources and separately preserved V14 firmware, with explicit generation and dependency boundaries. [1] [2] [8] [10]
Build & first use →Official website
- For
- Educators using supported complete robots; Developers researching Thymio II hardware and firmware revisions [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-3.0 · license not fully assessed for firmware · Details by part
Overview
Thymio is an educational wheeled robot developed through the EPFL and ECAL ecosystem and produced by Mobsya. This profile selects the Thymio II electronics release PCB_version_2.1, commit 8d0cdec0c5fd3f5352c4c15204b279e2143cd524. The official site now also announces Thymio 3; the older design archive must not be presented as that newer robot's fabrication package. [1] [2] [7]
Is this for you?
3D preview
Thymio II mechanical assembly. The complete Thymio II mechanical STEP assembly from the official electronics-thymio2 Models folder (a 2011 Pro/ENGINEER export by EPFL): upper and lower shells, both wheel assemblies, two gear motors, the main and capacitive-touch circuit boards, battery, IR sensors and screws at their source placements. The assembly file references 12 separate part files; the download bundle contains all of them unchanged, plus two unreferenced part files from the same folder. The assembly predates the 2018 repository revision, and the current production revision is not verified. Licensed CC BY-SA 3.0. Electronics, fit and operation are not verified.
Share-alike license: the repository license.txt is Creative Commons Attribution-ShareAlike 3.0 Unported, and the README says the Thymio II design is freely available under that license. This preview and the hosted original files remain under CC BY-SA 3.0 with attribution to EPFL MOBOTS, ECAL and Mobsya. License: CC BY-SA 3.0 · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP assembly bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: EPFL MOBOTS, ECAL and Mobsya, revision 8d0cdec0c5fd3f5352c4c15204b279e2143cd524. Original and preview: CC-BY-SA-3.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Operating system
- Thymio Suite desktop: Linux, macOS and Windows; official product page also names Android and iPad client apps
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
The archive contains design and production-reference files
The selected repository includes Altium schematic and board sources, fabrication outputs, spreadsheet BOMs and STEP models. The models include an assembly and shell, wheel, battery and motor references. File presence establishes available design material, not a validated printable kit or a confirmed match between every historical output and the selected board revision. [1] [5]
Mobsya declares the Thymio II hardware under CC BY-SA 3.0, and the repository contains the full license. This is a useful source package for studying the robot's electronics and geometry. Fabrication readiness, component substitutions, assembly yield and complete delivered cost were not established here. [1] [3] [5]
Firmware is separately versioned and has separate dependencies
Firmware tag V14 was preserved at commit 5dca3889903ce7d0deb9608fee0c4263136fecc3. The documented target is PIC24FJ128GB106, with Microchip XC16 and legacy peripheral libraries. The build also needs a separate Aseba source tree and submodules including molole and cmake-microchip. A repository archive alone does not supply all of these dependencies. [8] [9] [12]
The source defines firmware version 14 and variant 1, which its own comments identify as the development variant. That distinction is recorded rather than assuming the source tag proves an identical production binary. The instructions describe both MPLAB X and an experimental CMake path, and specify the Thymio firmware upgrader for upload. Neither path was built or flashed by this catalog. [8] [9] [10]
The main firmware source declares LGPL version 3, while the bundled USB directory has a separate license restricting its supplied software to Microchip PIC products. This profile therefore leaves the normalized whole-firmware license unresolved. The broad open-source description on the product page does not eliminate those component-specific terms or establish the licenses of uncollected dependencies. [6] [10] [11] [12]
Using a complete robot and reproducing its hardware are different tasks
The official product page describes wheel motors, LEDs, a speaker and several sensor types, and points users to Thymio Suite on desktop systems and mobile client apps. Those are manufacturer-described capabilities. This review did not measure sensor behavior, battery endurance or control performance, and it does not claim that the selected old hardware release has been tested with current software. [6]
For source research, the next concrete task is matching the actual robot generation and board revision to its firmware, host software and replacement parts. The repository is valuable evidence for that work, but it does not by itself establish a current complete build budget or qualification result. [2] [5] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: host computer, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-3.0 Selected Thymio II design archive. STEP reference models and Altium/fabrication files are present; completeness, manufacturing readiness and exact mechanical/board revision matching were not validated. [1] [3] [5] |
| electronics | available · CC-BY-SA-3.0 Selected Thymio II design archive. STEP reference models and Altium/fabrication files are present; completeness, manufacturing readiness and exact mechanical/board revision matching were not validated. [1] [3] [5] |
| firmware | available · License not fully assessed V14 source main.c declares LGPL version 3, but usb_pic24 has Microchip PIC-only terms and external dependencies remain separate. No normalized whole-firmware license assigned. [8] [10] [11] [12] |
| software | not found · License not fully assessed Thymio Suite and Aseba are identified, but complete matching application sources and dependency licenses were not collected in this scoped hardware review. [6] [8] [12] |
| documentation | available · CC-BY-SA-3.0 Selected electronics-repository documentation only; website media and separate firmware documentation are not assigned this license. [1] [3] |
Selected conventional Thymio II control platform does not require learned policy weights or training data.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Mobsya/electronics-thymio2: README.md
Revision, date & where cited
github.com · revision
8d0cdec· Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, The archive contains design and production-reference files and 1 more - S002 Mobsya/electronics-thymio2: commit 8d0cdec
Revision, date & where cited
github.com · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Using a complete robot and reproducing its hardware are different tasks, What we checked - S003 Mobsya/electronics-thymio2: license.txt
Revision, date & where cited
github.com · revision
8d0cdec· Accessed Oct 1, 2026
Used for: The archive contains design and production-reference files, Source files and licenses - S004 Mobsya/electronics-thymio2: files
Revision, date & where cited
github.com · revision
8d0cdec· archive file inventory · Accessed Oct 1, 2026 - S005 Thymio II complete archive file inventory
Revision, date & where cited
github.com · revision
8d0cdec· archive inventory · Accessed Oct 1, 2026
Used for: The archive contains design and production-reference files, Using a complete robot and reproducing its hardware are different tasks, Source files and licenses - S006 Official Thymio official-product
Revision, date & where cited
Mobsya / project contributors · thymio.org · Retrieved October 1 2026 · Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, Firmware is separately versioned and has separate dependencies, Using a complete robot and reproducing its hardware are different tasks and 1 more - S007 Official Thymio official-home
Revision, date & where cited
Mobsya / project contributors · thymio.org · Retrieved October 1 2026 · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts - S008 Thymio II V14 readme.md
Revision, date & where cited
github.com · revision
5dca388· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Hardware & parts, Firmware is separately versioned and has separate dependencies and 2 more - S009 Thymio II V14 cmake.md
Revision, date & where cited
github.com · revision
5dca388· Accessed Oct 1, 2026
Used for: What you need, Firmware is separately versioned and has separate dependencies - S010 Thymio II V14 main.c
Revision, date & where cited
github.com · revision
5dca388· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware & parts, Firmware is separately versioned and has separate dependencies, Source files and licenses - S011 Thymio II V14 usb_pic24/LICENSE
Revision, date & where cited
github.com · revision
5dca388· Accessed Oct 1, 2026
Used for: Is this for you?, Firmware is separately versioned and has separate dependencies, Source files and licenses - S012 Thymio II V14 .gitmodules
Revision, date & where cited
github.com · revision
5dca388· Accessed Oct 1, 2026
Used for: What you need, Firmware is separately versioned and has separate dependencies, Source files and licenses - S014 Upstream image and reuse attribution
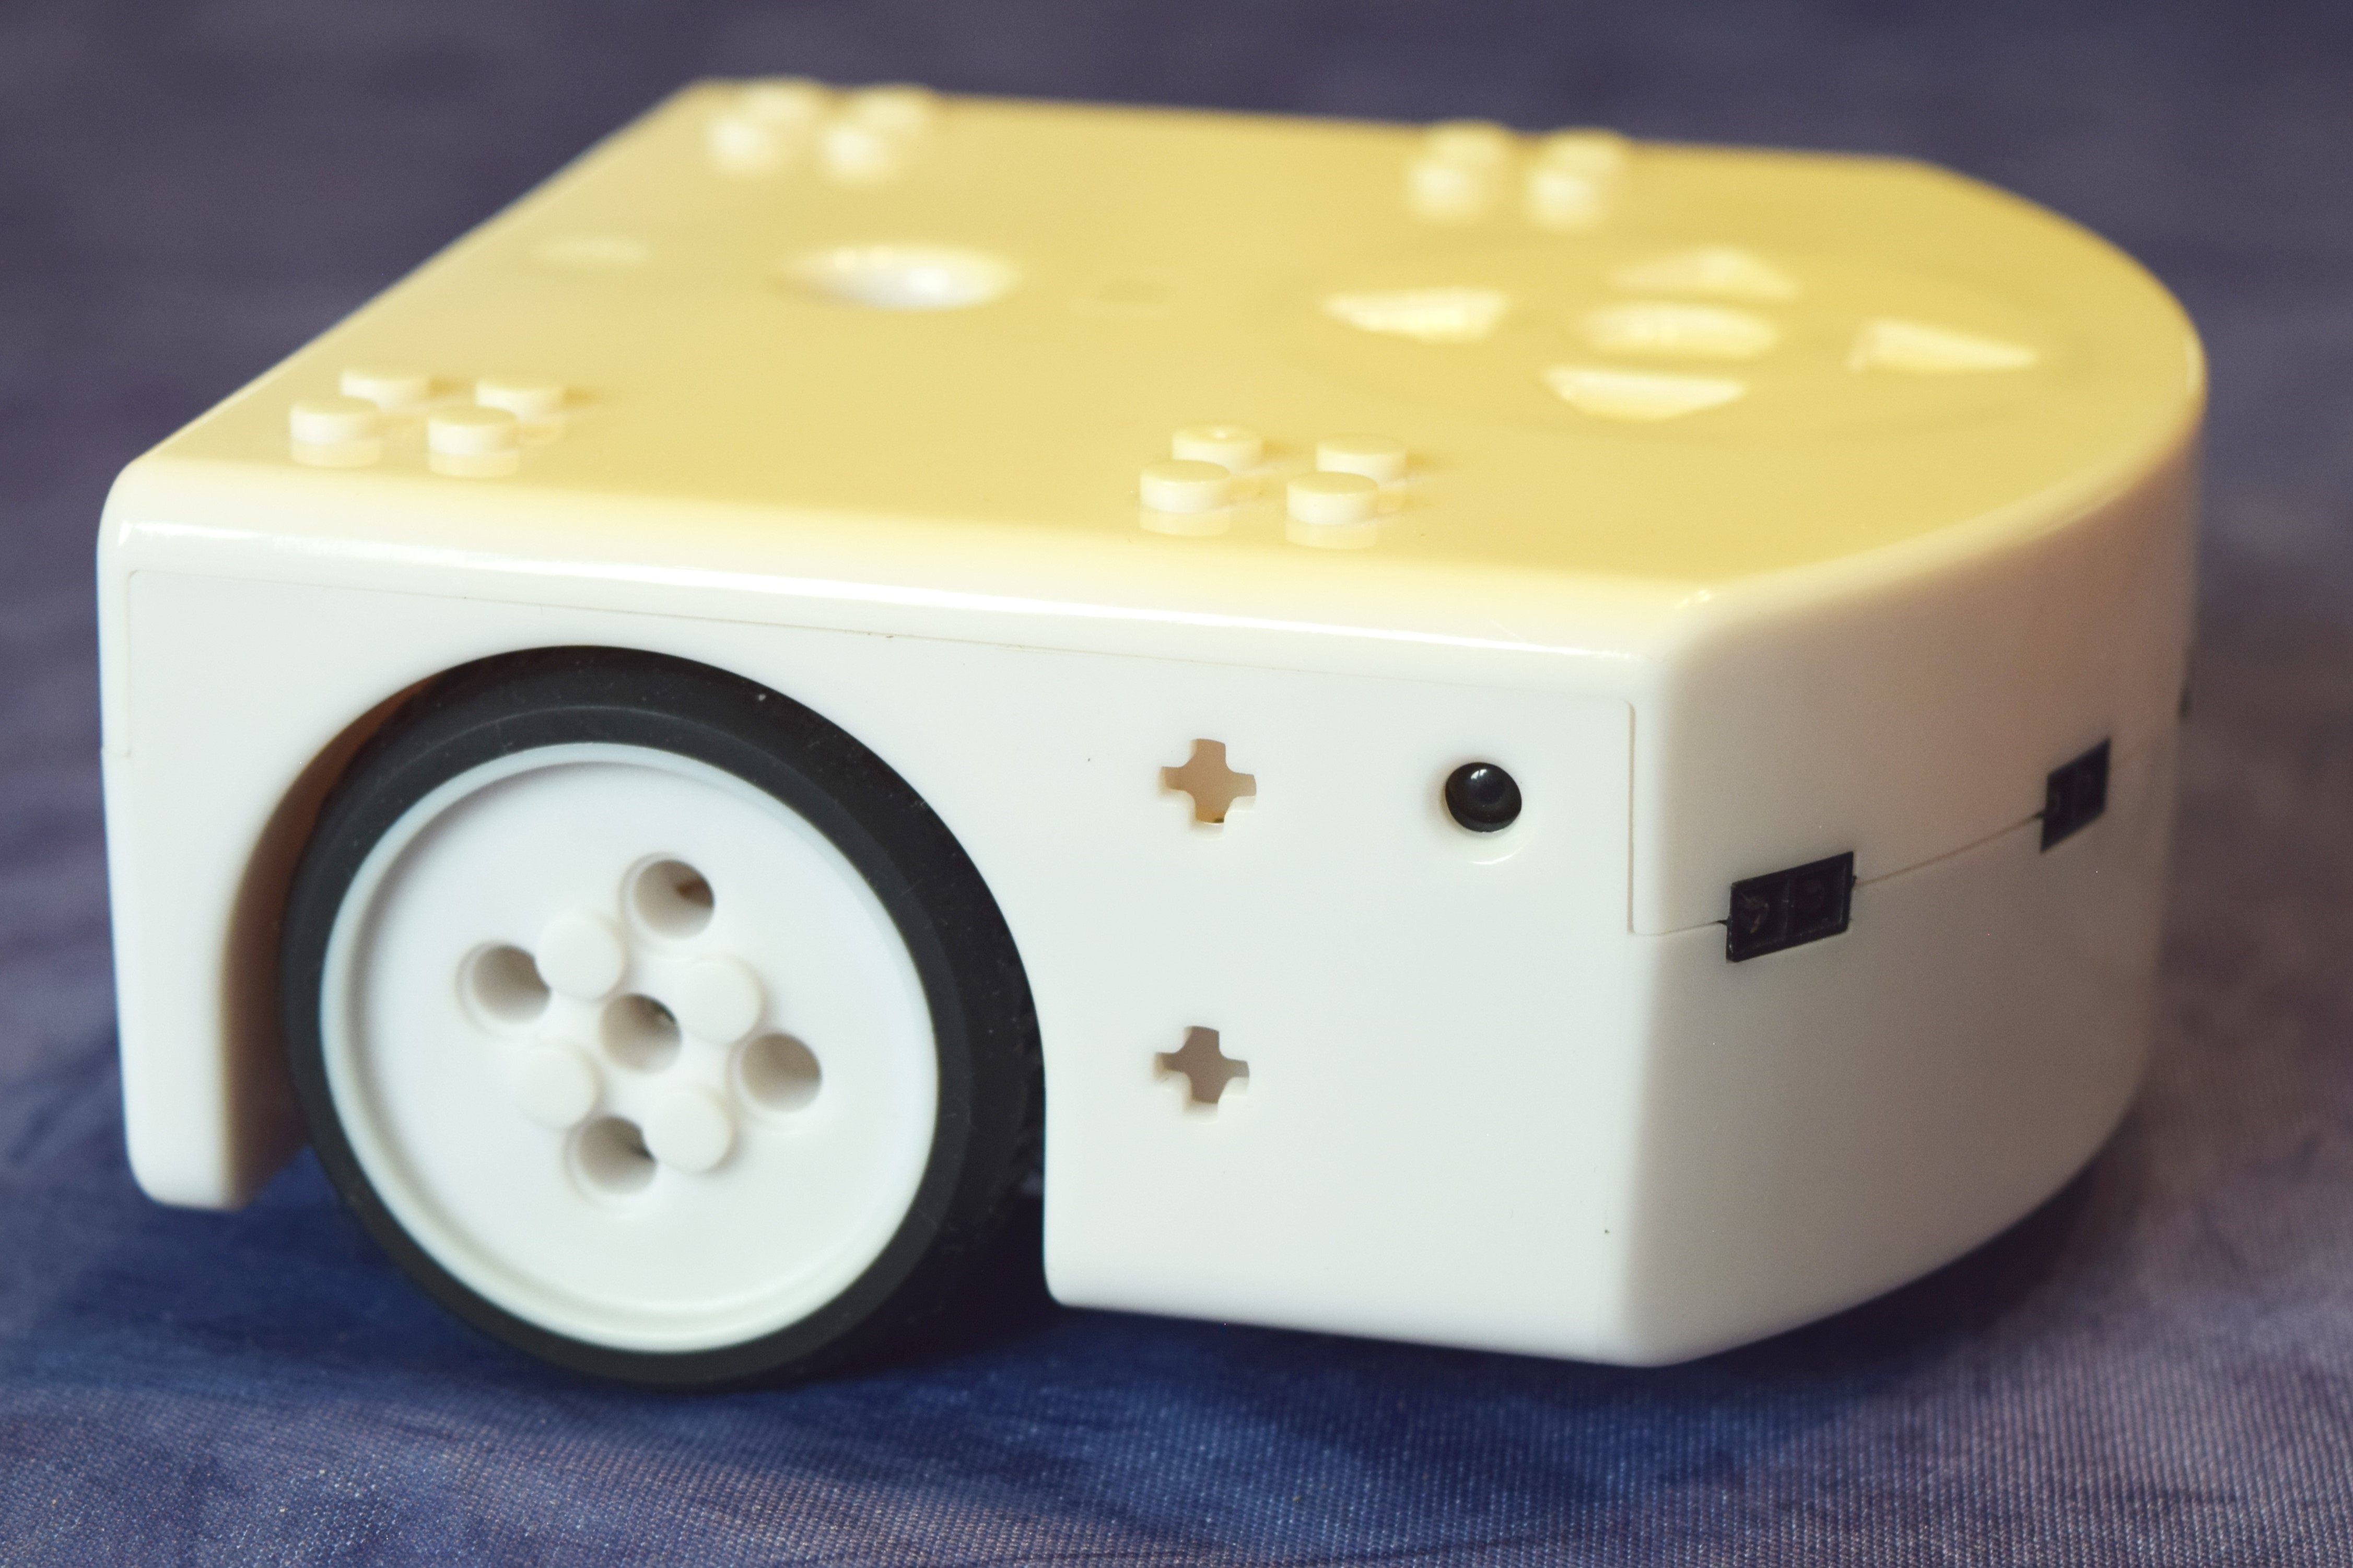
Media-only review: Photograph of a Thymio II robot, taken January 20, 2026. Reuse basis: CC0-1.0. Inspected the original photo and file-specific own-work creator/license declaration. The pictured version and other robot in the frame are disclosed. This image permission does not change hardware reuse restrictions. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Onibi1999 · commons.wikimedia.org · File-specific creator, own-work declaration, licensing and file history; image SHA-256 15836e9571191126d496beed47fe392c7453a366bbb80b845aee4911cf964e2e · Accessed Oct 26, 2026
Videos
- S013 Thymio (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Thymio · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S013): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.